
Wireless-Controlled Robotic System with Arduino and NRF24L01
View and Edit Project In Cirkit Designer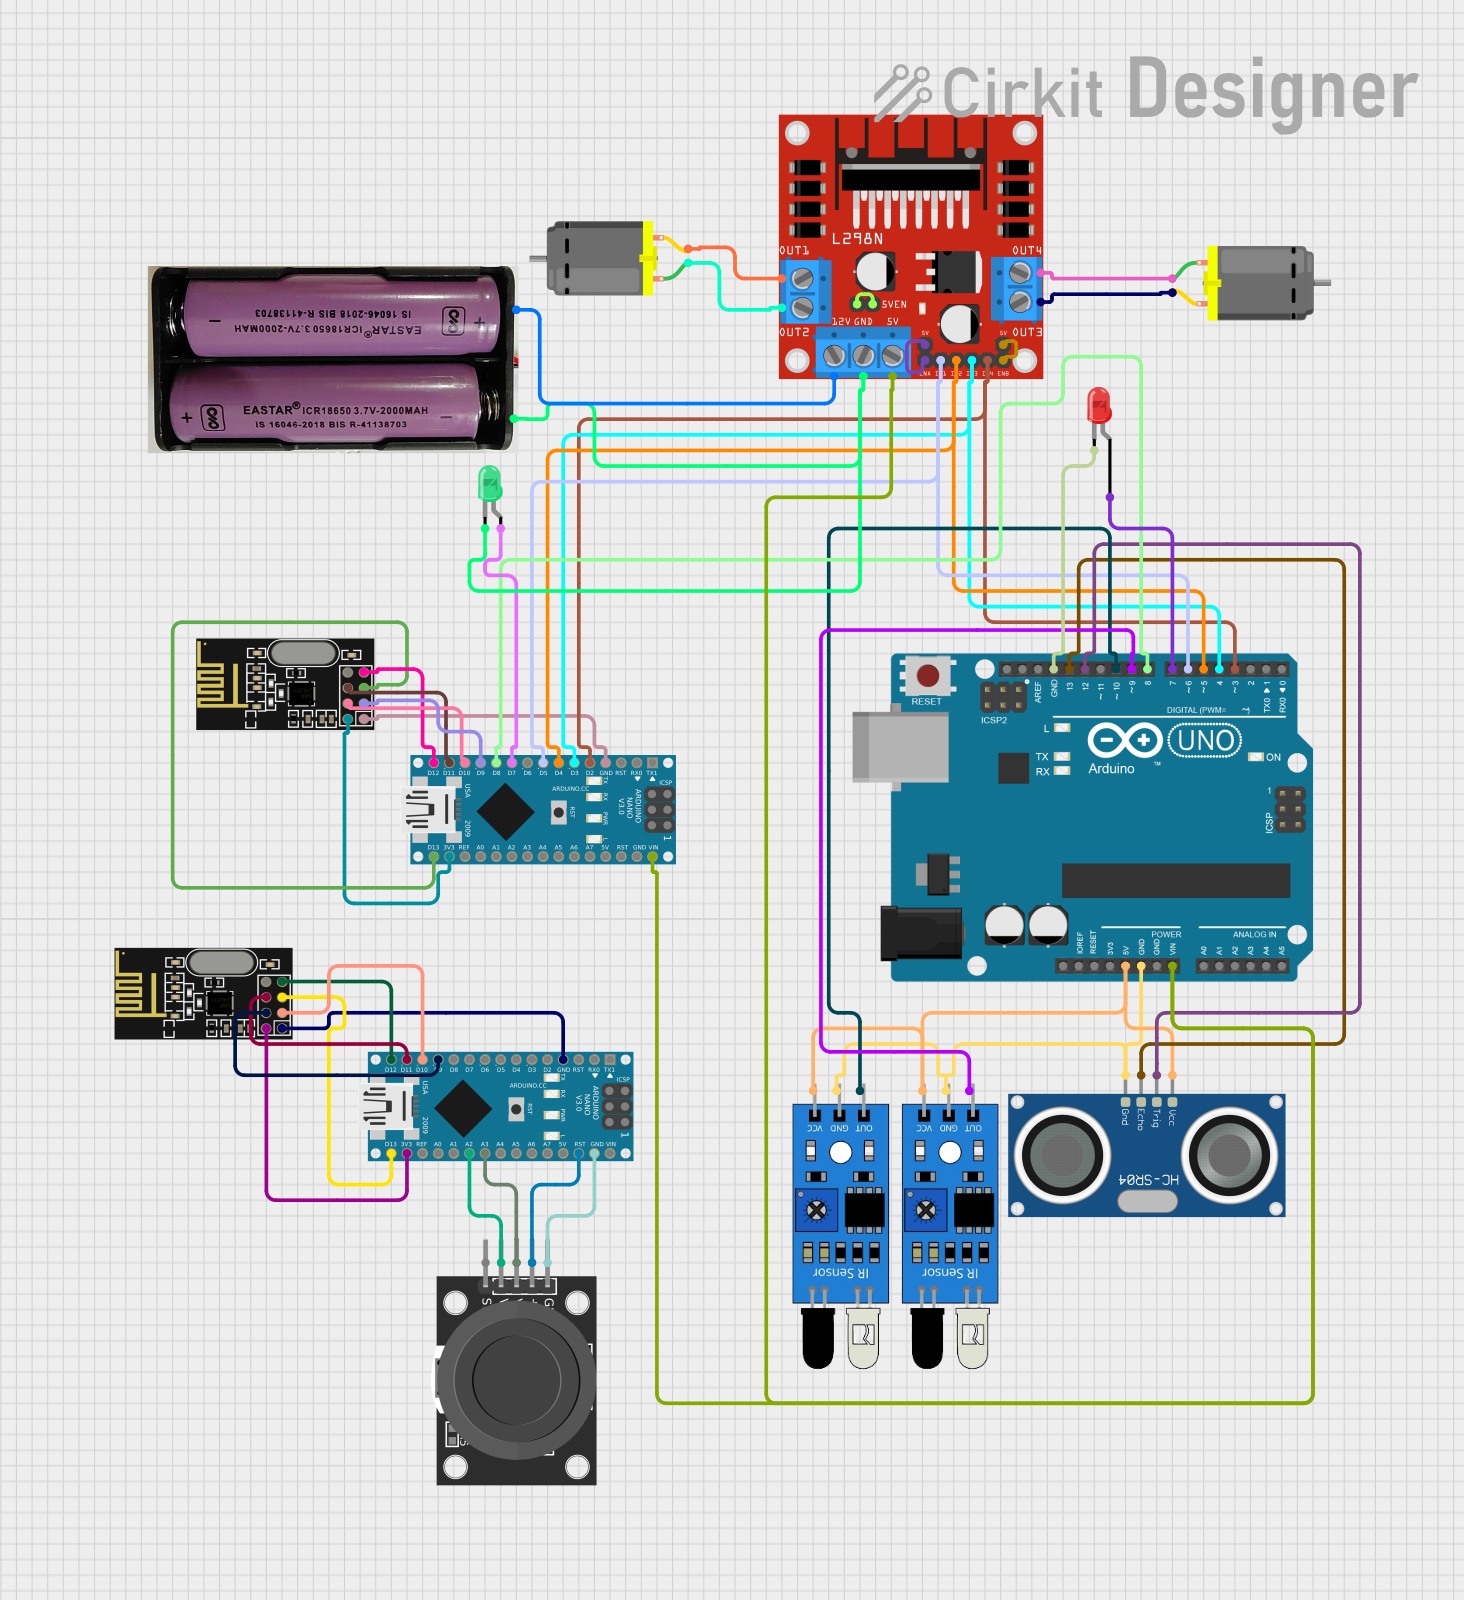
Circuit Documentation
Summary
This document provides a detailed overview of a circuit designed to interface an Arduino Nano with an NRF24L01 wireless transceiver module, a KY-023 Dual Axis Joystick Module, an L298N DC motor driver, an HC-SR04 Ultrasonic Sensor, IR sensors, LEDs, and DC motors. The circuit is powered by a 7.4V power source and includes an Arduino UNO for additional functionality. The purpose of the circuit is not explicitly stated, but it appears to be a complex system potentially for a robotics or remote control application, given the components involved.
Component List
Microcontrollers
- Arduino Nano: A compact microcontroller board based on the ATmega328P, featuring digital and analog I/O pins.
- Arduino UNO: A microcontroller board based on the ATmega328P, with a variety of digital and analog I/O pins.
Wireless Module
- NRF24L01: A 2.4GHz wireless transceiver module used for short-range wireless communication.
Sensors and Modules
- KY-023 Dual Axis Joystick Module: A joystick controller with two analog outputs and a digital output corresponding to the x-axis, y-axis, and button press.
- HC-SR04 Ultrasonic Sensor: An ultrasonic ranging module for distance measurement.
- IR Sensor: An infrared sensor used for detecting obstacles or receiving IR signals.
Motor Driver
- L298N DC Motor Driver: A module capable of driving two DC motors or one stepper motor with direction and speed control.
Actuators
- DC Motor: An electric motor that converts electrical energy into mechanical rotation.
Power Supply
- 7.4V Battery: A power source for the circuit.
Indicators
- LED (Green and Red): Light Emitting Diodes used as visual indicators.
Wiring Details
Arduino Nano
- Connected to NRF24L01 for wireless communication.
- Interfaces with the KY-023 Joystick Module for control inputs.
- Wired to the L298N Motor Driver for motor control signals.
Arduino UNO
- Provides control signals to the L298N Motor Driver.
- Reads data from the HC-SR04 Ultrasonic Sensor and IR Sensors.
- Drives LEDs for indication purposes.
NRF24L01
- Communicates with the Arduino Nano for wireless data transmission.
KY-023 Dual Axis Joystick Module
- Provides analog input to the Arduino Nano for control purposes.
L298N DC Motor Driver
- Receives control signals from both Arduino boards to drive the DC Motors.
- Powered by the 7.4V battery.
HC-SR04 Ultrasonic Sensor
- Connected to the Arduino UNO for distance measurements.
IR Sensors
- Detects obstacles or receives IR signals, interfaced with the Arduino UNO.
LEDs (Green and Red)
- Used as indicators, controlled by the Arduino UNO.
DC Motors
- Driven by the L298N Motor Driver to perform mechanical actions.
7.4V Battery
- Supplies power to the motor driver and indirectly to other components through voltage regulation.
Documented Code
Arduino Nano Code (First Instance)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Arduino Nano Code (Second Instance)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Arduino UNO Code
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code for each microcontroller is a template and does not contain specific functionality. It is expected that the user will add the necessary code to initialize and control the connected components as per the requirements of the application.