
ESP32-Based Wi-Fi Controlled Robotic Car with Ultrasonic Obstacle Detection
View and Edit Project In Cirkit Designer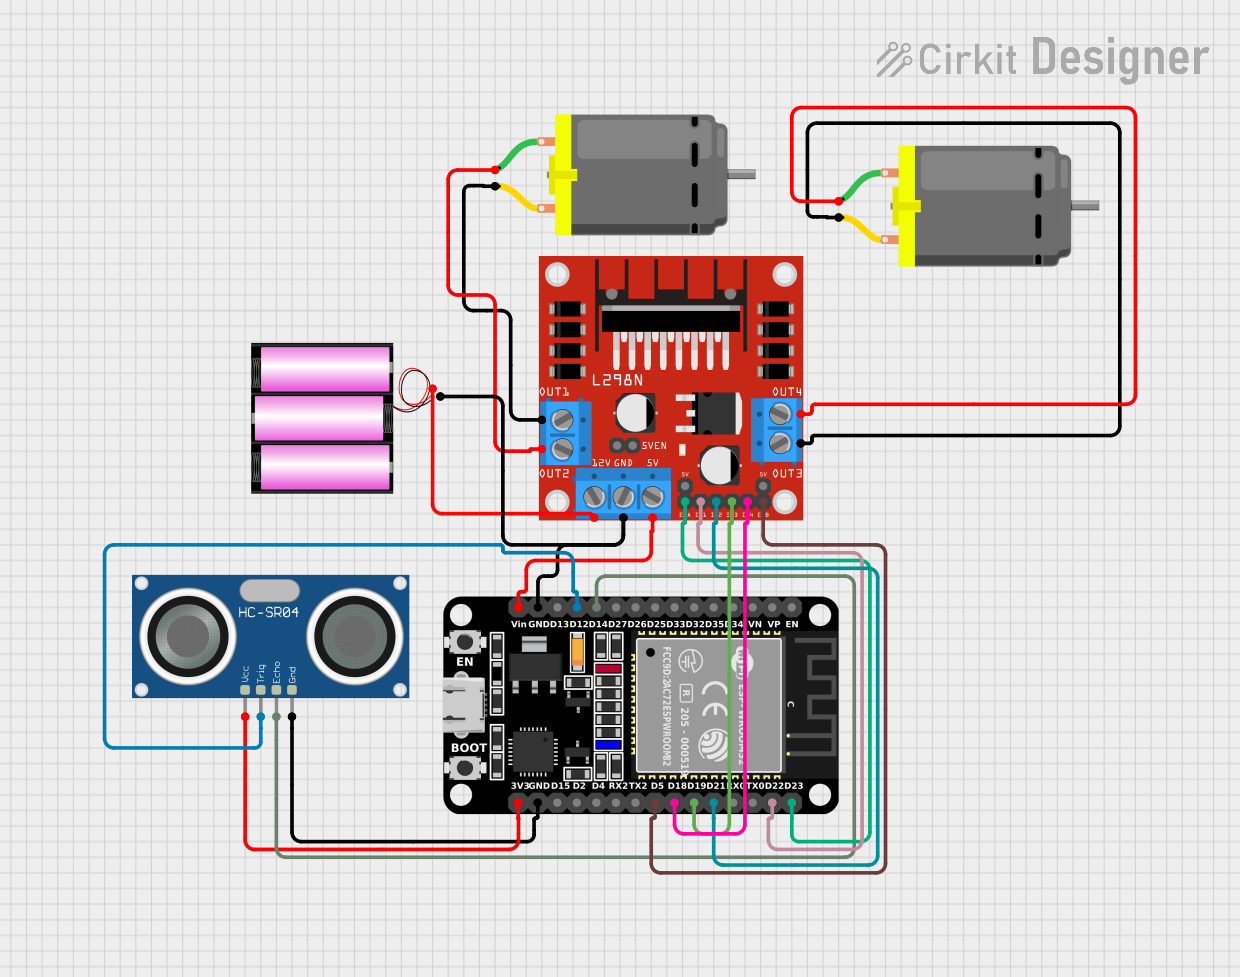
Circuit Documentation
Summary
This circuit involves an ESP32 microcontroller interfacing with an HC-SR04 Ultrasonic Sensor and an L298N DC motor driver to control two DC motors. The ESP32 is responsible for processing sensor data and controlling the motor driver to drive the motors. The circuit is powered by a 12V battery.
Component List
ESP32 (30 pin)
- Description: A powerful microcontroller with built-in Wi-Fi and Bluetooth capabilities.
- Pins: EN, VP, VN, D34, D35, D32, D33, D25, D26, D27, D14, D12, D13, GND, Vin, D23, D22, TX0, RX0, D21, D19, D18, D5, TX2, RX2, D4, D2, D15, 3V3
HC-SR04 Ultrasonic Sensor
- Description: A sensor used to measure distance by using ultrasonic waves.
- Pins: VCC, TRIG, ECHO, GND
L298N DC Motor Driver
- Description: A dual H-Bridge motor driver that allows control of two DC motors.
- Pins: OUT1, OUT2, 12V, GND, 5V, OUT3, OUT4, 5V-ENA-JMP-I, 5V-ENA-JMP-O, +5V-J1, +5V-J2, ENA, IN1, IN2, IN3, IN4, ENB
DC Motor (Motor 1)
- Description: A simple DC motor.
- Pins: pin 1, pin 2
DC Motor (Motor 2)
- Description: A simple DC motor.
- Pins: pin 1, pin 2
Battery 12V
- Description: A 12V battery used to power the circuit.
- Pins: +, -
Wiring Details
ESP32 (30 pin)
- D14 connected to HC-SR04 Ultrasonic Sensor ECHO
- D12 connected to HC-SR04 Ultrasonic Sensor TRIG
- GND connected to L298N DC Motor Driver GND, Battery 12V -, HC-SR04 Ultrasonic Sensor GND
- Vin connected to L298N DC Motor Driver 5V
- D23 connected to L298N DC Motor Driver ENA
- D22 connected to L298N DC Motor Driver IN1
- D21 connected to L298N DC Motor Driver IN2
- D19 connected to L298N DC Motor Driver IN3
- D18 connected to L298N DC Motor Driver IN4
- D5 connected to L298N DC Motor Driver ENB
- 3V3 connected to HC-SR04 Ultrasonic Sensor VCC
HC-SR04 Ultrasonic Sensor
- ECHO connected to ESP32 D14
- TRIG connected to ESP32 D12
- GND connected to ESP32 GND
- VCC connected to ESP32 3V3
L298N DC Motor Driver
- GND connected to Battery 12V -, ESP32 GND
- 5V connected to ESP32 Vin
- ENA connected to ESP32 D23
- IN1 connected to ESP32 D22
- IN2 connected to ESP32 D21
- IN3 connected to ESP32 D19
- IN4 connected to ESP32 D18
- ENB connected to ESP32 D5
- OUT1 connected to DC Motor (Motor 2) pin 2
- OUT2 connected to DC Motor (Motor 2) pin 1
- OUT3 connected to DC Motor (Motor 1) pin 2
- OUT4 connected to DC Motor (Motor 1) pin 1
- 12V connected to Battery 12V +
DC Motor (Motor 1)
- pin 2 connected to L298N DC Motor Driver OUT3
- pin 1 connected to L298N DC Motor Driver OUT4
DC Motor (Motor 2)
- pin 2 connected to L298N DC Motor Driver OUT1
- pin 1 connected to L298N DC Motor Driver OUT2
Battery 12V
- - connected to L298N DC Motor Driver GND, ESP32 GND
- + connected to L298N DC Motor Driver 12V
Documented Code
sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
documentation.txt