
Arduino Mega 2560 Dual Stepper Motor Controller with A4988 Drivers and Battery Power
View and Edit Project In Cirkit Designer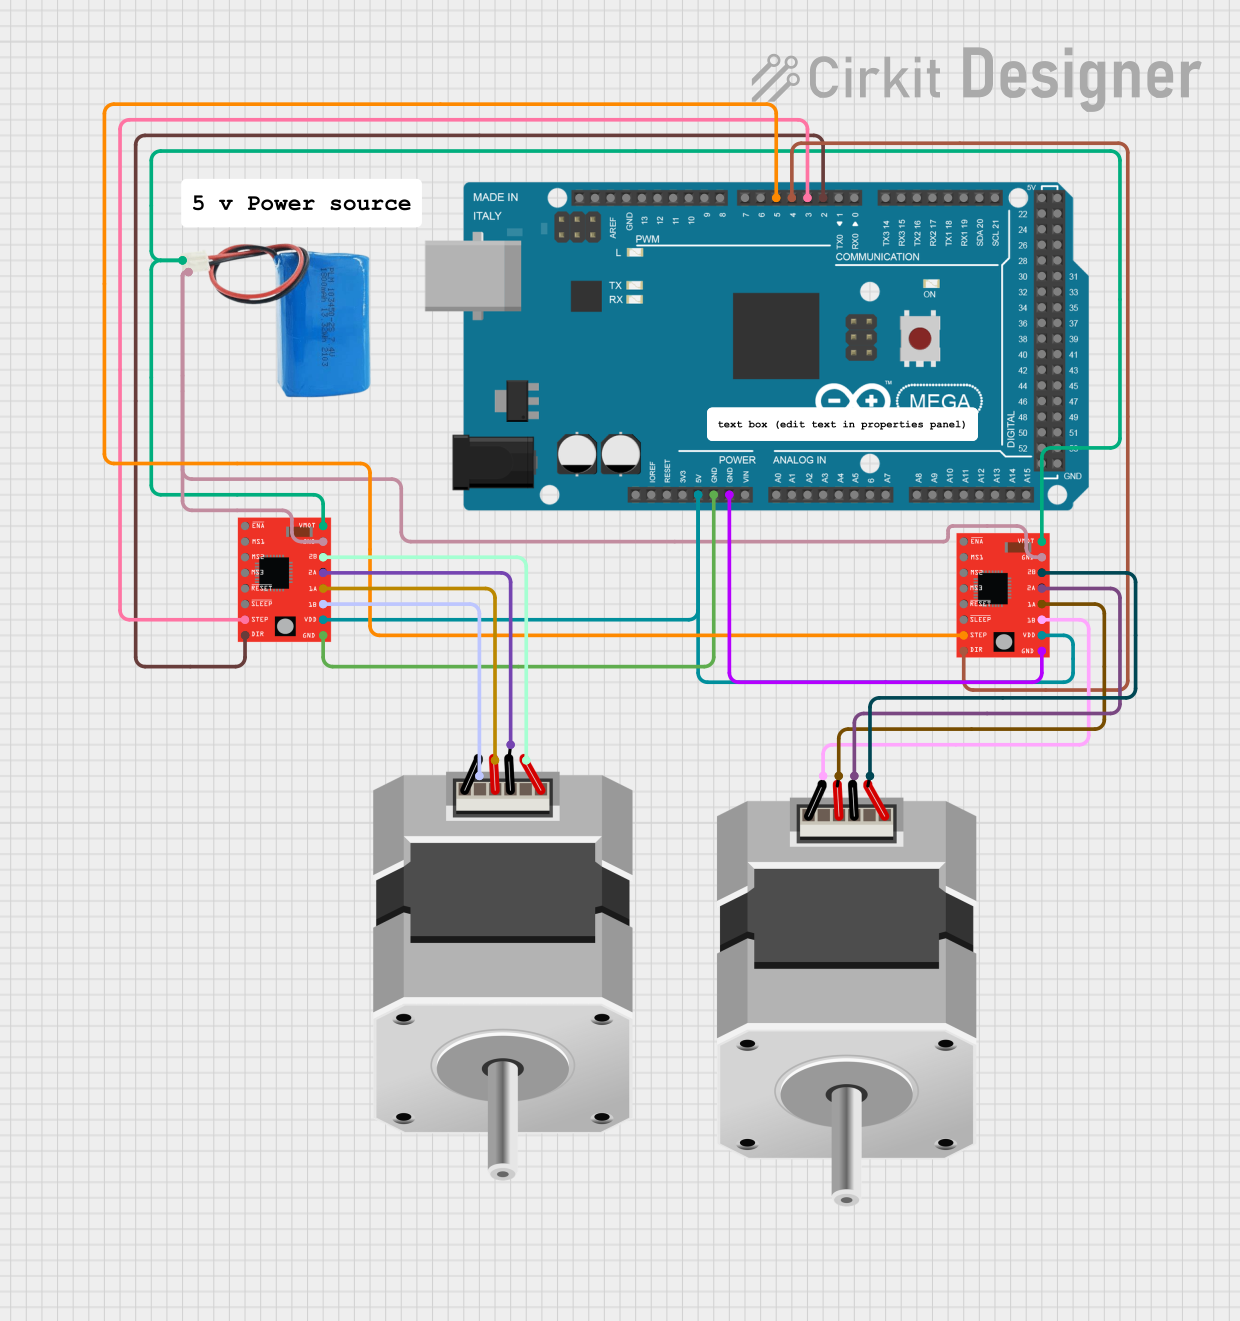
Circuit Documentation
Summary
This circuit controls two bipolar stepper motors using A4988 stepper motor drivers and an Arduino Mega 2560. The motors rotate 3000 steps forward and then 3000 steps backward with a 1-second delay between direction changes. The DIR and STEP pins for each motor are connected to the Arduino Mega 2560.
Component List
Stepper Motor (Bipolar)
- Pins: D, B, C, A
- Description: A bipolar stepper motor used for precise control of rotational position.
Arduino Mega 2560
- Pins: IOREF, RESET, 3V3, 5V, GND, VIN, A0-A15, D21/SCL, D20/SDA, D19/RX1, D18/TX1, D17 PWM/RX2, D16 PWM/TX2, D15/RX3, D14/TX3, D0 RX0, D1 TX0, D2 PWM, D3 PWM, D4 PWM, D5 PWM, D6 PWM, D7 PWM, D8 PWM, D9 PWM, D10 PWM, D11 PWM, D12 PWM, D13 PWM, AREF, SDA, SCL, D52, D50, D48, D46, D44, D42, D40, D38, D36, D34, D32, D30, D28, D26, D24, D22, D53, D51, D49, D47, D45, D43, D41, D39, D37, D35, D33, D31, D29, D27, D25, D23
- Description: A microcontroller board based on the ATmega2560, used to control the stepper motors.
A4988 Stepper Motor Driver (Red)
- Pins: ENABLE, MS1, MS2, MS3, RESET, SLEEP, STEP, DIR, VMOT, GND, 2B, 2A, 1A, 1B, VDD
- Description: A driver module for controlling bipolar stepper motors.
5V Battery
- Pins: positive, negative
- Description: A power source providing 5V for the circuit.
Wiring Details
Stepper Motor (Bipolar) 1
- Pin D connected to A4988 Stepper Motor Driver (Red) 1B
- Pin B connected to A4988 Stepper Motor Driver (Red) 1A
- Pin C connected to A4988 Stepper Motor Driver (Red) 2A
- Pin A connected to A4988 Stepper Motor Driver (Red) 2B
Stepper Motor (Bipolar) 2
- Pin D connected to A4988 Stepper Motor Driver (Red) 1B
- Pin B connected to A4988 Stepper Motor Driver (Red) 1A
- Pin C connected to A4988 Stepper Motor Driver (Red) 2A
- Pin A connected to A4988 Stepper Motor Driver (Red) 2B
Arduino Mega 2560
- Pin 5V connected to A4988 Stepper Motor Driver (Red) VDD
- Pin GND connected to A4988 Stepper Motor Driver (Red) GND
- Pin D2 PWM connected to A4988 Stepper Motor Driver (Red) DIR
- Pin D3 PWM connected to A4988 Stepper Motor Driver (Red) STEP
- Pin D4 PWM connected to A4988 Stepper Motor Driver (Red) DIR
- Pin D5 PWM connected to A4988 Stepper Motor Driver (Red) STEP
A4988 Stepper Motor Driver (Red) 1
- Pin VDD connected to Arduino Mega 2560 5V
- Pin GND connected to Arduino Mega 2560 GND
- Pin DIR connected to Arduino Mega 2560 D2 PWM
- Pin STEP connected to Arduino Mega 2560 D3 PWM
- Pin VMOT connected to 5V Battery positive
- Pin GND connected to 5V Battery negative
A4988 Stepper Motor Driver (Red) 2
- Pin VDD connected to Arduino Mega 2560 5V
- Pin GND connected to Arduino Mega 2560 GND
- Pin DIR connected to Arduino Mega 2560 D4 PWM
- Pin STEP connected to Arduino Mega 2560 D5 PWM
- Pin VMOT connected to 5V Battery positive
- Pin GND connected to 5V Battery negative
5V Battery
- Pin positive connected to A4988 Stepper Motor Driver (Red) VMOT
- Pin negative connected to A4988 Stepper Motor Driver (Red) GND
Code Documentation
/*
 * This Arduino Sketch controls two bipolar stepper motors using A4988 drivers.
 * The motors rotate 3000 steps forward and then 3000 steps backward with a
 * 1-second delay between direction changes. The DIR and STEP pins for each
 * motor are connected to the Arduino Mega 2560.
 */

#define DIR_PIN1 2   // Direction pin for Motor 1
#define STEP_PIN1 3  // Step pin for Motor 1
#define DIR_PIN2 4   // Direction pin for Motor 2
#define STEP_PIN2 5  // Step pin for Motor 2
#define DELAY_BETWEEN_STEPS 300 // Microseconds between steps
#define DELAY_BETWEEN_DIRECTIONS 1000 // Milliseconds between direction changes

void setup() {
  pinMode(DIR_PIN1, OUTPUT);
  pinMode(STEP_PIN1, OUTPUT);
  pinMode(DIR_PIN2, OUTPUT);
  pinMode(STEP_PIN2, OUTPUT);
}

void loop() {
  // Move both motors forward
  digitalWrite(DIR_PIN1, HIGH); // Set direction for Motor 1
  digitalWrite(DIR_PIN2, HIGH); // Set direction for Motor 2
  moveMotor(STEP_PIN1, 3000);   // Move Motor 1
  moveMotor(STEP_PIN2, 3000);   // Move Motor 2

  delay(DELAY_BETWEEN_DIRECTIONS); // 1-second delay

  // Move both motors backward
  digitalWrite(DIR_PIN1, LOW);  // Change direction for Motor 1
  digitalWrite(DIR_PIN2, LOW);  // Change direction for Motor 2
  moveMotor(STEP_PIN1, 3000);   // Move Motor 1
  moveMotor(STEP_PIN2, 3000);   // Move Motor 2

  delay(DELAY_BETWEEN_DIRECTIONS); // 1-second delay
}

void moveMotor(int stepPin, int steps) {
  for (int i = 0; i < steps; i++) {
    digitalWrite(stepPin, HIGH);
    delayMicroseconds(DELAY_BETWEEN_STEPS);
    digitalWrite(stepPin, LOW);
    delayMicroseconds(DELAY_BETWEEN_STEPS);
  }
}
This code sets up the Arduino Mega 2560 to control two stepper motors via the A4988 drivers. The motors are moved forward and backward with a specified delay between steps and direction changes.