
Arduino-Based Alcohol Detection and GPS Tracking System with GSM Alerts
View and Edit Project In Cirkit Designer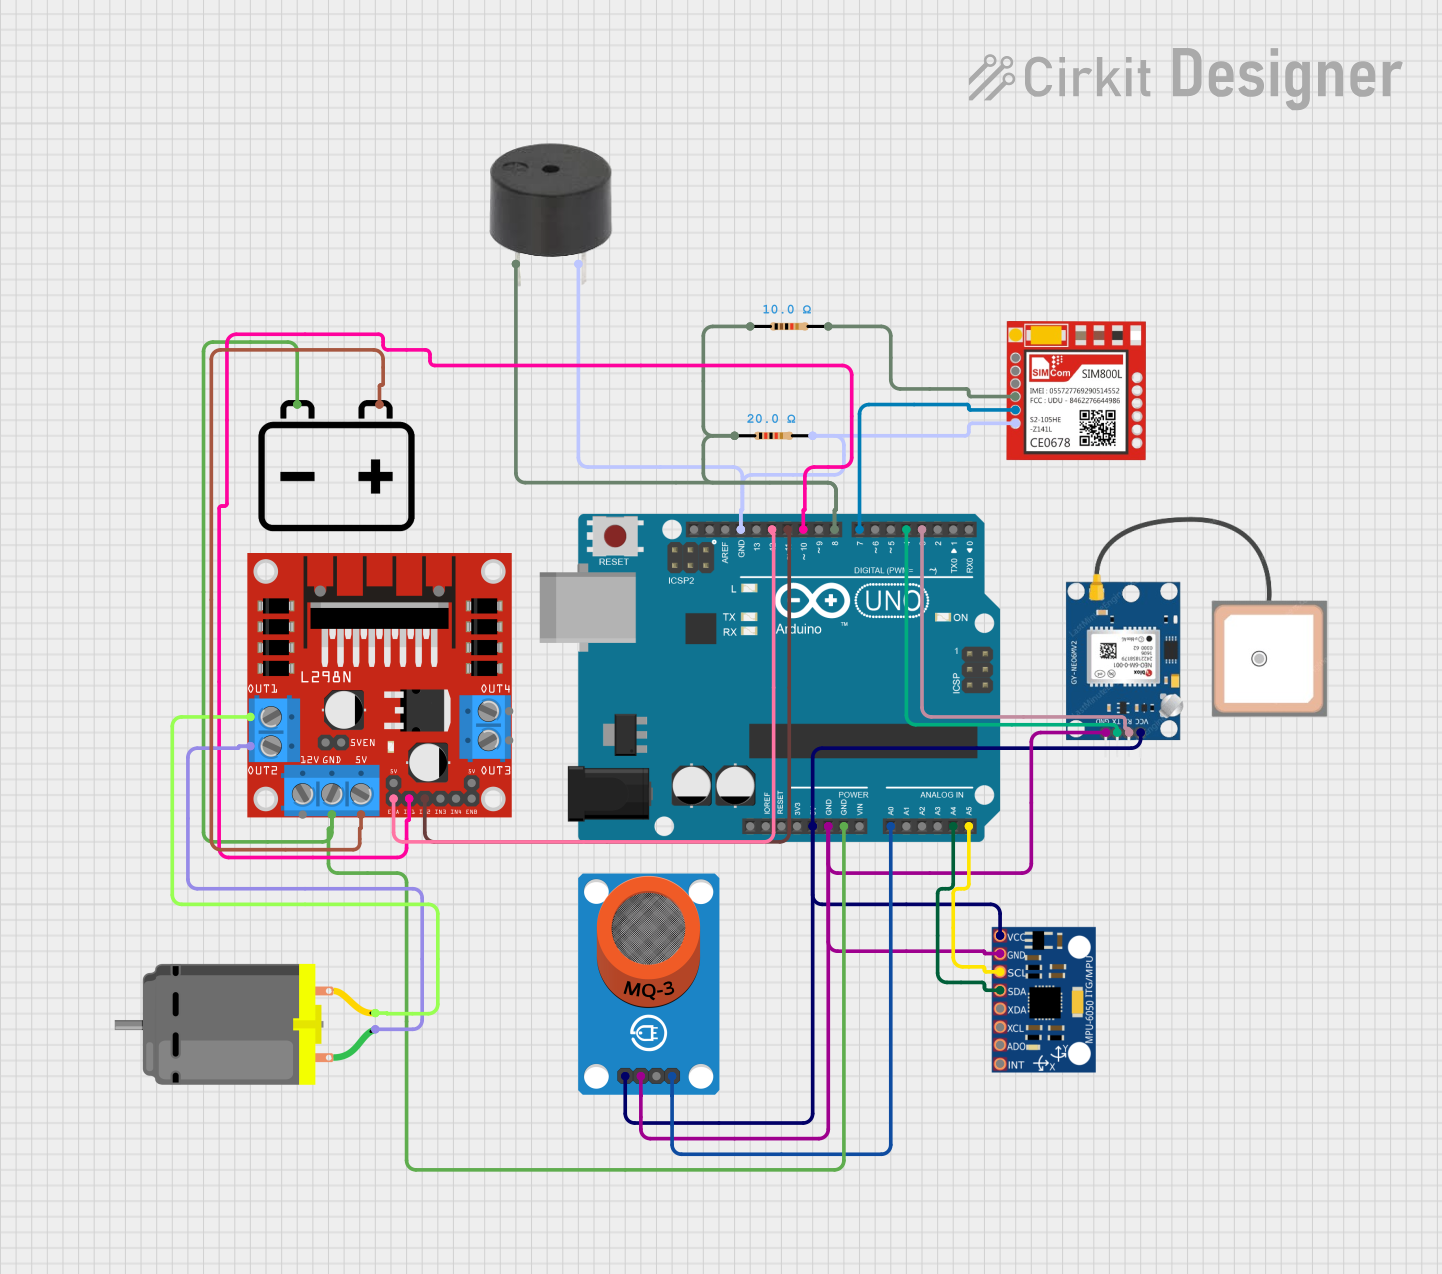
Circuit Documentation
Summary
This circuit is designed to detect alcohol levels using an MQ-3 sensor and take appropriate actions such as stopping a motor, alerting the driver with a buzzer, and sending the GPS location via SMS using a Sim800l GSM module. The circuit also includes an MPU-6050 for additional sensor data and a GPS NEO 6M module for location tracking. The Arduino UNO microcontroller is used to control the entire system.
Component List
Arduino UNO
- Description: Microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
MQ-3 Breakout
- Description: Alcohol sensor module.
- Pins: VCC, GND, DO, AO
MPU-6050
- Description: 6-axis motion tracking device.
- Pins: VCC, GND, SCL, SDA, XDA, XCL, AD0, INT
Sim800l
- Description: GSM/GPRS module for communication.
- Pins: NET, RST, VCC, RXD, TXD, GND
Resistor (10 Ohms)
- Description: Resistor with 10 Ohms resistance.
- Pins: pin1, pin2
Resistor (20 Ohms)
- Description: Resistor with 20 Ohms resistance.
- Pins: pin1, pin2
GPS NEO 6M
- Description: GPS module for location tracking.
- Pins: VCC, RX, TX, GND
L298N DC motor driver
- Description: Dual H-Bridge motor driver.
- Pins: OUT1, OUT2, 12V, GND, 5V, OUT3, OUT4, 5V-ENA-JMP-I, 5V-ENA-JMP-O, +5V-J1, +5V-J2, ENA, IN1, IN2, IN3, IN4, ENB
12v Battery
- Description: Power source.
- Pins: -, +
DC Motor
- Description: DC motor.
- Pins: pin 1, pin 2
Buzzer
- Description: Buzzer for alerting.
- Pins: PIN, GND
Wiring Details
Arduino UNO
- 5V connected to VCC of MQ-3 Breakout, MPU-6050, and GPS NEO 6M.
- GND connected to GND of MQ-3 Breakout, MPU-6050, GPS NEO 6M, L298N DC motor driver, Sim800l, and Buzzer.
- A0 connected to AO of MQ-3 Breakout.
- A4 connected to SDA of MPU-6050.
- A5 connected to SCL of MPU-6050.
- D12 connected to ENA of L298N DC motor driver.
- D11 connected to IN2 of L298N DC motor driver.
- D10 connected to IN1 of L298N DC motor driver.
- D8 connected to PIN of Buzzer and pin1 of 10 Ohms Resistor and 20 Ohms Resistor.
- D7 connected to TXD of Sim800l.
- D4 connected to TX of GPS NEO 6M.
- D3 connected to RX of GPS NEO 6M.
MQ-3 Breakout
- VCC connected to 5V of Arduino UNO.
- GND connected to GND of Arduino UNO.
- AO connected to A0 of Arduino UNO.
MPU-6050
- VCC connected to 5V of Arduino UNO.
- GND connected to GND of Arduino UNO.
- SDA connected to A4 of Arduino UNO.
- SCL connected to A5 of Arduino UNO.
Sim800l
- GND connected to GND of Arduino UNO.
- TXD connected to D7 of Arduino UNO.
- RXD connected to pin2 of 10 Ohms Resistor.
GPS NEO 6M
- VCC connected to 5V of Arduino UNO.
- GND connected to GND of Arduino UNO.
- TX connected to D4 of Arduino UNO.
- RX connected to D3 of Arduino UNO.
L298N DC motor driver
- GND connected to GND of Arduino UNO.
- ENA connected to D12 of Arduino UNO.
- IN2 connected to D11 of Arduino UNO.
- IN1 connected to D10 of Arduino UNO.
- OUT1 connected to pin 2 of DC Motor.
- OUT2 connected to pin 1 of DC Motor.
- 5V connected to + of 12v Battery.
12v Battery
- - connected to GND of Arduino UNO and L298N DC motor driver.
- + connected to 5V of L298N DC motor driver.
DC Motor
- pin 1 connected to OUT2 of L298N DC motor driver.
- pin 2 connected to OUT1 of L298N DC motor driver.
Buzzer
- PIN connected to D8 of Arduino UNO.
- GND connected to GND of Arduino UNO.
Resistor (10 Ohms)
- pin1 connected to D8 of Arduino UNO.
- pin2 connected to RXD of Sim800l.
Resistor (20 Ohms)
- pin1 connected to D8 of Arduino UNO.
- pin2 connected to GND of Arduino UNO.
Documented Code
#include <SoftwareSerial.h> // Include for GSM communication
#include <Wire.h>           // Include for I2C communication (if needed)

// Define hardware pins
#define ALCOHOL_PIN      A0  // Analog pin for alcohol sensor
#define BUZZER_PIN       8   // Digital pin for buzzer
#define LED_PIN          9   // Digital pin for LED
#define MOTOR_IN1_PIN    10  // Digital pin for motor driver IN1
#define MOTOR_IN2_PIN    11  // Digital pin for motor driver IN2
#define MOTOR_ENA_PIN    12  // Digital pin for motor driver ENA

// SoftwareSerial for GSM module
SoftwareSerial gsmSerial(7, 6); // RX, TX for GSM module

// Function prototypes
void stopMotor();
void alertDriver();
void sendLocation();
void sendSMS(const char* text);
bool getGPSLocation(double* latitude, double* longitude);

// Setup function
void setup() {
    Serial.begin(9600);         // Initialize serial communication for debugging
    gsmSerial.begin(9600);      // Initialize GSM communication

    // Configure pin modes
    pinMode(ALCOHOL_PIN, INPUT);
    pinMode(BUZZER_PIN, OUTPUT);
    pinMode(LED_PIN, OUTPUT);
    pinMode(MOTOR_IN1_PIN, OUTPUT);
    pinMode(MOTOR_IN2_PIN, OUTPUT);
    pinMode(MOTOR_ENA_PIN, OUTPUT);

    digitalWrite(MOTOR_ENA_PIN, HIGH); // Enable motor

    // Send initialization message
    sendSMS("System initialized and ready.");
}

// Main loop
void loop() {
    // Alcohol detection
    int alcoholValue = analogRead(ALCOHOL_PIN);

    // Alcohol detection threshold
    if (alcoholValue > 400) {
        Serial.println("Alcohol detected!");
        stopMotor();
        alertDriver();
        sendLocation();  // Send GPS location via SMS
    }

    // Simulate GPS data (mock, replace with actual GPS logic)
    double latitude = 12.345678;
    double longitude = 98.765432;
    Serial.print("Latitude: ");
    Serial.println(latitude, 6);
    Serial.print("Longitude: ");
    Serial.println(longitude, 6);

    delay(1000);
}

// Stop the motor
void stopMotor() {
    digitalWrite(MOTOR_IN1_PIN, LOW);
    digitalWrite(MOTOR_IN2_PIN, LOW);
}

// Alert the driver
void alertDriver() {
    digitalWrite(BUZZER_PIN, HIGH);
    digitalWrite(LED_PIN, HIGH);
    delay(2000); // Sound the alarm for 2 seconds
    digitalWrite(BUZZER_PIN, LOW);
    digitalWrite(LED_PIN, LOW);