
Arduino Nano ESP32 Battery-Powered Robotic Arm with Servo Motors and Distance Sensor
View and Edit Project In Cirkit Designer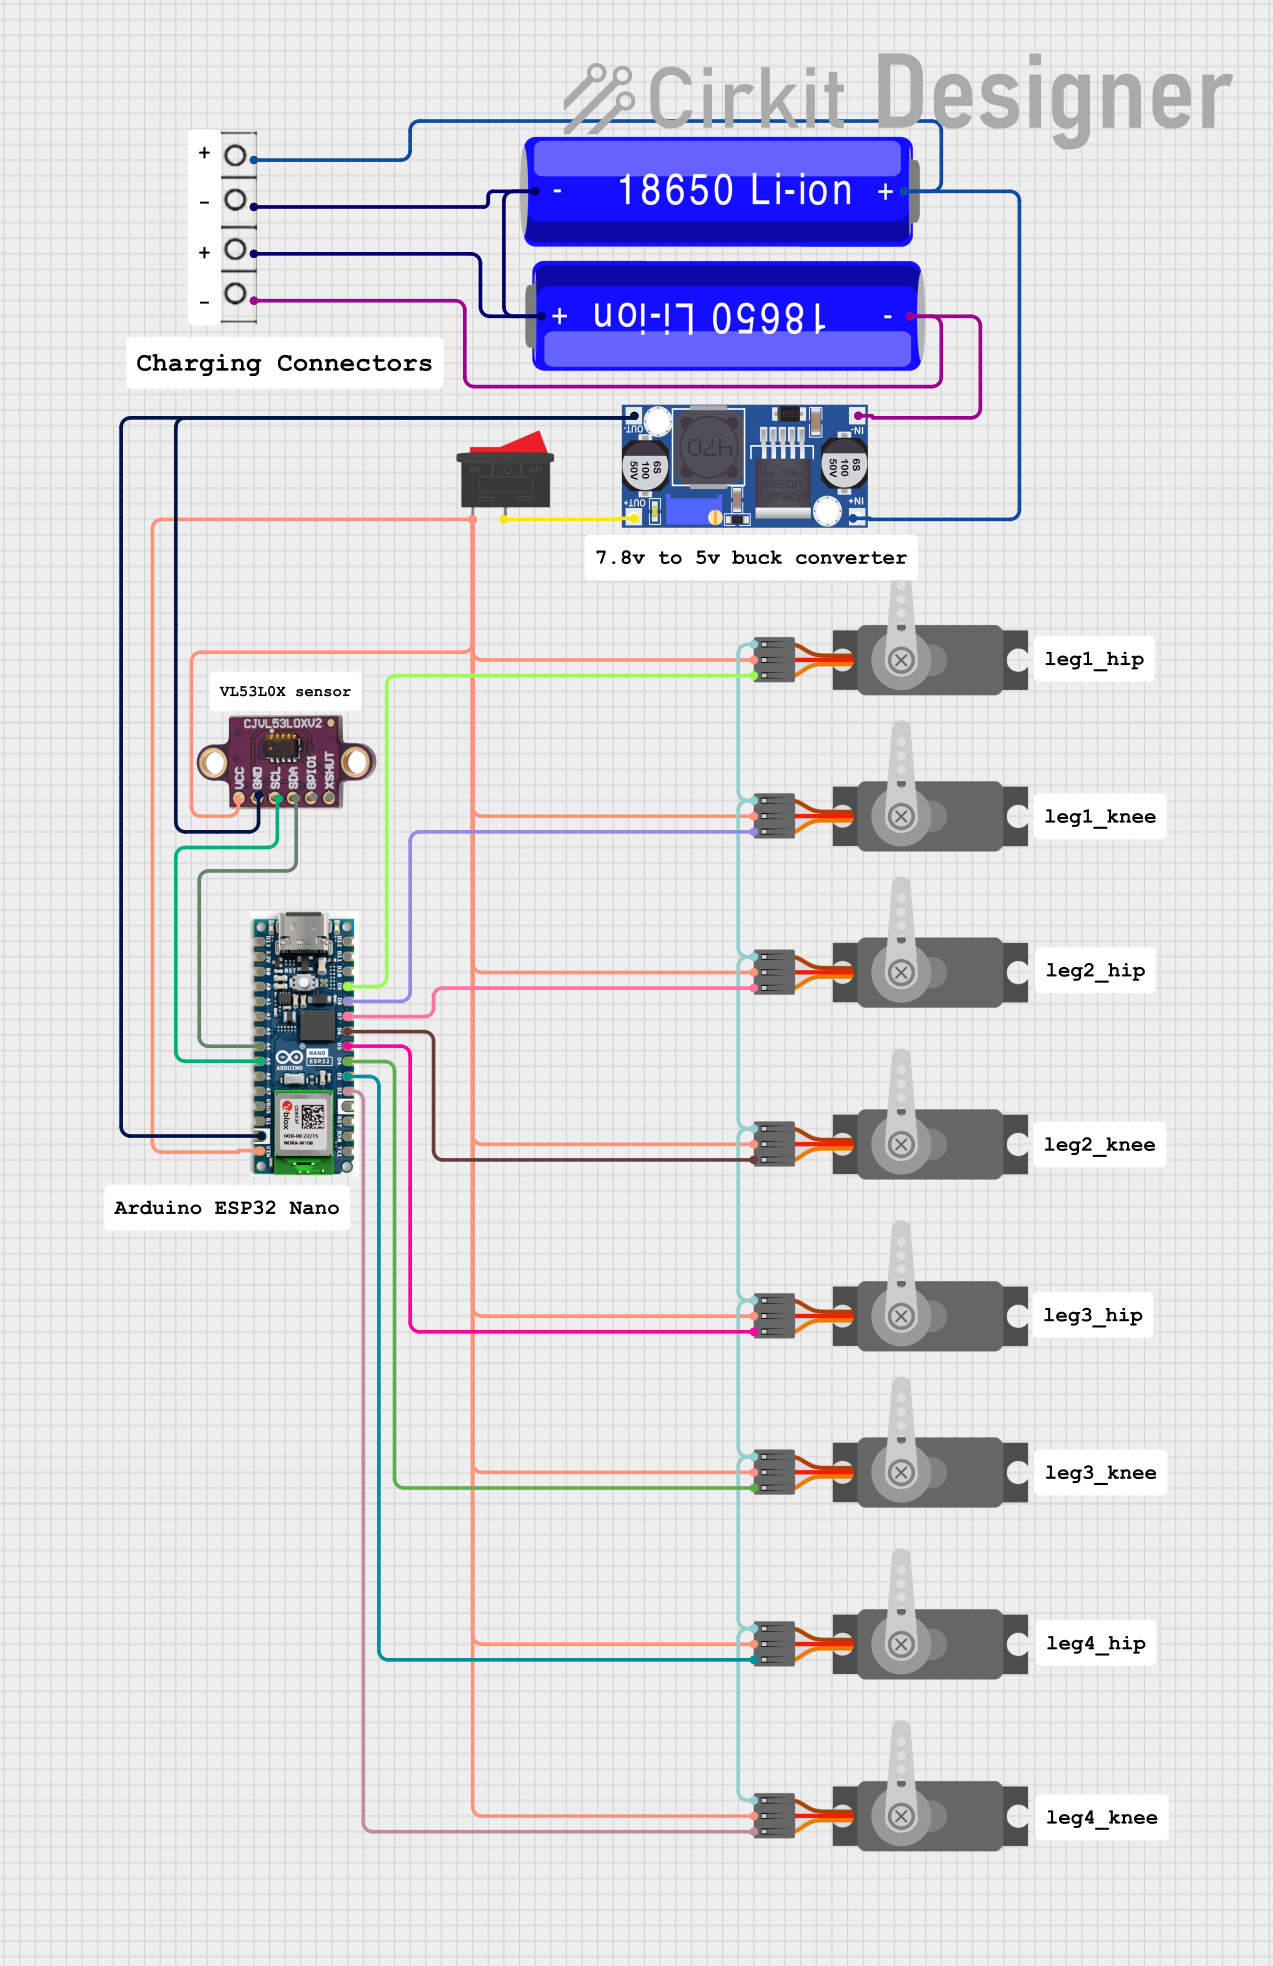
Circuit Documentation
Summary
This circuit involves an Arduino Nano ESP32 microcontroller, multiple servo motors, a VL53L0X V2 distance sensor, a buck converter, and two 18650 Li-ion batteries. The circuit is designed to control the servo motors using the Arduino Nano ESP32, with power supplied by the batteries through the buck converter. The VL53L0X V2 distance sensor is used for distance measurement.
Component List
Arduino Nano ESP32
- Description: A microcontroller board based on the ESP32.
- Pins: D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, GND, RST, RX0, TX1, D13, 3.3V, B0, A0, A1, A2, A3, A4, A5, A6, A7, VBUS, B1, VIN
Servo (Wokwi Compatible)
- Description: A servo motor compatible with Wokwi.
- Pins: GND, V+, PWM
VL53L0X V2
- Description: A time-of-flight distance sensor.
- Pins: vcc, GND, scl, SDA, SPI01, XSHUT
Buck Converter
- Description: A DC-DC converter to step down voltage.
- Pins: IN+, IN-, OUT+, OUT-
18650 Li-ion Battery
- Description: A rechargeable lithium-ion battery.
- Pins: +, -
Rocker Switch
- Description: A switch to control the power supply.
- Pins: 1, 2
Wire Connector
- Description: A connector for wiring.
- Pins: +, -
Wiring Details
Arduino Nano ESP32
- D9 connected to PWM of Servo (Wokwi Compatible)
- D8 connected to PWM of Servo (Wokwi Compatible)
- D7 connected to PWM of Servo (Wokwi Compatible)
- D6 connected to PWM of Servo (Wokwi Compatible)
- D5 connected to PWM of Servo (Wokwi Compatible)
- D4 connected to PWM of Servo (Wokwi Compatible)
- D3 connected to PWM of Servo (Wokwi Compatible)
- D2 connected to PWM of Servo (Wokwi Compatible)
- A4 connected to SDA of VL53L0X V2
- A5 connected to scl of VL53L0X V2
- GND connected to GND of VL53L0X V2 and OUT- of Buck Converter
- VIN connected to V+ of multiple Servo (Wokwi Compatible) and vcc of VL53L0X V2
Servo (Wokwi Compatible)
- PWM connected to D9 of Arduino Nano ESP32
- PWM connected to D8 of Arduino Nano ESP32
- PWM connected to D7 of Arduino Nano ESP32
- PWM connected to D6 of Arduino Nano ESP32
- PWM connected to D5 of Arduino Nano ESP32
- PWM connected to D4 of Arduino Nano ESP32
- PWM connected to D3 of Arduino Nano ESP32
- PWM connected to D2 of Arduino Nano ESP32
- V+ connected to 1 of Rocker Switch
- GND connected to GND of multiple Servo (Wokwi Compatible)
VL53L0X V2
- SDA connected to A4 of Arduino Nano ESP32
- scl connected to A5 of Arduino Nano ESP32
- GND connected to GND of Arduino Nano ESP32 and OUT- of Buck Converter
- vcc connected to V+ of multiple Servo (Wokwi Compatible) and VIN of Arduino Nano ESP32
Buck Converter
- IN+ connected to + of 18650 Li-ion Battery and + of Wire Connector
- IN- connected to - of 18650 Li-ion Battery and - of Wire Connector
- OUT+ connected to 2 of Rocker Switch
- OUT- connected to GND of Arduino Nano ESP32 and GND of VL53L0X V2
18650 Li-ion Battery
- + connected to IN+ of Buck Converter and + of Wire Connector
- - connected to IN- of Buck Converter and - of Wire Connector
Rocker Switch
- 1 connected to V+ of multiple Servo (Wokwi Compatible)
- 2 connected to OUT+ of Buck Converter
Wire Connector
- + connected to + of 18650 Li-ion Battery
- - connected to - of 18650 Li-ion Battery
Code
No code is provided for this circuit.
This documentation provides a comprehensive overview of the circuit, including a summary, component list, wiring details, and code section. Each component and its connections are clearly described to facilitate understanding and replication of the circuit.