
Circuit Documentation
Summary
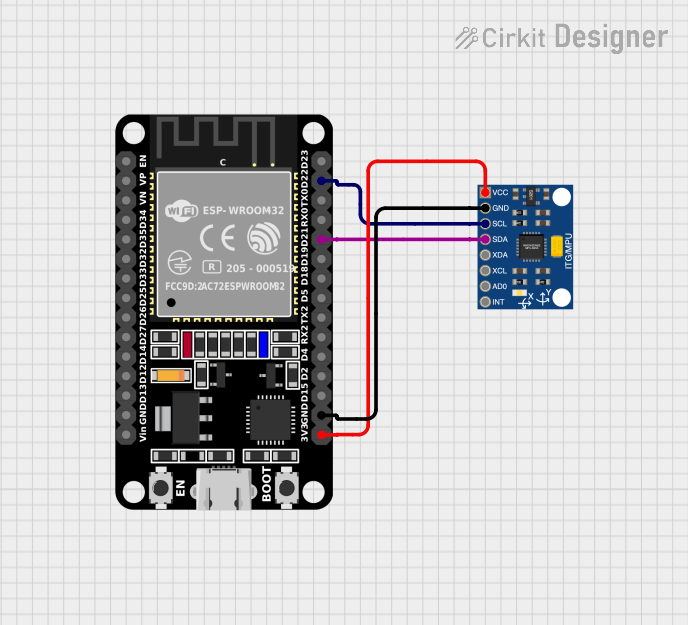
This document provides a detailed overview of a circuit that includes an ESP32 microcontroller and an InvenSense MPU6050 sensor. The ESP32 is used to interface with the MPU6050 via I2C communication. The document includes a list of components, wiring details, and any associated code.
Component List
ESP32 (30 pin)
- Description: A powerful microcontroller with integrated Wi-Fi and Bluetooth capabilities.
- Pins: EN, VP, VN, D34, D35, D32, D33, D25, D26, D27, D14, D12, D13, GND, Vin, D23, D22, TX0, RX0, D21, D19, D18, D5, TX2, RX2, D4, D2, D15, 3V3
- Purpose in Circuit: Acts as the main controller, interfacing with the MPU6050 sensor.
InvenSense MPU6050
- Description: A 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer.
- Pins: VCC, GND, SCL, SDA, XDA, XCL, AD0, INT
- Purpose in Circuit: Provides motion tracking data to the ESP32 via I2C communication.
Wiring Details
ESP32 (30 pin)
- D22: Connected to MPU6050 SCL
- D21: Connected to MPU6050 SDA
- GND: Connected to MPU6050 GND
- 3V3: Connected to MPU6050 VCC
InvenSense MPU6050
- SCL: Connected to ESP32 D22
- SDA: Connected to ESP32 D21
- GND: Connected to ESP32 GND
- VCC: Connected to ESP32 3V3
Code
No code is provided for this circuit.
This document provides a comprehensive overview of the circuit, including the components used and their interconnections. The ESP32 microcontroller interfaces with the MPU6050 sensor via I2C, enabling motion tracking capabilities.