
Arduino Mega 2560 and ESP32-Based Autonomous Robot with Sensor Integration
View and Edit Project In Cirkit Designer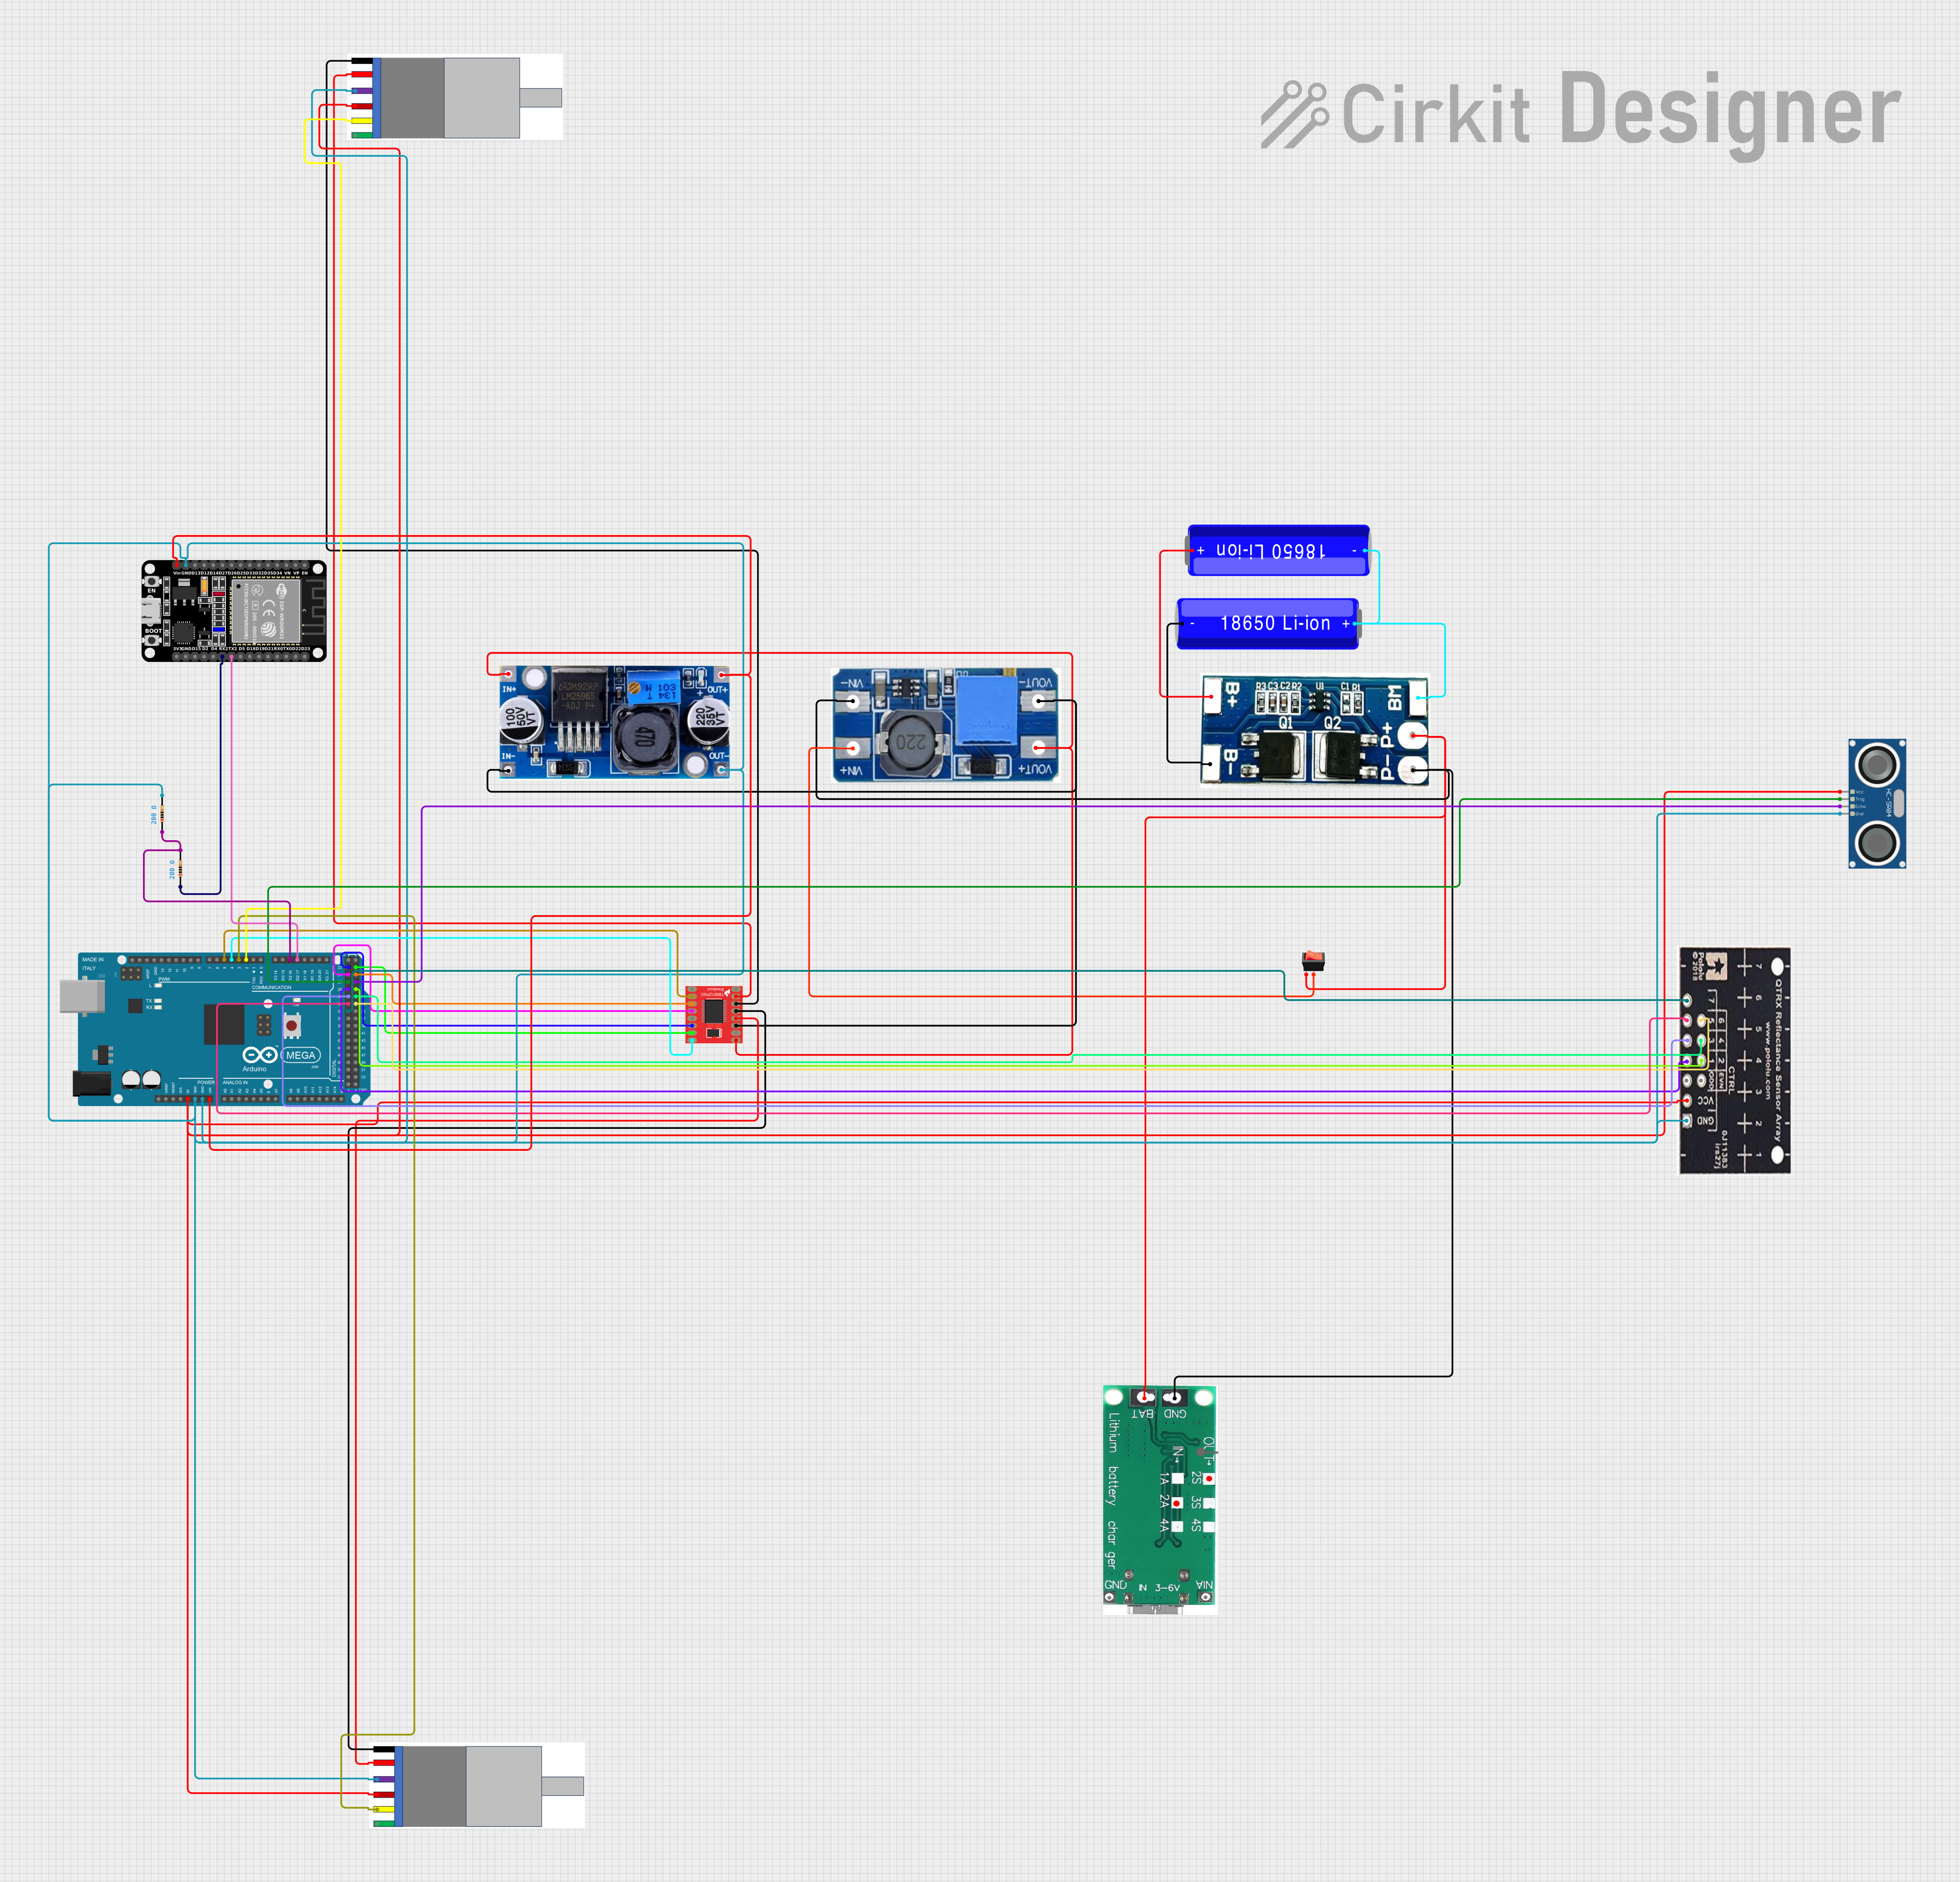
Circuit Documentation
Summary
This circuit integrates a variety of components including an Arduino Mega 2560, ESP32, motor drivers, gear motors with encoders, a reflectance sensor array, an ultrasonic sensor, power supply modules, and a rocker switch. The circuit is designed to control motors, read sensor inputs, and manage power distribution. The Arduino Mega 2560 serves as the primary microcontroller, while the ESP32 may be used for additional processing or connectivity. The motor drivers control the gear motors, and the sensors provide feedback for navigation or other functions. Power management is handled by battery protection, charging boards, and voltage regulators to ensure stable operation.
Component List
Microcontrollers
- Arduino Mega 2560: A microcontroller board based on the ATmega2560 with numerous digital and analog I/O pins.
- ESP32 (30 pin): A microcontroller with Wi-Fi and Bluetooth capabilities, featuring a variety of I/O options.
Power Supply Components
- 18650 Li-ion Battery: A rechargeable battery providing power to the circuit.
- 2S Lithium Battery Protection Board Module: Protects the lithium batteries from overcharge, over-discharge, and short circuits.
- Lithium Battery Charging Board Type-C: Charges the lithium batteries via a Type-C connection.
- Step Up Boost Power Converter, Adjustable Voltage Regulator: Boosts the voltage to a higher level as needed.
- Buck Converter, Adjustable Regulator: Steps down the voltage to a lower level as required.
Motor and Driver
- Motor Driver 1A Dual TB6612FNG: Controls two motors with direction and speed control capabilities.
- Gear Motor with Integrated Encoder: Provides motion and rotational feedback through an integrated encoder.
Sensors
- QTRX-HD-07RC Reflectance Sensor Array: Detects changes in reflectivity, useful for line following or edge detection.
- HC-SR04 Ultrasonic Sensor: Measures distance using ultrasonic waves.
Switches and Resistors
- Rocker Switch: A simple on/off switch for controlling power flow.
- Resistor: A component with a fixed resistance, used for current limiting or voltage division.
Wiring Details
Arduino Mega 2560
- 5V: Powers the reflectance sensor array, ultrasonic sensor, and gear motor encoders.
- GND: Common ground for various components.
- VIN: Receives input voltage from the buck converter.
- Digital Pins (D2, D3, D4, D5, D22, D23, D24, D25, D26, D27, D28, D29, D30, D31, D32, D33, D34): Interface with motor drivers, sensors, and encoders.
- PWM Pins (D2, D3, D4, D5): Provide pulse-width modulation signals to the motor drivers for speed control.
- Serial Communication Pins (D16, D17): Communicate with the ESP32.
ESP32 (30 pin)
- GND: Common ground connection.
- Vin: Receives input voltage from the buck converter.
- RX2/TX2: Serial communication with the Arduino Mega 2560.
Motor Driver 1A Dual TB6612FNG
- VM: Motor power supply from the step-up boost converter.
- VCC: Logic power supply from the Arduino Mega 2560.
- GND: Common ground connection.
- A01, A02, B01, B02: Connections to the gear motors.
- PWMA, PWMB: PWM control signals from the Arduino Mega 2560.
- AIN1, AIN2, BIN1, BIN2: Direction control signals from the Arduino Mega 2560.
Gear Motor with Integrated Encoder
- MOTOR +/-: Power connections from the motor driver.
- Encoder +/-: Power connections for the encoder.
- Encoder A, Encoder B: Feedback signals to the Arduino Mega 2560.
QTRX-HD-07RC Reflectance Sensor Array
- VCC: Powered by the Arduino Mega 2560.
- GND: Common ground connection.
- Sensor Outputs (1, 2, 3, 4, 5, 6, 7): Connected to various digital pins on the Arduino Mega 2560.
HC-SR04 Ultrasonic Sensor
- VCC: Powered by the Arduino Mega 2560.
- GND: Common ground connection.
- TRIG: Trigger signal from the Arduino Mega 2560.
- ECHO: Echo signal to the Arduino Mega 2560.
Power Supply Components
- Batteries: Provide power to the protection board, which in turn connects to the charging board and the step-up boost converter.
- Protection Board: Ensures safe battery operation.
- Charging Board: Charges the batteries via a Type-C connection.
- Step-Up Boost Converter: Boosts the battery voltage to power the motor driver.
- Buck Converter: Steps down the voltage to power the microcontrollers.
Rocker Switch
- Input: Connected to the battery positive terminal.
- Output: Connected to the charging board and protection board.
Resistor
- Used in series with the ESP32 for serial communication with the Arduino Mega 2560.
Documented Code
Arduino Mega 2560 Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
This code provides the basic structure for the Arduino sketch. The setup() function is called once when the program starts and is used to initialize settings. The loop() function is called repeatedly and contains the main logic of the program. Specific functionality will be added to these functions based on the requirements of the circuit's operation.
ESP32 Code
No code provided for the ESP32. If the ESP32 is to be used, appropriate code will need to be developed and uploaded to the microcontroller.