
ESP32-Based Robotic Navigator with Ultrasonic and IR Sensing
View and Edit Project In Cirkit Designer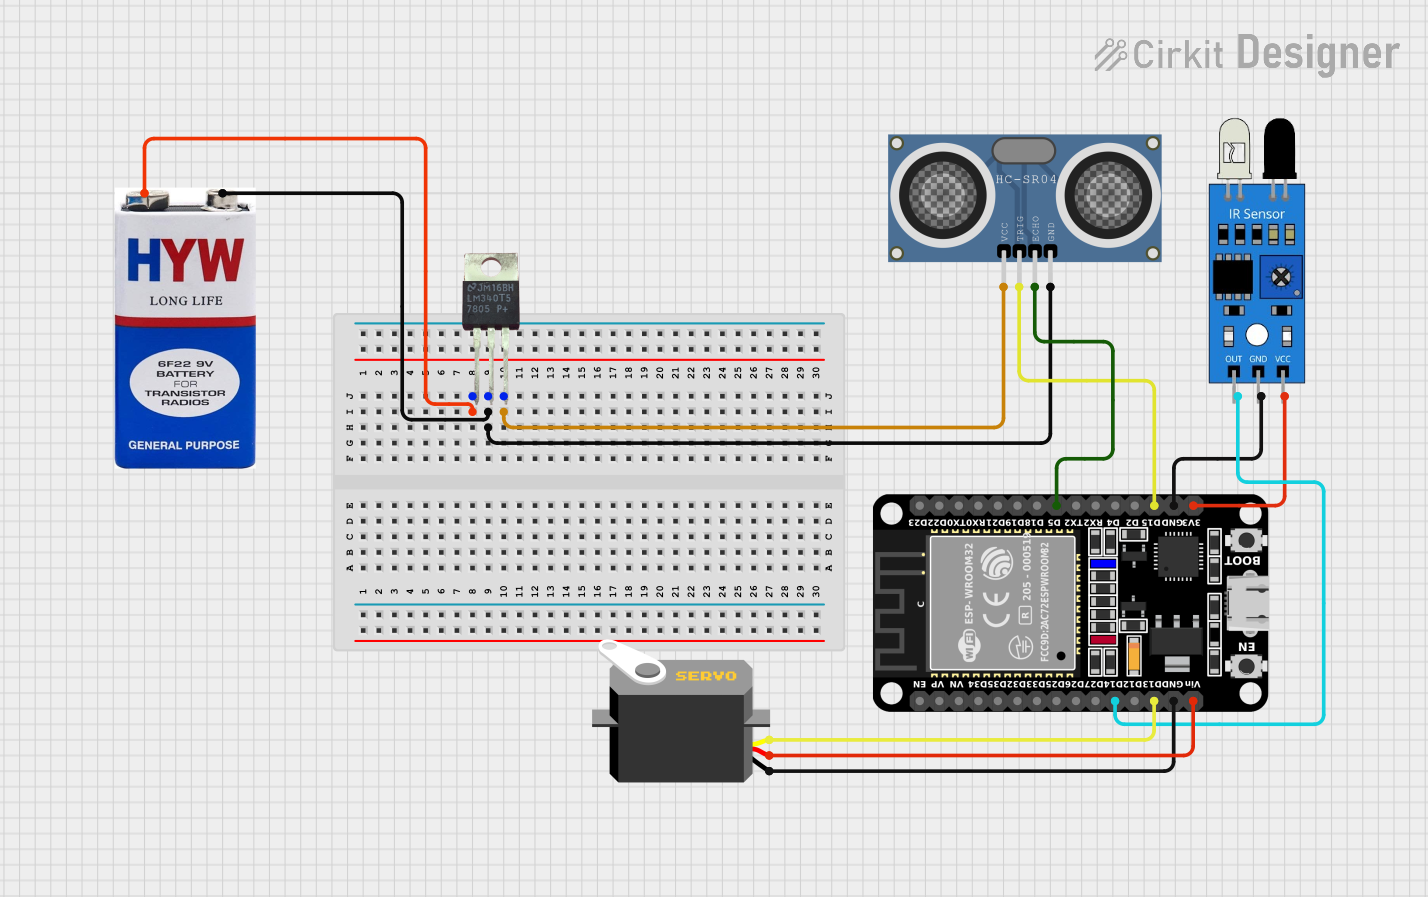
Circuit Documentation
Summary of the Circuit
This circuit is designed to interface an ESP32 microcontroller with a set of sensors and actuators. It includes a power supply module, an ultrasonic distance sensor, an infrared sensor, and a servo motor. The ESP32 reads data from the sensors and controls the servo motor based on the sensor inputs. The power supply module regulates the voltage from a 9V battery to provide a stable 5V output for the sensors and the ESP32.
Component List
9V Battery
- Description: Provides the power source for the circuit.
- Pins:
+(positive terminal),-(negative terminal).
LM340T5 7805 Voltage Regulator
- Description: Regulates the input voltage to a stable 5V output.
- Pins:
Vout(regulated 5V output),Vin(input voltage),GND(ground).
ESP32 (30 pin)
- Description: A microcontroller with WiFi and Bluetooth capabilities, used as the main processing unit of the circuit.
- Pins:
EN,VP,VN,D34,D35,D32,D33,D25,D26,D27,D14,D12,D13,GND,Vin,D23,D22,TX0,RX0,D21,D19,D18,D5,TX2,RX2,D4,D2,D15,3V3.
HC-SR04 Ultrasonic Distance Sensor (Wokwi Compatible)
- Description: Measures distances by emitting ultrasonic waves and measuring the time taken for the echo to return.
- Pins:
VCC(power supply),TRIG(trigger input),ECHO(echo output),GND(ground).
IR Sensor
- Description: Detects infrared light, often used in proximity and object detection.
- Pins:
out(output signal),gnd(ground),vcc(power supply).
Servo
- Description: A motor capable of precise position control.
- Pins:
gnd(ground),vcc(power supply),pulse(control signal).
Wiring Details
9V Battery
+connected toVinof LM340T5 7805 Voltage Regulator.-connected toGNDof LM340T5 7805 Voltage Regulator andGNDof HC-SR04 Ultrasonic Distance Sensor.
LM340T5 7805 Voltage Regulator
Vinconnected to+of 9V Battery.GNDconnected to-of 9V Battery,GNDof HC-SR04 Ultrasonic Distance Sensor.Voutconnected toVCCof HC-SR04 Ultrasonic Distance Sensor.
ESP32 (30 pin)
D14connected tooutof IR Sensor.D13connected topulseof Servo.GNDconnected togndof Servo andgndof IR Sensor.Vinconnected tovccof Servo.D5connected toECHOof HC-SR04 Ultrasonic Distance Sensor.D15connected toTRIGof HC-SR04 Ultrasonic Distance Sensor.3V3connected tovccof IR Sensor.
HC-SR04 Ultrasonic Distance Sensor (Wokwi Compatible)
VCCconnected toVoutof LM340T5 7805 Voltage Regulator.TRIGconnected toD15of ESP32.ECHOconnected toD5of ESP32.GNDconnected toGNDof LM340T5 7805 Voltage Regulator.
IR Sensor
outconnected toD14of ESP32.gndconnected toGNDof ESP32.vccconnected to3V3of ESP32.
Servo
gndconnected toGNDof ESP32.vccconnected toVinof ESP32.pulseconnected toD13of ESP32.
Documented Code
No code has been provided for the microcontroller. The documentation of the code would typically include a description of the functionality, setup and loop functions, and any functions or libraries used to interface with the sensors and actuators. Since no code is available, this section cannot be completed. If code becomes available, it should be documented here with comments explaining each section and its purpose in the overall operation of the circuit.