
Arduino UNO-Based Smart Parking System with RFID and Ultrasonic Sensors
View and Edit Project In Cirkit Designer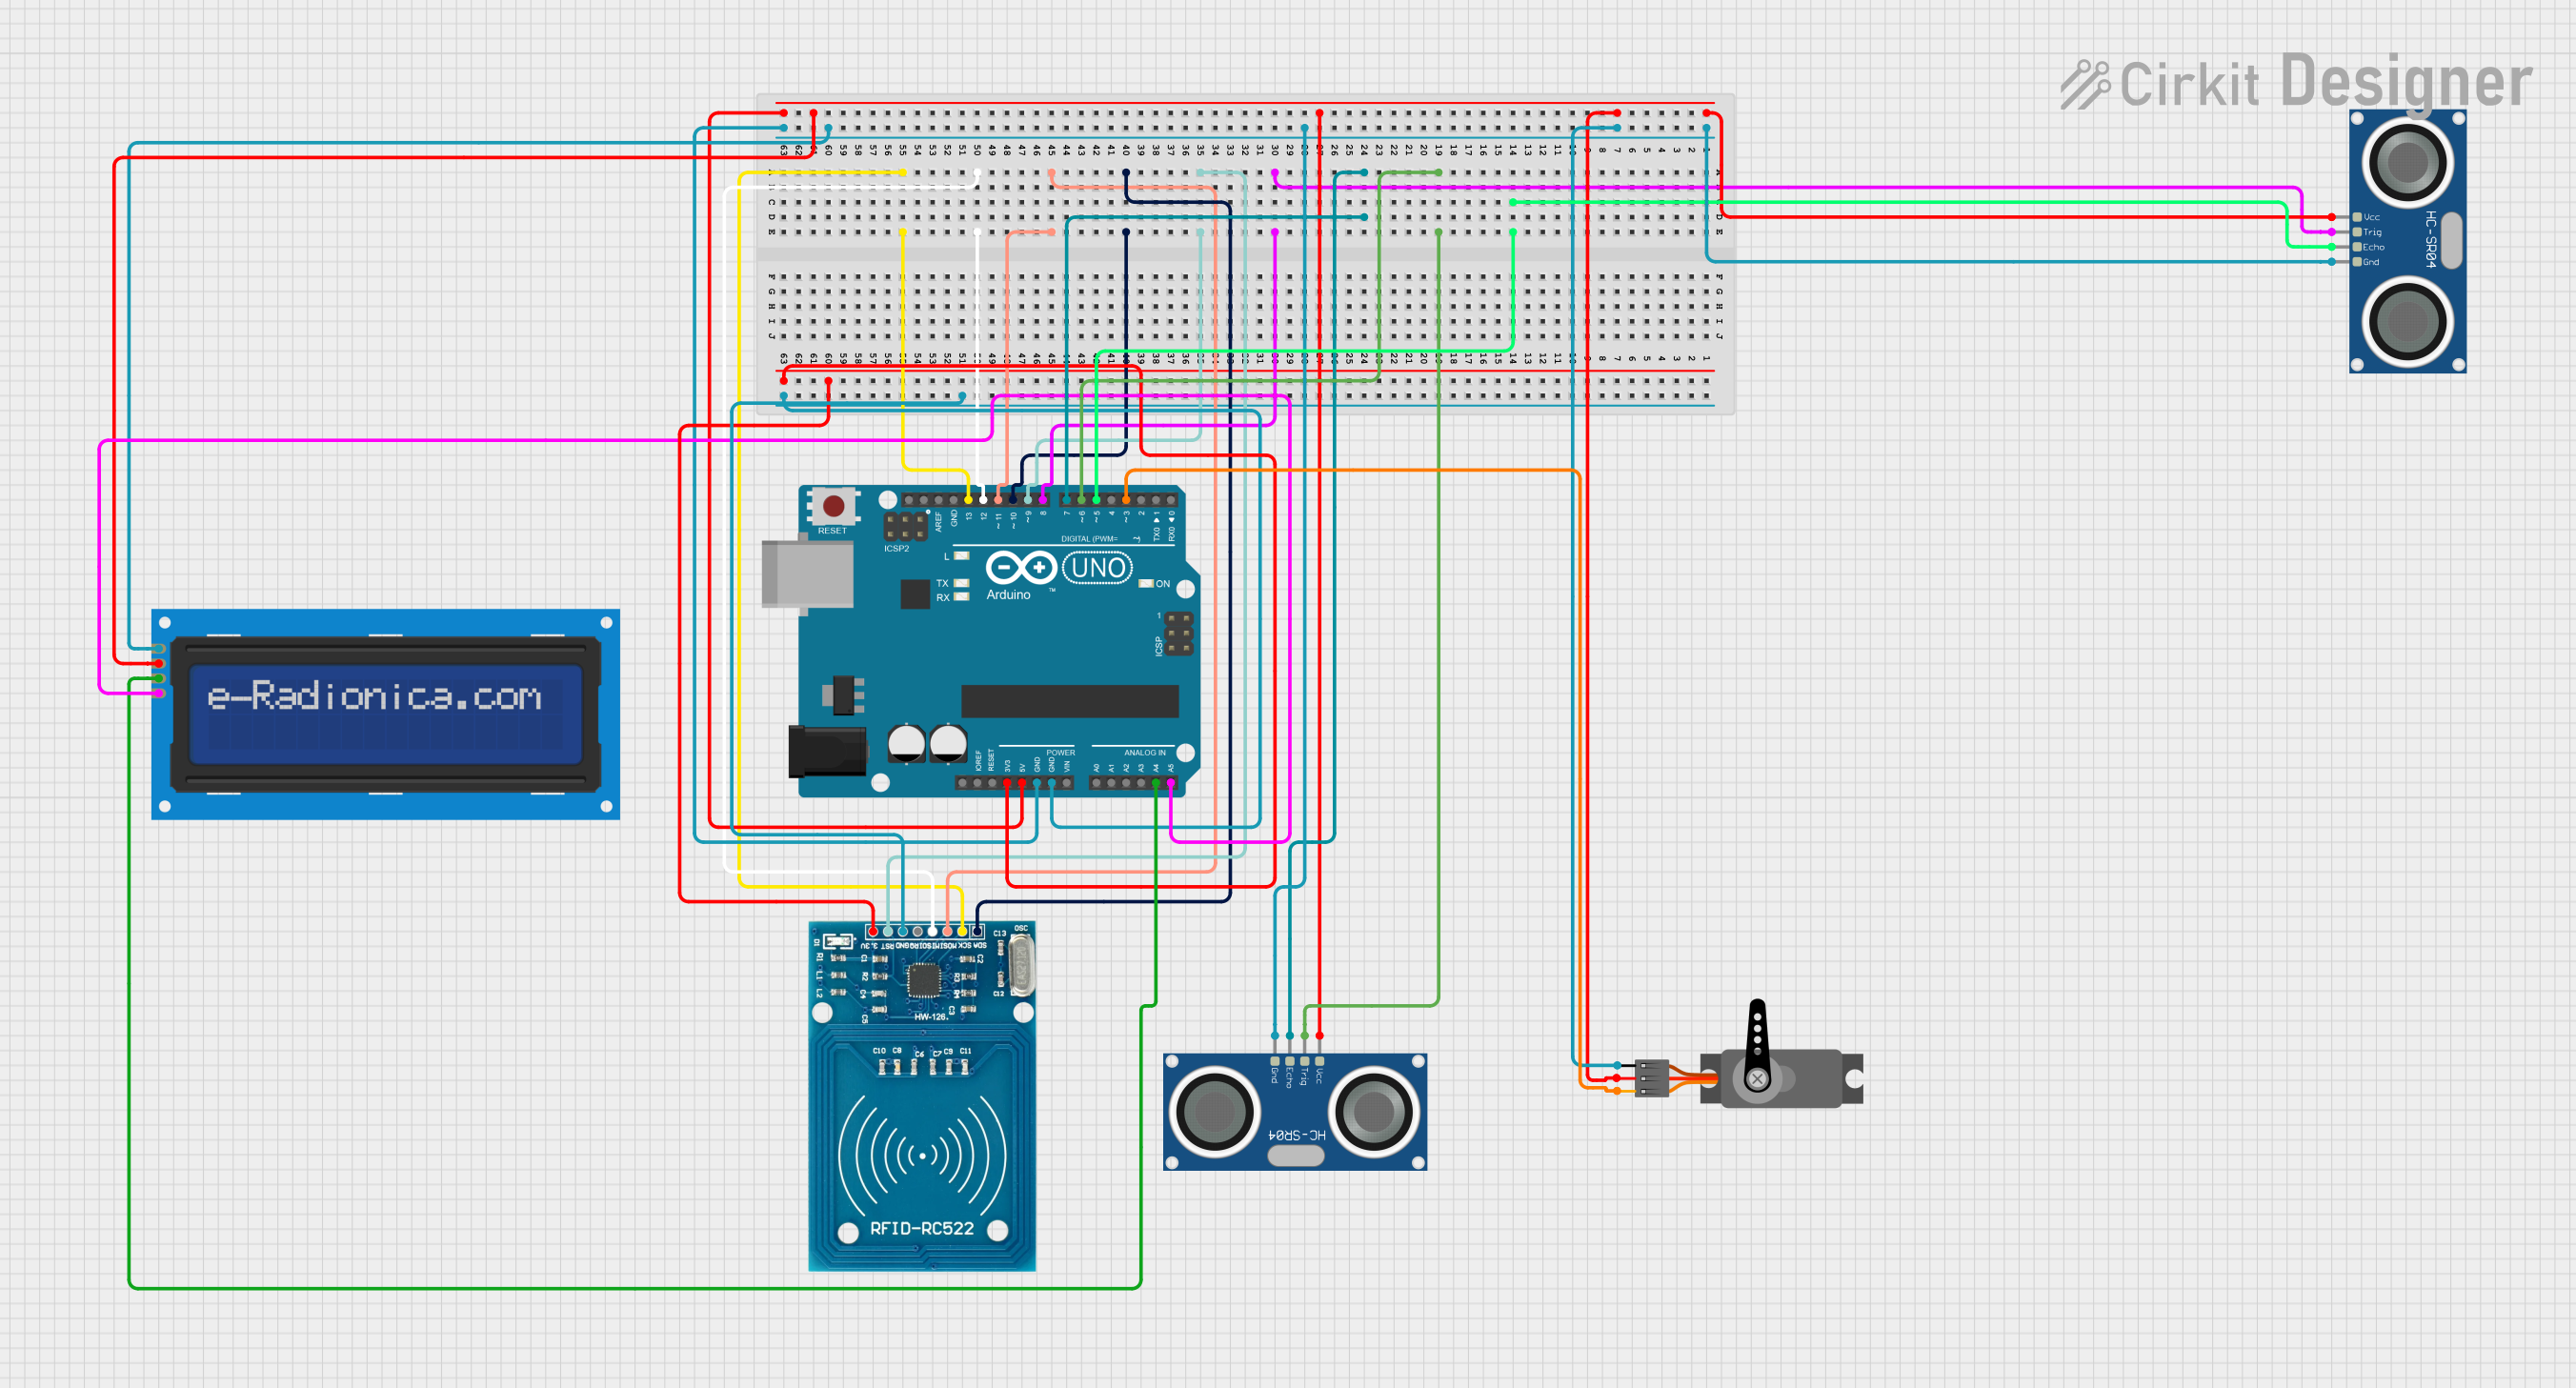
Circuit Documentation
Summary
This circuit is designed to manage a parking system using an Arduino UNO microcontroller. The system includes RFID for access control, ultrasonic sensors for detecting car presence, a servo motor for gate control, and an LCD screen for displaying available parking slots. The Arduino UNO coordinates all these components and runs the embedded code to manage the parking system.
Component List
HC-SR04 Ultrasonic Sensor
- Pins: VCC, TRIG, ECHO, GND
- Description: Used to measure distance to detect the presence of a car.
- Purpose in Circuit: One sensor is used to detect cars near the gate, and another is used to detect cars in the parking slot.
Arduino UNO
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
- Description: Microcontroller board based on the ATmega328P.
- Purpose in Circuit: Acts as the central controller for the parking system.
RFID-RC522
- Pins: VCC (3.3V), RST, GND, IRQ, MISO, MOSI, SCK, SDA
- Description: RFID reader module.
- Purpose in Circuit: Used to read RFID tags for access control.
LCD screen 16x2 I2C
- Pins: SCL, SDA, VCC, GND
- Description: 16x2 character LCD display with I2C interface.
- Purpose in Circuit: Displays the number of available parking slots.
Servo
- Pins: GND, VCC, PWM
- Description: Servo motor.
- Purpose in Circuit: Controls the gate mechanism.
Wiring Details
HC-SR04 Ultrasonic Sensor (Gate)
- VCC: Connected to Arduino UNO 5V
- TRIG: Connected to Arduino UNO D6
- ECHO: Connected to Arduino UNO D7
- GND: Connected to Arduino UNO GND
HC-SR04 Ultrasonic Sensor (Slot)
- VCC: Connected to Arduino UNO 5V
- TRIG: Connected to Arduino UNO D8
- ECHO: Connected to Arduino UNO D5
- GND: Connected to Arduino UNO GND
Arduino UNO
- 5V: Connected to VCC of both HC-SR04 sensors, Servo, and LCD screen
- 3.3V: Connected to VCC of RFID-RC522
- GND: Connected to GND of both HC-SR04 sensors, Servo, LCD screen, and RFID-RC522
- D3: Connected to PWM of Servo
- D5: Connected to ECHO of HC-SR04 (Slot)
- D6: Connected to TRIG of HC-SR04 (Gate)
- D7: Connected to ECHO of HC-SR04 (Gate)
- D8: Connected to TRIG of HC-SR04 (Slot)
- D9: Connected to RST of RFID-RC522
- D10: Connected to SDA of RFID-RC522
- D11: Connected to MOSI of RFID-RC522
- D12: Connected to MISO of RFID-RC522
- D13: Connected to SCK of RFID-RC522
- A4: Connected to SDA of LCD screen
- A5: Connected to SCL of LCD screen
RFID-RC522
- VCC (3.3V): Connected to Arduino UNO 3.3V
- RST: Connected to Arduino UNO D9
- GND: Connected to Arduino UNO GND
- MISO: Connected to Arduino UNO D12
- MOSI: Connected to Arduino UNO D11
- SCK: Connected to Arduino UNO D13
- SDA: Connected to Arduino UNO D10
LCD screen 16x2 I2C
- SCL: Connected to Arduino UNO A5
- SDA: Connected to Arduino UNO A4
- VCC: Connected to Arduino UNO 5V
- GND: Connected to Arduino UNO GND
Servo
- GND: Connected to Arduino UNO GND
- VCC: Connected to Arduino UNO 5V
- PWM: Connected to Arduino UNO D3
Documented Code
#include <MFRC522.h>
#include <Servo.h>
#include <LiquidCrystal_I2C.h>

// RFID setup
#define RST_PIN 9
#define SS_PIN 10
MFRC522 rfid(SS_PIN, RST_PIN);

// Ultrasonic sensors setup
#define TRIG_GATE 6
#define ECHO_GATE 7
#define TRIG_SLOT 8
#define ECHO_SLOT 5

// Servo motor setup
Servo gateServo;

// LCD setup
LiquidCrystal_I2C lcd(0x27, 16, 2);

// Variables
int totalSlots = 1;
int availableSlots = 1;
bool slotRecentlyFreed = false; // Tracks if the slot was just freed

// Allowed and restricted UIDs
const char* allowedUIDs[] = {"C3 CA 3F 1A", "81 A8 52 1B"};
const char* restrictedUIDs[] = {"05 8E 97 02 6E 31 00"};

void setup() {
  Serial.begin(9600);

  // Initialize RFID
  SPI.begin();
  rfid.PCD_Init();

  // Ultrasonic sensors setup
  pinMode(TRIG_GATE, OUTPUT);
  pinMode(ECHO_GATE, INPUT);
  pinMode(TRIG_SLOT, OUTPUT);
  pinMode(ECHO_SLOT, INPUT);

  // Servo motor setup
  gateServo.attach(3);
  gateServo.write(0); // Initial position: closed

  // LCD setup
  lcd.init();
  lcd.backlight();
  lcd.setCursor(0, 0);
  lcd.print("Parking System");
  delay(2000);
  lcd.clear();
  updateLCD();
}

void loop() {
  // Check for RFID card
  if (rfid.PICC_IsNewCardPresent() && rfid.PICC_ReadCardSerial()) {
    String uid = getUID();
    Serial.print("RFID UID: ");
    Serial.println(uid);

    // Check UID access
    if (isUIDAllowed(uid) && isCarNearGate()) {
      if (availableSlots > 0) {
        Serial.println("Access granted!");
        openGate(3000);
      } else {
        Serial.println("No slots available!");
        lcd.clear();
        lcd.setCursor(0, 0);
        lcd.print("No Slots Available");
        delay(2000);
        updateLCD();
      }
    } else if(!isCarNearGate()){
      //
    }

    else {
      Serial.println("Access denied!");
      lcd.clear();
      lcd.setCursor(0, 0);
      lcd.print("Access Denied");
      delay(2000);
      updateLCD();
    }

    rfid.PICC_HaltA(); // Halt RFID reading
  }

  // Monitor parking slot status
  if (isSlotOccupied()) {
    if (availableSlots > 0) {
      availableSlots--;
      updateLCD();
    }
  } else {
    if (availableSlots < totalSlots) {
      availableSlots++;
      slotRecentlyFreed = true; // Mark slot as recently freed
      updateLCD();
    }
  }

  // Handle exit logic
  if (slotRecentlyFreed) {
    Serial.println("Car leaving. Opening gate.");
    openGate(5000);
    slotRecentlyFreed = false; // Reset flag after gate opens
  }

  delay(500); // Delay to avoid rapid updates
}

void openGate(int delayTime) {
  // Open the gate
  gateServo.write(90); // Open gate
  lcd.clear();
  lcd.setCursor(0, 0);
  lcd.print("Gate Opening...");
  delay(delayTime); // Keep gate open for specified seconds
  gateServo.write(0);  // Close gate
  lcd.clear();
  updateLCD();
}

bool isCarNearGate() {
  digitalWrite(TRIG_GATE, LOW);
  delayMicroseconds(2);
  digitalWrite(TRIG_GATE, HIGH);
  delayMicroseconds(10);
  digitalWrite(TRIG_GATE, LOW);
  long duration = pulseIn(ECHO_GATE, HIGH);
  int distance = duration * 0.034 / 2;
  return distance < 10; // Car detected within 10 cm
}

bool isSlotOccupied() {
  digitalWrite(TRIG_SLOT, LOW);
  delayMicroseconds(2);
  digitalWrite(TRIG_SLOT, HIGH);
  delayMicroseconds(10);
  digitalWrite(TRIG_SLOT, LOW);
  long duration = pulseIn(ECHO_SLOT, HIGH);
  int distance = duration * 0.034 / 2;
  return distance < 10; // Car detected within 10 cm
}

void updateLCD