
Arduino Mega 2560-Based Obstacle Detection and Moisture Sensing System with Vibration Motor and Buzzer
View and Edit Project In Cirkit Designer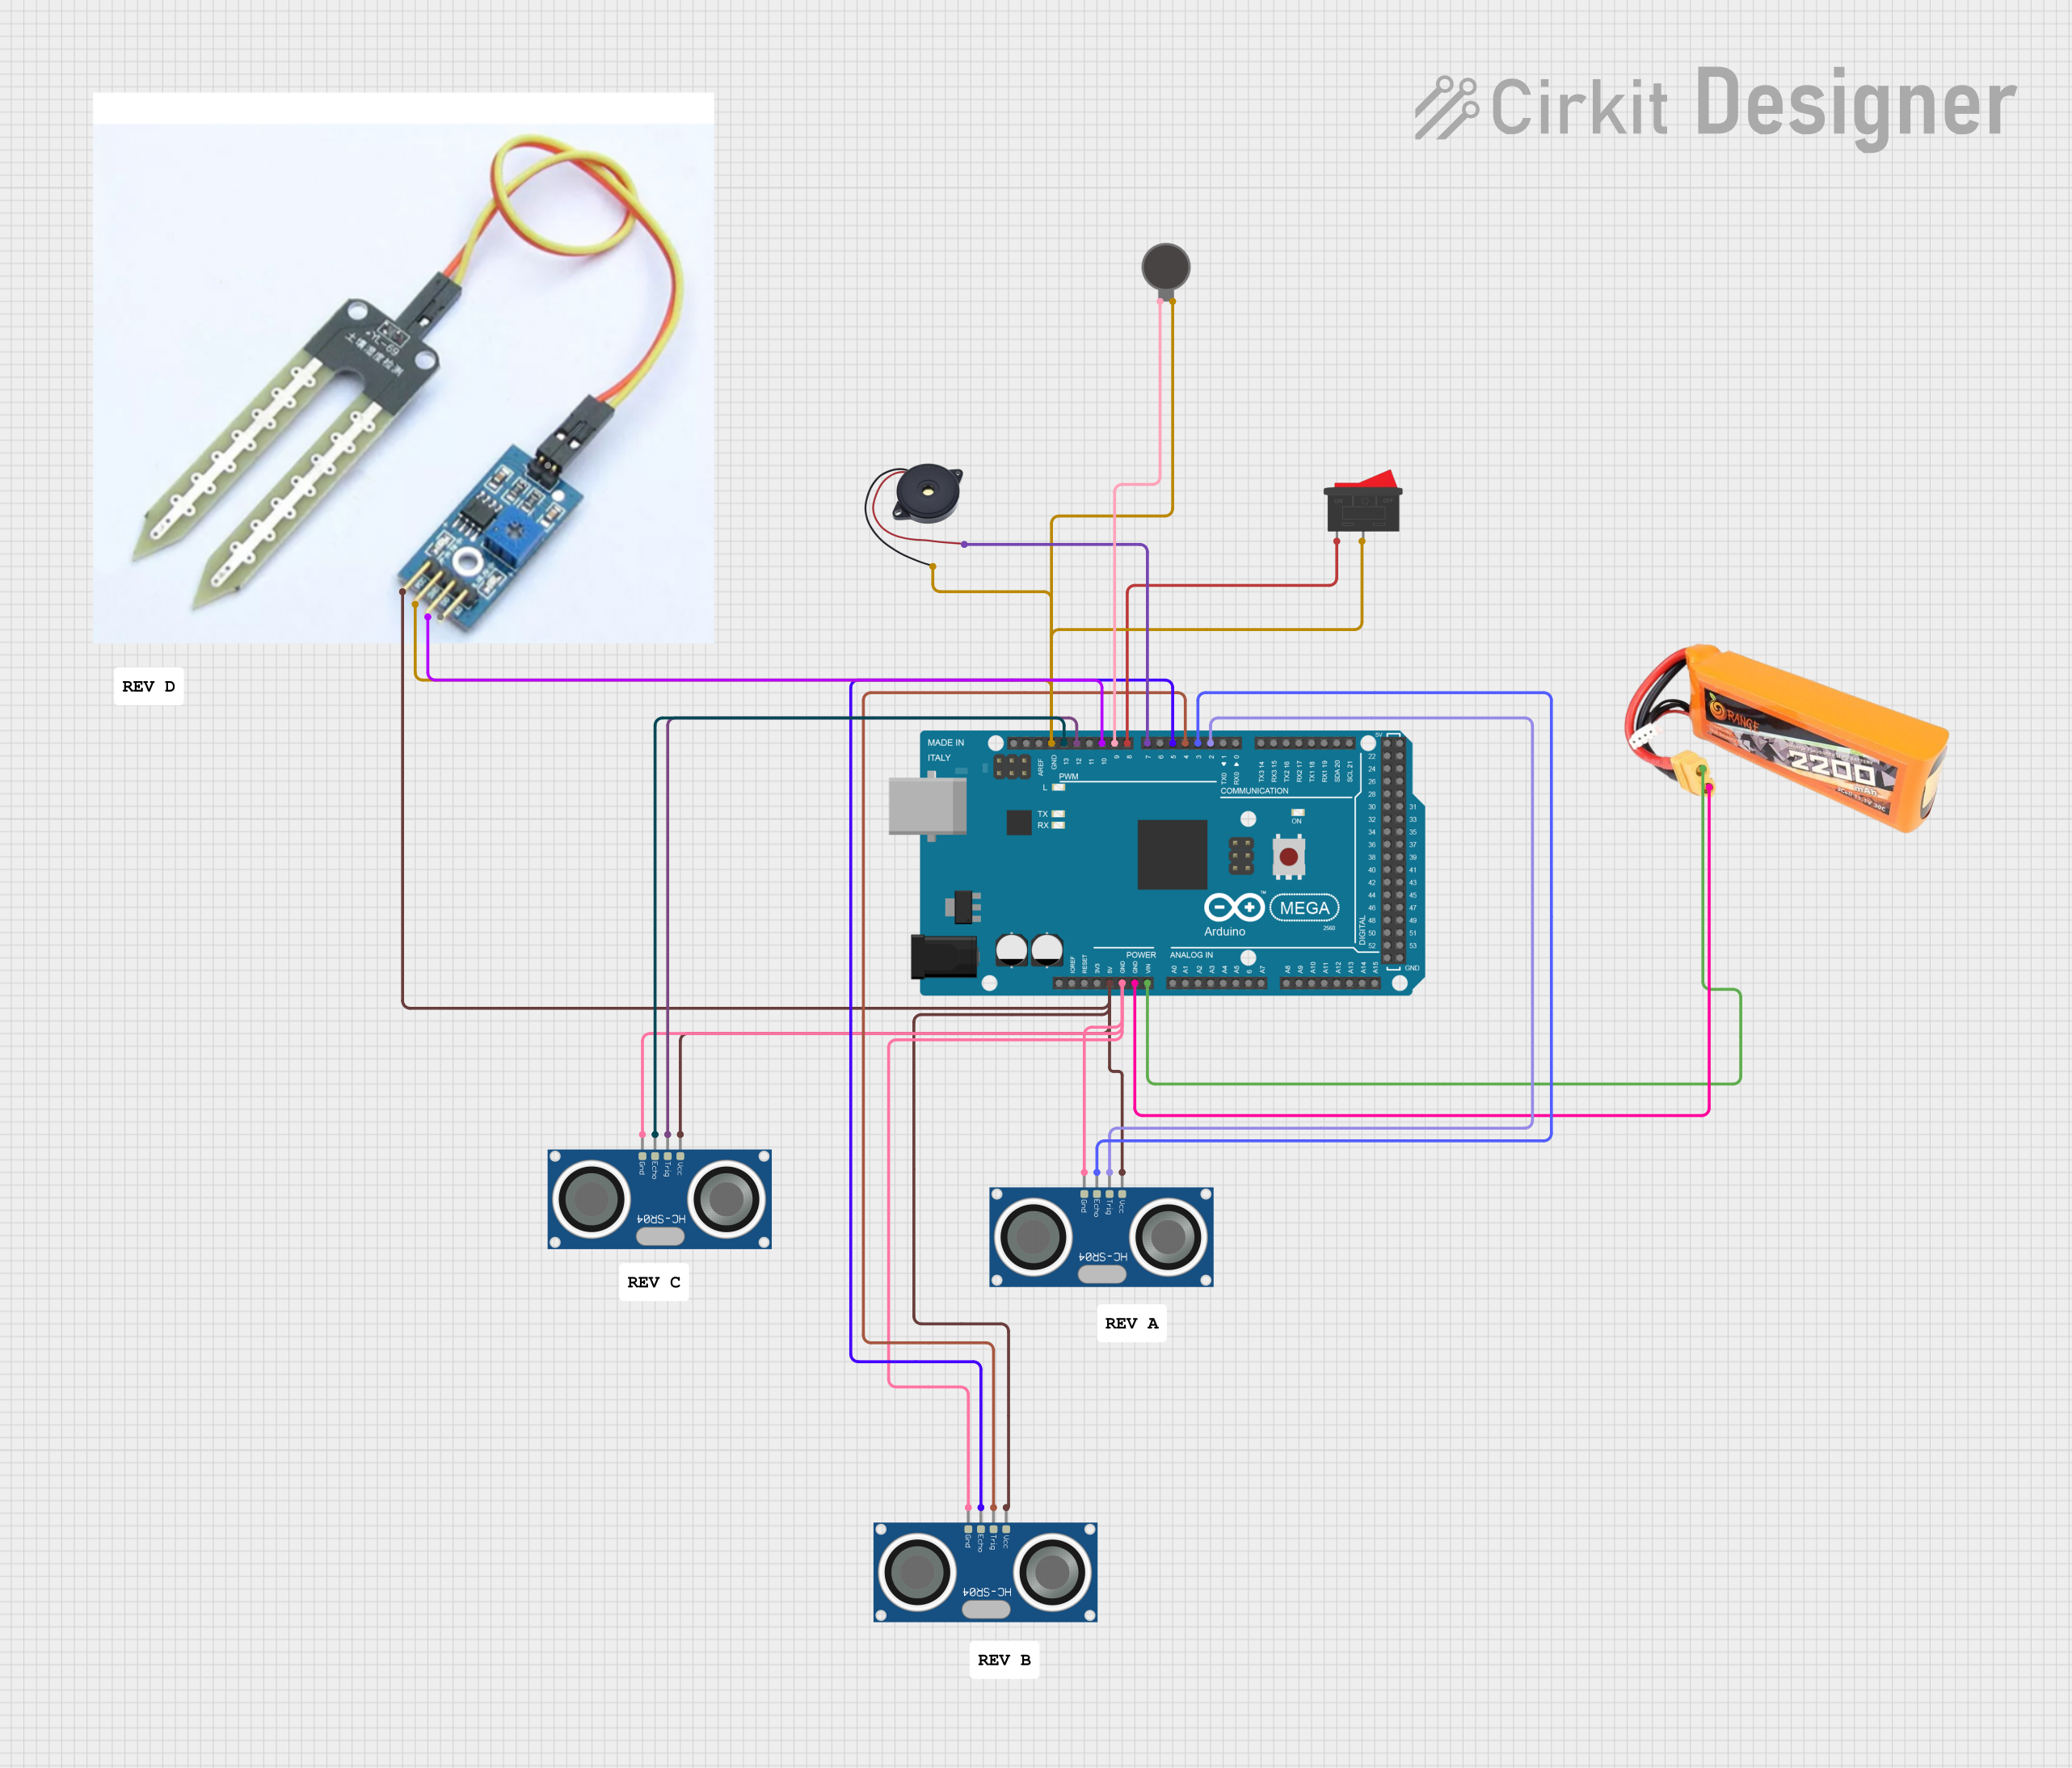
Circuit Documentation
Summary
This circuit is designed to detect obstacles and water using ultrasonic sensors and a moisture sensor, respectively. It uses an Arduino Mega 2560 microcontroller to process sensor data and control a vibration motor and a buzzer. The system includes an emergency rocker switch to activate an emergency mode.
Component List
Rocker Switch
- Description: A switch used to activate emergency mode.
- Pins: 1, 2
HC-SR04 Ultrasonic Sensor
- Description: Ultrasonic sensor used for distance measurement.
- Pins: VCC, TRIG, ECHO, GND
Vibration Motor
- Description: Motor that vibrates to provide haptic feedback.
- Pins: +, -
Buzzer
- Description: Buzzer used for audio alerts.
- Pins: GND, IN
LiPo Battery 2200mAH 30C
- Description: Power source for the circuit.
- Pins: VCC, GND
Arduino Mega 2560
- Description: Microcontroller used to control the circuit.
- Pins: IOREF, RESET, 3V3, 5V, GND, VIN, A0-A15, D0-D53, AREF, SDA, SCL
Soil Sensor
- Description: Sensor used to detect moisture.
- Pins: VCC, GND, D0, A0
Wiring Details
Rocker Switch
- Pin 1: Connected to Arduino Mega 2560 pin D8 PWM
- Pin 2: Connected to Arduino Mega 2560 GND
HC-SR04 Ultrasonic Sensor (Upper)
- VCC: Connected to Arduino Mega 2560 5V
- TRIG: Connected to Arduino Mega 2560 pin D2 PWM
- ECHO: Connected to Arduino Mega 2560 pin D3 PWM
- GND: Connected to Arduino Mega 2560 GND
HC-SR04 Ultrasonic Sensor (Middle)
- VCC: Connected to Arduino Mega 2560 5V
- TRIG: Connected to Arduino Mega 2560 pin D4 PWM
- ECHO: Connected to Arduino Mega 2560 pin D5 PWM
- GND: Connected to Arduino Mega 2560 GND
HC-SR04 Ultrasonic Sensor (Bottom)
- VCC: Connected to Arduino Mega 2560 5V
- TRIG: Connected to Arduino Mega 2560 pin D12 PWM
- ECHO: Connected to Arduino Mega 2560 pin D13 PWM
- GND: Connected to Arduino Mega 2560 GND
Vibration Motor
- +: Connected to Arduino Mega 2560 pin D9 PWM
- -: Connected to Arduino Mega 2560 GND
Buzzer
- IN: Connected to Arduino Mega 2560 pin D7 PWM
- GND: Connected to Arduino Mega 2560 GND
LiPo Battery 2200mAH 30C
- VCC: Connected to Arduino Mega 2560 VIN
- GND: Connected to Arduino Mega 2560 GND
Soil Sensor
- VCC: Connected to Arduino Mega 2560 5V
- GND: Connected to Arduino Mega 2560 GND
- D0: Connected to Arduino Mega 2560 pin D10 PWM
Code Documentation
#include <Arduino.h>
#include <NewPing.h>

// Pin Definitions
#define TRIG_PIN_UPPER 2     // Upper ultrasonic sensor (obstacles above user)
#define ECHO_PIN_UPPER 3
#define TRIG_PIN_MIDDLE 4    // Middle ultrasonic sensor (front obstacles)
#define ECHO_PIN_MIDDLE 5
#define MOISTURE_SENSOR_PIN 10 // Moisture sensor (water detection)
#define TRIG_PIN_BOTTOM 12   // Bottom ultrasonic sensor (replacing IR)
#define ECHO_PIN_BOTTOM 13
#define VIBRATION_MOTOR_PIN 9
#define ROCKER_SWITCH_PIN 8  // Emergency rocker switch
#define BUZZER_PIN 7

// Constants
#define MAX_DISTANCE 200     // Maximum distance in cm for ultrasonic sensors
#define DETECTION_DELAY 100  // Delay between detection cycles
#define PWM_HIGH 255         // High-speed vibration
#define PWM_MEDIUM 128       // Medium-speed vibration
#define PWM_LOW 64           // Low-speed vibration

// Objects for ultrasonic sensors
NewPing sonarUpper(TRIG_PIN_UPPER, ECHO_PIN_UPPER, MAX_DISTANCE);
NewPing sonarMiddle(TRIG_PIN_MIDDLE, ECHO_PIN_MIDDLE, MAX_DISTANCE);
NewPing sonarBottom(TRIG_PIN_BOTTOM, ECHO_PIN_BOTTOM, MAX_DISTANCE);

// Global Variables
volatile bool emergencyActive = false; // Emergency flag

void setup() {
    pinMode(VIBRATION_MOTOR_PIN, OUTPUT);
    pinMode(ROCKER_SWITCH_PIN, INPUT_PULLUP);
    pinMode(BUZZER_PIN, OUTPUT);
    pinMode(MOISTURE_SENSOR_PIN, INPUT); // Moisture sensor pin

    // Interrupt for emergency rocker switch
    attachInterrupt(digitalPinToInterrupt(ROCKER_SWITCH_PIN), handleEmergencyInterrupt, CHANGE);

    // Start Serial for debugging
    Serial.begin(9600);
    Serial.println("System Initialized.");
}

void loop() {
    if (emergencyActive) {
        // Activate buzzer for emergency
        digitalWrite(BUZZER_PIN, HIGH);
        Serial.println("Emergency Mode Active! Buzzer ON.");
    } else {
        // Turn off emergency buzzer and handle other functionality
        digitalWrite(BUZZER_PIN, LOW);
        handleUpperSensor();
        handleMiddleSensor();
        handleBottomSensor();
        handleMoistureDetection(); // New moisture sensor function
    }

    delay(DETECTION_DELAY); // Small delay between cycles
}

// Interrupt Service Routine for Emergency System
void handleEmergencyInterrupt() {
    emergencyActive = (digitalRead(ROCKER_SWITCH_PIN) == LOW);
    Serial.print("Emergency Switch State Changed. Emergency Active: ");
    Serial.println(emergencyActive);
}

// Function to handle upper ultrasonic sensor
void handleUpperSensor() {
    int distance = sonarUpper.ping_cm();
    Serial.print("Upper Sensor Distance: ");
    Serial.print(distance);
    Serial.println(" cm");

    if (distance > 0 && distance <= 50) {
        Serial.println("Obstacle detected above. Vibrating motor at HIGH speed.");
        for (int i = 0; i < 3; i++) { // Vibrate 3 times
            analogWrite(VIBRATION_MOTOR_PIN, PWM_HIGH);
            delay(400);
            analogWrite(VIBRATION_MOTOR_PIN, 0);
            delay(400);  // Adjust the pause between vibrations
        }
    } else if (distance > 50 && distance <= 100) {
        Serial.println("Obstacle detected above. Vibrating motor at MEDIUM speed.");
        for (int i = 0; i < 3; i++) { // Vibrate 3 times
            analogWrite(VIBRATION_MOTOR_PIN, PWM_MEDIUM);
            delay(400);
            analogWrite(VIBRATION_MOTOR_PIN, 0);
            delay(400);
        }
    } else if (distance > 100 && distance <= 200) {
        Serial.println("Obstacle detected above. Vibrating motor at LOW speed.");
        for (int i = 0; i < 3; i++) { // Vibrate 3 times
            analogWrite(VIBRATION_MOTOR_PIN, PWM_LOW);
            delay(400);
            analogWrite(VIBRATION_MOTOR_PIN, 0);
            delay(400);
        }
    } else {
        Serial.println("No obstacle above. Motor OFF.");
        analogWrite(VIBRATION_MOTOR_PIN, 0);
    }
}

// Function to handle middle ultrasonic sensor
void handleMiddleSensor() {
    int distance = sonarMiddle.ping_cm();
    Serial.print("Middle Sensor Distance: ");
    Serial.print(distance);
    Serial.println(" cm");

    if (distance > 0 && distance <= 50) {
        Serial.println("Obstacle detected in front. Vibrating motor at HIGH speed.");
        for (int i = 0; i < 2; i++) { // Vibrate 2 times
            analogWrite(VIBRATION_MOTOR_PIN, PWM_HIGH);
            delay(400);
            analogWrite(VIBRATION_MOTOR_PIN, 0);
            delay(400);  // Adjust the pause between vibrations
        }
    } else if (distance > 50 && distance <= 100) {
        Serial.println("Obstacle detected in front. Vibrating motor at MEDIUM speed.");
        for (int i = 0; i < 2; i++) { // Vibrate 2 times
            analogWrite(VIBRATION_MOTOR_PIN, PWM_MEDIUM);
            delay(400);
            analogWrite(VIBRATION_MOTOR_PIN, 0);
            delay(400);
        }
    } else if (distance > 100 && distance <= 200) {
        Serial.println("Obstacle detected in front. Vibrating motor at LOW speed.");
        for (int i = 0; i < 2; i