
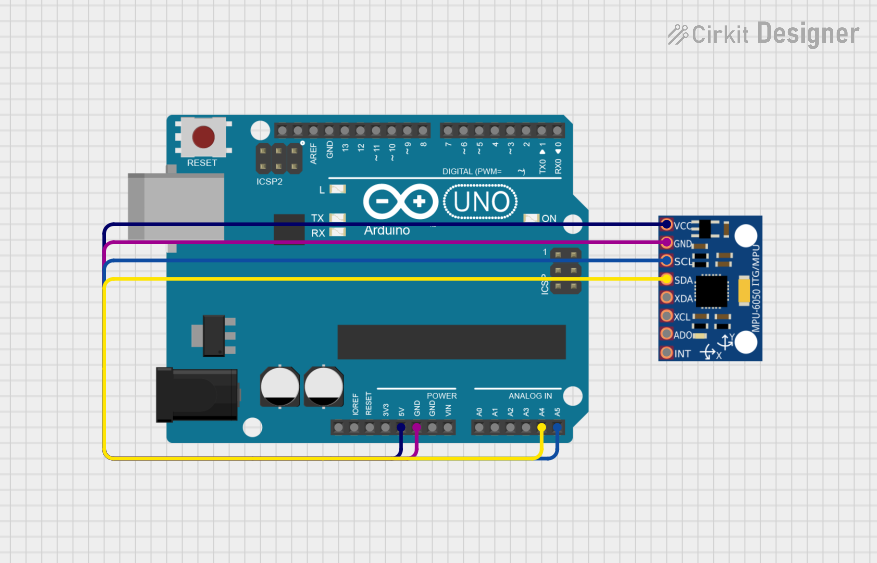
Circuit Documentation
Summary of the Circuit
This circuit consists of an Arduino UNO microcontroller board interfaced with an MPU-6050 sensor module. The MPU-6050 is a 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer. The Arduino UNO is used to communicate with the MPU-6050 via the I2C protocol, facilitated by the SCL and SDA lines. The Arduino UNO provides power to the MPU-6050 and serves as the platform for running the user-defined code to interact with the sensor.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13.
- Purpose: Acts as the main controller for the circuit, providing I/O capabilities and processing power.
MPU-6050
- Description: A 6-axis motion tracking device with a gyroscope and accelerometer.
- Pins: VCC, GND, SCL, SDA, XDA, XCL, AD0, INT.
- Purpose: Senses motion and provides acceleration and gyroscopic data to the Arduino UNO.
Wiring Details
Arduino UNO
- 5V - Provides power to the MPU-6050 VCC.
- GND - Common ground with the MPU-6050.
- A4 (SDA) - I2C data line connected to the MPU-6050 SDA.
- A5 (SCL) - I2C clock line connected to the MPU-6050 SCL.
MPU-6050
- VCC - Powered by the Arduino UNO 5V pin.
- GND - Connected to the Arduino UNO GND.
- SCL - I2C clock line connected to the Arduino UNO A5.
- SDA - I2C data line connected to the Arduino UNO A4.
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code is a template and does not include specific instructions for interacting with the MPU-6050 sensor. To fully utilize the sensor, the setup function should initialize the I2C communication, and the loop function should contain code to read and process data from the MPU-6050.
Additional Files
- documentation.txt: This file is mentioned in the code input but contains no content. It is likely intended for additional notes or manual documentation.