
Arduino-Controlled Robotics Platform with Solar Charging and Object Detection
View and Edit Project In Cirkit Designer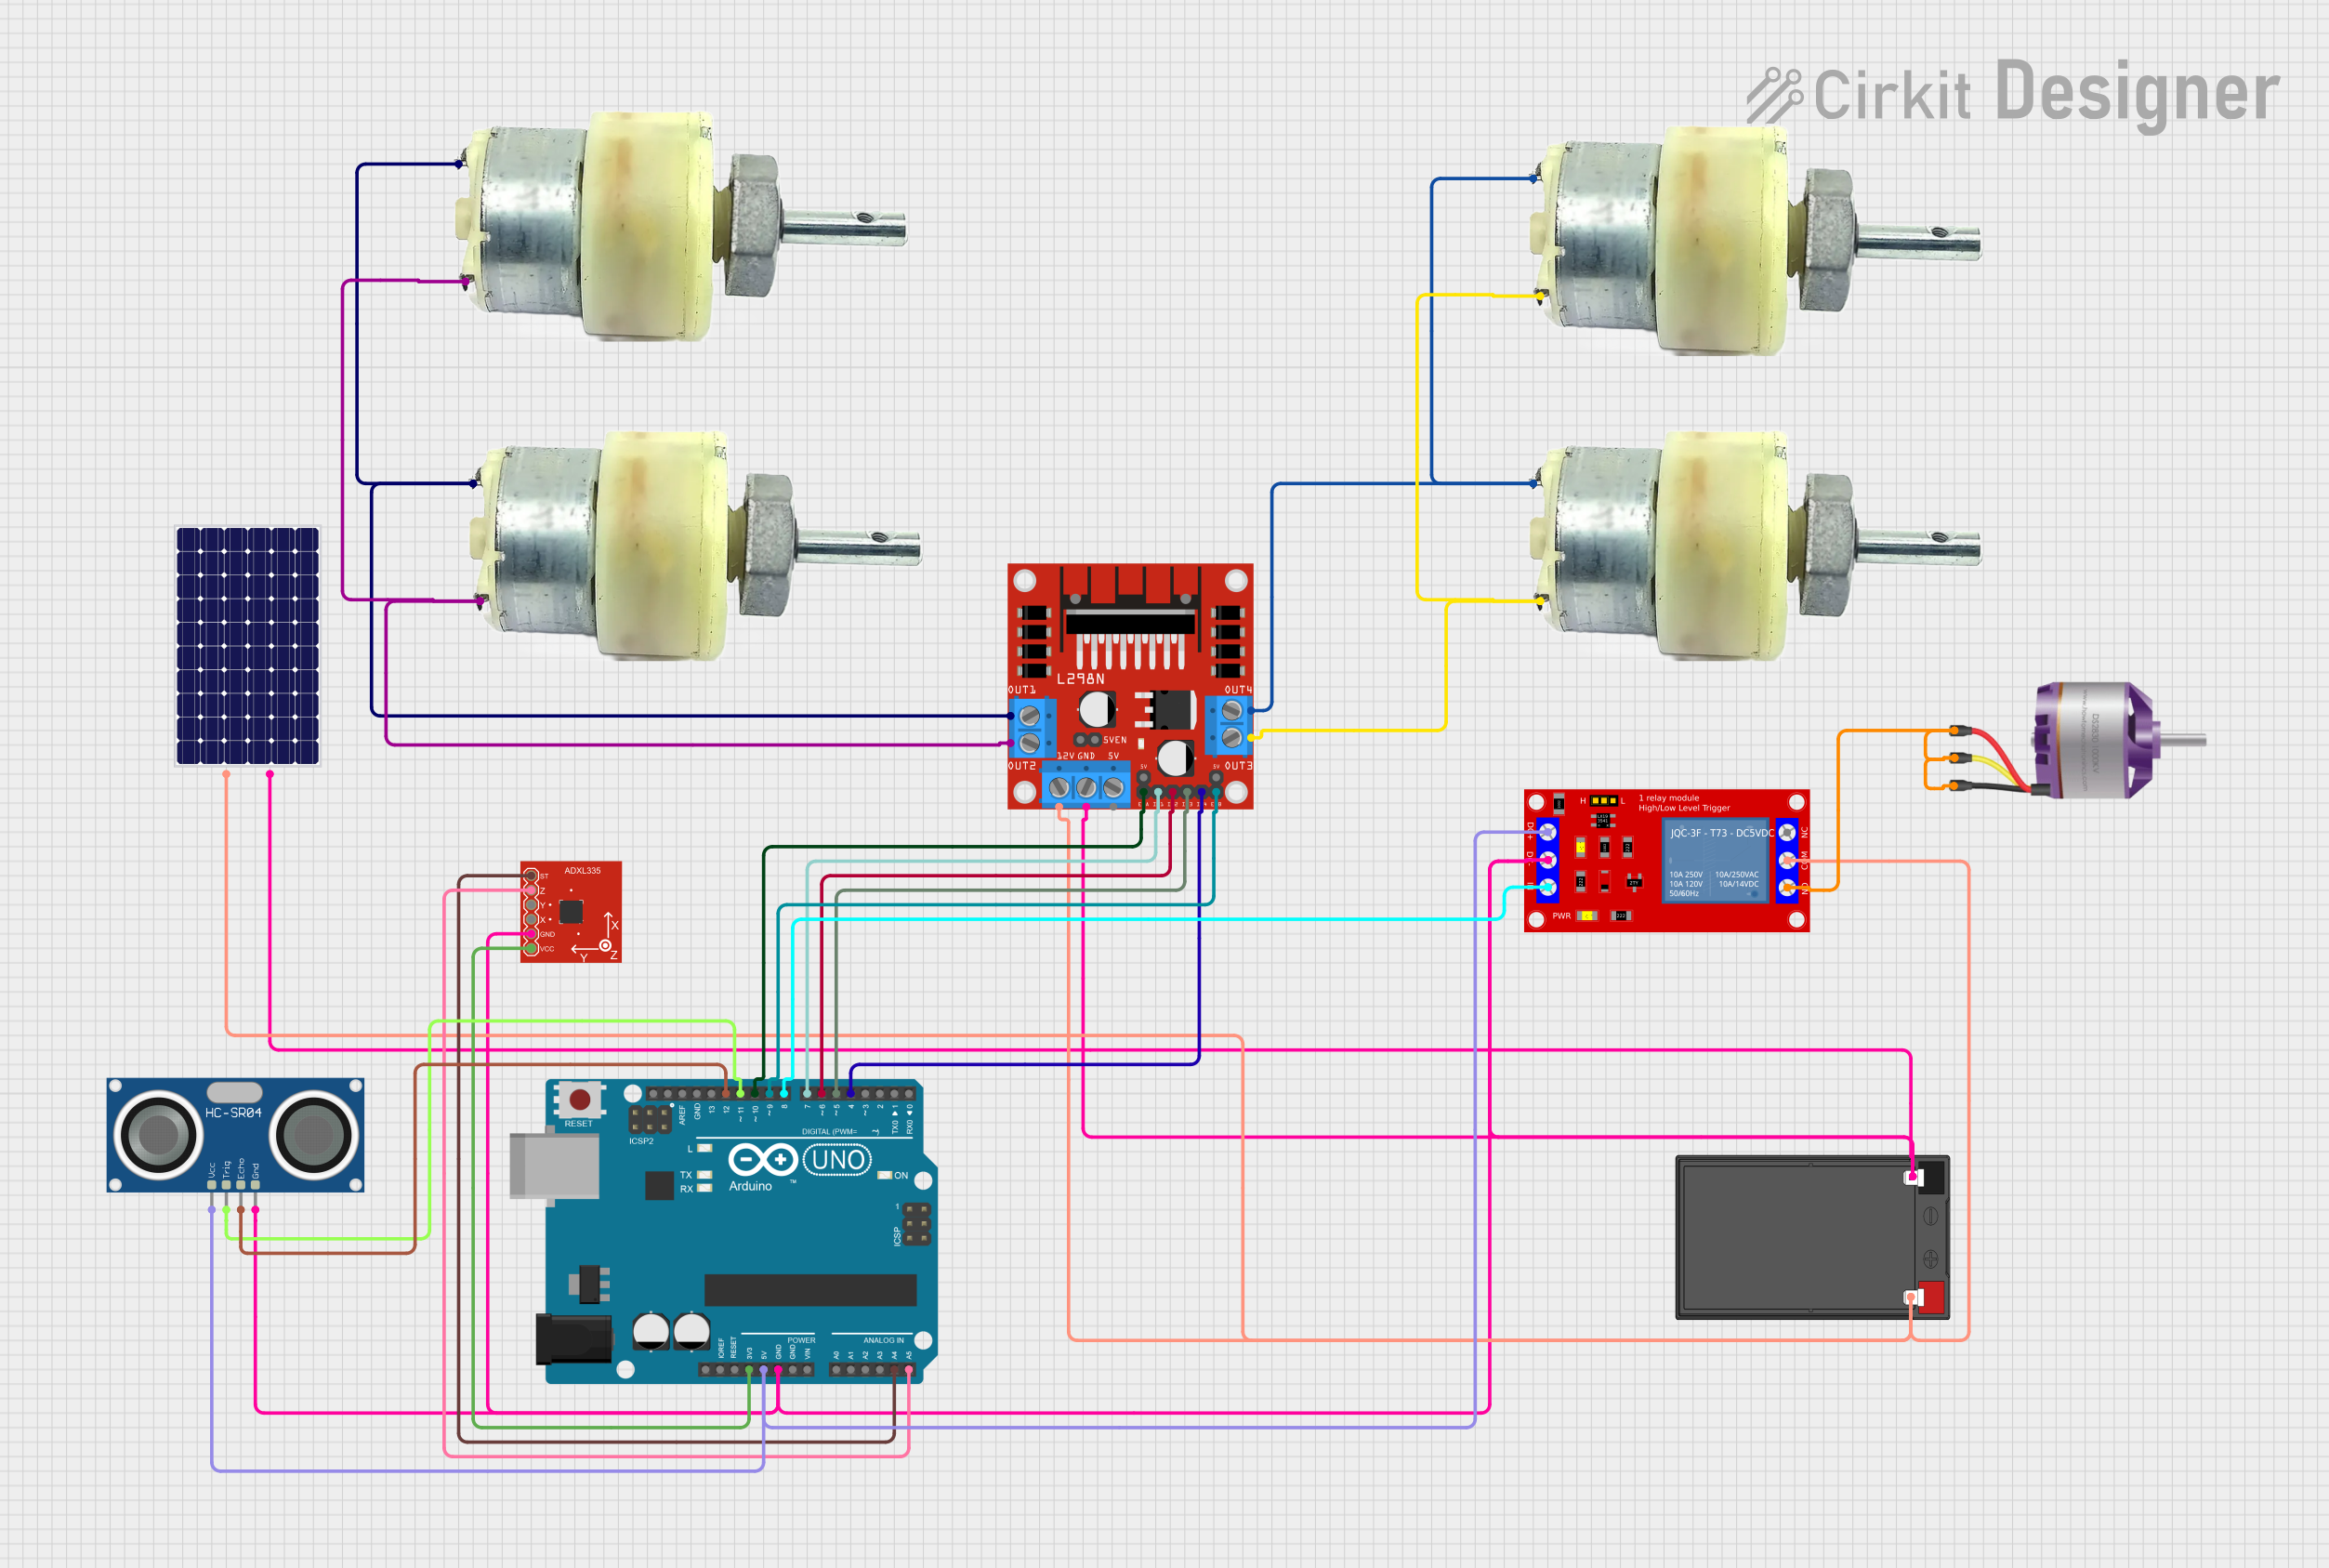
Circuit Documentation
Summary
This circuit is designed to control various motors and sensors through an Arduino UNO microcontroller. It includes a motor driver for controlling geared motors, a relay module for switching a brushless motor, an ultrasonic sensor for distance measurement, a triple-axis accelerometer for motion detection, and a solar panel with a battery for power supply. The circuit is likely intended for a robotics or automation project where motor control and environmental sensing are required.
Component List
Microcontroller
- Arduino UNO: A microcontroller board based on the ATmega328P, with a variety of digital and analog I/O pins.
Motors
- 12V Geared Motors: Motors with gear reduction for increased torque.
- Brushless Motor: A high-efficiency motor commonly used in applications requiring high reliability and power efficiency.
Power Supply
- 12v 7ah Battery: A rechargeable battery providing a 12V power source.
- Solar Panel: A photovoltaic panel used to convert solar energy into electrical power.
Motor Driver
- L298N DC Motor Driver: A module capable of driving up to two DC motors with directional and speed control.
Sensors
- Triple Axis Accelerometer (ADXL335): A sensor measuring acceleration in three axes.
- HC-SR04 Ultrasonic Sensor: A sensor for measuring distance via ultrasonic waves.
Relay Module
- 1 Channel 5V Relay Module: A module for controlling high power devices, acting as an electrically operated switch.
Wiring Details
Arduino UNO
- 3.3V connected to Triple Axis Accelerometer (ADXL335) VCC
- 5V connected to 1 Channel 5V Relay Module VCC+ and HC-SR04 Ultrasonic Sensor VCC
- GND connected to L298N DC Motor Driver GND, Solar Panel -, Triple Axis Accelerometer (ADXL335) GND, 1 Channel 5V Relay Module VCC- (GND), 12v 7ah Battery 12v -, and HC-SR04 Ultrasonic Sensor GND
- A4 (SCL) connected to Triple Axis Accelerometer (ADXL335) ST
- A5 (SDA) connected to Triple Axis Accelerometer (ADXL335) ZOUT
- D4-D12 various control signals for L298N DC Motor Driver and HC-SR04 Ultrasonic Sensor
12V Geared Motors
- Terminal 1 & Terminal 2 connected to L298N DC Motor Driver OUT1, OUT2, OUT3, and OUT4 for motor control
Brushless Motor
- L1, L2, L3 connected to 1 Channel 5V Relay Module N.O. for power switching
L298N DC Motor Driver
- 12V connected to Solar Panel + and 12v 7ah Battery 12v +
- Motor control pins (IN1-IN4, ENA, ENB) connected to Arduino UNO for motor control
HC-SR04 Ultrasonic Sensor
- TRIG and ECHO connected to Arduino UNO D11 and D12 for distance measurement
1 Channel 5V Relay Module
- IN connected to Arduino UNO D8 for relay control
- COM connected to Solar Panel + and 12v 7ah Battery 12v +
Solar Panel and 12v 7ah Battery
- + and - provide power to the circuit and are connected to the L298N DC Motor Driver and 1 Channel 5V Relay Module
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
The provided code is a template with empty setup() and loop() functions, which are the entry points for Arduino code. The setup() function is called once when the program starts and is used to initialize settings. The loop() function runs repeatedly, allowing the program to change and respond. Users will need to fill in these functions with specific commands to control the motors, read sensor data, and implement the desired logic for their application.