
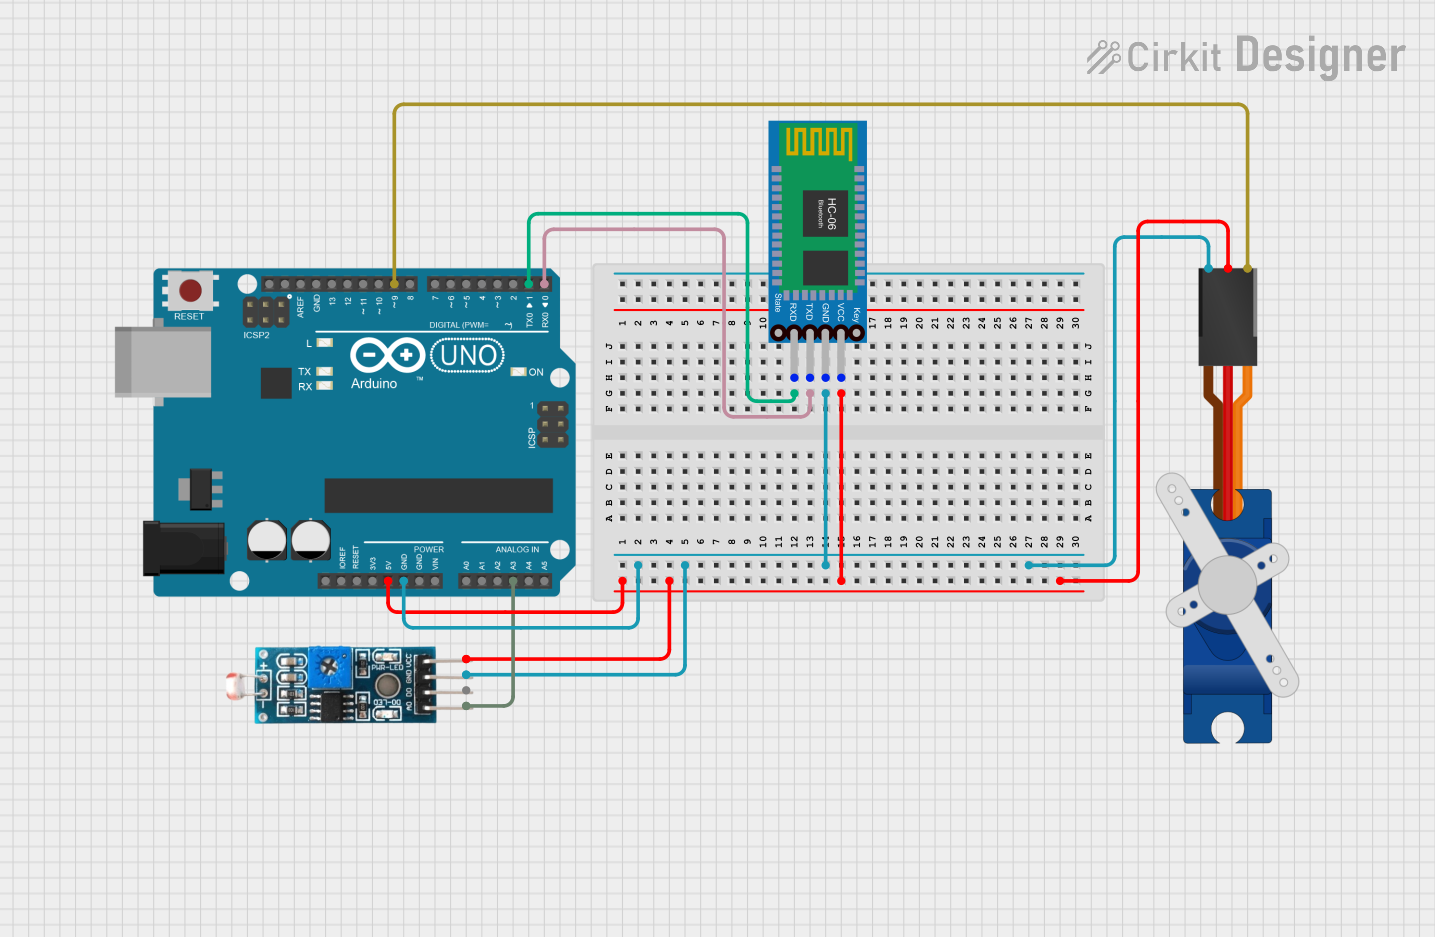
Circuit Documentation
Summary of the Circuit
This circuit integrates an Arduino UNO microcontroller with a Bluetooth HC-06 module, a Tower Pro SG90 servo motor, and a Module LDR (Light Dependent Resistor). The Arduino UNO serves as the central processing unit, controlling the servo based on signals from the LDR and communicating wirelessly via the Bluetooth module. The servo motor's position is likely to be adjusted in response to the light intensity detected by the LDR. The Bluetooth module enables remote communication, possibly for receiving commands or sending sensor data.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P. It has digital input/output pins, analog inputs, a USB connection for programming, and power management features.
- Purpose: Acts as the central controller for the circuit, interfacing with the Bluetooth module, reading the LDR sensor, and controlling the servo motor.
Tower Pro SG90 Servo
- Description: A small and lightweight servo motor capable of precise control. It operates on 5V and can be used for various applications requiring controlled movement.
- Purpose: To provide controlled movement, likely adjusted based on the LDR sensor readings.
Module LDR
- Description: A light sensor module that includes an LDR and typically has both analog and digital outputs.
- Purpose: To detect the intensity of light in the environment and provide input to the Arduino for processing.
Bluetooth HC-06
- Description: A Bluetooth module that allows for wireless communication over Bluetooth. It has a serial interface for communication with microcontrollers.
- Purpose: To enable wireless communication for the circuit, possibly for remote control or data transmission.
Wiring Details
Arduino UNO
- 5V: Powers the Bluetooth HC-06, Module LDR, and Tower Pro SG90 servo.
- GND: Common ground for Bluetooth HC-06, Module LDR, and Tower Pro SG90 servo.
- D0 (RX): Receives serial data from the TXD pin of the Bluetooth HC-06.
- D1 (TX): Transmits serial data to the RXD pin of the Bluetooth HC-06.
- A3: Reads the analog output from the AO pin of the Module LDR.
- D9: Outputs PWM signal to control the Tower Pro SG90 servo.
Tower Pro SG90 Servo
- Signal: Connected to D9 on the Arduino UNO for PWM control.
- +5V: Powered by the 5V output from the Arduino UNO.
- GND: Connected to the common ground.
Module LDR
- AO: Analog output connected to A3 on the Arduino UNO.
- VCC: Powered by the 5V output from the Arduino UNO.
- GND: Connected to the common ground.
Bluetooth HC-06
- TXD: Transmits serial data to D0 (RX) on the Arduino UNO.
- RXD: Receives serial data from D1 (TX) on the Arduino UNO.
- VCC: Powered by the 5V output from the Arduino UNO.
- GND: Connected to the common ground.
Documented Code
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
File: sketch.ino
Note: The provided code is a template and does not contain any functional code. It needs to be populated with the logic for reading the LDR sensor, controlling the servo, and managing Bluetooth communication.