
Raspberry Pi-Controlled Drone with Brushless Motors and Camera Module
View and Edit Project In Cirkit Designer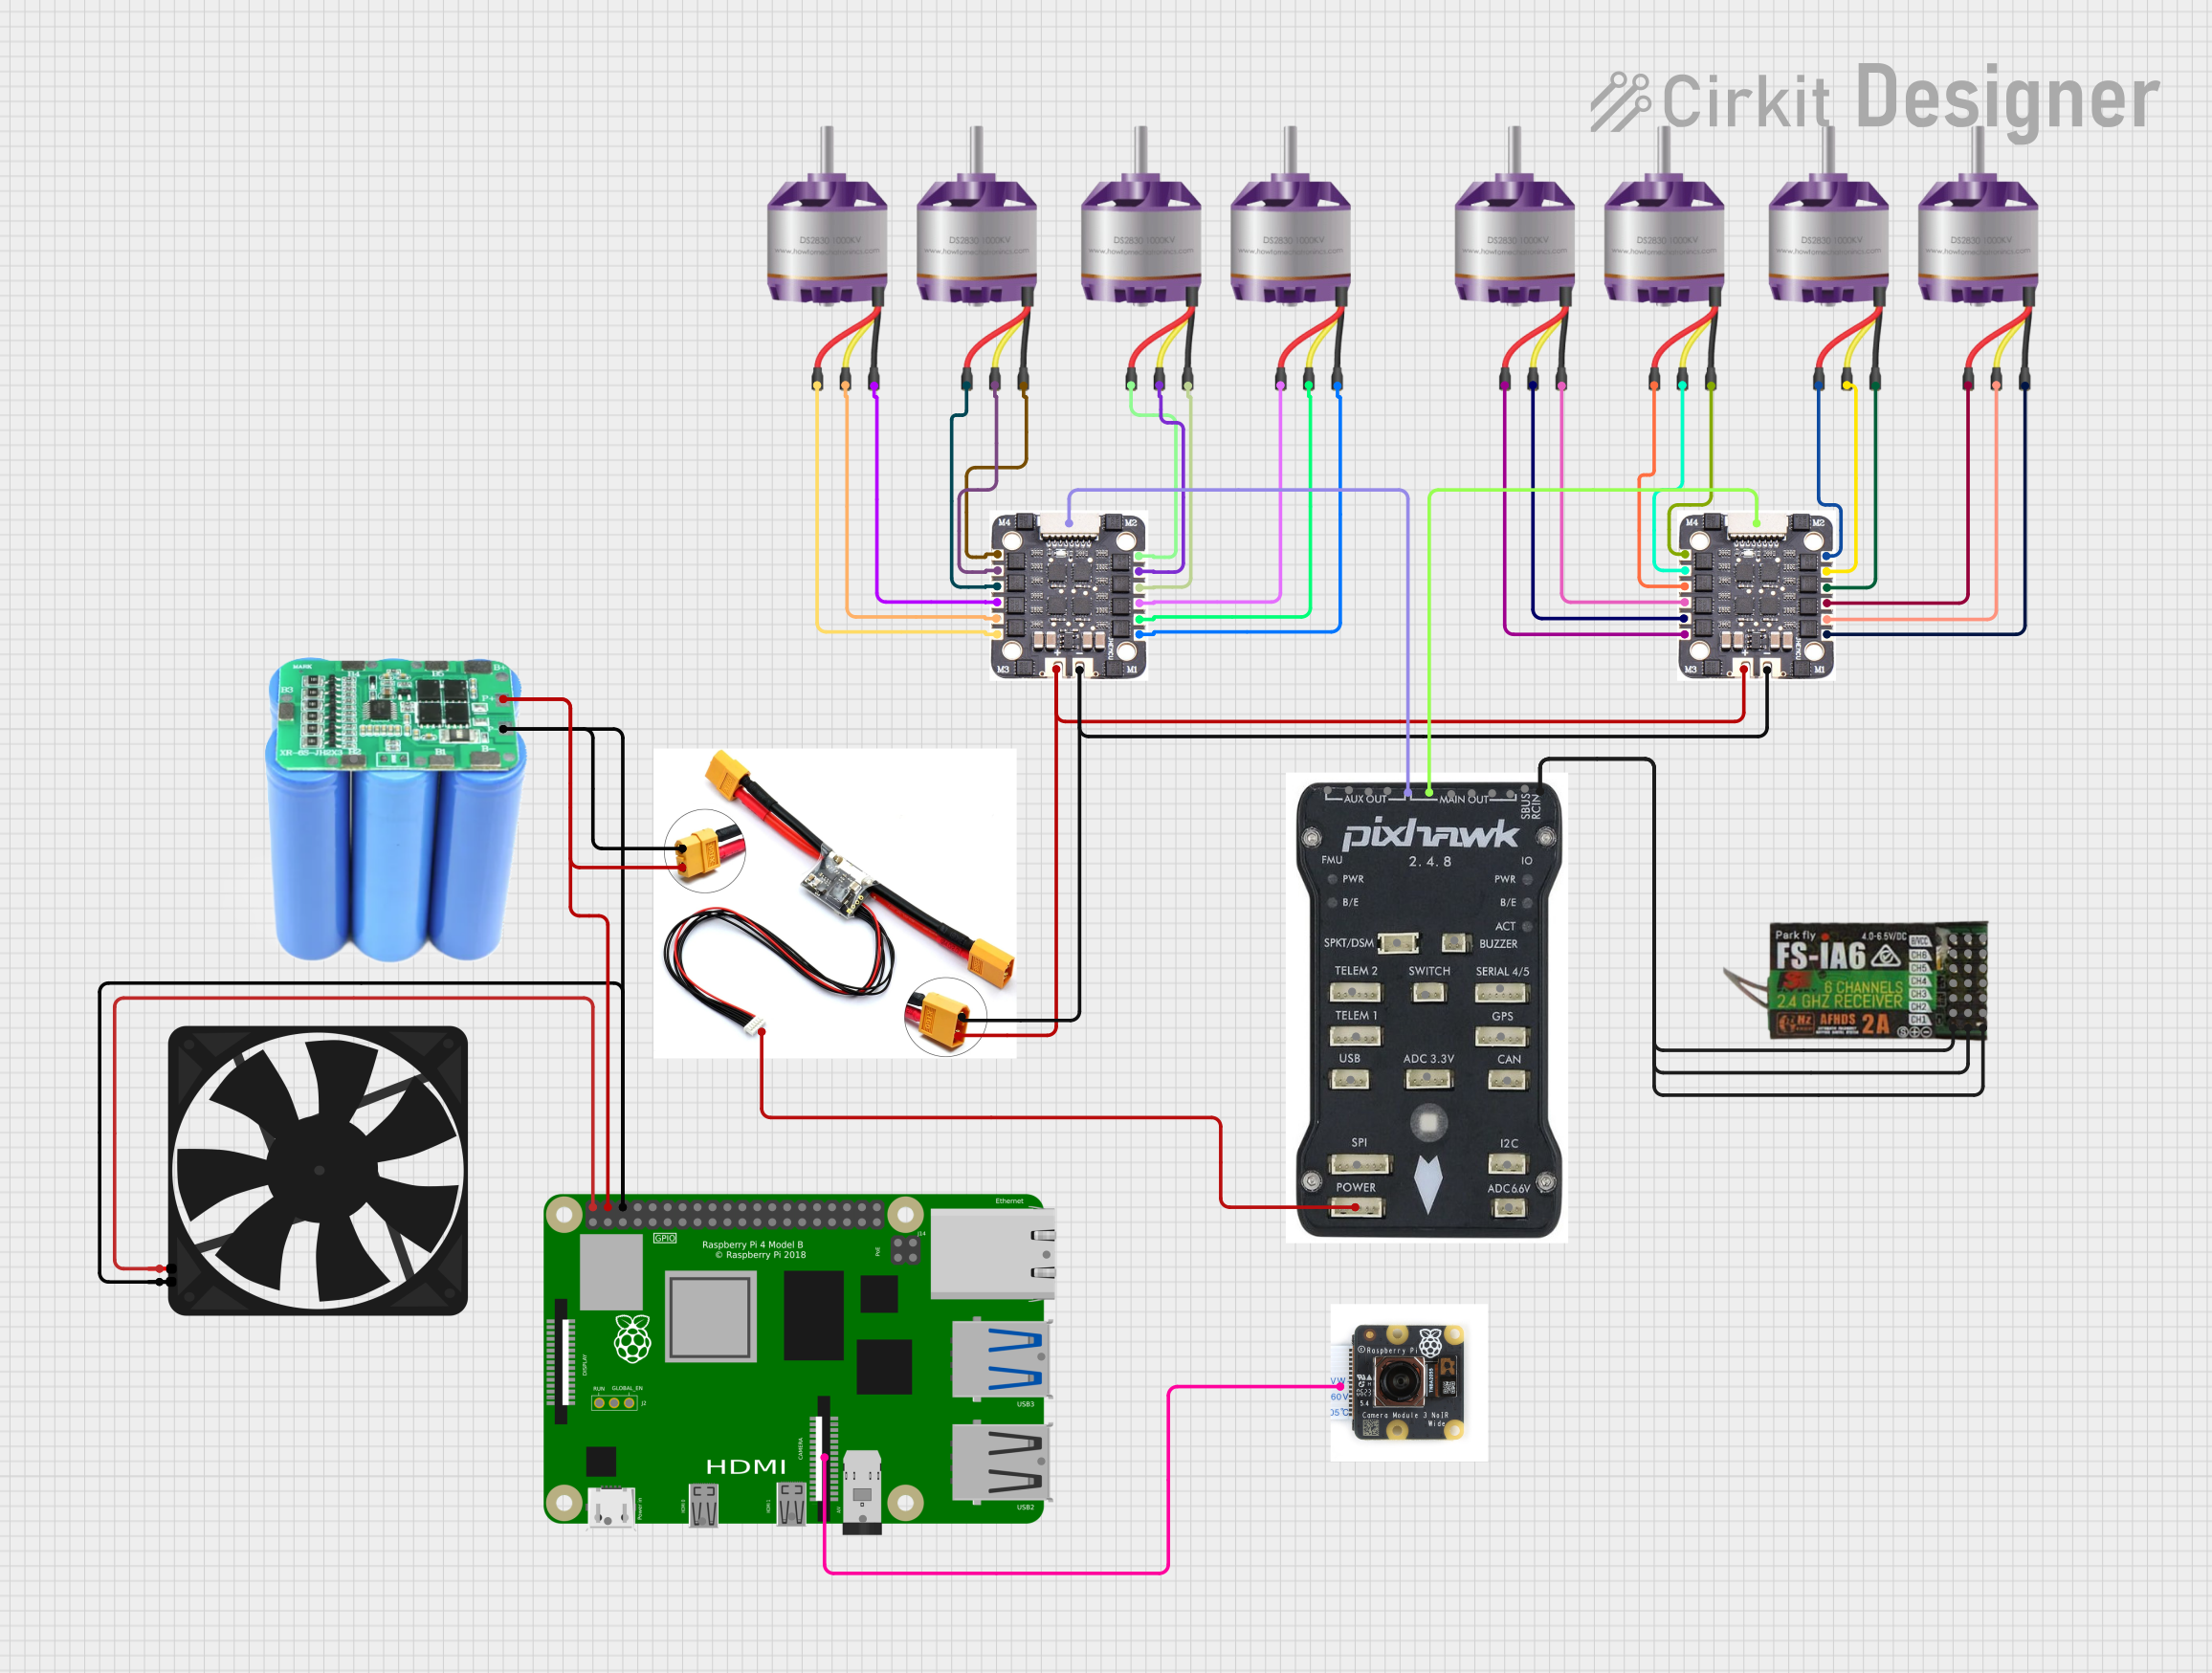
Circuit Documentation
Summary
The circuit in question appears to be designed for a multi-motor application, possibly for a drone or a similar multi-rotor vehicle. It includes a power distribution system, motor controllers, brushless motors, a flight controller, a single-board computer for higher-level functions, a camera module, a receiver for remote control, and a cooling fan. The power is supplied by a 18650 3s2p battery configuration, and the power distribution is managed by an APM/Pixhawk Power Module. The motor control is handled by two BLHELI_S EM-40A 4IN1 ESCs, which drive eight brushless motors. The Raspberry Pi 4B serves as the onboard computer, interfacing with a NoIR camera module. The Pixhawk PX4 flight controller is responsible for flight dynamics and receives input from a FLYSKY FS-IA6 receiver. A fan is included to provide cooling, likely for the Raspberry Pi.
Component List
Brushless Motors
- Description: These are the actuators in the system, responsible for converting electrical energy into mechanical rotation.
- Purpose: To provide thrust when connected to propellers in a multi-rotor vehicle.
18650 3s2p Battery Pack
- Description: A rechargeable battery pack configuration using 18650-type cells.
- Purpose: To supply power to the entire circuit.
BLHELI_S EM-40A 4IN1 ESC
- Description: An electronic speed controller capable of driving four brushless motors.
- Purpose: To control the speed and rotation of the brushless motors.
APM/Pixhawk Power Module
- Description: A module that provides power to the flight controller and measures voltage and current from the battery.
- Purpose: To distribute power and provide telemetry data.
Raspberry Pi 4B
- Description: A powerful single-board computer with a variety of I/O options.
- Purpose: To handle high-level tasks, data processing, and interfacing with peripherals like the camera module.
Raspberry Pi Camera Module 3 NoIR
- Description: A camera module compatible with the Raspberry Pi, lacking an infrared filter for night vision capabilities.
- Purpose: To capture visual data for processing or remote viewing.
Fan
- Description: A small cooling fan.
- Purpose: To provide airflow and cooling, likely for the Raspberry Pi.
FLYSKY FS-IA6 Receiver
- Description: A 6-channel receiver for remote control signals.
- Purpose: To receive control inputs from a remote transmitter.
Pixhawk PX4 PIX 2.4.8 32 Bit Flight Controller
- Description: An advanced flight controller for multi-rotor vehicles.
- Purpose: To manage flight dynamics and stabilization.
Wiring Details
Brushless Motors
- Connected to the corresponding motor outputs on the BLHELI_S EM-40A 4IN1 ESCs.
18650 3s2p Battery Pack
- Positive terminal connected to the APM/Pixhawk Power Module.
- Negative terminal connected to the common ground in the circuit.
BLHELI_S EM-40A 4IN1 ESC
- Battery inputs connected to the APM/Pixhawk Power Module for power.
- Motor outputs connected to the respective brushless motors.
- Data line connected to the Pixhawk PX4 flight controller for control signals.
APM/Pixhawk Power Module
- Connected to the battery pack for power input.
- Provides power to the Raspberry Pi 4B and the Pixhawk PX4 flight controller.
- Common ground connection with the fan, Raspberry Pi, and battery pack.
Raspberry Pi 4B
- Powered by the APM/Pixhawk Power Module.
- Ground connected to the common ground in the circuit.
- Camera interface connected to the Raspberry Pi Camera Module 3 NoIR.
- 5V output connected to the fan for power.
Raspberry Pi Camera Module 3 NoIR
- Interface connected to the Raspberry Pi 4B.
Fan
- Powered by the 5V output from the Raspberry Pi 4B.
- Ground connected to the common ground in the circuit.
FLYSKY FS-IA6 Receiver
- Powered by a 5V supply.
- Ground connected to the common ground in the circuit.
- Control channels interfaced with the Pixhawk PX4 flight controller.
Pixhawk PX4 PIX 2.4.8 32 Bit Flight Controller
- Powered by the APM/Pixhawk Power Module.
- Receives control signals from the FLYSKY FS-IA6 receiver.
- Sends control signals to the BLHELI_S EM-40A 4IN1 ESCs.
Documented Code
No code was provided for the microcontrollers in the circuit. If code is available, it should be documented here with descriptions of its functionality and how it interfaces with the hardware components.