
Raspberry Pi and TB6600 Stepper Motor Driver Controlled NEMA23 Motors
View and Edit Project In Cirkit Designer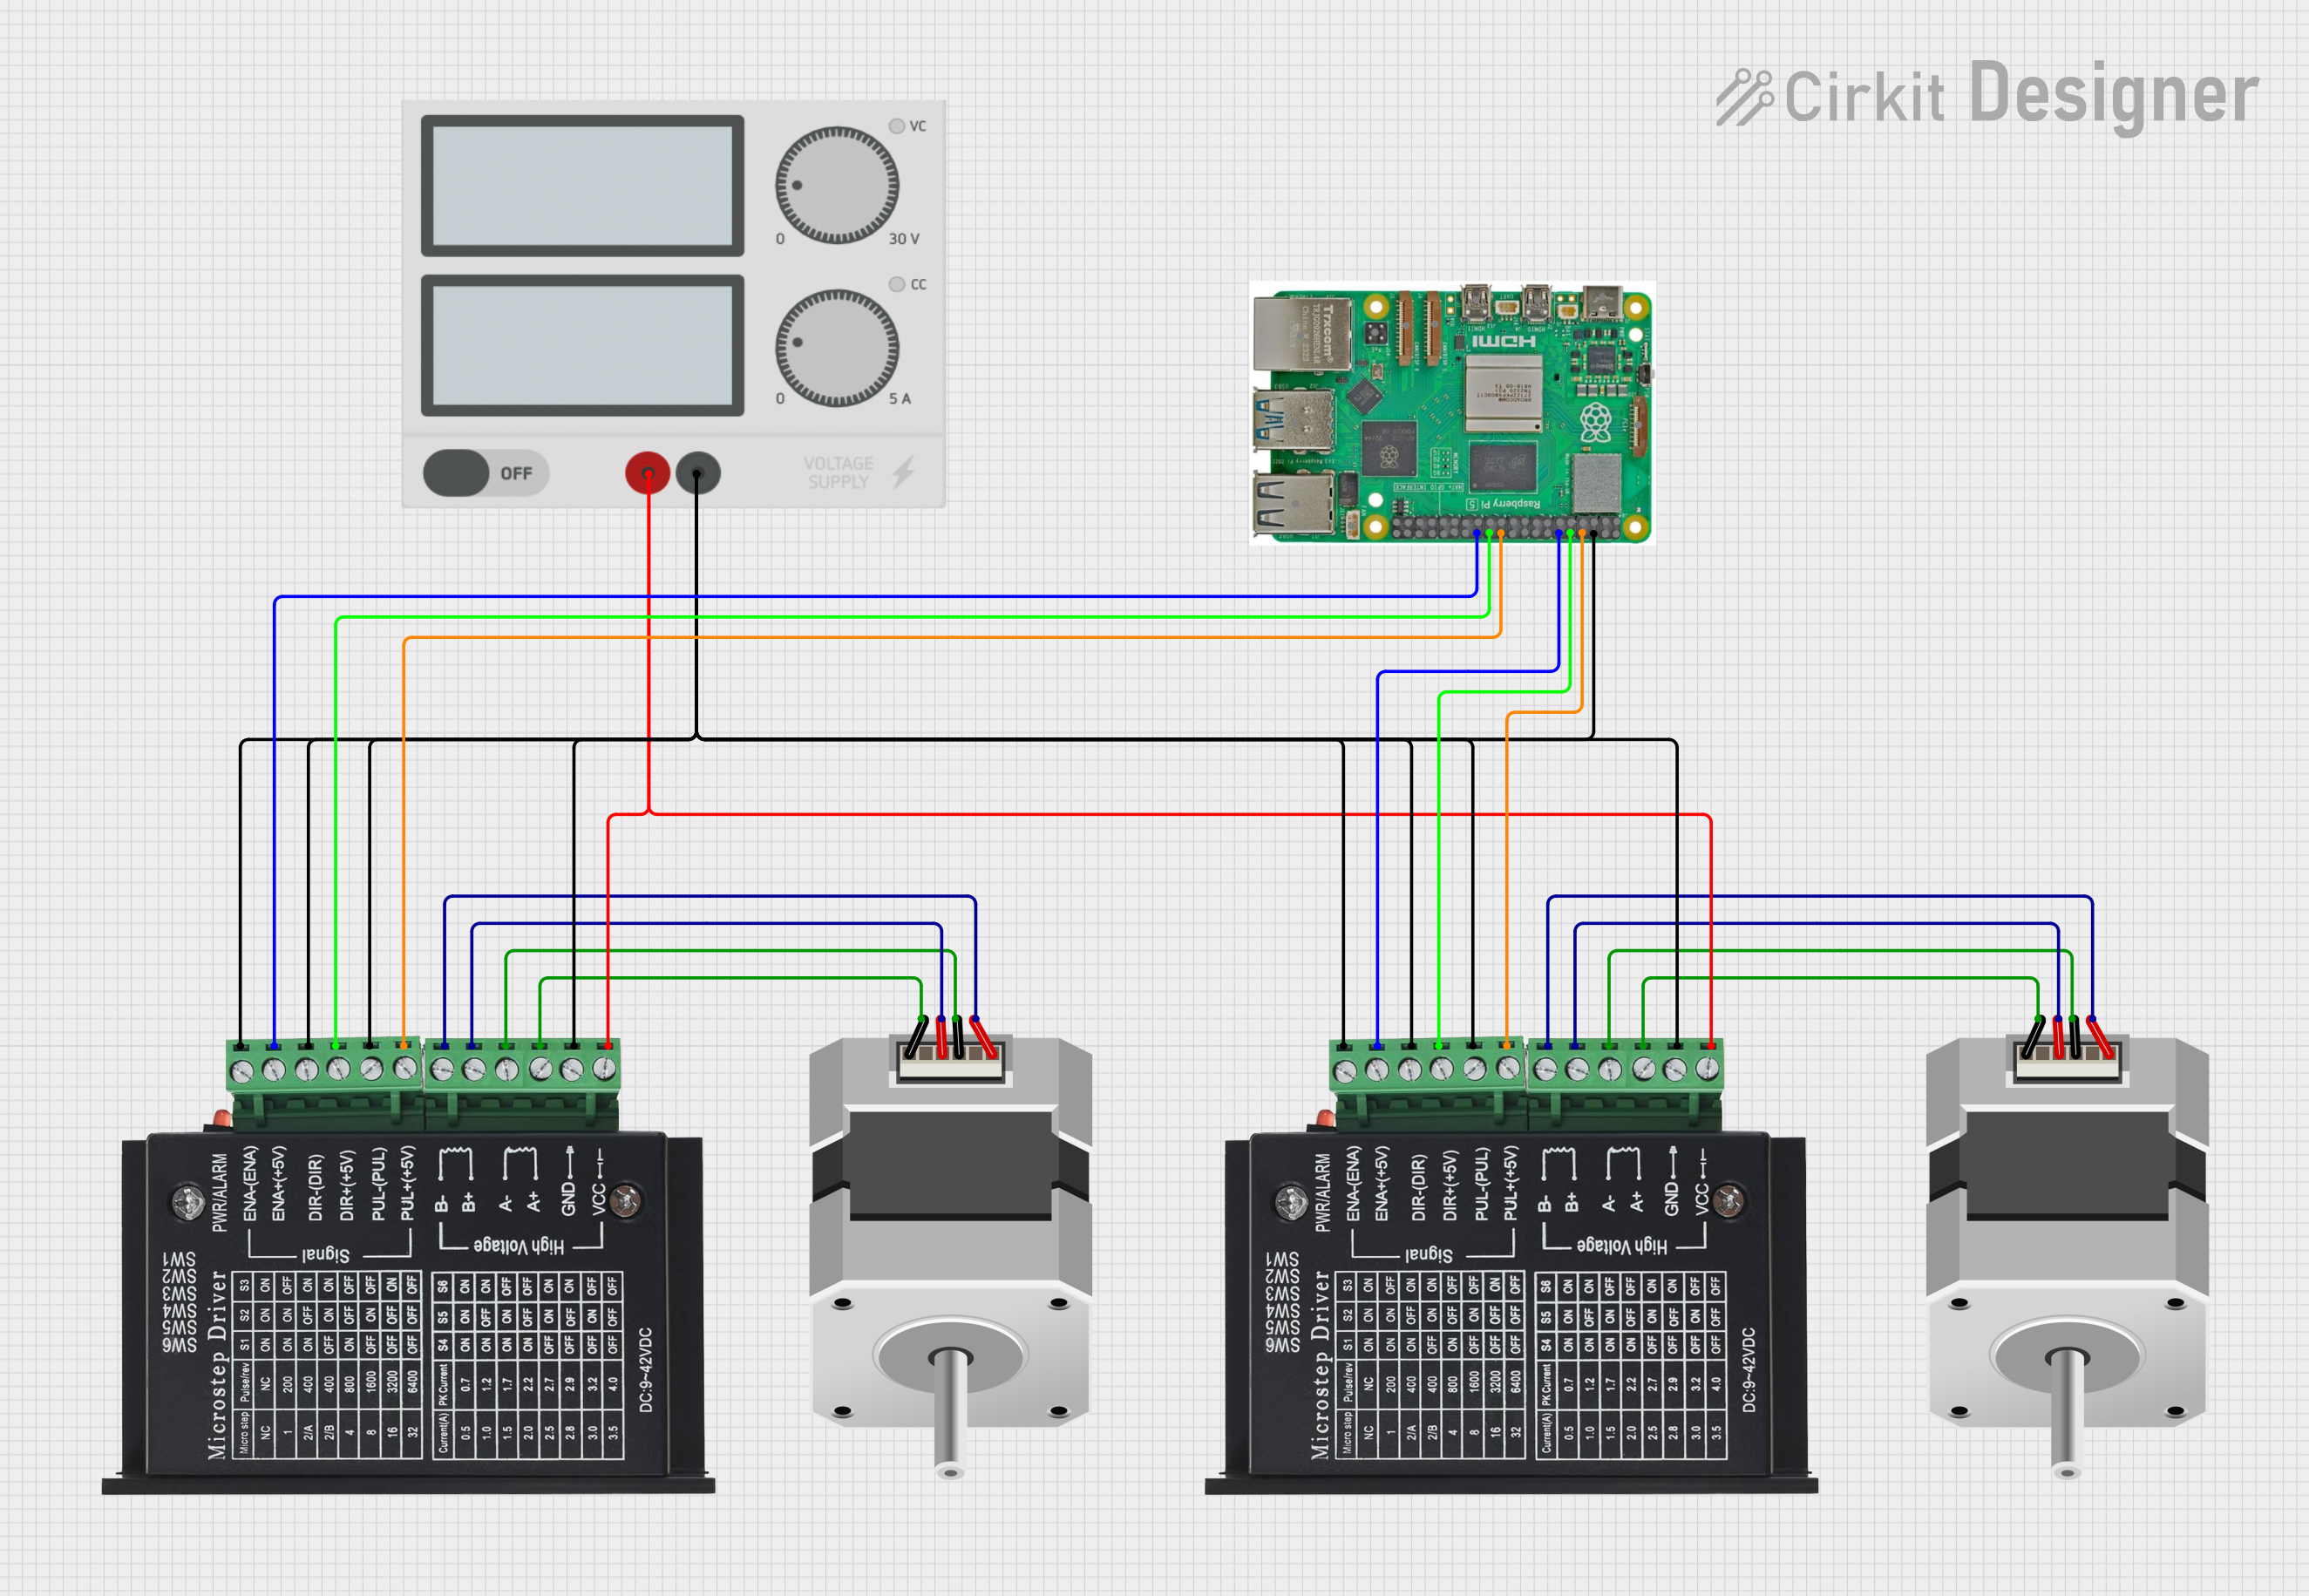
Circuit Documentation
Summary
This document provides a detailed overview of a circuit that includes a Raspberry Pi 5, two TB6600 stepper motor drivers, two NEMA23 stepper motors, and a power supply. The Raspberry Pi 5 is used to control the TB6600 drivers, which in turn drive the NEMA23 stepper motors. The power supply provides the necessary voltage and current to the TB6600 drivers.
Component List
Raspberry Pi 5
- Description: A single-board computer used for controlling the stepper motor drivers.
- Pins: Type-C, Micro HDMI 1, Micro HDMI 2, Camera 1, Camera 2, PoE, Fan, PCIe, USB 3.0, USB 2.0, Ethernet, 5V, GND, 3.3v, GPIO 14, GPIO 15, GPIO 18, GPIO 23, GPIO 24, GPIO 25, GPIO 8, GPIO 7, GPIO 1, GPIO 12, GPIO 16, GPIO 20, GPIO 21, GPIO 2, GPIO 3, GPIO 4, GPIO 17, GPIO 27, GPIO 22, GPIO 10, GPIO 9, GPIO 11, GPIO 0, GPIO 5, GPIO 6, GPIO 13, GPIO 19, GPIO 26
TB6600 Stepper Motor Driver (2 units)
- Description: A stepper motor driver used to control the NEMA23 stepper motors.
- Pins: ENA-, ENA+, DIR-, DIR+, PUL-, PUL+, B-, B+, A-, A+, GND, VCC
NEMA23 Stepper Motor (2 units)
- Description: A stepper motor used for precise control of mechanical movements.
- Pins: D, B, C, A
Power Supply
- Description: Provides the necessary voltage and current to the TB6600 drivers.
- Pins: +, -
Wiring Details
Raspberry Pi 5
GND is connected to:
- TB6600 (ENA-, GND, DIR-, PUL-) of both units
- Power Supply (-)
GPIO 7 is connected to:
- TB6600 (ENA+) of the first unit
GPIO 8 is connected to:
- TB6600 (DIR+) of the first unit
GPIO 25 is connected to:
- TB6600 (PUL+) of the first unit
GPIO 18 is connected to:
- TB6600 (ENA+) of the second unit
GPIO 15 is connected to:
- TB6600 (DIR+) of the second unit
GPIO 14 is connected to:
- TB6600 (PUL+) of the second unit
TB6600 Stepper Motor Driver (First Unit)
ENA- is connected to:
- Raspberry Pi 5 (GND)
ENA+ is connected to:
- Raspberry Pi 5 (GPIO 7)
DIR- is connected to:
- Raspberry Pi 5 (GND)
DIR+ is connected to:
- Raspberry Pi 5 (GPIO 8)
PUL- is connected to:
- Raspberry Pi 5 (GND)
PUL+ is connected to:
- Raspberry Pi 5 (GPIO 25)
B- is connected to:
- NEMA23 (A)
B+ is connected to:
- NEMA23 (B)
A- is connected to:
- NEMA23 (C)
A+ is connected to:
- NEMA23 (D)
GND is connected to:
- Raspberry Pi 5 (GND)
VCC is connected to:
- Power Supply (+)
TB6600 Stepper Motor Driver (Second Unit)
ENA- is connected to:
- Raspberry Pi 5 (GND)
ENA+ is connected to:
- Raspberry Pi 5 (GPIO 18)
DIR- is connected to:
- Raspberry Pi 5 (GND)
DIR+ is connected to:
- Raspberry Pi 5 (GPIO 15)
PUL- is connected to:
- Raspberry Pi 5 (GND)
PUL+ is connected to:
- Raspberry Pi 5 (GPIO 14)
B- is connected to:
- NEMA23 (A)
B+ is connected to:
- NEMA23 (B)
A- is connected to:
- NEMA23 (C)
A+ is connected to:
- NEMA23 (D)
GND is connected to:
- Raspberry Pi 5 (GND)
VCC is connected to:
- Power Supply (+)
NEMA23 Stepper Motor (First Unit)
A is connected to:
- TB6600 (B-)
B is connected to:
- TB6600 (B+)
C is connected to:
- TB6600 (A-)
D is connected to:
- TB6600 (A+)
NEMA23 Stepper Motor (Second Unit)
A is connected to:
- TB6600 (B-)
B is connected to:
- TB6600 (B+)
C is connected to:
- TB6600 (A-)
D is connected to:
- TB6600 (A+)
Power Supply
+ is connected to:
- TB6600 (VCC) of both units
- is connected to:
- Raspberry Pi 5 (GND)
- TB6600 (GND) of both units
Code
No code is provided for this circuit.