
Circuit Documentation
Summary of the Circuit
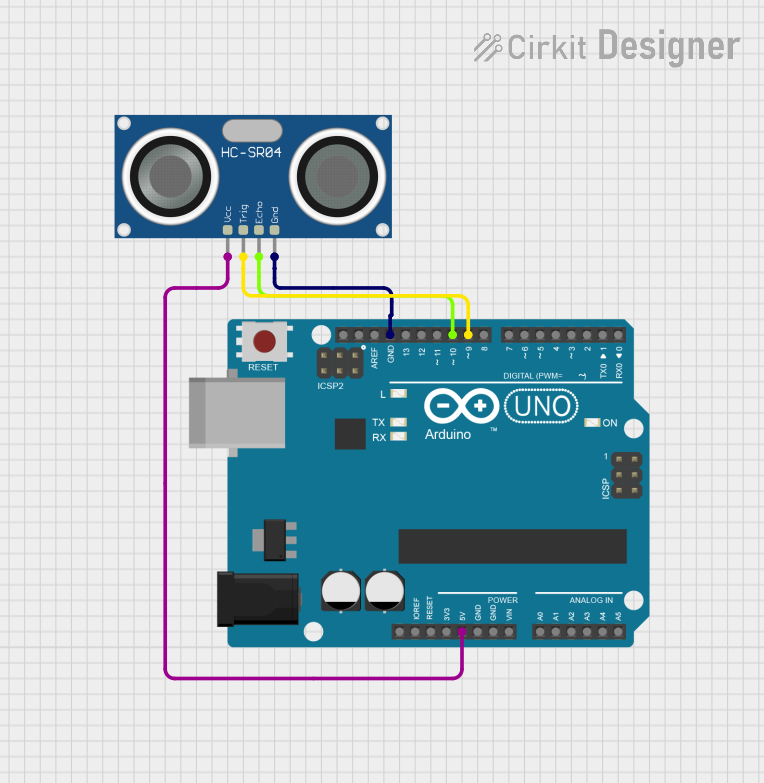
This circuit integrates an Arduino UNO microcontroller board with an HC-SR04 Ultrasonic Sensor. The purpose of the circuit is to utilize the ultrasonic sensor for distance measurement, with the Arduino UNO serving as the control unit to process the sensor data. The sensor is powered by the Arduino and communicates with it using two digital pins for triggering and receiving echo signals.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13.
- Purpose: Acts as the central processing unit for the circuit, controlling the HC-SR04 Ultrasonic Sensor and processing its signals.
HC-SR04 Ultrasonic Sensor
- Description: An ultrasonic distance sensor capable of measuring distances from 2cm to 400cm.
- Pins: VCC, TRIG, ECHO, GND.
- Purpose: Measures the distance to an object by emitting ultrasonic waves and timing the return of the reflected signal.
Wiring Details
Arduino UNO
- 5V: Provides power to the HC-SR04 Ultrasonic Sensor.
- GND: Common ground with the HC-SR04 Ultrasonic Sensor.
- D10: Connected to the ECHO pin of the HC-SR04 Ultrasonic Sensor to receive the signal.
- D9: Connected to the TRIG pin of the HC-SR04 Ultrasonic Sensor to send the trigger signal.
HC-SR04 Ultrasonic Sensor
- VCC: Connected to the 5V pin of the Arduino UNO for power.
- GND: Connected to the GND pin of the Arduino UNO for common ground.
- ECHO: Connected to the D10 pin of the Arduino UNO to send the echo signal.
- TRIG: Connected to the D9 pin of the Arduino UNO to receive the trigger signal.
Documented Code
sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
documentation.txt
(No additional documentation provided in the code input)
This concludes the documentation for the given circuit. The code provided is a template and does not include the logic for operating the HC-SR04 Ultrasonic Sensor. The user is expected to implement the setup and loop functions to initialize the sensor and to handle the trigger and echo signals for distance measurement.