
Arduino-Controlled Bluetooth Robotic Car with Dual Motor Driver
View and Edit Project In Cirkit Designer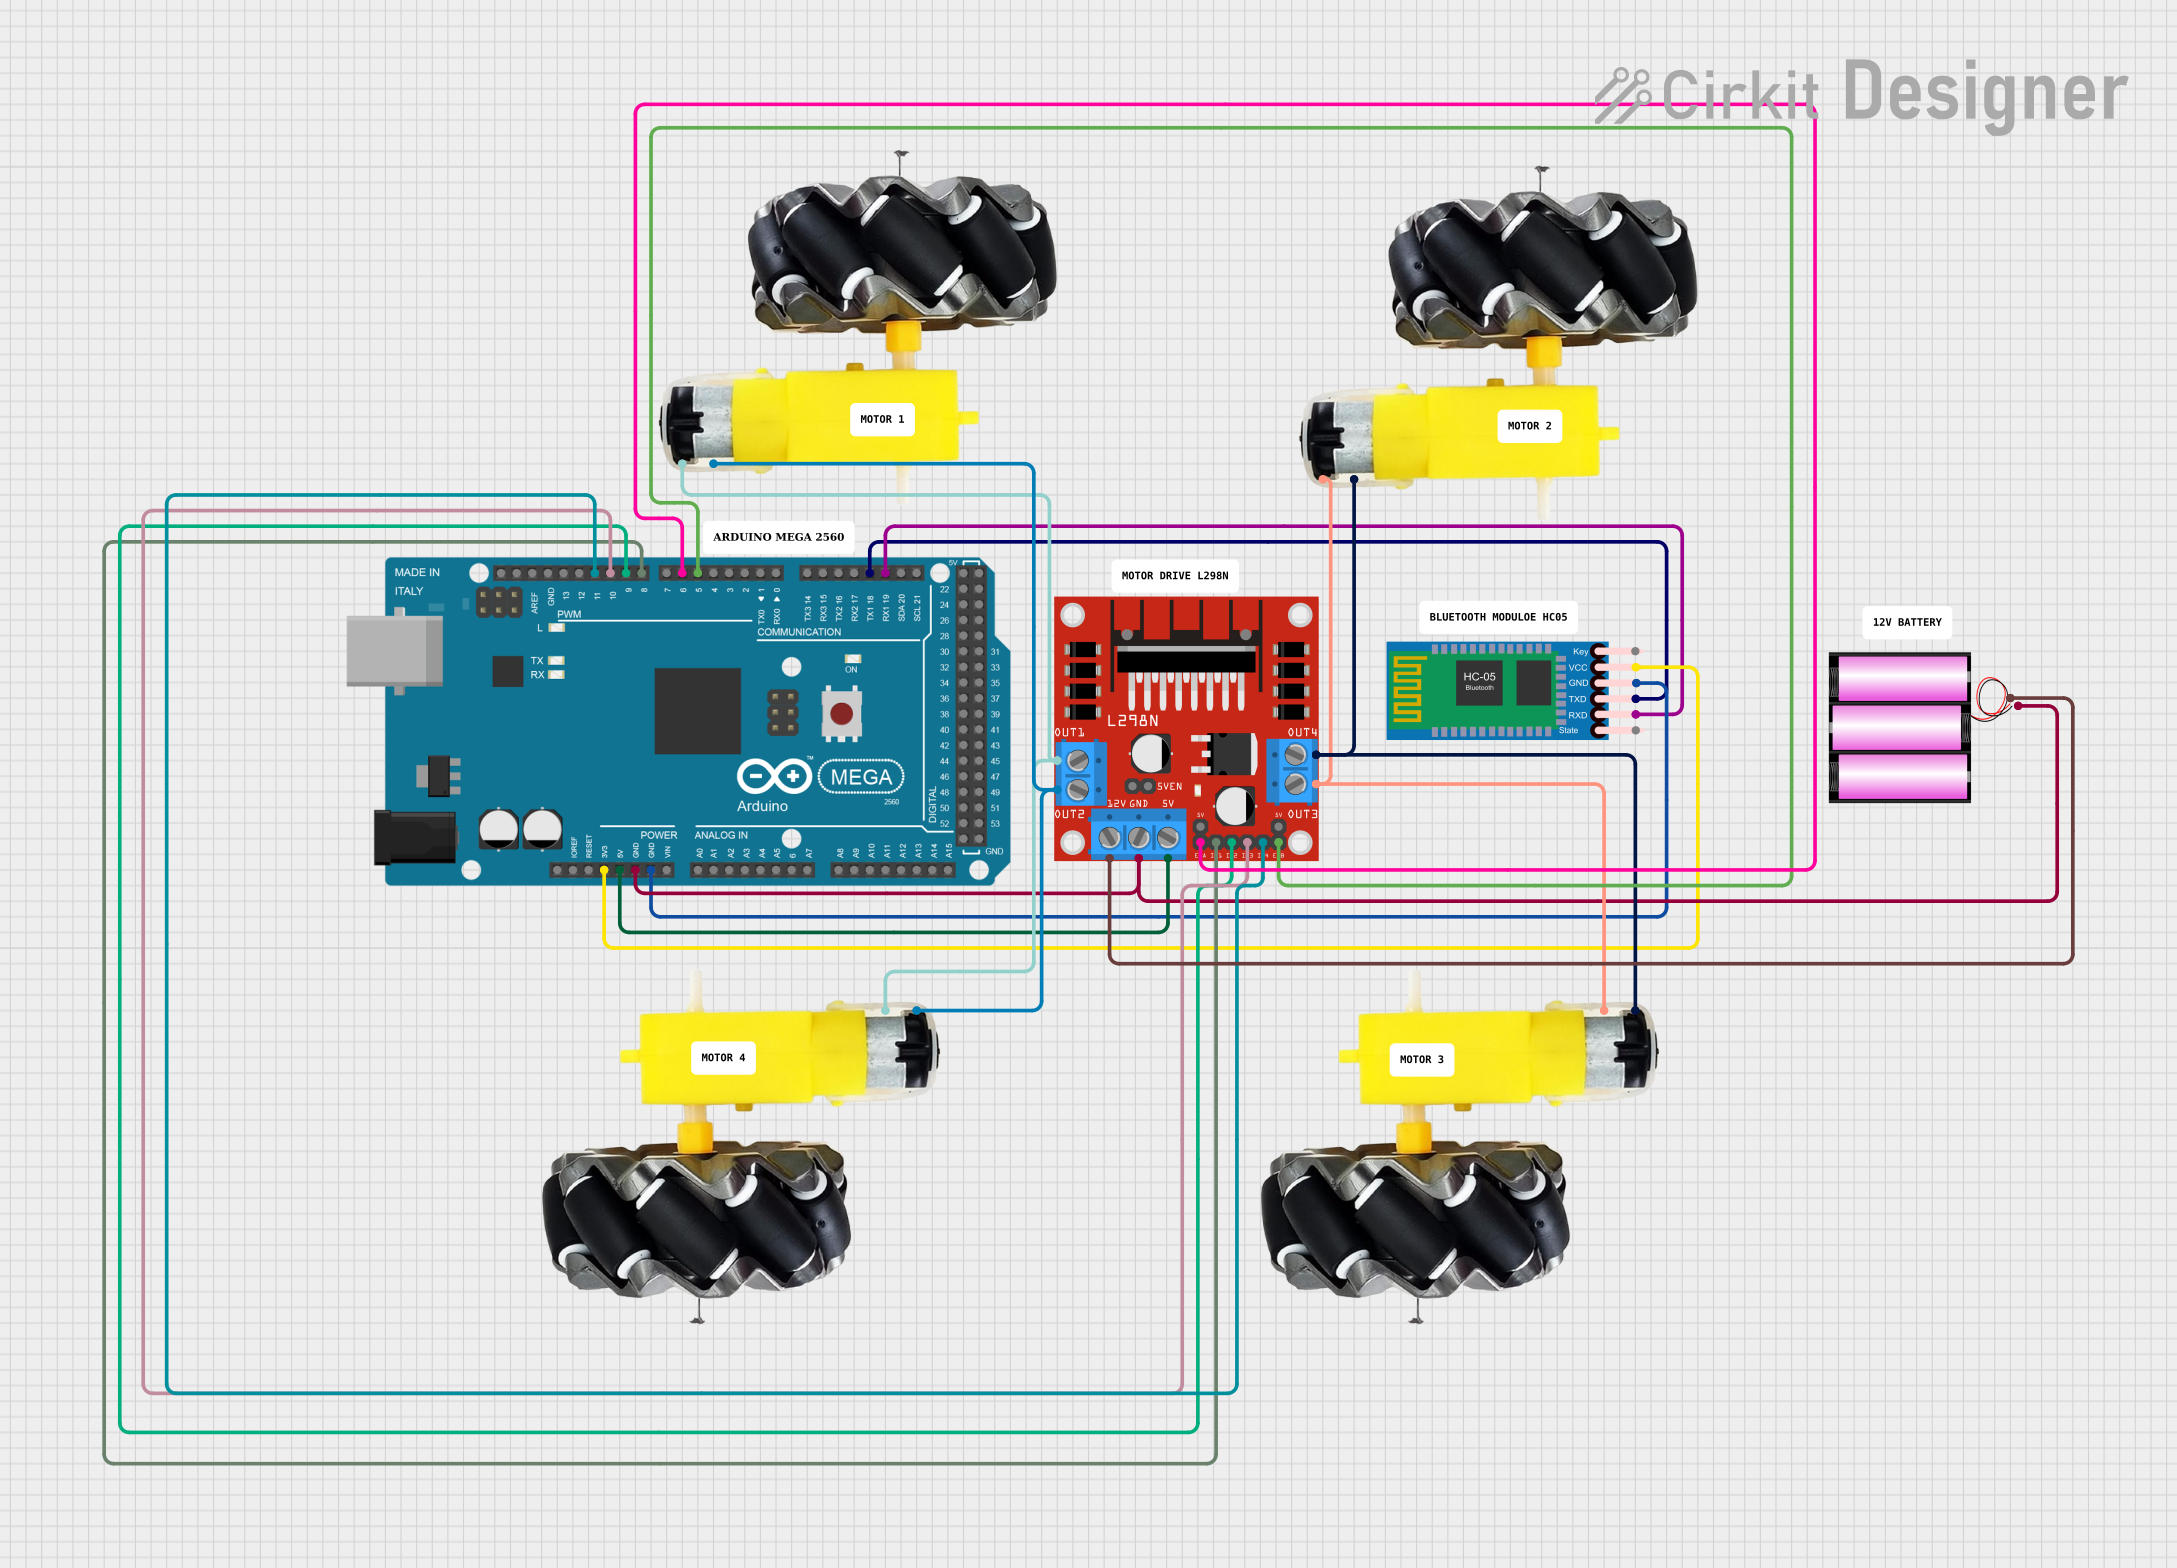
Circuit Documentation
Summary
This circuit is designed to control a set of motors using an Arduino Mega 2560 microcontroller, interfaced with an HC-05 Bluetooth module for wireless communication and an L298N DC motor driver to drive the motors. The circuit is powered by a 12V battery, and the motor driver module regulates the motor operations based on the signals from the Arduino.
Component List
HC-05 Bluetooth Module
- Description: A Bluetooth module for wireless communication.
- Pins: Key, VCC, TXD, RXD, State, GND
Motor and Wheels (x4)
- Description: Motors with attached wheels for movement.
- Pins: vcc, GND
Arduino Mega 2560
- Description: A microcontroller board based on the ATmega2560.
- Pins: IOREF, RESET, 3V3, 5V, GND, VIN, Analog Pins (A0-A15), Digital Pins (D0-D53), PWM Pins (D2-D13), Communication Pins (TX0/RX0, TX1/RX1, TX2/RX2, TX3/RX3, SCL, SDA), Power Pins (IOREF, RESET, 3V3, 5V, GND, VIN), SPI Pins (D50-D52), AREF
L298N DC Motor Driver
- Description: A module to drive DC motors.
- Pins: OUT1, OUT2, 12V, GND, 5V, OUT3, OUT4, 5V-ENA-JMP-I, 5V-ENA-JMP-O, +5V-J1, +5V-J2, ENA, IN1, IN2, IN3, IN4, ENB
Battery 12V
- Description: A 12V power source for the circuit.
- Pins: +, -
Comments
- Description: Comments are placeholders and do not have physical representations in the circuit.
Wiring Details
HC-05 Bluetooth Module
- VCC connected to Arduino Mega 2560 3V3
- GND connected to Arduino Mega 2560 GND
- TXD connected to Arduino Mega 2560 D18/TX1
- RXD connected to Arduino Mega 2560 D19/RX1
Arduino Mega 2560
- 5V connected to L298N DC motor driver 5V
- GND connected to L298N DC motor driver GND and Battery 12V -
- D5 PWM connected to L298N DC motor driver ENB
- D6 PWM connected to L298N DC motor driver ENA
- D8 PWM connected to L298N DC motor driver IN1
- D9 PWM connected to L298N DC motor driver IN2
- D10 PWM connected to L298N DC motor driver IN3
- D11 PWM connected to L298N DC motor driver IN4
L298N DC Motor Driver
- 12V connected to Battery 12V +
- OUT1 connected to Motor and Wheels (Instance 1) GND and Motor and Wheels (Instance 2) vcc
- OUT2 connected to Motor and Wheels (Instance 1) vcc and Motor and Wheels (Instance 2) GND
- OUT3 connected to Motor and Wheels (Instance 3) vcc and Motor and Wheels (Instance 4) GND
- OUT4 connected to Motor and Wheels (Instance 3) GND and Motor and Wheels (Instance 4) vcc
Motors and Wheels
- Each motor has one pin connected to a corresponding OUT pin on the L298N and the other to GND.
Documented Code
Arduino Mega 2560 Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Additional Documentation (documentation.txt)
No additional documentation provided.