
Raspberry Pi Pico Controlled Ultrasonic Distance Measurement
View and Edit Project In Cirkit Designer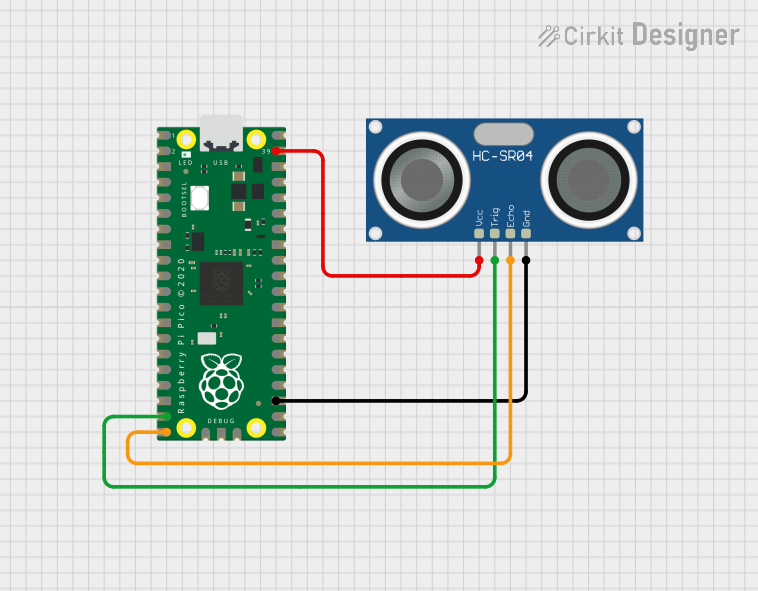
Circuit Documentation
Summary of the Circuit
This circuit integrates a Raspberry Pi Pico microcontroller with an HC-SR04 Ultrasonic Sensor. The Raspberry Pi Pico is responsible for controlling the sensor and processing the data it provides. The HC-SR04 sensor is used to measure distances by emitting ultrasonic waves and detecting their reflection from objects.
Component List
Raspberry Pi Pico
- Description: A microcontroller board based on the RP2040 microcontroller chip.
- Purpose: Acts as the central processing unit of the circuit, controlling the ultrasonic sensor and handling data processing.
- Pins: 43 GPIO pins, including digital I/O, power, and ground pins.
HC-SR04 Ultrasonic Sensor
- Description: An ultrasonic ranging module that provides 2cm to 400cm non-contact measurement functionality.
- Purpose: Measures the distance to an object by emitting ultrasonic waves and detecting their reflection.
- Pins: VCC, TRIG, ECHO, GND.
Wiring Details
Raspberry Pi Pico
- TRIG: Connected to pin 19 of the Raspberry Pi Pico.
- ECHO: Connected to pin 20 of the Raspberry Pi Pico.
- GND: Connected to pin 23 of the Raspberry Pi Pico.
- VCC: Connected to pin 39 of the Raspberry Pi Pico.
HC-SR04 Ultrasonic Sensor
- VCC: Receives power from pin 39 of the Raspberry Pi Pico.
- TRIG: Sends trigger signal to pin 19 of the Raspberry Pi Pico.
- ECHO: Sends echo signal to pin 20 of the Raspberry Pi Pico.
- GND: Connected to the ground pin 23 of the Raspberry Pi Pico.
Documented Code
The following code is intended for the Raspberry Pi Pico microcontroller to interface with the HC-SR04 Ultrasonic Sensor. The code is written in C/C++ and is designed to be compiled and uploaded using an Arduino-like environment.
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
File Name: sketch.ino
This code template provides the basic structure for initializing the microcontroller and contains two primary functions: setup() and loop(). The setup() function is called once when the microcontroller is powered on or reset. It is used to initialize the pins and set up the sensor. The loop() function is called repeatedly and contains the main logic for triggering the ultrasonic sensor and reading the distance measurements.
Additional code should be added to the setup() function to configure the TRIG and ECHO pins as output and input, respectively. In the loop() function, code should be added to trigger the ultrasonic pulse, measure the time taken for the echo to return, and calculate the distance based on the speed of sound.
Note: The actual implementation code for the HC-SR04 sensor is not provided and should be implemented according to the specific requirements of the application.