
Arduino Nano Controlled Bluetooth Robotic Vehicle with MPU-6050 Gyroscope
View and Edit Project In Cirkit Designer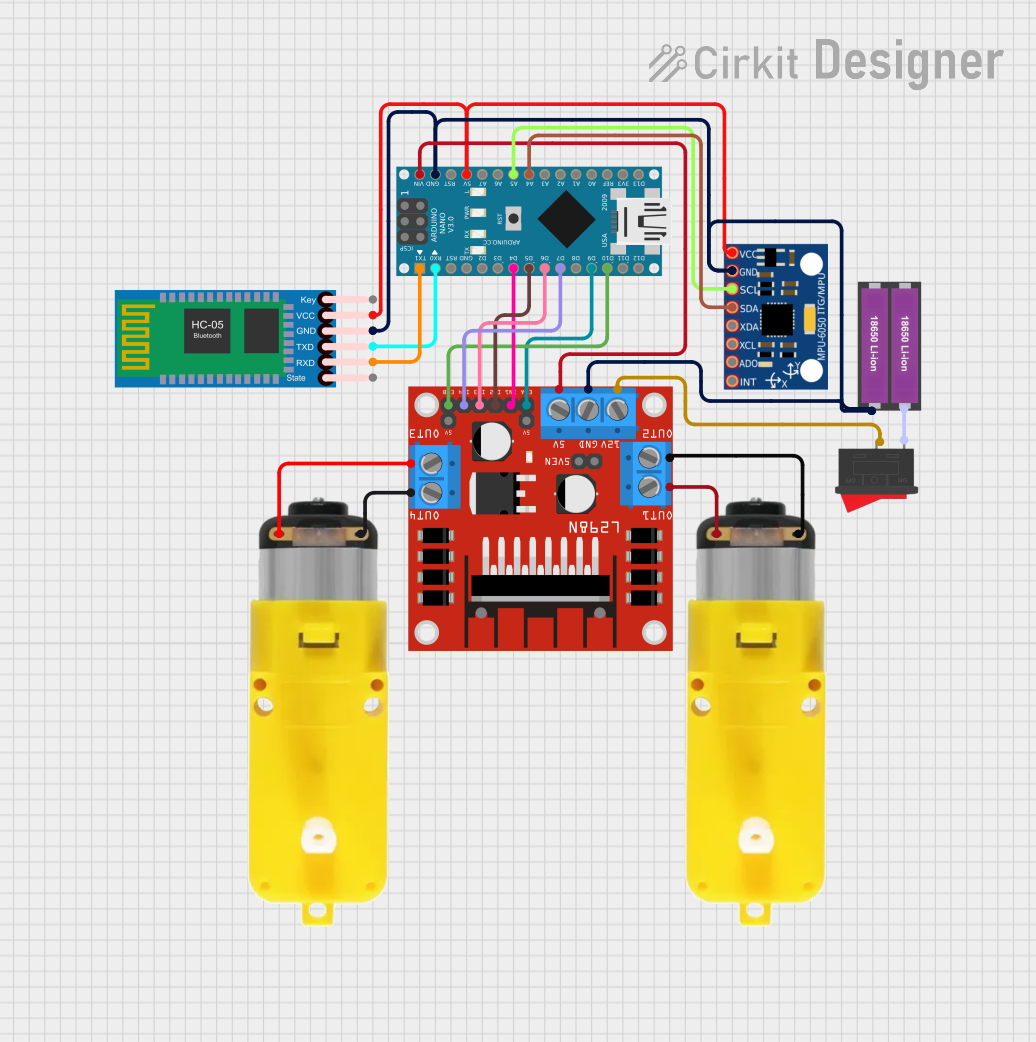
Circuit Documentation
Summary
This circuit is designed to control two DC motors with reducers using an Arduino Nano as the main microcontroller. The Arduino Nano interfaces with an L298N DC motor driver to manage the motor's direction and speed. Communication with the Arduino Nano is facilitated through an HC-05 Bluetooth module, allowing for wireless control. An MPU-6050 sensor is included for motion tracking, providing gyroscopic and accelerometer data to the Arduino. The circuit is powered by two 18650 Li-ion batteries, and a rocker switch is used to control the power supply to the circuit.
Component List
Arduino Nano
- Microcontroller board based on the ATmega328P
- Offers a variety of digital and analog I/O pins
- Capable of serial communication via UART
L298N DC Motor Driver
- Dual H-bridge motor driver
- Capable of driving two DC motors or one stepper motor
- Provides motor direction and speed control
HC-05 Bluetooth Module
- Bluetooth to serial communication module
- Allows for wireless communication with the Arduino Nano
MPU-6050
- Motion tracking device with a 3-axis gyroscope and a 3-axis accelerometer
- Uses I2C for communication with the Arduino Nano
Motor with Reducer (x2)
- DC motor with a gear reduction mechanism
- Operates within the voltage range of 3 - 6 V
18650 Li-ion Battery x 2
- Rechargeable lithium-ion battery cells
- Provides power to the circuit
Rocker Switch
- Simple on/off switch
- Controls the power supply from the batteries to the circuit
Wiring Details
Arduino Nano
D1/TXconnected to HC-05 Bluetooth ModuleRXDD0/RXconnected to HC-05 Bluetooth ModuleTXDD4toD7connected to L298N DC motor driverIN1toIN4D9,D10connected to L298N DC motor driverENA,ENBVINconnected to L298N DC motor driver5VGNDconnected to common ground5Vconnected to MPU-6050VCCand HC-05 Bluetooth ModuleVCCA4,A5connected to MPU-6050SDA,SCL
L298N DC Motor Driver
OUT1,OUT2connected to one Motor with reducerOUT3,OUT4connected to the other Motor with reducer12Vconnected to Rocker Switch2GNDconnected to common ground
HC-05 Bluetooth Module
VCCconnected to Arduino Nano5VGNDconnected to common groundTXDconnected to Arduino NanoD0/RXRXDconnected to Arduino NanoD1/TX
MPU-6050
VCCconnected to Arduino Nano5VGNDconnected to common groundSCLconnected to Arduino NanoA5SDAconnected to Arduino NanoA4
Motor with Reducer
3 - 6 VCCconnected to L298N DC motor driverOUT1orOUT3GNDconnected to L298N DC motor driverOUT2orOUT4
18650 Li-ion Battery x 2
+connected to Rocker Switch1-connected to common ground
Rocker Switch
1connected to 18650 Li-ion Battery x 2+2connected to L298N DC motor driver12V
Documented Code
Arduino Nano - sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Arduino Nano - documentation.txt
(No additional documentation provided for the code)
This concludes the documentation for the given circuit. The circuit is designed for controlling motors and receiving sensor data, with the capability of wireless communication through Bluetooth. The code provided is a template and should be expanded to include the logic for motor control, Bluetooth communication handling, and MPU-6050 data processing.