
Arduino UNO Controlled GPS and pH Monitoring System with Dual Thruster Management
View and Edit Project In Cirkit Designer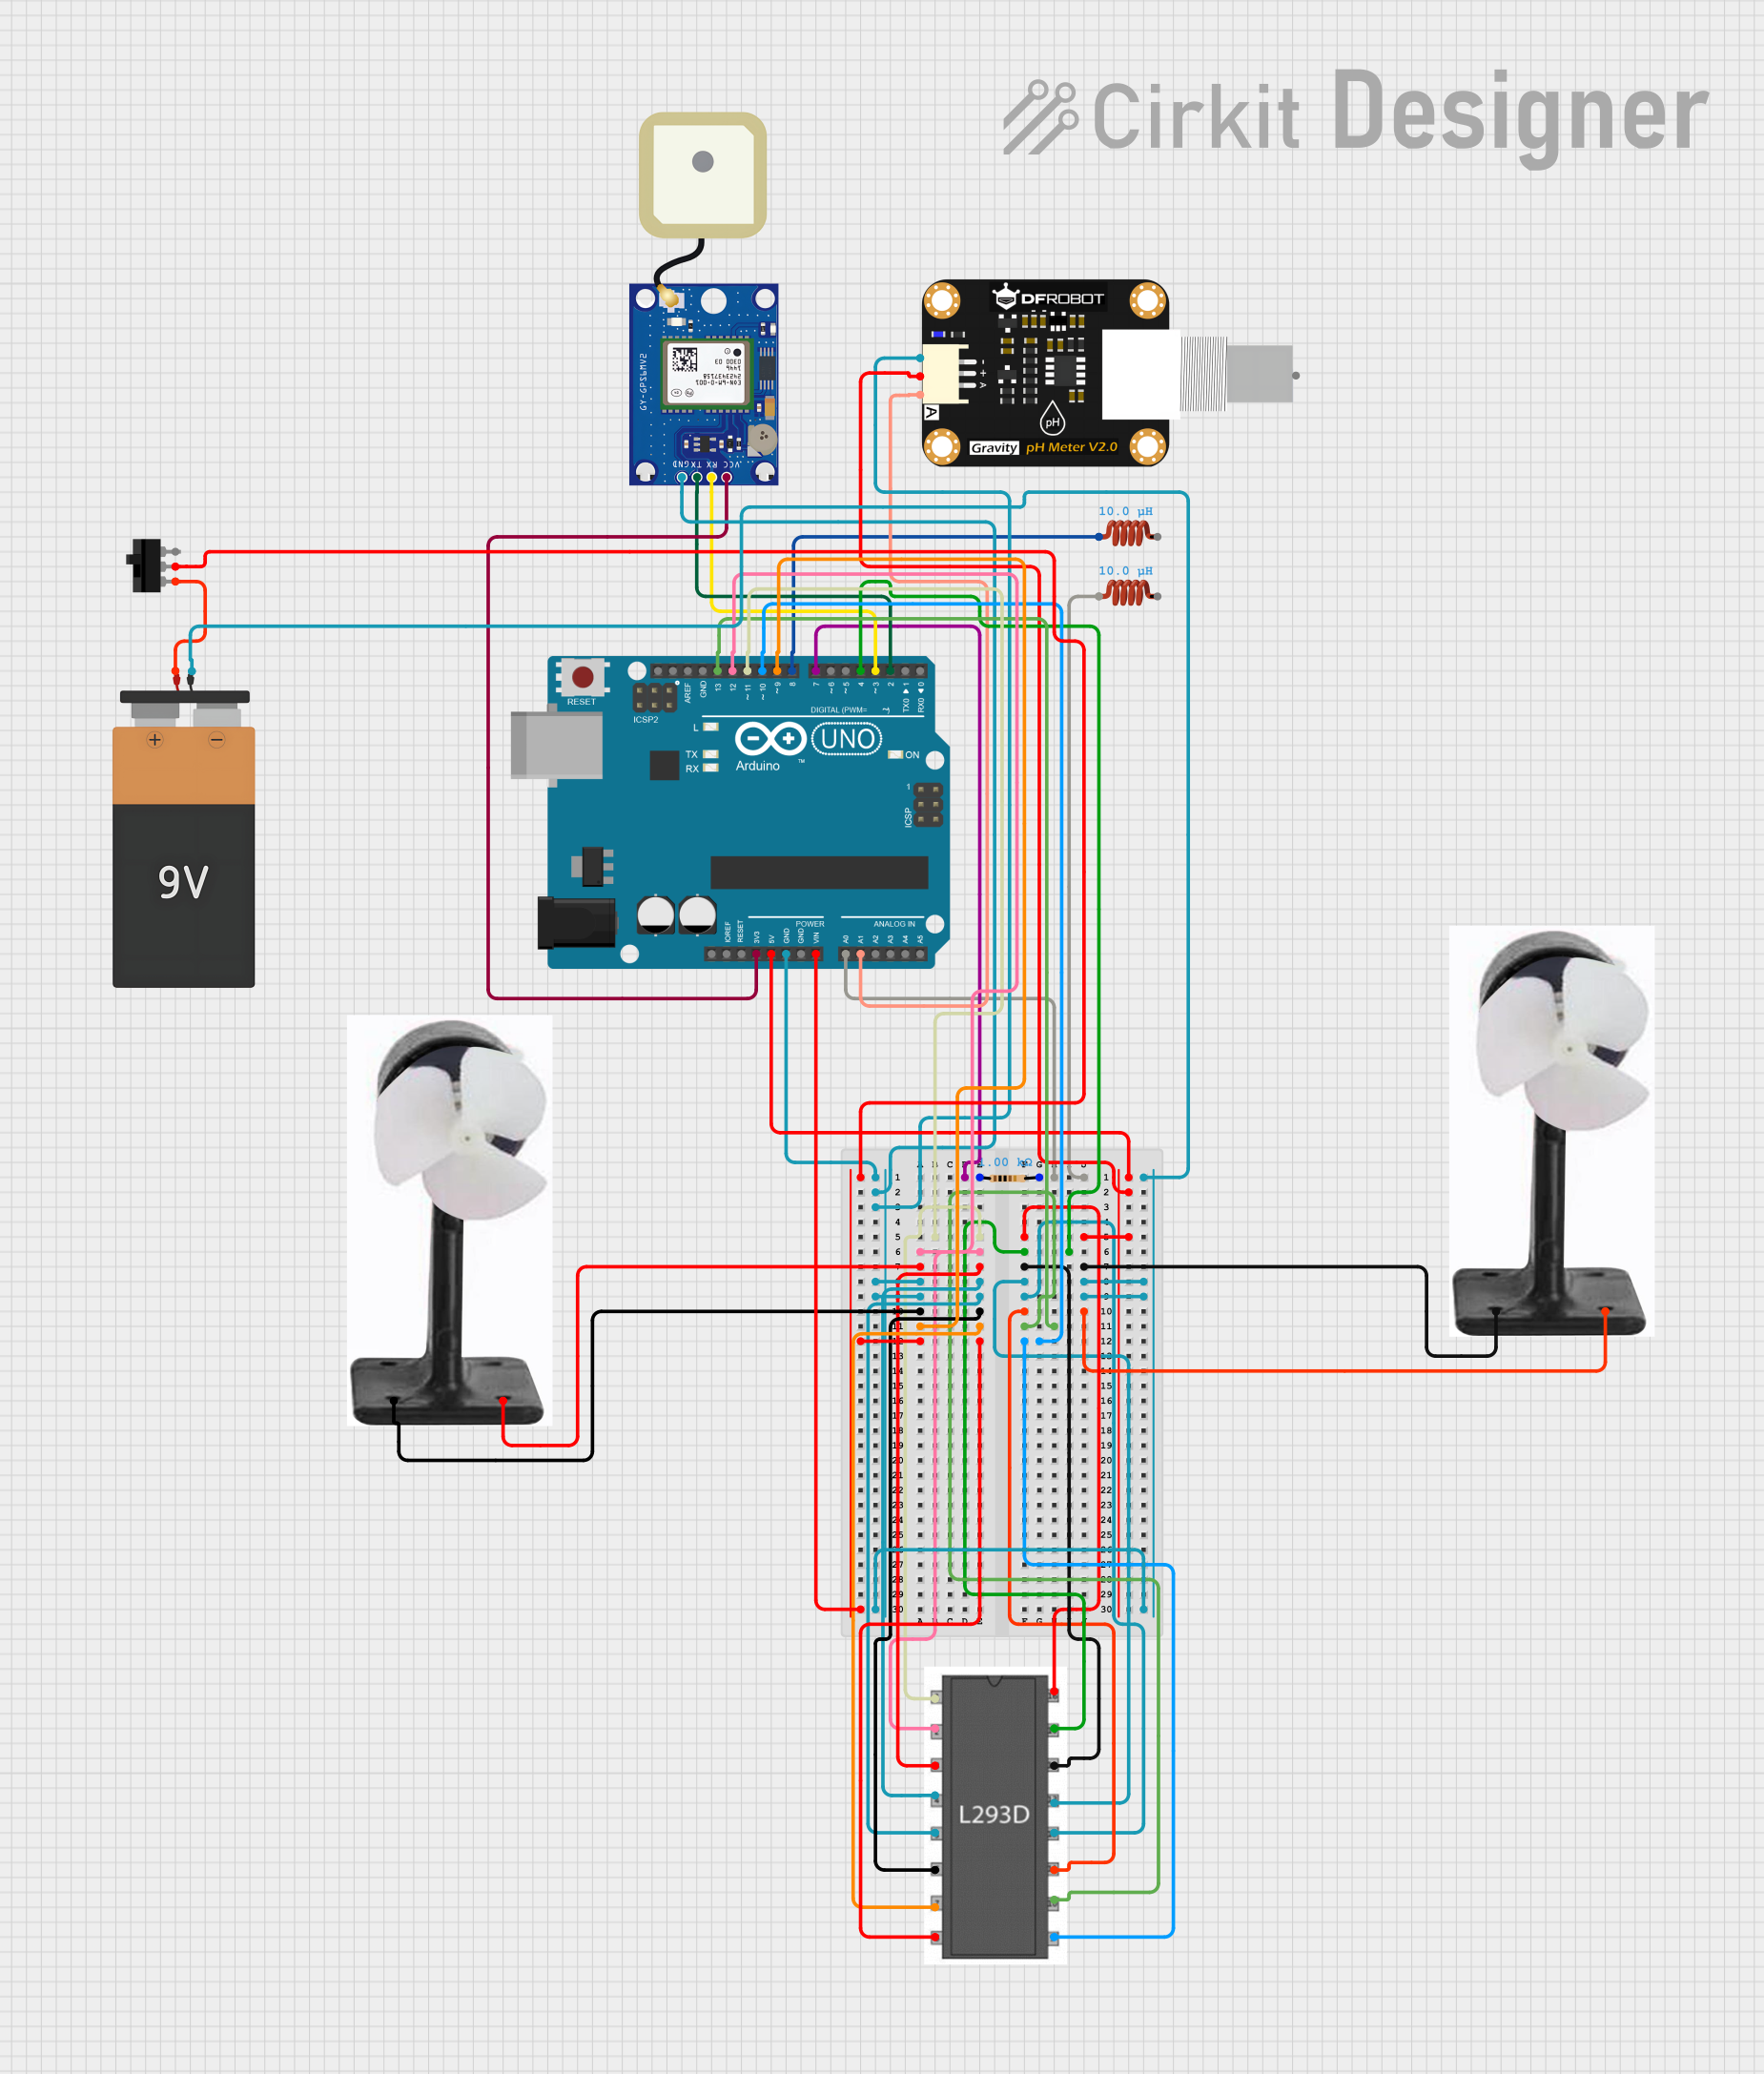
Circuit Documentation
Summary
This circuit integrates various components including an Arduino UNO, GPS module, pH sensor module, inductors, resistors, a motor driver (l293d), RC boat underwater thrusters, a battery, and a toggle switch. The Arduino UNO serves as the central microcontroller, interfacing with the GPS module for location tracking and the pH sensor for environmental data. The l293d motor driver controls the thrusters, which are powered by a 9V battery through a toggle switch. The circuit is designed to possibly function as a remotely operated vehicle (ROV) with environmental sensing capabilities.
Component List
- Arduino UNO: A microcontroller board based on the ATmega328P, featuring digital and analog I/O pins.
- Inductor: A passive component that stores energy in its magnetic field with an inductance value of 10 µH.
- Resistor: A passive component that provides electrical resistance of 1 kΩ.
- GPS NEO-6M V2: A GPS module that provides location data.
- Modulo Sensor PH: A pH sensor module for measuring the acidity or alkalinity of a solution.
- RC Boat Underwater Thruster: A propulsion device designed for underwater vehicles.
- l293d: A motor driver IC capable of driving inductive loads such as relays, solenoids, and motors.
- Battery 9V: A power source for the circuit.
- Toggle Switch: A switch that can control the connection of the circuit to the battery.
Wiring Details
Arduino UNO
3.3Vconnected to GPS NEO-6M V2VCC5Vconnected to Modulo Sensor PH+and l293dVcc1GNDconnected to GPS NEO-6M V2GND, Modulo Sensor PH-, l293dGND, and Battery 9VGNDVinconnected to Toggle SwitchCOMand l293dVcc2A0connected to one side of the ResistorA1connected to Modulo Sensor PHAD13connected to l293dInput 3D12connected to l293dInput 1D11connected to l293dEnable 1,2D10connected to l293dEnable 3,4D9connected to l293dInput 2D8connected to one side of an InductorD7connected to the other side of the ResistorD4connected to l293dInput 4D3connected to GPS NEO-6M V2RXD2connected to GPS NEO-6M V2TX
Inductors
- Two inductors with one side connected to Arduino UNO
D8andA0respectively.
Resistor
- Connected between Arduino UNO
A0andD7.
GPS NEO-6M V2
VCCconnected to Arduino UNO3.3VRXconnected to Arduino UNOD3TXconnected to Arduino UNOD2GNDconnected to Arduino UNOGND
Modulo Sensor PH
+connected to Arduino UNO5VAconnected to Arduino UNOA1-connected to Arduino UNOGND
RC Boat Underwater Thrusters
- Two thrusters with one terminal connected to l293d
Output 1andOutput 3, and the other terminal toOutput 2andOutput 4respectively.
l293d
Enable 1,2andEnable 3,4connected to Arduino UNOD11andD10respectively.Input 1,Input 2,Input 3, andInput 4connected to Arduino UNOD12,D9,D13, andD4respectively.Output 1,Output 2,Output 3, andOutput 4connected to the respective terminals of the RC Boat Underwater Thrusters.Vcc1connected to Arduino UNO5VVcc2connected to Arduino UNOVinGNDconnected to Arduino UNOGND
Battery 9V
VCCconnected to Toggle SwitchL1GNDconnected to Arduino UNOGND
Toggle Switch
COMconnected to Arduino UNOVinL1connected to Battery 9VVCC
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code is a template and does not include specific functionality. It needs to be populated with the logic to control the motor driver, read sensor data, and handle GPS communication.