
Arduino-Controlled Firefighting Robot with Ultrasonic Obstacle Detection and Bluetooth Interface
View and Edit Project In Cirkit Designer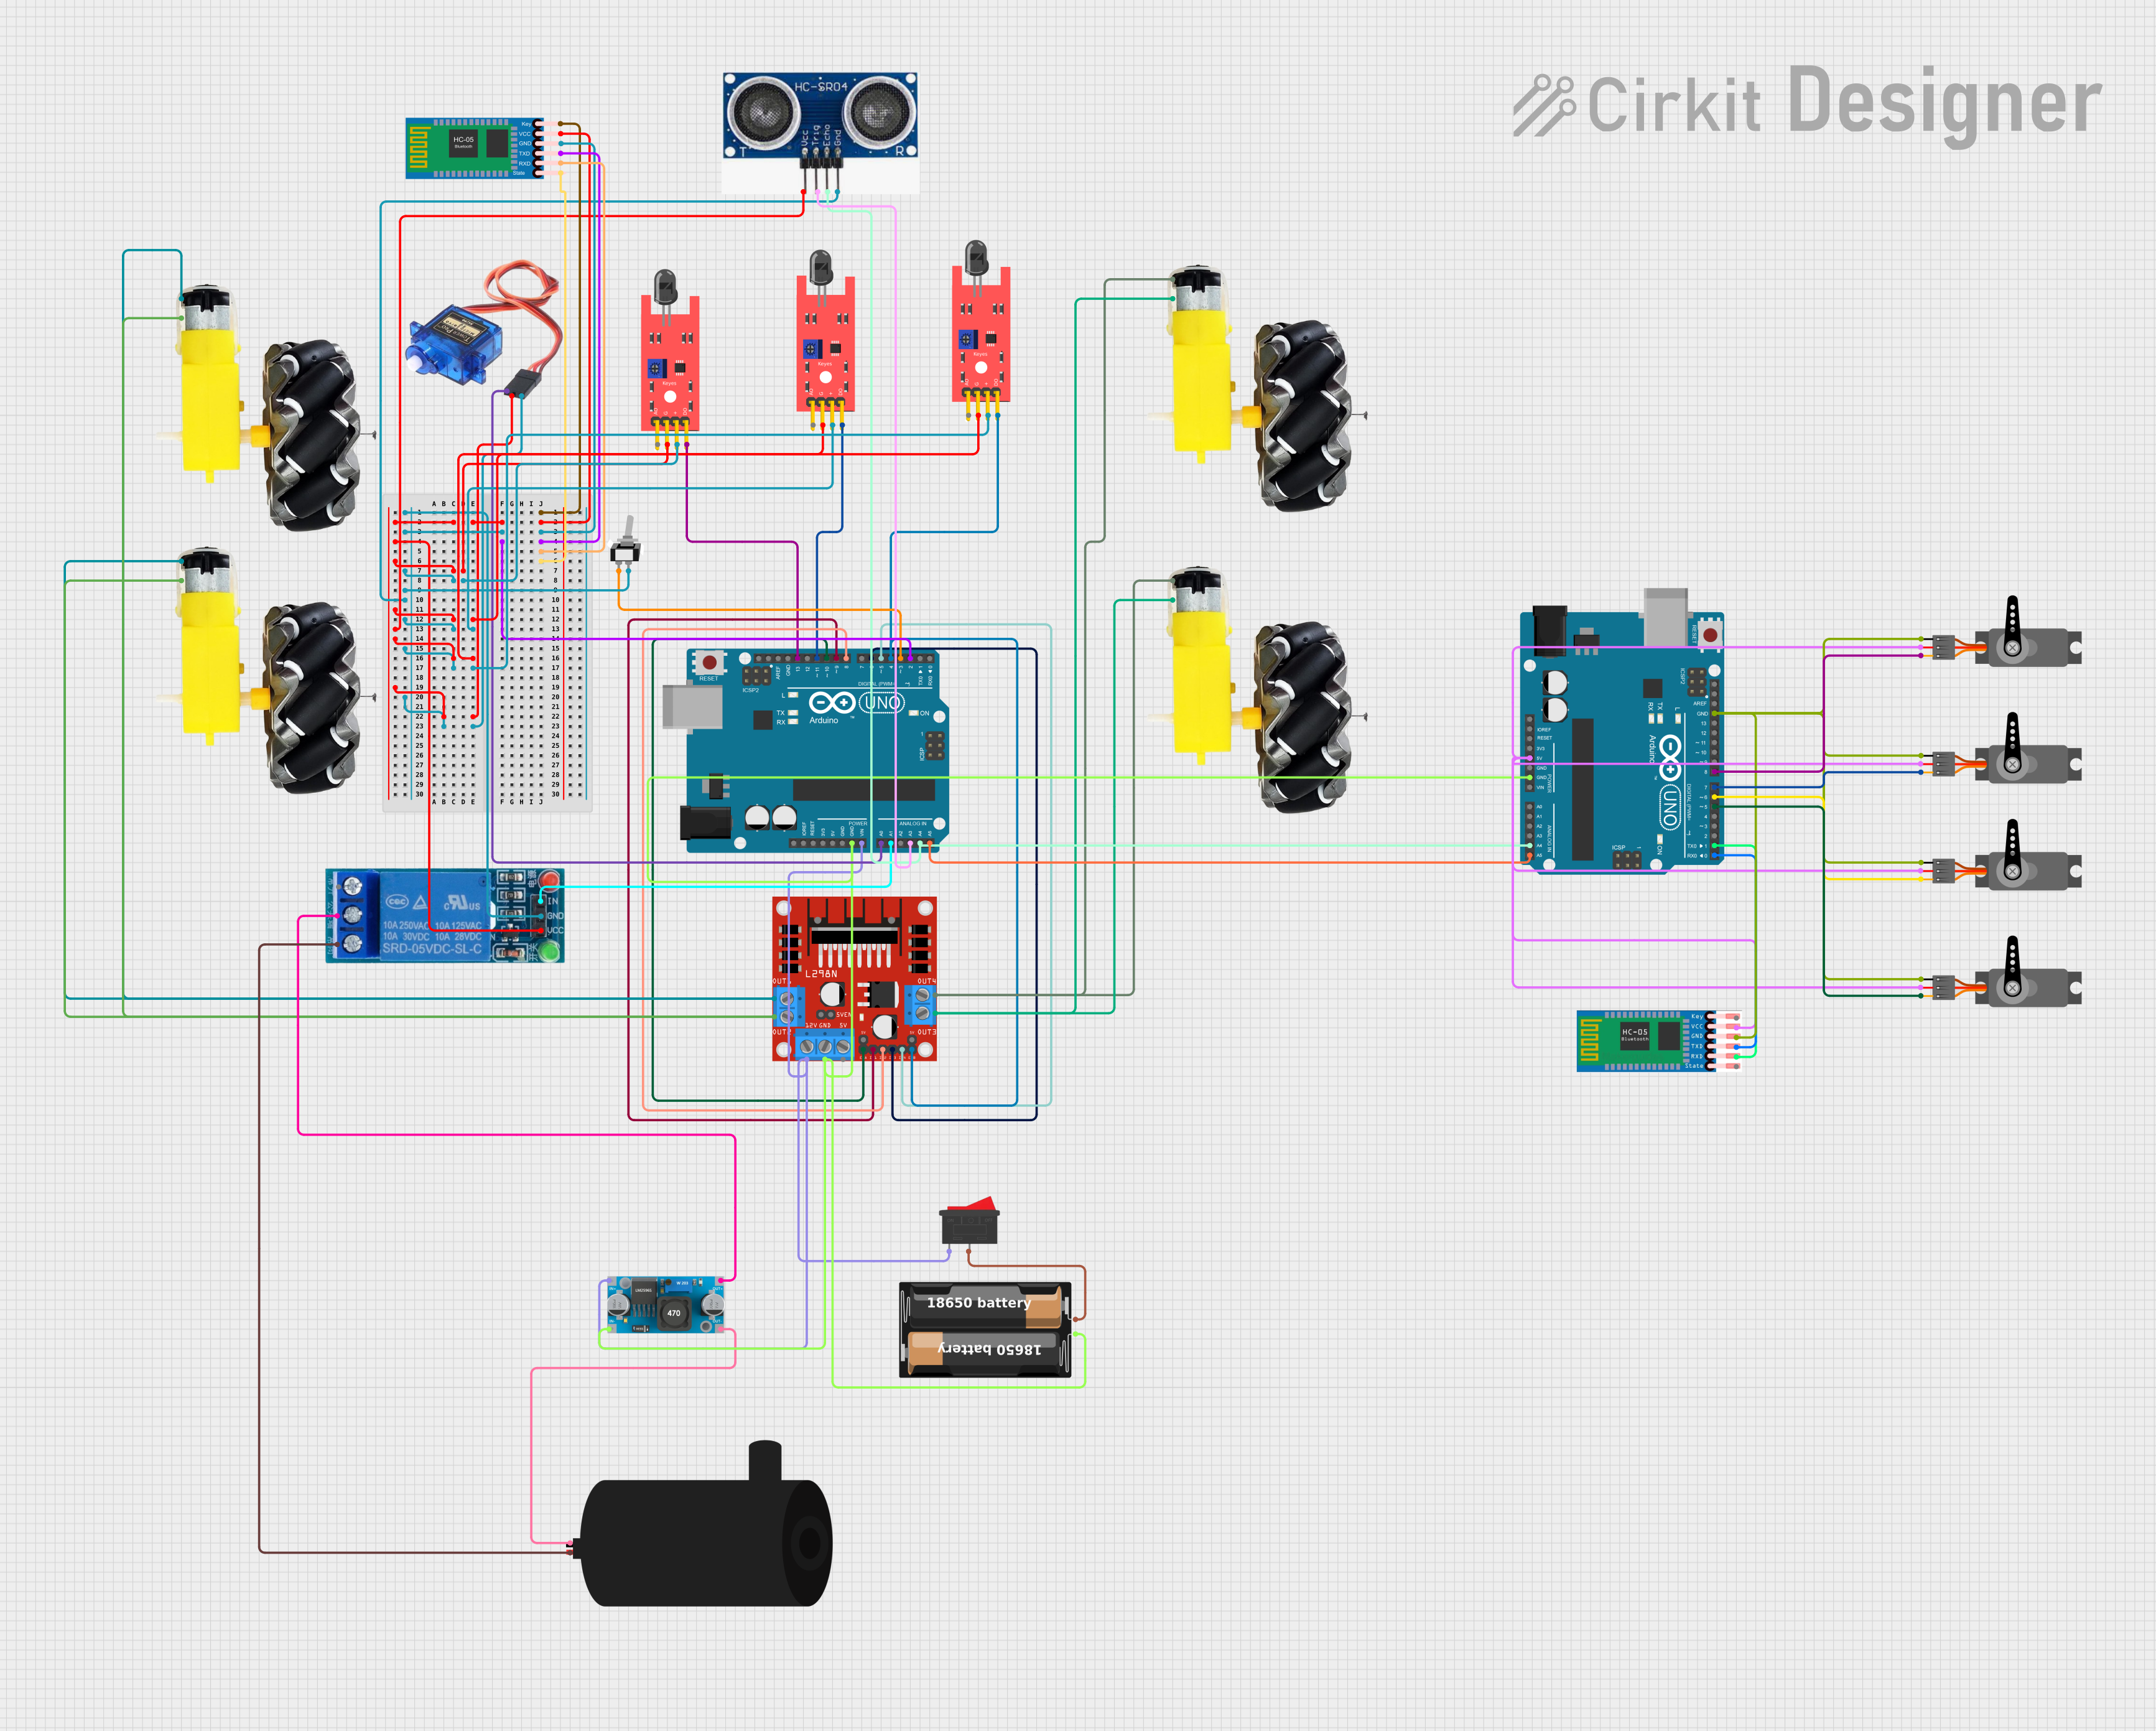
Circuit Documentation
Summary
The circuit in question appears to be a robotic system equipped with various sensors, actuators, and control modules. It includes flame sensors for fire detection, an ultrasonic sensor for distance measurement, motors for movement, a water pump for extinguishing fires, and an Arduino UNO microcontroller for processing and control. The system also features a Bluetooth module for wireless communication, a motor driver for controlling the motors, a relay for switching the water pump, and power management components such as a battery case and a buck converter. The robot is designed to navigate, detect flames, and take action to extinguish fires, with the capability to be controlled remotely via Bluetooth.
Component List
Sensors
- KY-026 Flame Sensor: Detects the presence of a flame or fire.
- Ultrasonic Sensor: Measures distance to objects by emitting ultrasonic waves.
Actuators
- Motor and Wheels: Provides mobility to the robot.
- Water Pump: Used to pump water for extinguishing fires.
- Servo Motor: Precision rotary actuator used for positioning.
Control Modules
- Arduino UNO: The main microcontroller board for processing and control logic.
- HC-05 Bluetooth Module: Enables wireless communication for remote control.
- L298N DC Motor Driver: Controls the direction and speed of the motors.
- Relay 5V Single Connection: Electrically operated switch for controlling the water pump.
Power Management
- My Battery Case: Holds batteries to power the circuit.
- LM2596 Buck Converter: Steps down voltage to a lower level.
Switches
- Rocker Switch: A simple on/off switch.
- Toggle Switch SPST: Single Pole Single Throw switch for controlling circuit connectivity.
Wiring Details
KY-026 Flame Sensor
- A0: Analog output connected to the Arduino for flame intensity.
- GND: Ground connection.
- VCC: Power supply input.
- D0: Digital output connected to the Arduino for flame detection.
Ultrasonic Sensor
- Vcc: Power supply input.
- Trigger: Trigger pin connected to the Arduino for sending ultrasonic pulses.
- Echo: Echo pin connected to the Arduino for receiving the reflected pulses.
- Gnd: Ground connection.
Motor and Wheels
- vcc: Power supply input for the motor.
- GND: Ground connection for the motor.
Water Pump
- Positive: Positive power supply input.
- Negative: Ground connection.
Servo Motor
- Ground: Ground connection.
- Power: Power supply input.
- Signal: Control signal input from the Arduino.
Arduino UNO
- Digital and Analog Pins: Various I/O pins used for interfacing with sensors, actuators, and communication modules.
- 5V and GND: Power supply and ground connections for the board and connected components.
- Vin: Voltage input from the power source.
HC-05 Bluetooth Module
- Key: Used to enter AT command mode.
- VCC: Power supply input.
- TXD: Transmit pin connected to the Arduino's receive pin.
- RXD: Receive pin connected to the Arduino's transmit pin.
- State: Indicates the connection status.
- GND: Ground connection.
L298N DC Motor Driver
- OUT1, OUT2, OUT3, OUT4: Outputs to the motors.
- 12V: Power supply input for the motors.
- GND: Ground connection.
- 5V: Power supply input for the logic circuit.
- ENA, ENB: Enable pins for controlling motor speed.
- IN1, IN2, IN3, IN4: Input pins for controlling motor direction.
Relay 5V Single Connection
- VCC: Power supply input.
- GND: Ground connection.
- IN: Input signal from the Arduino to control the relay.
- NO, COMM, NC: Normally open, common, and normally closed contacts for switching.
LM2596 Buck Converter
- IN +, IN -: Voltage input.
- OUT +, OUT -: Voltage output.
Rocker Switch
- 1, 2: Pins for switching the circuit on and off.
Toggle Switch SPST
- L1, COM: Pins for controlling circuit connectivity.
Documented Code
Arduino UNO (Main Controller)
#include <Wire.h>
#include <Servo.h>
#include <Adafruit_MLX90614.h>
#include <SoftwareSerial.h>

// Define Ultrasonic Sensor Pins
#define TRIG_PIN A3
#define ECHO_PIN A2

Adafruit_MLX90614 mlx = Adafruit_MLX90614();

// Define pins for flame sensors
#define FLAME_SENSOR_LEFT 4
#define FLAME_SENSOR_RIGHT 13
#define FLAME_SENSOR_FRONT 11

#define LM1 6  // Left motor forward
#define LM2 7  // Left motor backward
#define RM1 8  // Right motor forward
#define RM2 9  // Right motor backward
#define PUMP_PIN A1 // Water pump

#define enA 5  // Enable pin for left motor
#define enB 10 // Enable pin for right motor

#define BUZZER_PIN 3  // Buzzer pin

#define BLUETOOTH_RX 12
#define BLUETOOTH_TX 2

// Distance threshold to stop the robot (in cm)
#define DISTANCE_THRESHOLD 20

// Create SoftwareSerial object for Bluetooth communication
SoftwareSerial bluetooth(BLUETOOTH_TX, BLUETOOTH_RX);

void setup() {
  // Initialize serial communication for Bluetooth
  bluetooth.begin(9600);
  Serial.begin(9600);

  // Motor pins setup
  pinMode(LM1, OUTPUT);
  pinMode(LM2, OUTPUT);
  pinMode(RM1, OUTPUT);
  pinMode(RM2, OUTPUT);

  // Sensors and actuators setup
  pinMode(FLAME_SENSOR_LEFT, INPUT);
  pinMode(FLAME_SENSOR_RIGHT, INPUT);
  pinMode(FLAME_SENSOR_FRONT, INPUT);
  pinMode(BUZZER_PIN, OUTPUT);
  pinMode(PUMP_PIN, OUTPUT);

  // Ultrasonic sensor setup
  pinMode(TRIG_PIN, OUTPUT);
  pinMode(ECHO_PIN, INPUT);

  // Initialize actuators to be off
  digitalWrite(BUZZER_PIN, LOW);
  digitalWrite(PUMP_PIN, LOW);

  // Initialize MLX90614 sensor
  mlx.begin();
}

void loop() {
  // Read flame sensor values (digital)
  bool leftFlame = digitalRead(FLAME_SENSOR_LEFT);
  bool rightFlame = digitalRead(FLAME_SENSOR_RIGHT);
  bool frontFlame = digitalRead(FLAME_SENSOR_FRONT);

  // Measure distance using the ultrasonic sensor
  long distance = measureDistance();  // This will also print the distance to the Serial Monitor

  // Robot movement logic
  if (distance <= DISTANCE_THRESHOLD) {  // Obstacle detected within threshold
    stopRobot();
    if (!frontFlame) {  // Flame detected in front after stopping
      extinguishFire();
    }
  } else if (!frontFlame) {  // Flame detected in front
    moveForward();
  } else if (!leftFlame) {  // Flame detected on the left
    moveRight();
  } else if (!rightFlame) {  // Flame detected on the right
    moveLeft();
  } else {  // No flame detected
    stopRobot();
  }

  // Bluetooth control
  if (bluetooth.available()) {
    char command = bluetooth.read();
    controlRobotViaBluetooth(command);
  }
}

void moveForward() {
  Serial.println("Moving Forward");
  analogWrite(enA, 120); // Write The Duty Cycle 0 to 255 Enable Pin A for Motor1 Speed
  analogWrite(enB, 120);
  digitalWrite(LM1, LOW);
  digitalWrite(LM2, HIGH);
  digitalWrite(RM1, LOW);
  digitalWrite(RM2, HIGH);
}

void moveLeft() {
  Serial.println("Turning Left");
  analogWrite(enA, 200); // Write The Duty Cycle 0 to 255 Enable Pin A for Motor1 Speed
  analogWrite(enB, 200);
  digitalWrite(LM1, LOW); // Left Motor backward Pin
  digitalWrite(LM2, LOW); // Left Motor forward Pin
  digitalWrite(RM1, LOW); // Right Motor forward Pin
  digitalWrite(RM2, HIGH); // Right Motor backward Pin
}

void moveRight() {
  Serial.println("Turning Right");
  analogWrite(enA, 200); // Reduce speed for turning
  analogWrite(enB, 200);
  digitalWrite(LM1, LOW); // Left Motor backward Pin
  digitalWrite(LM2, HIGH); // Left Motor forward Pin
  digitalWrite(RM1, LOW); // Right Motor forward Pin
  digitalWrite(RM2, LOW); // Right Motor backward Pin
}

void stopRobot() {
  Serial.println("Stopping Robot");
  digitalWrite(LM1, LOW);
  digitalWrite(LM2, LOW);
  digitalWrite(RM1, LOW);
  digitalWrite(RM2, LOW);
}

void extinguishFire() {
  Serial.println("Extinguishing Fire");
  // Activate buzzer and pump for fire extinguishing
  digitalWrite(BUZZER_PIN, HIGH);
  digitalWrite(PUMP_PIN, HIGH);

  // Run pump for a certain period (adjust time as needed)
  delay(5000