
Arduino UNO Based Quadcopter Control System with GPS, MPU6050, and Ultrasonic Sensor
View and Edit Project In Cirkit Designer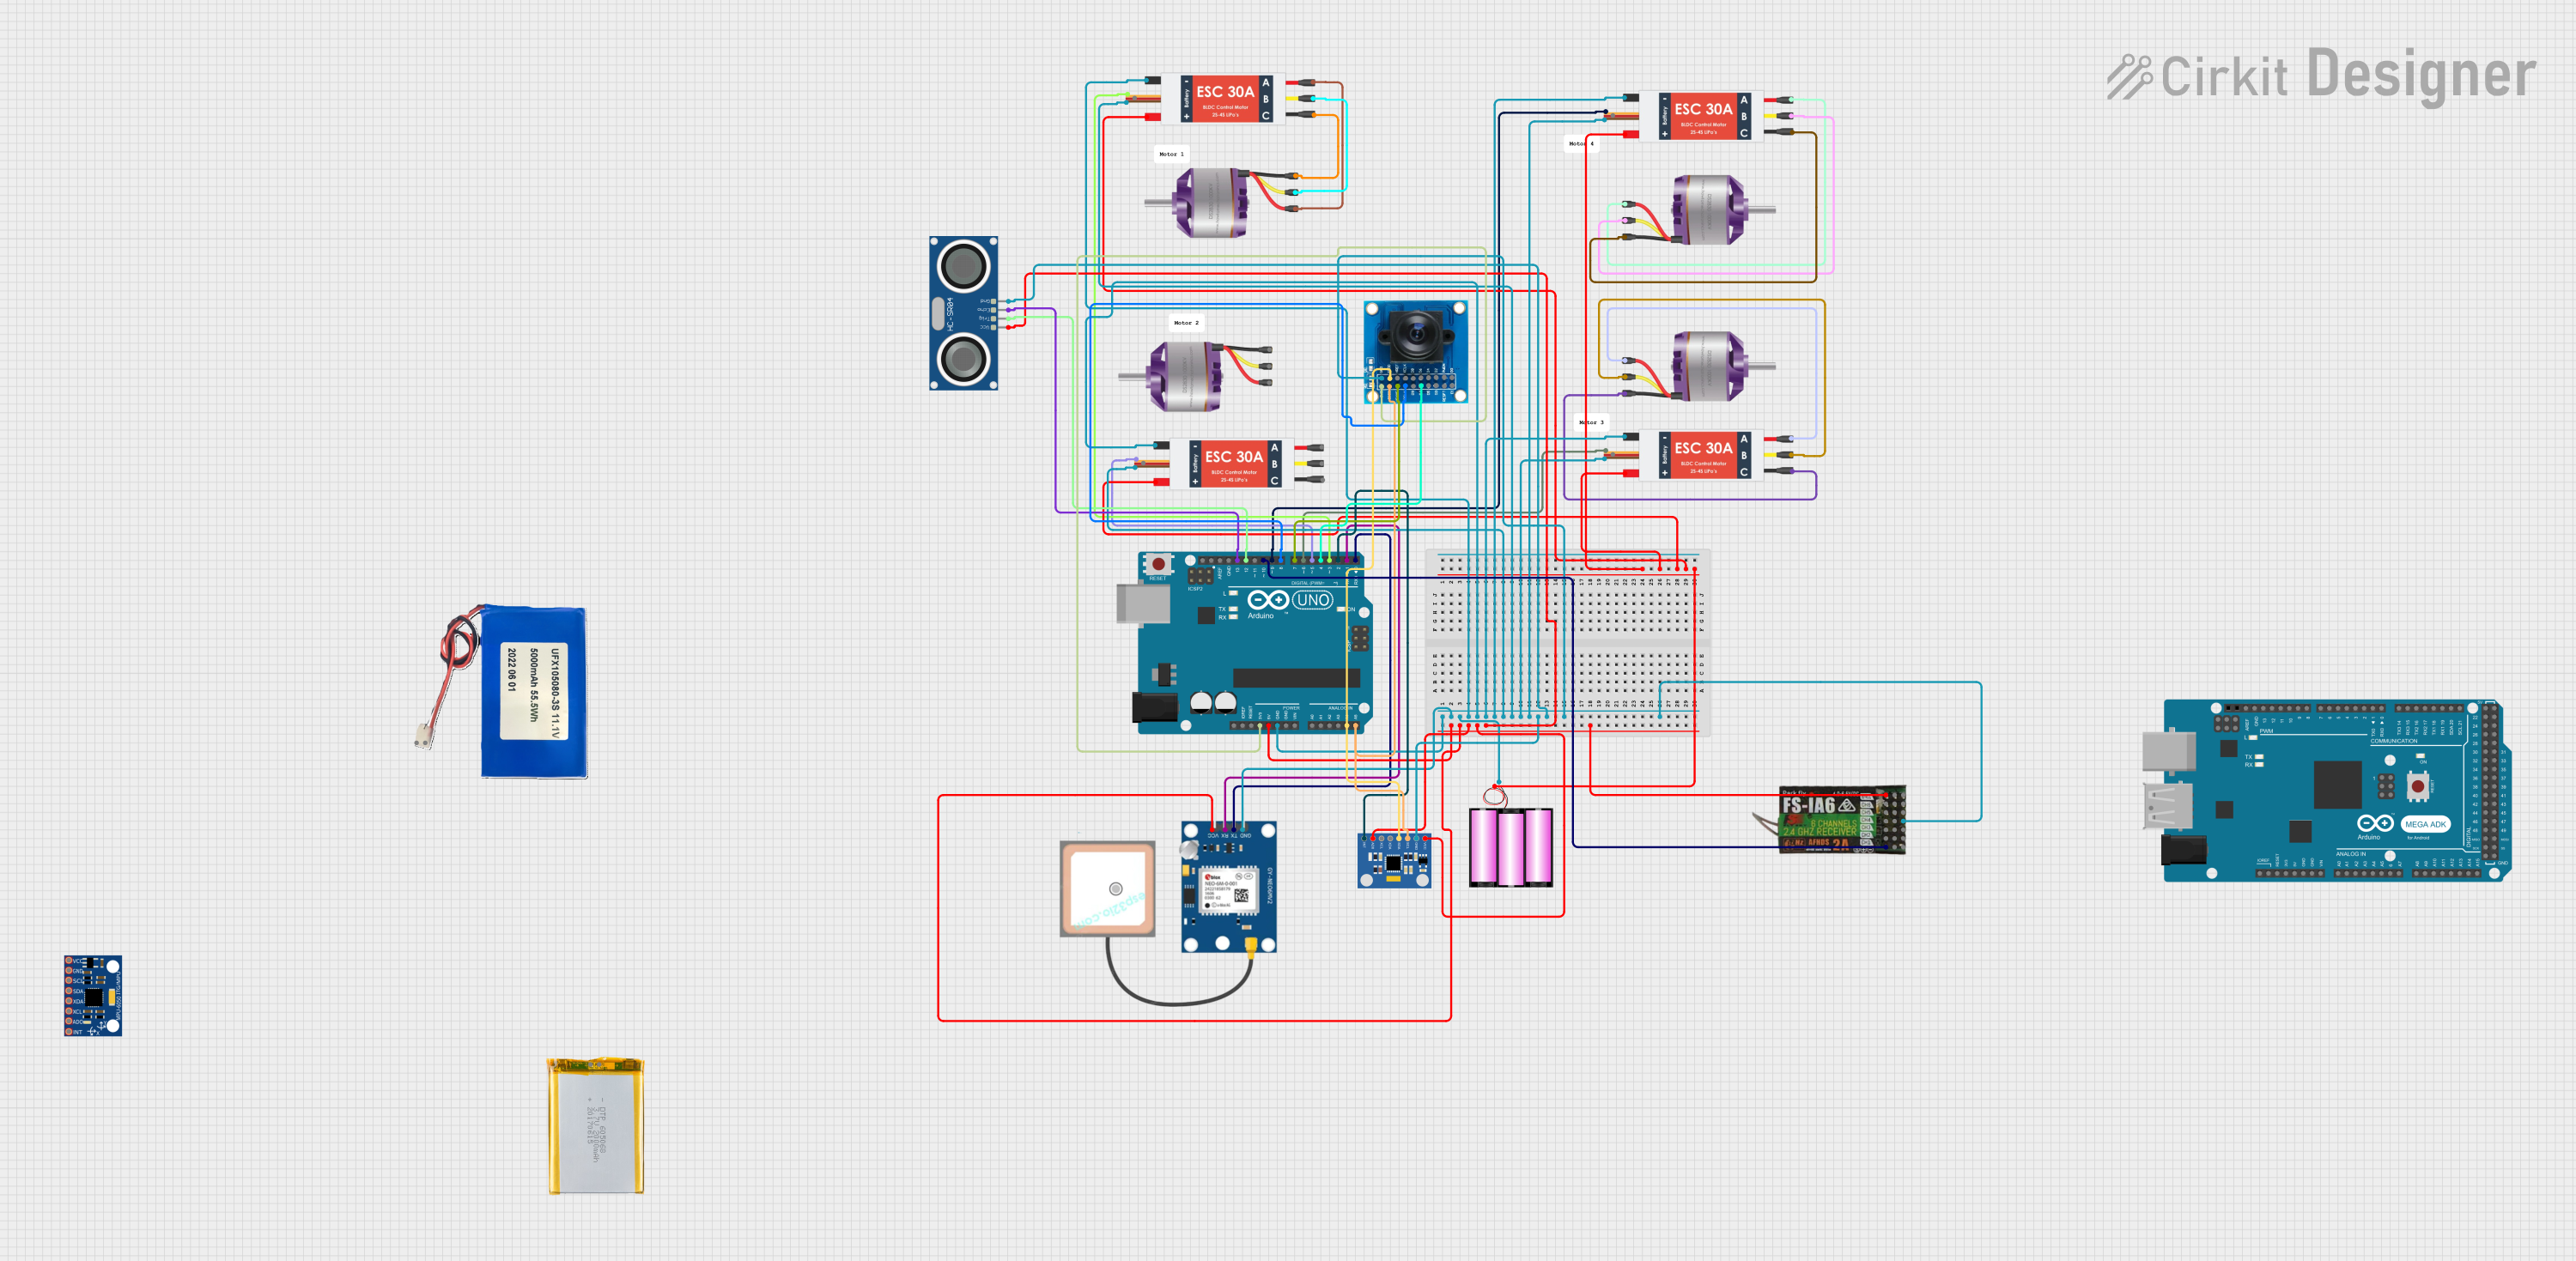
Circuit Documentation
Summary
This circuit integrates various components including an Arduino UNO, a NEO-6M GPS module, multiple brushless motors with their respective electronic speed controllers (ESCs), an MPU6050 accelerometer and gyroscope, a FLYSKY FS-IA6 receiver, an OV7725 camera module, an HC-SR04 ultrasonic sensor, and different power sources. The Arduino UNO serves as the central microcontroller unit, interfacing with sensors, the GPS module, and controlling the ESCs for motor management. The circuit is designed to provide a comprehensive control system, likely for a drone or a similar autonomous vehicle, with capabilities for motion sensing, distance measurement, image capture, and GPS positioning.
Component List
Arduino UNO
- Microcontroller board based on the ATmega328P
- Provides digital and analog I/O pins
- Used for controlling and interfacing with other components in the circuit
NEO-6M (GPS MODULE)
- GPS receiver module for satellite navigation
- Communicates with the Arduino via serial connection
Brushless Motor
- Provides high-efficiency rotational motion
- Typically used in applications requiring precise speed control and high power-to-weight ratio
Electronic Speed Controller (ESC)
- Electronic circuit to control the speed of a brushless motor
- Receives control signals from the Arduino and provides power to the motors
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
- Motion tracking device that measures acceleration and angular rate
- Used for stabilization and motion detection in the circuit
FLYSKY FS-IA6
- 6-channel receiver for remote control applications
- Interfaces with the Arduino to receive control signals from a transmitter
OV7725
- Camera module capable of capturing images and video
- Interfaced with the Arduino for image processing or capture tasks
HC-SR04 Ultrasonic Sensor
- Distance measuring sensor using ultrasonic waves
- Used for obstacle detection or range finding
Power Sources (2000mAh Battery, Li-ion 5000mah, battery 12v)
- Provide electrical power to the circuit components
- Different voltage levels to accommodate various component requirements
Wiring Details
Arduino UNO
GNDconnected to the common ground net5Vconnected to NEO-6M VCC, MPU6050 VCC, HC-SR04 VCC, and FLYSKY FS-IA6 VCC3.3Vconnected to OV7725 3V3A4 (SDA)connected to MPU6050 SDA and OV7725 SIODA5 (SCL)connected to MPU6050 SCL and OV7725 SIOCD0-D13connected to various components for control and data transfer
NEO-6M (GPS MODULE)
GNDconnected to the common ground netVCCconnected to Arduino 5VTXconnected to Arduino D0RXconnected to Arduino D1
Brushless Motors
L1, L2, L3connected to corresponding ESCs M1, M2, M3
Electronic Speed Controllers (ESC)
Battery VCCconnected to battery 12V +Battery GNDconnected to the common ground netSignalconnected to Arduino D3, D5, D6, D9 for motor control5v outandGND outnot explicitly connected in the provided net list
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
GNDconnected to the common ground netVCCconnected to Arduino 5VSDAconnected to Arduino A4SCLconnected to Arduino A5INTconnected to Arduino D2
FLYSKY FS-IA6
GNDconnected to the common ground netVCCconnected to Arduino 5VCH1connected to Arduino D10
OV7725
GNDconnected to the common ground net3V3connected to Arduino 3.3VSIOCconnected to Arduino A5SIODconnected to Arduino A4VSYNCconnected to Arduino D7PCLKconnected to Arduino D8D7connected to Arduino D4
HC-SR04 Ultrasonic Sensor
GNDconnected to the common ground netVCCconnected to Arduino 5VTRIGconnected to Arduino D12ECHOconnected to Arduino D13
Power Sources
2000mAh Battery,Li-ion 5000mah,battery 12vprovide power to the circuitbattery 12v+ connected to ESC Battery VCCbattery 12v- connected to the common ground net
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code is a template and does not contain any functional implementation. It needs to be populated with the logic to control and interface with the components as per the circuit's requirements.