
Raspberry Pi and Pixhawk-Based Battery-Powered Drone with Brushless Motors
View and Edit Project In Cirkit Designer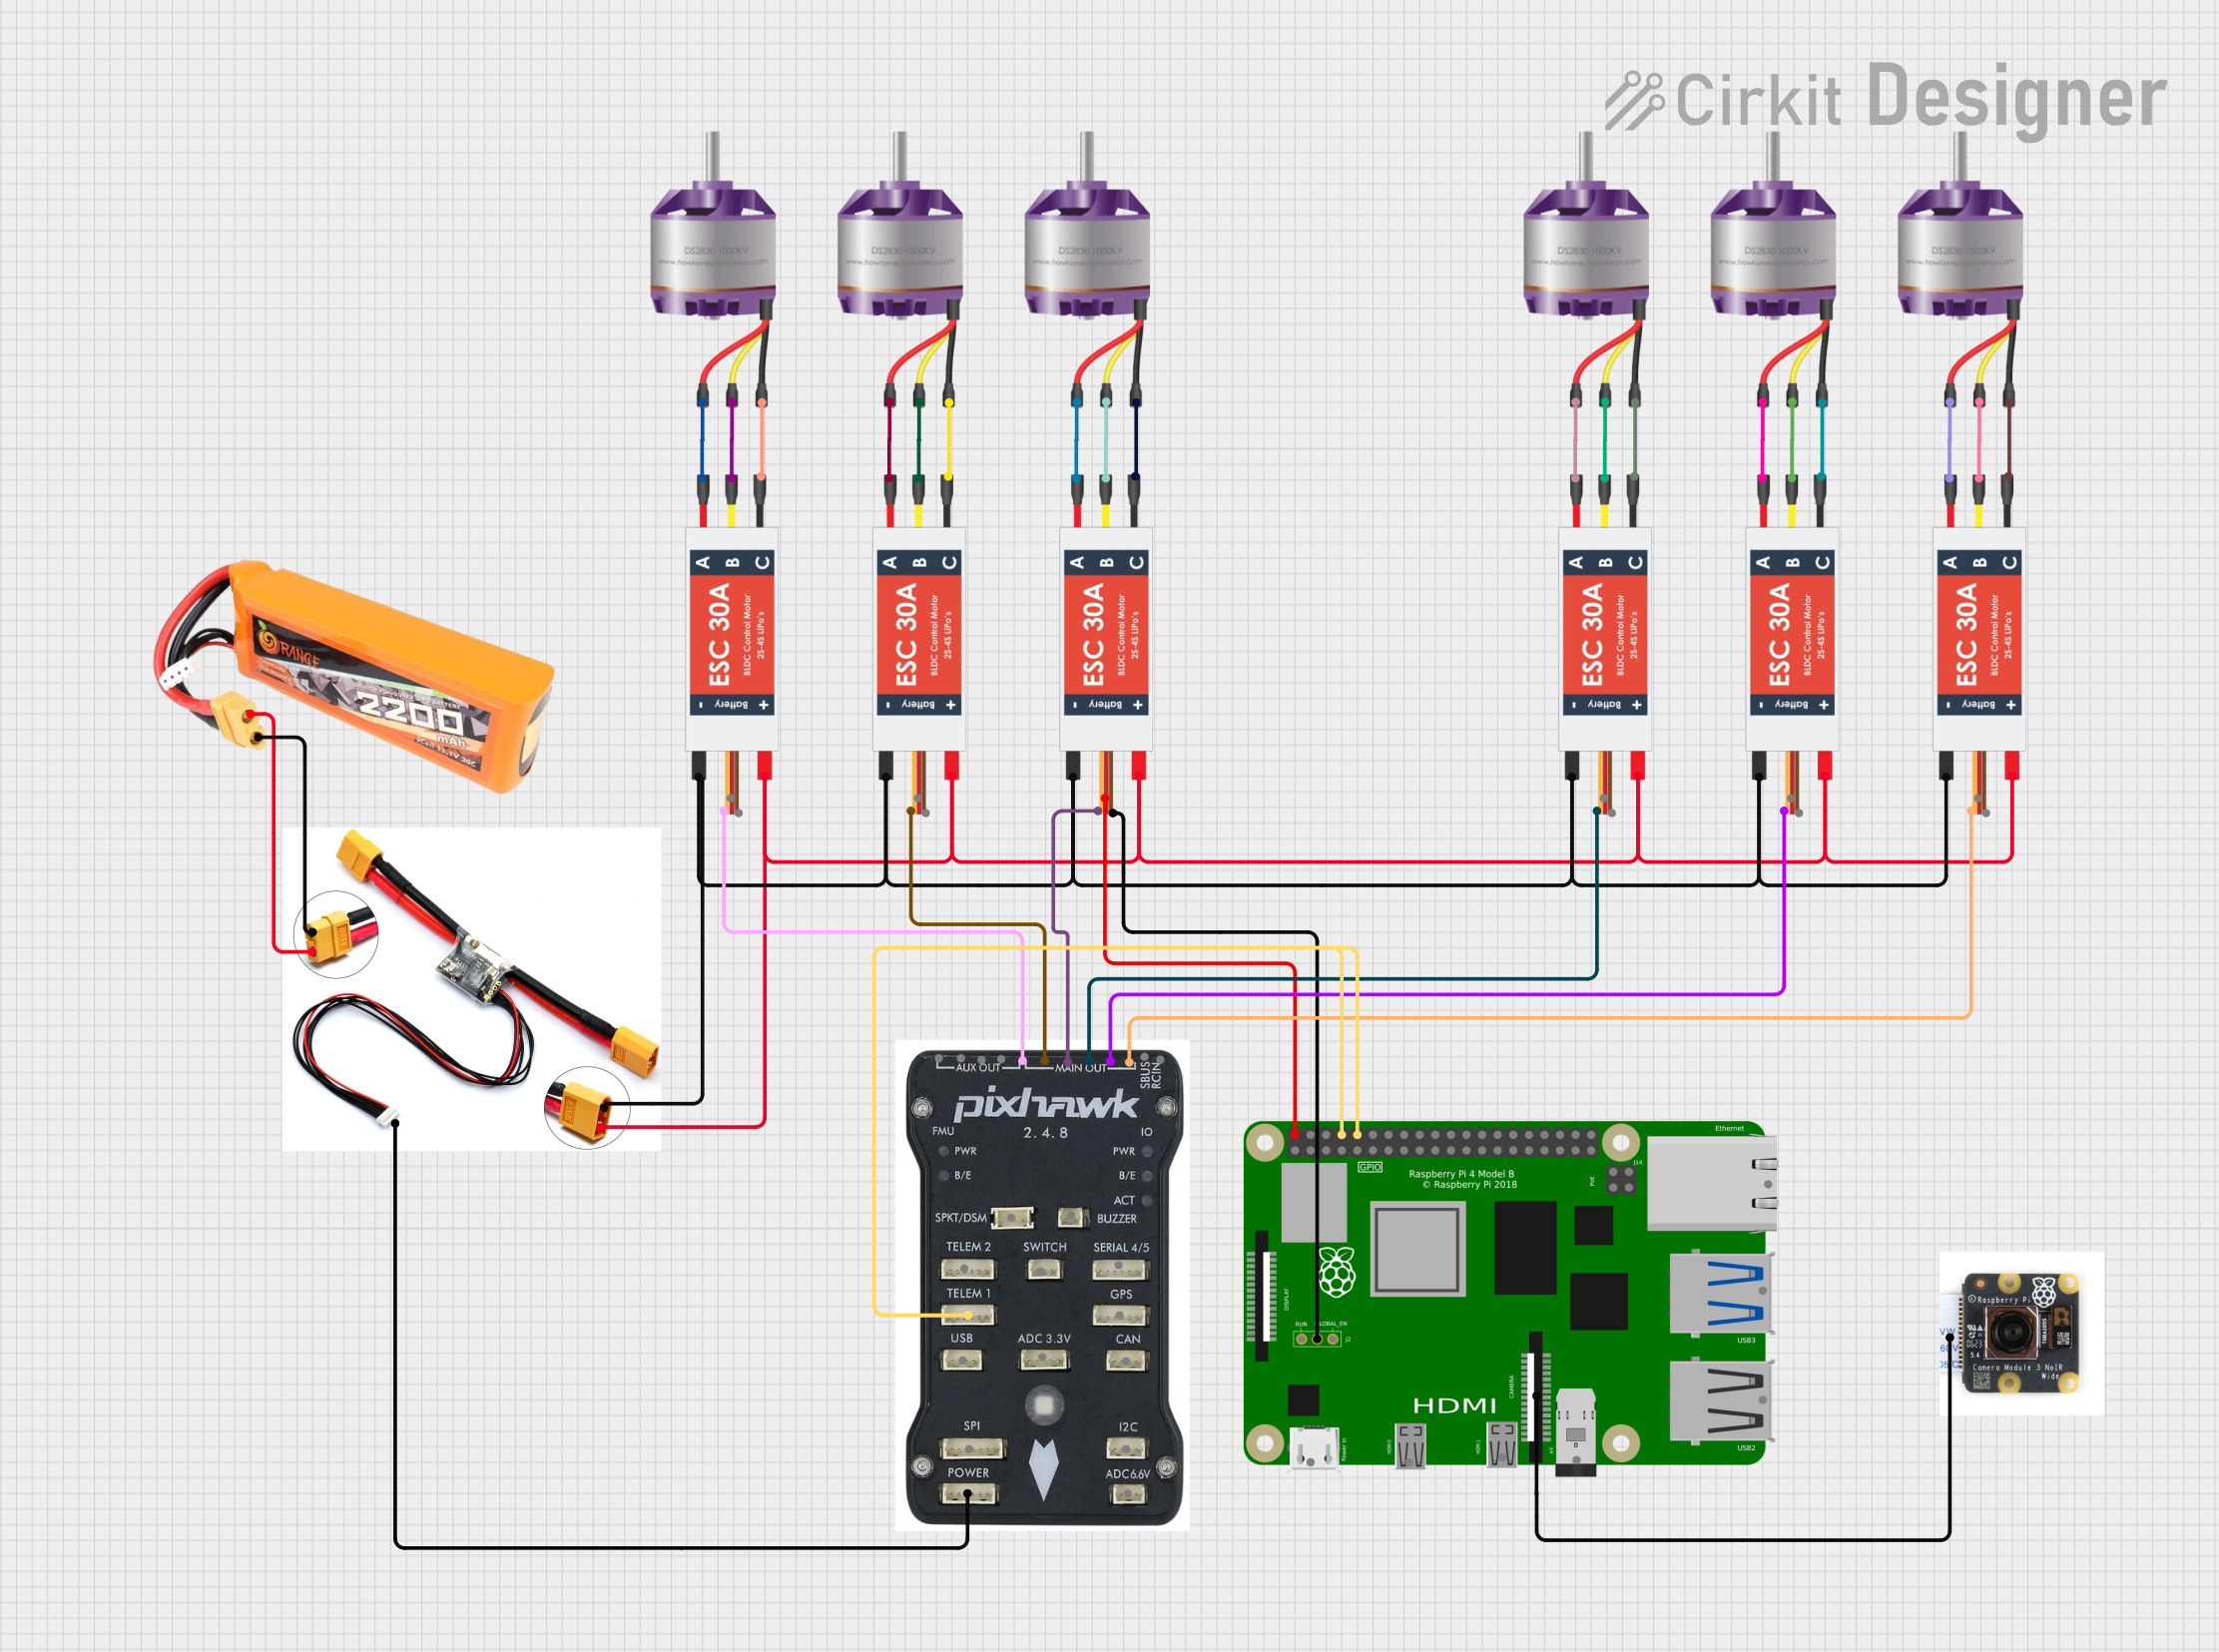
Circuit Documentation
Summary
This document provides a detailed overview of a circuit designed to control multiple brushless motors using electronic speed controllers (ESCs) and a flight controller. The circuit also includes a Raspberry Pi for additional processing and a camera module for visual input. Power is supplied by a LiPo battery, and the system is managed by a Pixhawk flight controller.
Component List
Brushless Motor
- Pins: L1, L2, L3
- Description: A motor that operates without brushes, typically used in drones and other high-performance applications.
Electronic Speed Controller (ESC)
- Pins: Battery VCC, Battery GND, Signal, 5v out, GND out, M1, M2, M3
- Description: A device that controls the speed of the brushless motor by varying the power supplied to it.
Raspberry Pi 4B
- Pins: 3V3, 5V, GPIO2, GPIO3, GND, GPIO4, GPIO14, GPIO15, GPIO17, GPIO18, GPIO27, GPIO22, GPIO23, GPIO24, GPIO10, GPIO9, GPIO25, GPIO11, GPIO8, GPIO7, ID_SD, GPIO5, GPIO6, GPIO12, GPIO13, GPIO19, GPIO16, GPIO26, GPIO20, GPIO21, ID_SC, TR01_TAP, TR00_TAP, TR03_TAP, TR02_TAP, RUN, GLOBAL_EN, ETH, HDMI 0, HDMI 1, CAMERA, AV
- Description: A small, affordable computer that can be used for a variety of applications, including robotics and IoT.
Raspberry Pi Camera Module 3 NoIR
- Pins: None
- Description: A camera module for the Raspberry Pi, capable of capturing high-quality images and video.
Pixhawk PX4 PIX 2.4.8 32 Bit Flight Controller
- Pins: Power from module, I2C, ADC 6.6V, SPI, USB, ADC 3.3V, CAN, GPS, TELEM 1, Serial 4/5, SW, TELEM2, SPKT/DSM, BUZZ
- Description: A flight controller used for managing the flight of drones and other UAVs.
LiPo Battery 2200mAH 30C
- Pins: VCC, GND
- Description: A rechargeable lithium polymer battery, commonly used in high-drain applications like drones.
APM/Pixhawk Power Module
- Pins: Pow -, Pow +, Power Pixhawk
- Description: A power module that supplies power to the Pixhawk flight controller and monitors battery voltage and current.
Wiring Details
Brushless Motor to ESC Connections
Brushless Motor 1
- L1 to ESC 1 M1
- L2 to ESC 1 M2
- L3 to ESC 1 M3
Brushless Motor 2
- L1 to ESC 2 M1
- L2 to ESC 2 M2
- L3 to ESC 2 M3
Brushless Motor 3
- L1 to ESC 3 M1
- L2 to ESC 3 M2
- L3 to ESC 3 M3
Brushless Motor 4
- L1 to ESC 4 M1
- L2 to ESC 4 M2
- L3 to ESC 4 M3
Brushless Motor 5
- L1 to ESC 5 M1
- L2 to ESC 5 M2
- L3 to ESC 5 M3
Brushless Motor 6
- L1 to ESC 6 M1
- L2 to ESC 6 M2
- L3 to ESC 6 M3
ESC to Power Module and Battery Connections
ESCs Battery VCC
- All ESCs Battery VCC pins are connected together and to the Power Module Pow + pin.
ESCs Battery GND
- All ESCs Battery GND pins are connected together and to the Power Module Pow - pin.
ESC to Pixhawk Flight Controller Connections
- ESC 1 Signal to Pixhawk Flight Controller
- ESC 2 Signal to Pixhawk Flight Controller
- ESC 3 Signal to Pixhawk Flight Controller
- ESC 4 Signal to Pixhawk Flight Controller
- ESC 5 Signal to Pixhawk Flight Controller
- ESC 6 Signal to Pixhawk Flight Controller
Power Module to Battery Connections
- Power Module Pow + to LiPo Battery VCC
- Power Module Pow - to LiPo Battery GND
Pixhawk Flight Controller to Raspberry Pi Connections
- Pixhawk TELEM 1 to Raspberry Pi GPIO14 (TX) and GPIO15 (RX)
Raspberry Pi to Camera Module Connections
- Raspberry Pi CAMERA to Camera Module
ESC to Raspberry Pi Power Connections
- ESC 3 5v out to Raspberry Pi 5V
- ESC 3 GND out to Raspberry Pi GND
Code Documentation
No code is provided for this circuit.
This document provides a comprehensive overview of the circuit, including a summary, component list, wiring details, and code documentation. Each section is designed to offer clear and concise information to facilitate understanding and implementation of the circuit.