
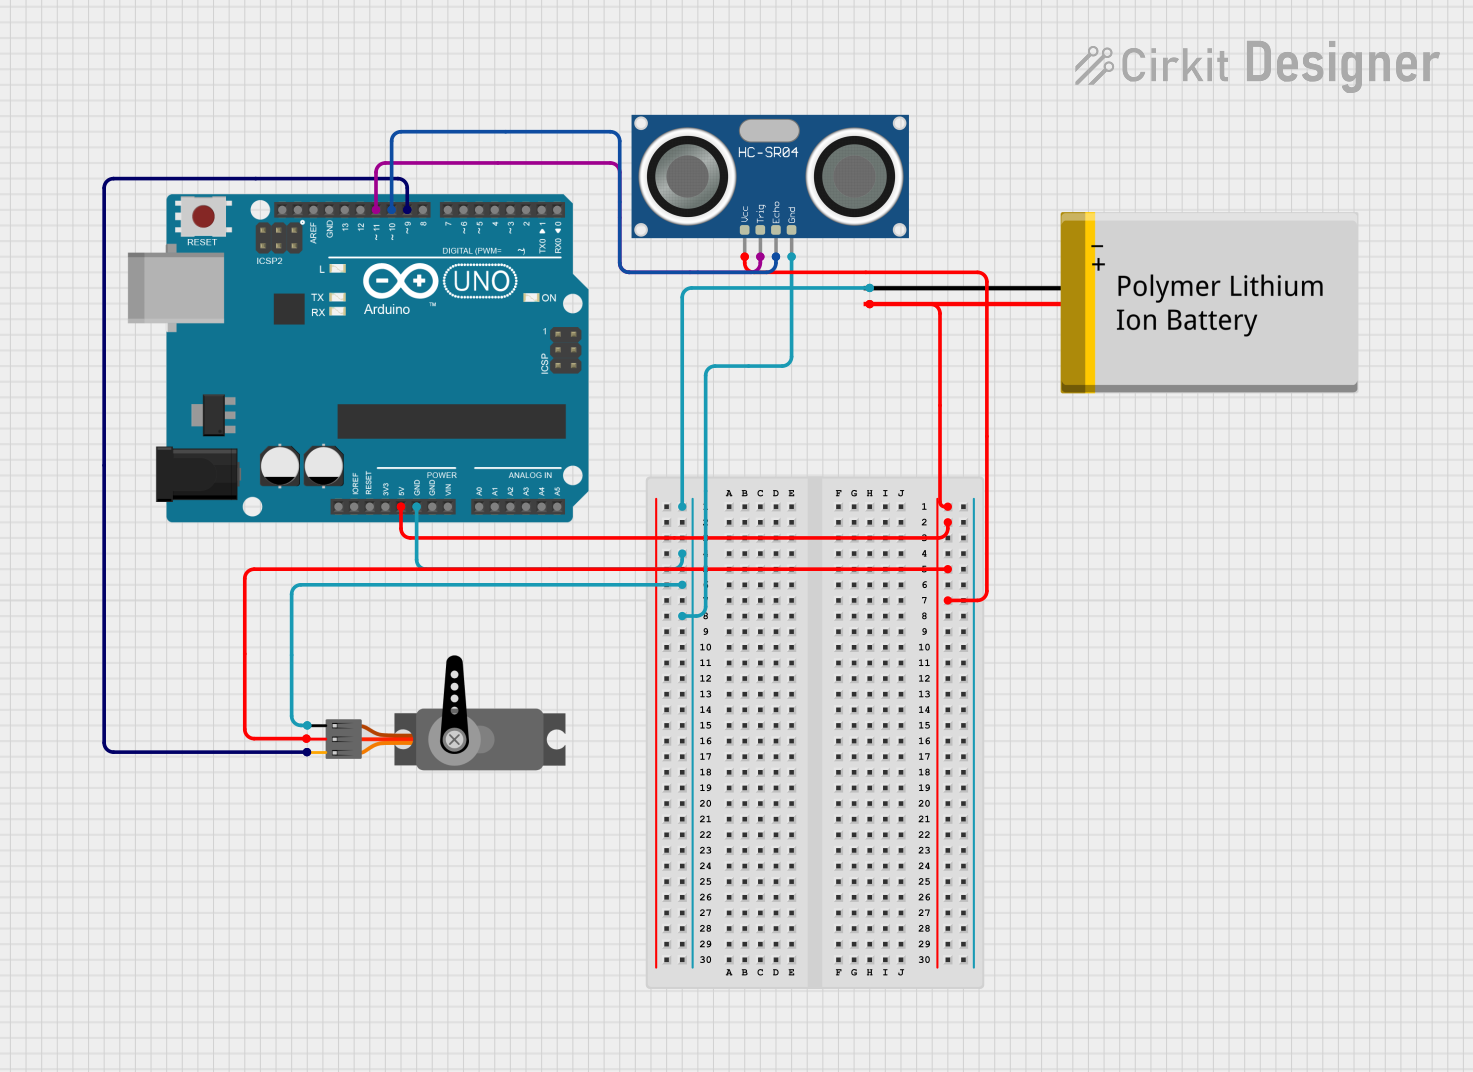
Circuit Documentation
Summary of the Circuit
This circuit is designed to interface an Arduino UNO with an HC-SR04 Ultrasonic Sensor and a Servo motor, powered by a Polymer Lithium Ion Battery. The Arduino UNO acts as the central processing unit, controlling the Servo motor based on distance measurements obtained from the HC-SR04 Ultrasonic Sensor. The Polymer Lithium Ion Battery provides the necessary power to all components in the circuit.
Component List
Polymer Lithium Ion Battery - Generic
- Pins: GND, VCC
- Description: Provides power to the circuit.
Arduino UNO
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13
- Description: Microcontroller board that controls the sensor and servo motor.
HC-SR04 Ultrasonic Sensor
- Pins: VCC, TRIG, ECHO, GND
- Description: Measures distance by emitting ultrasonic waves and receiving the echo.
Servo
- Pins: GND, VCC, PWM
- Description: Actuator that can be positioned to specific angles.
Wiring Details
Polymer Lithium Ion Battery - Generic
- GND connected to Arduino UNO GND, Servo GND, and HC-SR04 GND.
- VCC connected to Arduino UNO 5V, Servo VCC, and HC-SR04 VCC.
Arduino UNO
- GND connected to Polymer Lithium Ion Battery GND, Servo GND, and HC-SR04 GND.
- 5V connected to Polymer Lithium Ion Battery VCC, Servo VCC, and HC-SR04 VCC.
- D11 connected to HC-SR04 TRIG.
- D10 connected to HC-SR04 ECHO.
- D9 connected to Servo PWM.
HC-SR04 Ultrasonic Sensor
- GND connected to Polymer Lithium Ion Battery GND and Arduino UNO GND.
- VCC connected to Polymer Lithium Ion Battery VCC and Arduino UNO 5V.
- TRIG connected to Arduino UNO D11.
- ECHO connected to Arduino UNO D10.
Servo
- GND connected to Polymer Lithium Ion Battery GND and Arduino UNO GND.
- VCC connected to Polymer Lithium Ion Battery VCC and Arduino UNO 5V.
- PWM connected to Arduino UNO D9.
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Additional Notes (documentation.txt)
No additional code documentation provided.