
Circuit Documentation
Summary
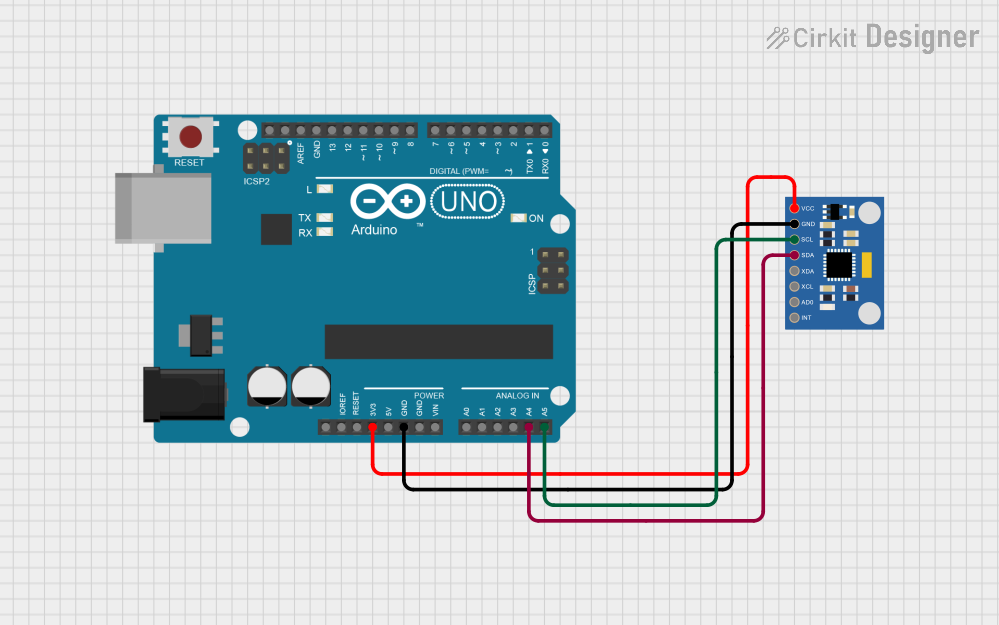
This circuit consists of an Arduino UNO microcontroller connected to an MPU6050 Accelerometer + Gyroscope sensor. The Arduino UNO provides power and communication to the MPU6050 sensor, allowing it to read acceleration and gyroscopic data.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
- Description: A sensor module that combines a 3-axis accelerometer and a 3-axis gyroscope.
- Pins: INT, AD0, XCL, XDA, SDA, SCL, GND, VCC
Wiring Details
Arduino UNO
- 3.3V: Connected to VCC of MPU6050
- GND: Connected to GND of MPU6050
- A4: Connected to SDA of MPU6050
- A5: Connected to SCL of MPU6050
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
- VCC: Connected to 3.3V of Arduino UNO
- GND: Connected to GND of Arduino UNO
- SDA: Connected to A4 of Arduino UNO
- SCL: Connected to A5 of Arduino UNO
Code Documentation
Arduino UNO Code
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
This code is a basic template for the Arduino UNO. The setup() function is where you initialize your settings, and the loop() function is where the main code runs repeatedly. Currently, both functions are empty and need to be filled with the appropriate logic to interact with the MPU6050 sensor.