
Arduino-Based Self-Driving Car with Ultrasonic Sensors and DC Motors
View and Edit Project In Cirkit Designer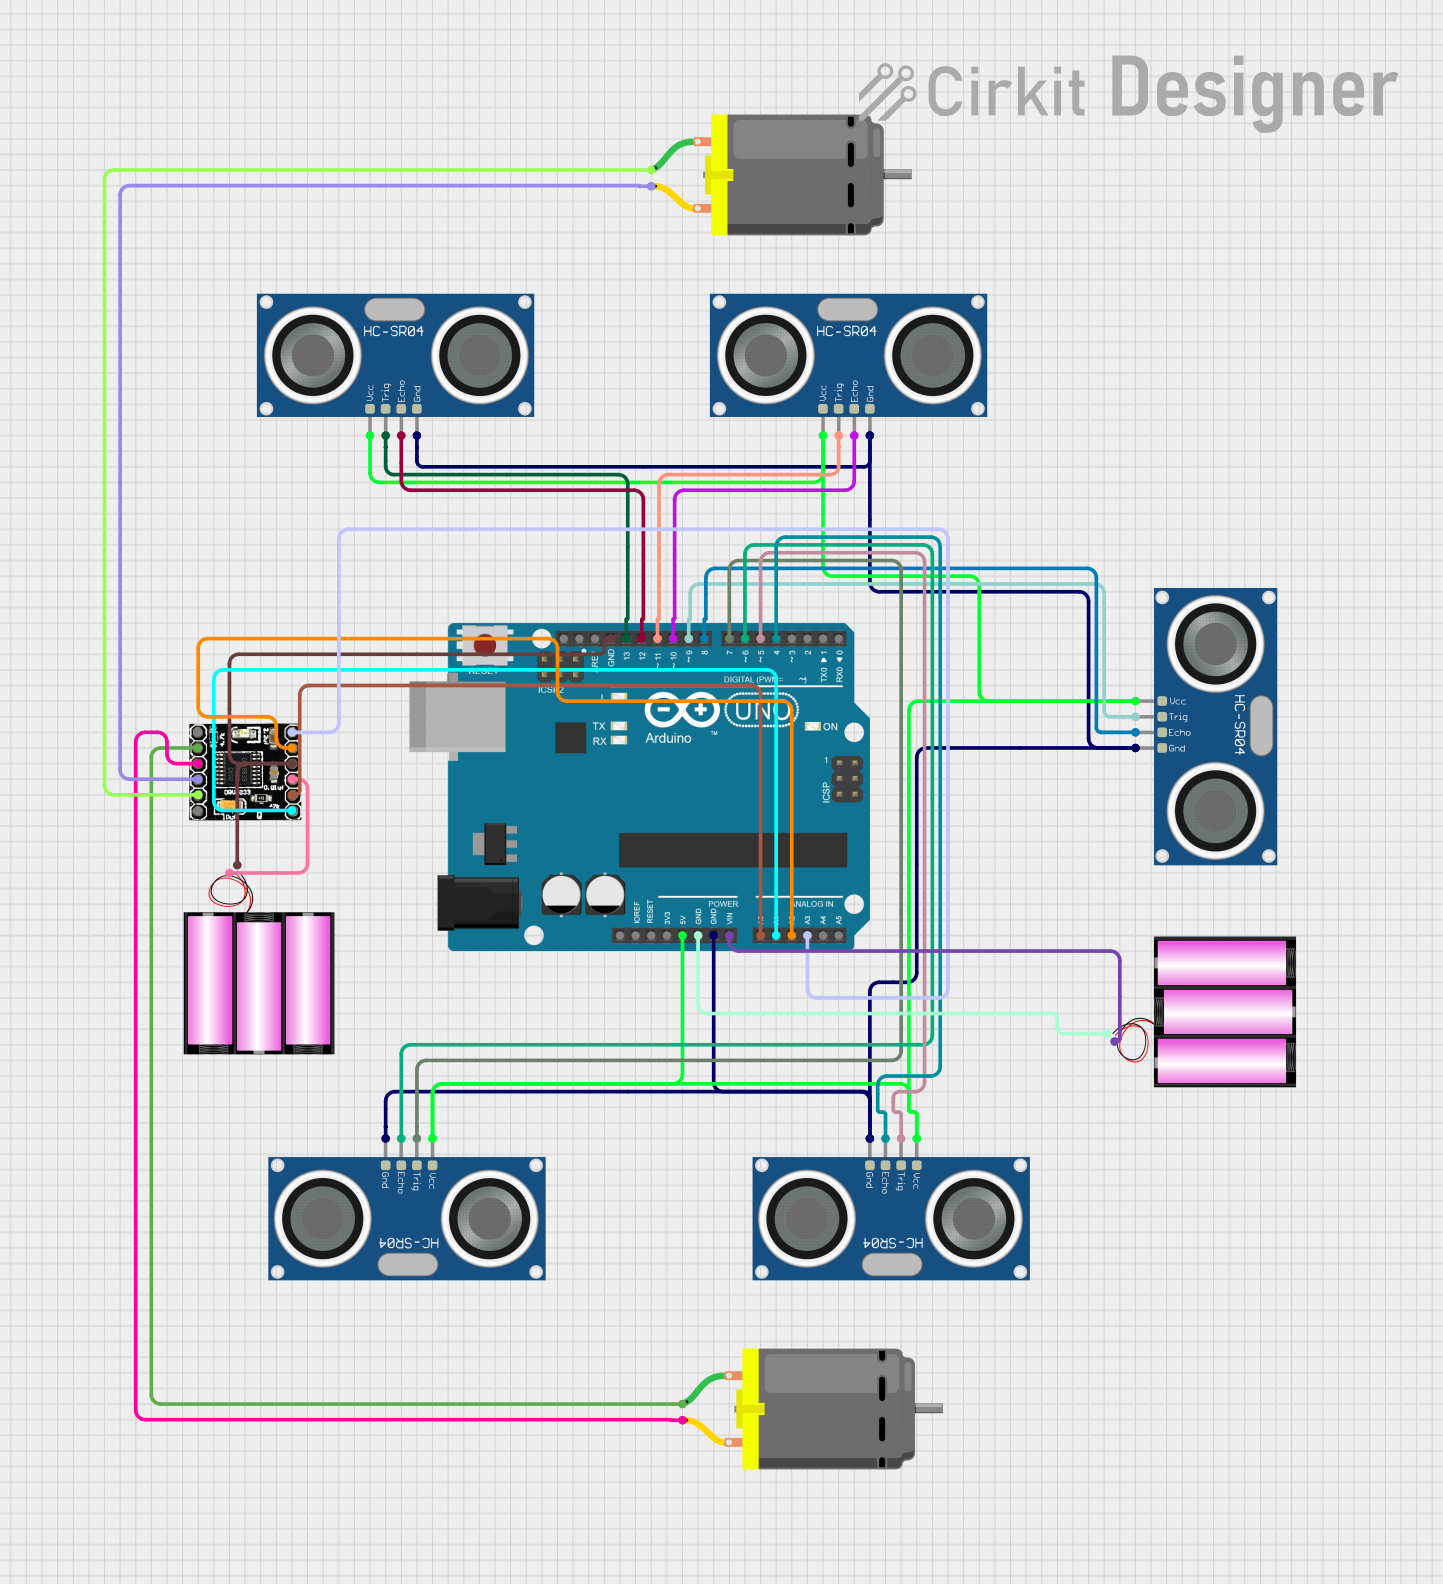
Self-Driving Car Project Documentation
Summary
This project involves the design and implementation of a self-driving car using an Arduino UNO microcontroller. The car uses five HC-SR04 ultrasonic sensors to detect and avoid obstacles. Two DC motors drive the car, controlled via a DRV8833 motor driver. The system is powered by a 12V battery.
Component List
HC-SR04 Ultrasonic Sensor
- Description: Ultrasonic distance sensor used for obstacle detection.
- Pins: VCC, TRIG, ECHO, GND
DC Motor
- Description: Motor used to drive the car.
- Pins: pin 1, pin 2
Drv8833
- Description: Motor driver used to control the DC motors.
- Pins: EEP, OUT1, OUT2, OUT3, OUT4, ULT, IN4, IN3, GND, VCC, IN1, IN2
Arduino UNO
- Description: Microcontroller used to control the entire system.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
Battery 12V
- Description: Power source for the system.
- Pins: +, -
Wiring Details
HC-SR04 Ultrasonic Sensor
- VCC: Connected to 5V on Arduino UNO
- TRIG: Connected to D13, D11, D9, D7, D5 on Arduino UNO
- ECHO: Connected to D12, D10, D8, D6, D4 on Arduino UNO
- GND: Connected to GND on Arduino UNO
DC Motor
Motor 1:
- pin 1: Connected to OUT4 on Drv8833
- pin 2: Connected to OUT3 on Drv8833
Motor 2:
- pin 1: Connected to OUT1 on Drv8833
- pin 2: Connected to OUT2 on Drv8833
Drv8833
- EEP: Not connected
- OUT1: Connected to pin 1 of Motor 2
- OUT2: Connected to pin 2 of Motor 2
- OUT3: Connected to pin 2 of Motor 1
- OUT4: Connected to pin 1 of Motor 1
- ULT: Not connected
- IN4: Connected to A3 on Arduino UNO
- IN3: Connected to A2 on Arduino UNO
- GND: Connected to GND on Arduino UNO and battery 12V
- VCC: Connected to + on battery 12V
- IN1: Connected to A0 on Arduino UNO
- IN2: Connected to A1 on Arduino UNO
Arduino UNO
- 5V: Connected to VCC of all HC-SR04 Ultrasonic Sensors
- GND: Connected to GND of all HC-SR04 Ultrasonic Sensors, Drv8833, and battery 12V
- Vin: Connected to + on battery 12V
- A0: Connected to IN1 on Drv8833
- A1: Connected to IN2 on Drv8833
- A2: Connected to IN3 on Drv8833
- A3: Connected to IN4 on Drv8833
- D13: Connected to TRIG of one HC-SR04 Ultrasonic Sensor
- D12: Connected to ECHO of one HC-SR04 Ultrasonic Sensor
- D11: Connected to TRIG of one HC-SR04 Ultrasonic Sensor
- D10: Connected to ECHO of one HC-SR04 Ultrasonic Sensor
- D9: Connected to TRIG of one HC-SR04 Ultrasonic Sensor
- D8: Connected to ECHO of one HC-SR04 Ultrasonic Sensor
- D7: Connected to TRIG of one HC-SR04 Ultrasonic Sensor
- D6: Connected to ECHO of one HC-SR04 Ultrasonic Sensor
- D5: Connected to TRIG of one HC-SR04 Ultrasonic Sensor
- D4: Connected to ECHO of one HC-SR04 Ultrasonic Sensor
Battery 12V
- +: Connected to Vin on Arduino UNO and VCC on Drv8833
- -: Connected to GND on Arduino UNO and Drv8833
Code Documentation
/*
 * Self-Driving Car Project
 * This Arduino sketch controls a self-driving car using 5 HC-SR04 ultrasonic
 * sensors to detect and avoid obstacles. The car is driven by two DC motors
 * controlled via a DRV8833 motor driver.
 */

// Pin definitions for ultrasonic sensors
const int trigPins[5] = {13, 11, 9, 7, 5};
const int echoPins[5] = {12, 10, 8, 6, 4};

// Pin definitions for motor driver
const int motorPins[4] = {A0, A1, A2, A3};

void setup() {
  // Initialize serial communication
  Serial.begin(9600);

  // Initialize ultrasonic sensor pins
  for (int i = 0; i < 5; i++) {
    pinMode(trigPins[i], OUTPUT);
    pinMode(echoPins[i], INPUT);
  }

  // Initialize motor driver pins
  for (int i = 0; i < 4; i++) {
    pinMode(motorPins[i], OUTPUT);
  }
}

void loop() {
  // Array to store distances from sensors
  long distances[5];

  // Read distances from all sensors
  for (int i = 0; i < 5; i++) {
    distances[i] = readUltrasonic(trigPins[i], echoPins[i]);
  }

  // Determine car movement based on sensor readings
  controlMotors(distances);

  // Small delay to avoid excessive processing
  delay(100);
}

long readUltrasonic(int trigPin, int echoPin) {
  // Send a 10us pulse to trigger pin
  digitalWrite(trigPin, LOW);
  delayMicroseconds(2);
  digitalWrite(trigPin, HIGH);
  delayMicroseconds(10);
  digitalWrite(trigPin, LOW);

  // Read the echo pin and calculate distance
  long duration = pulseIn(echoPin, HIGH);
  long distance = duration * 0.034 / 2;
  return distance;
}

void controlMotors(long distances[]) {
  // Example logic to avoid obstacles
  if (distances[0] < 20 || distances[1] < 20 || distances[2] < 20 ||
      distances[3] < 20 || distances[4] < 20) {
    // If any sensor detects an obstacle within 20 cm, stop the car
    stopCar();
  } else {
    // Otherwise, move forward
    moveForward();
  }
}

void stopCar() {
  // Stop both motors
  digitalWrite(motorPins[0], LOW);
  digitalWrite(motorPins[1], LOW);
  digitalWrite(motorPins[2], LOW);
  digitalWrite(motorPins[3], LOW);
}

void moveForward() {
  // Move both motors forward
  digitalWrite(motorPins[0], HIGH);
  digitalWrite(motorPins[1], LOW);
  digitalWrite(motorPins[2], HIGH);
  digitalWrite(motorPins[3], LOW);
}
This documentation provides a comprehensive overview of the self-driving car project, including the components used, their wiring details, and the code running on the Arduino UNO microcontroller.