
Arduino-Controlled Pressure-Sensitive Automated Motor System
View and Edit Project In Cirkit Designer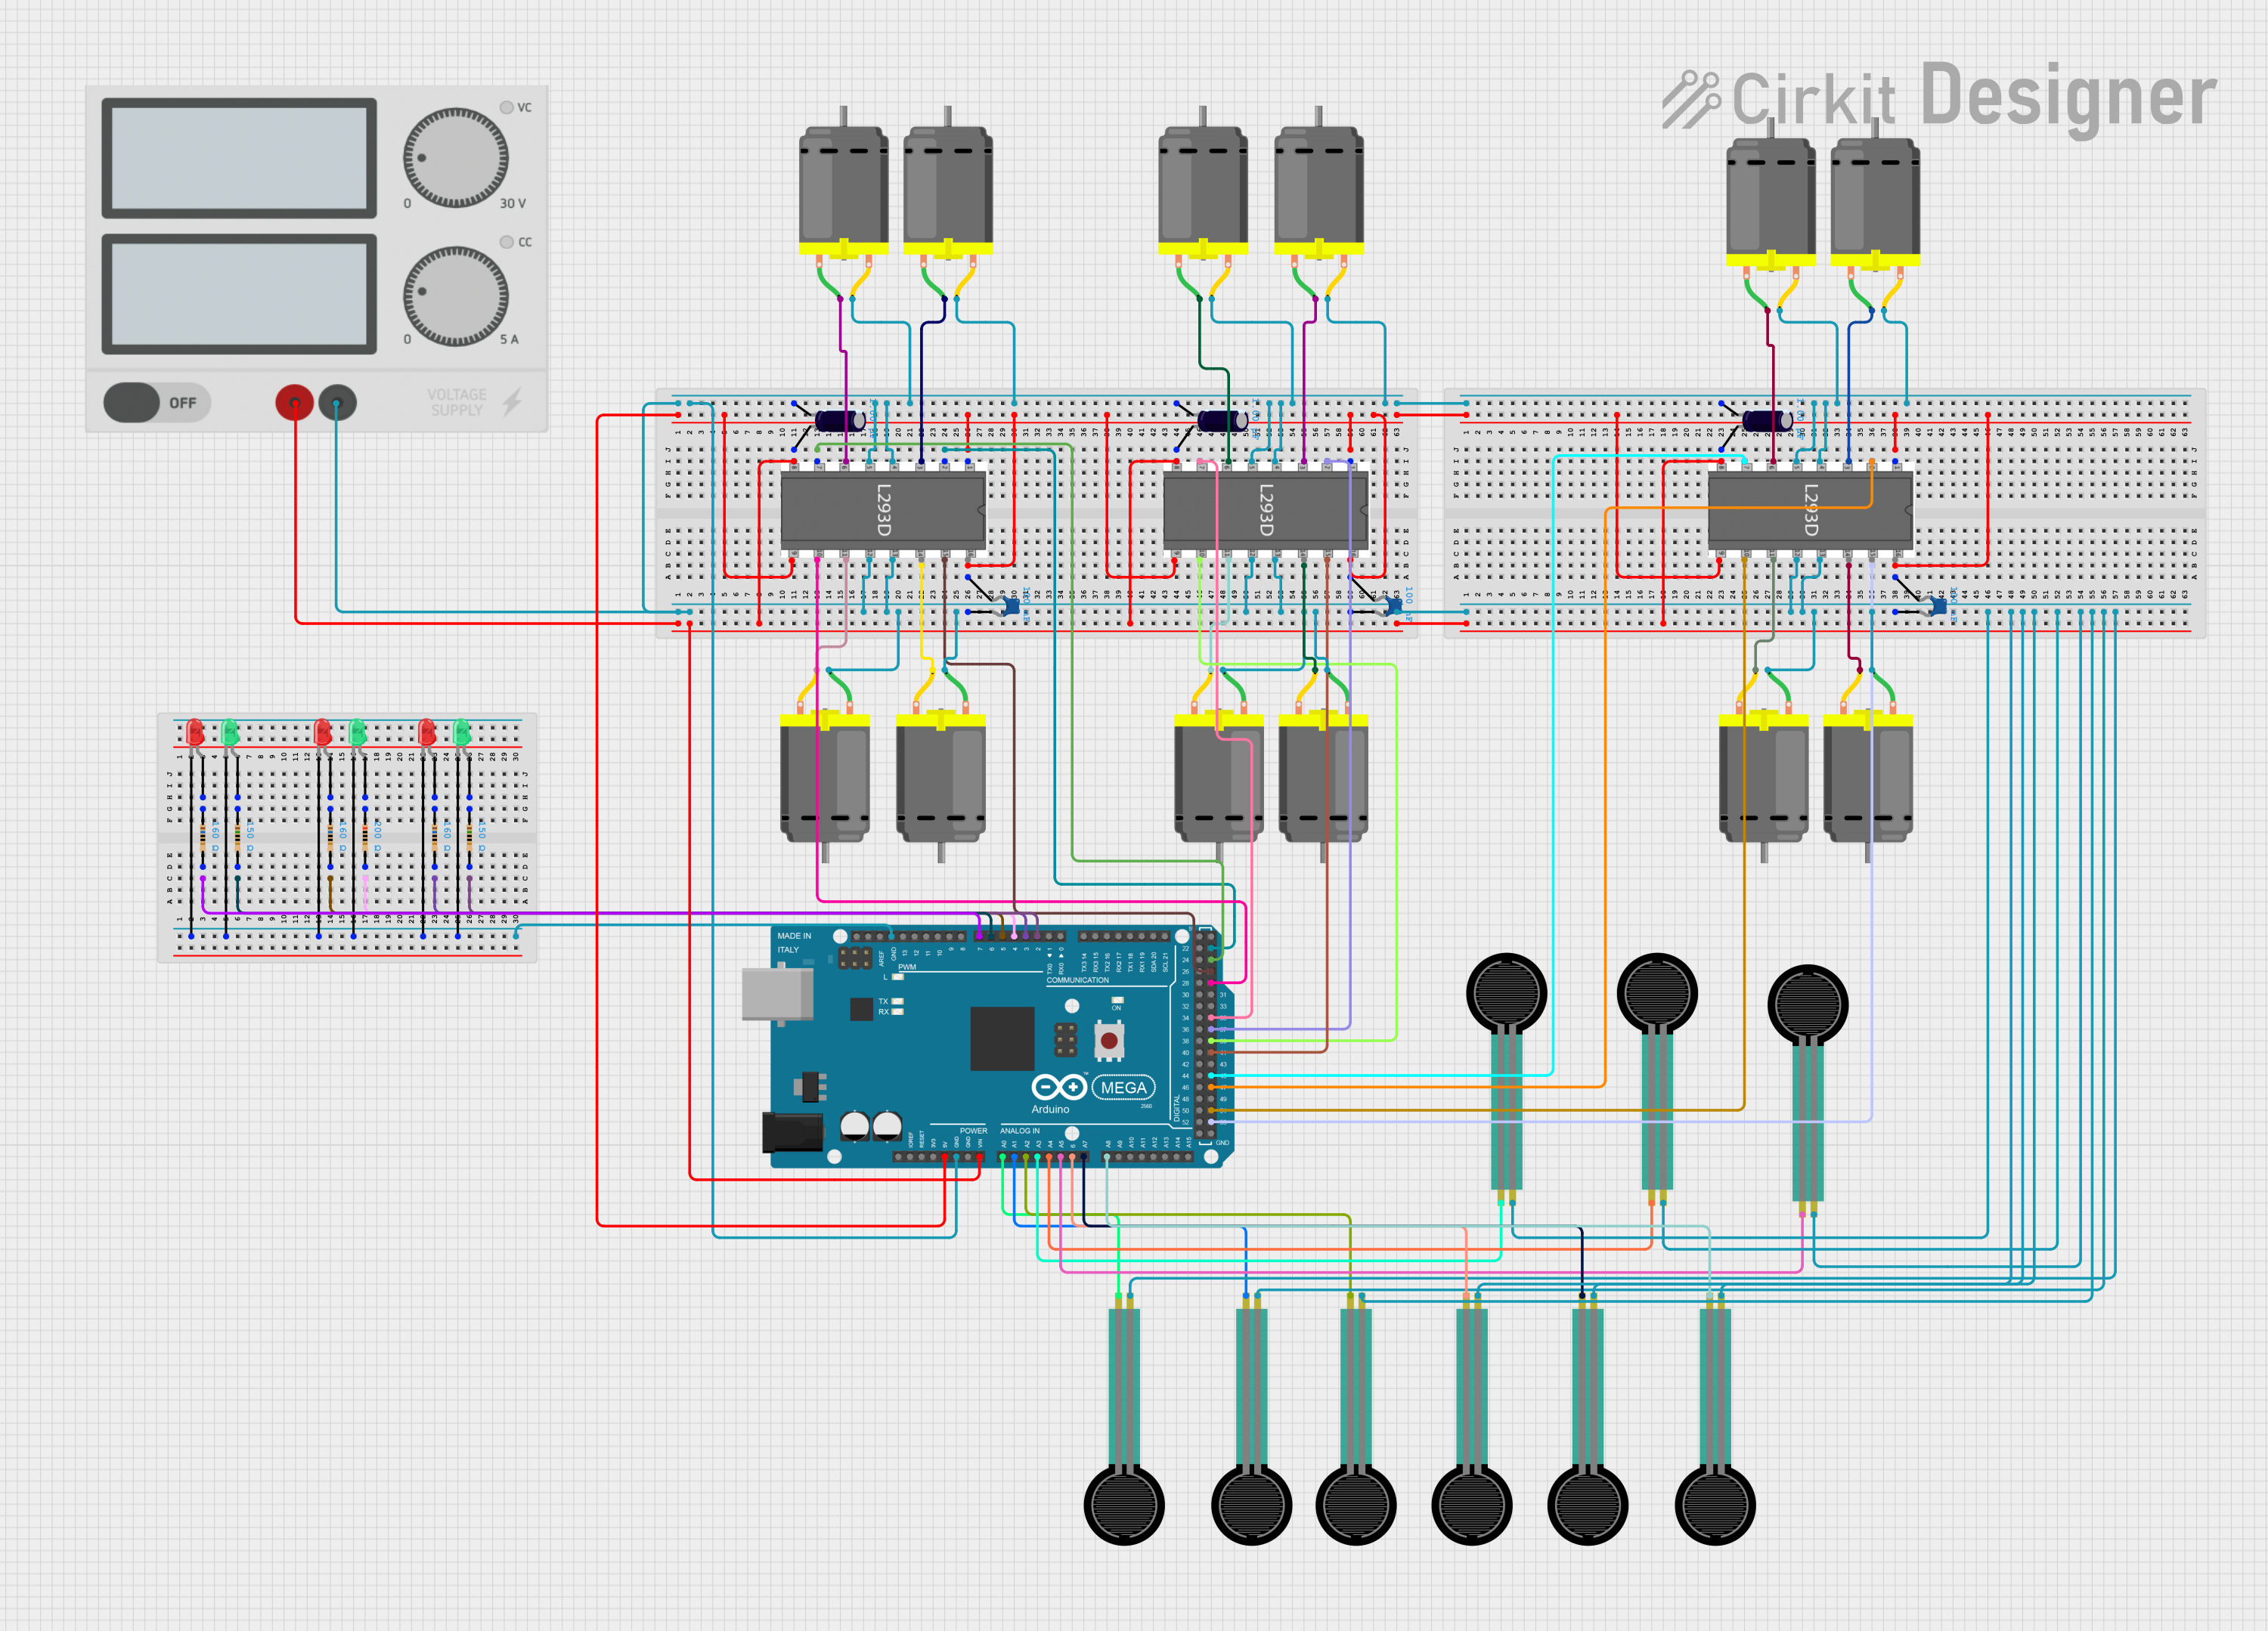
Circuit Documentation
Summary
This circuit is designed to control multiple DC motors using L293D motor drivers, with input signals coming from an Arduino Mega 2560 microcontroller. The circuit also includes force sensing resistors (FSRs) to detect pressure and LEDs to indicate the status of different sections of the circuit. Power is supplied by a dedicated power supply unit, and various capacitors and resistors are used for filtering and current limiting purposes.
Component List
Microcontrollers
- Arduino Mega 2560: A microcontroller board based on the ATmega2560, with numerous digital input/output pins, analog inputs, and a large amount of memory for running complex programs.
Motors
- DC Motors: These are simple electric motors that run on direct current power supply.
Motor Drivers
- L293D Motor Drivers: These are motor driver integrated circuits that provide bidirectional drive currents for motors with capability to control two motors simultaneously.
Sensors
- Force Sensing Resistors (FSRs): These are sensors that change resistance based on the pressure or force applied to them.
Power Supply
- Power Supply: Provides the necessary voltage and current to power the circuit.
LEDs
- LEDs (Red and Green): Light Emitting Diodes used as indicators in the circuit.
Capacitors
- Electrolytic Capacitors: Used for power supply filtering.
- Ceramic Capacitors: Used for noise reduction and power stabilization.
Resistors
- Resistors: Used to limit current to LEDs and for pull-up/pull-down purposes.
Wiring Details
DC Motors
- DC Motor: Two pins for power supply connection.
L293D Motor Drivers
- L293D Motor Driver: Multiple pins for motor control (enable, input, output), power supply (Vs, Vss), and ground (Gnd).
Force Sensing Resistors (FSRs)
- FSR: Two pins for sensing pressure changes.
Power Supply
- Power Supply: Two pins for positive (+) and negative (-) voltage supply.
LEDs
- LED (Red and Green): Two pins for anode and cathode.
Capacitors
- Electrolytic and Ceramic Capacitors: Two pins for positive (+) and negative (-) connections.
Resistors
- Resistor: Two pins for current limiting.
Documented Code
// Pressure sensor pins
int pressureSensor1 = A0; // Back sensor for column 1
int pressureSensor2 = A1; // Front sensor for column 1
int pressureSensor3 = A2; // Back sensor for column 2
int pressureSensor4 = A3; // Front sensor for column 2
int pressureSensor5 = A4; // Back sensor for column 3
int pressureSensor6 = A5; // Front sensor for column 3

// LED pins for each column
const int redLED1 = 2;  // Red LED for column 1
const int greenLED1 = 3; // Green LED for column 1
const int redLED2 = 4;  // Red LED for column 2
const int greenLED2 = 5; // Green LED for column 2
const int redLED3 = 6;  // Red LED for column 3
const int greenLED3 = 7; // Green LED for column 3

// Motor control pins (L293D)
int motor1Input1 = 23;
int motor1Input2 = 25;
int motor2Input1 = 27;
int motor2Input2 = 29;
int motor3Input1 = 35;
int motor3Input2 = 37;
int motor4Input1 = 39;
int motor4Input2 = 41;
int motor5Input1 = 45;
int motor5Input2 = 47;
int motor6Input1 = 51;
int motor6Input2 = 53;

// Enable pins (optional)
int motor1Enable = 5;
int motor2Enable = 4;
int motor3Enable = 6;
int motor4Enable = 7;
int motor5Enable = 8;
int motor6Enable = 9;

// Threshold for detecting if the pressure sensor is "full" or "empty"
const int threshold = 25;  // Adjust this value based on your sensor's readings

//-------------------------------------------------------------
// Function prototypes
void rotateMotor1();
void rotateMotor2();
void rotateMotor3();
void rotateMotor4();
void rotateMotor5();
void rotateMotor6();
void stopMotor1();
void stopMotor2();
void stopMotor3();
void stopMotor4();
void stopMotor5();
void stopMotor6();
void stopAllMotors();
bool isPressureDetected(int sensorPin);
//----------------------------------------------------------
void setup() {
  // Start the Serial communication
  Serial.begin(9600);

  // Initialize LED pins as output
  pinMode(redLED1, OUTPUT);
  pinMode(greenLED1, OUTPUT);
  pinMode(redLED2, OUTPUT);
  pinMode(greenLED2, OUTPUT);
  pinMode(redLED3, OUTPUT);
  pinMode(greenLED3, OUTPUT);


  // Set all control pins to OUTPUT
  pinMode(motor1Input1, OUTPUT);
  pinMode(motor1Input2, OUTPUT);

  pinMode(motor2Input1, OUTPUT);
  pinMode(motor2Input2, OUTPUT);

  pinMode(motor3Input1, OUTPUT);
  pinMode(motor3Input2, OUTPUT);

  pinMode(motor4Input1, OUTPUT);
  pinMode(motor4Input2, OUTPUT);

  pinMode(motor5Input1, OUTPUT);
  pinMode(motor5Input2, OUTPUT);

  pinMode(motor6Input1, OUTPUT);
  pinMode(motor6Input2, OUTPUT);

  // Enable pins setup (if used)
  pinMode(motor1Enable, OUTPUT);
  pinMode(motor2Enable, OUTPUT);
  pinMode(motor3Enable, OUTPUT);
  pinMode(motor4Enable, OUTPUT);
  pinMode(motor5Enable, OUTPUT);
  pinMode(motor6Enable, OUTPUT);

  // Pressure sensor pins setup
  pinMode(pressureSensor1, INPUT);
  pinMode(pressureSensor2, INPUT);
  pinMode(pressureSensor3, INPUT);
  pinMode(pressureSensor4, INPUT);
  pinMode(pressureSensor5, INPUT);
  pinMode(pressureSensor6, INPUT);

  // Initially stop all motors
  stopAllMotors();
}
//-------------------------------------------------------
void loop() {
  // Read pressure sensor values
  int sensorValue1 = analogRead(pressureSensor1); // Back of column 1
  int sensorValue2 = analogRead(pressureSensor2); // Front of column 1
  int sensorValue3 = analogRead(pressureSensor3); // Back of column 2
  int sensorValue4 = analogRead(pressureSensor4); // Front of column 2
  int sensorValue5 = analogRead(pressureSensor5); // Back of column 3
  int sensorValue6 = analogRead(pressureSensor6); // Front of column 3

  // Column 1: Control LED based on sensors 1 (back) and 2 (front)
  if (sensorValue1 <= threshold && sensorValue2 <= threshold) {
    // Both sensors detect product, light up green LED
    digitalWrite(redLED1, LOW);
    digitalWrite(greenLED1, HIGH);
  } else {
    // One or both sensors detect empty, light up red LED
    digitalWrite(redLED1, HIGH);
    digitalWrite(greenLED1, LOW);
  }

  // Column 2: Control LED based on sensors 3 (back) and 4 (front)
  if (sensorValue3 <= threshold && sensorValue4 <= threshold) {
    digitalWrite(redLED2, LOW);
    digitalWrite(greenLED2, HIGH);
  } else {
    digitalWrite(redLED2, HIGH);
    digitalWrite(greenLED2, LOW);
  }

  // Column 3: Control LED based on sensors 5 (back) and 6 (front)
  if (sensorValue5 <= threshold && sensorValue6 <= threshold) {
    digitalWrite(redLED3, LOW);
    digitalWrite(greenLED3, HIGH);
  } else {
    digitalWrite(redLED3, HIGH);
    digitalWrite(greenLED3, LOW);
  }

  // Optional: Print sensor values for debugging
  Serial.print("Sensor 1: "); Serial.println(sensorValue1);
  Serial.print("Sensor 2: "); Serial.println(sensorValue2);
  Serial.print("Sensor 3: "); Serial.println(sensorValue3);
  Serial.print("Sensor 4: "); Serial.println(sensorValue4);
  Serial.print("Sensor 5: "); Serial.println(sensorValue5);
  Serial.print("Sensor 6: "); Serial.println(sensorValue6);

  // Check and output pressure values for each sensor
  int pressure1 = analogRead(pressureSensor1);
  int pressure2 = analogRead(pressureSensor2);
  int pressure3 = analogRead(pressureSensor3);
  int pressure4 = analogRead(pressureSensor4);
  int pressure5 = analogRead(pressureSensor5);
  int pressure6 = analogRead(pressureSensor6);

  // Check pressure for each motor/sensor pair and control motors accordingly
  if (!isPressureDetected(pressureSensor1)) {
    stop