
Arduino UNO and PCA9685 PWM Servo Controller for Joystick-Controlled Robotic Arm
View and Edit Project In Cirkit Designer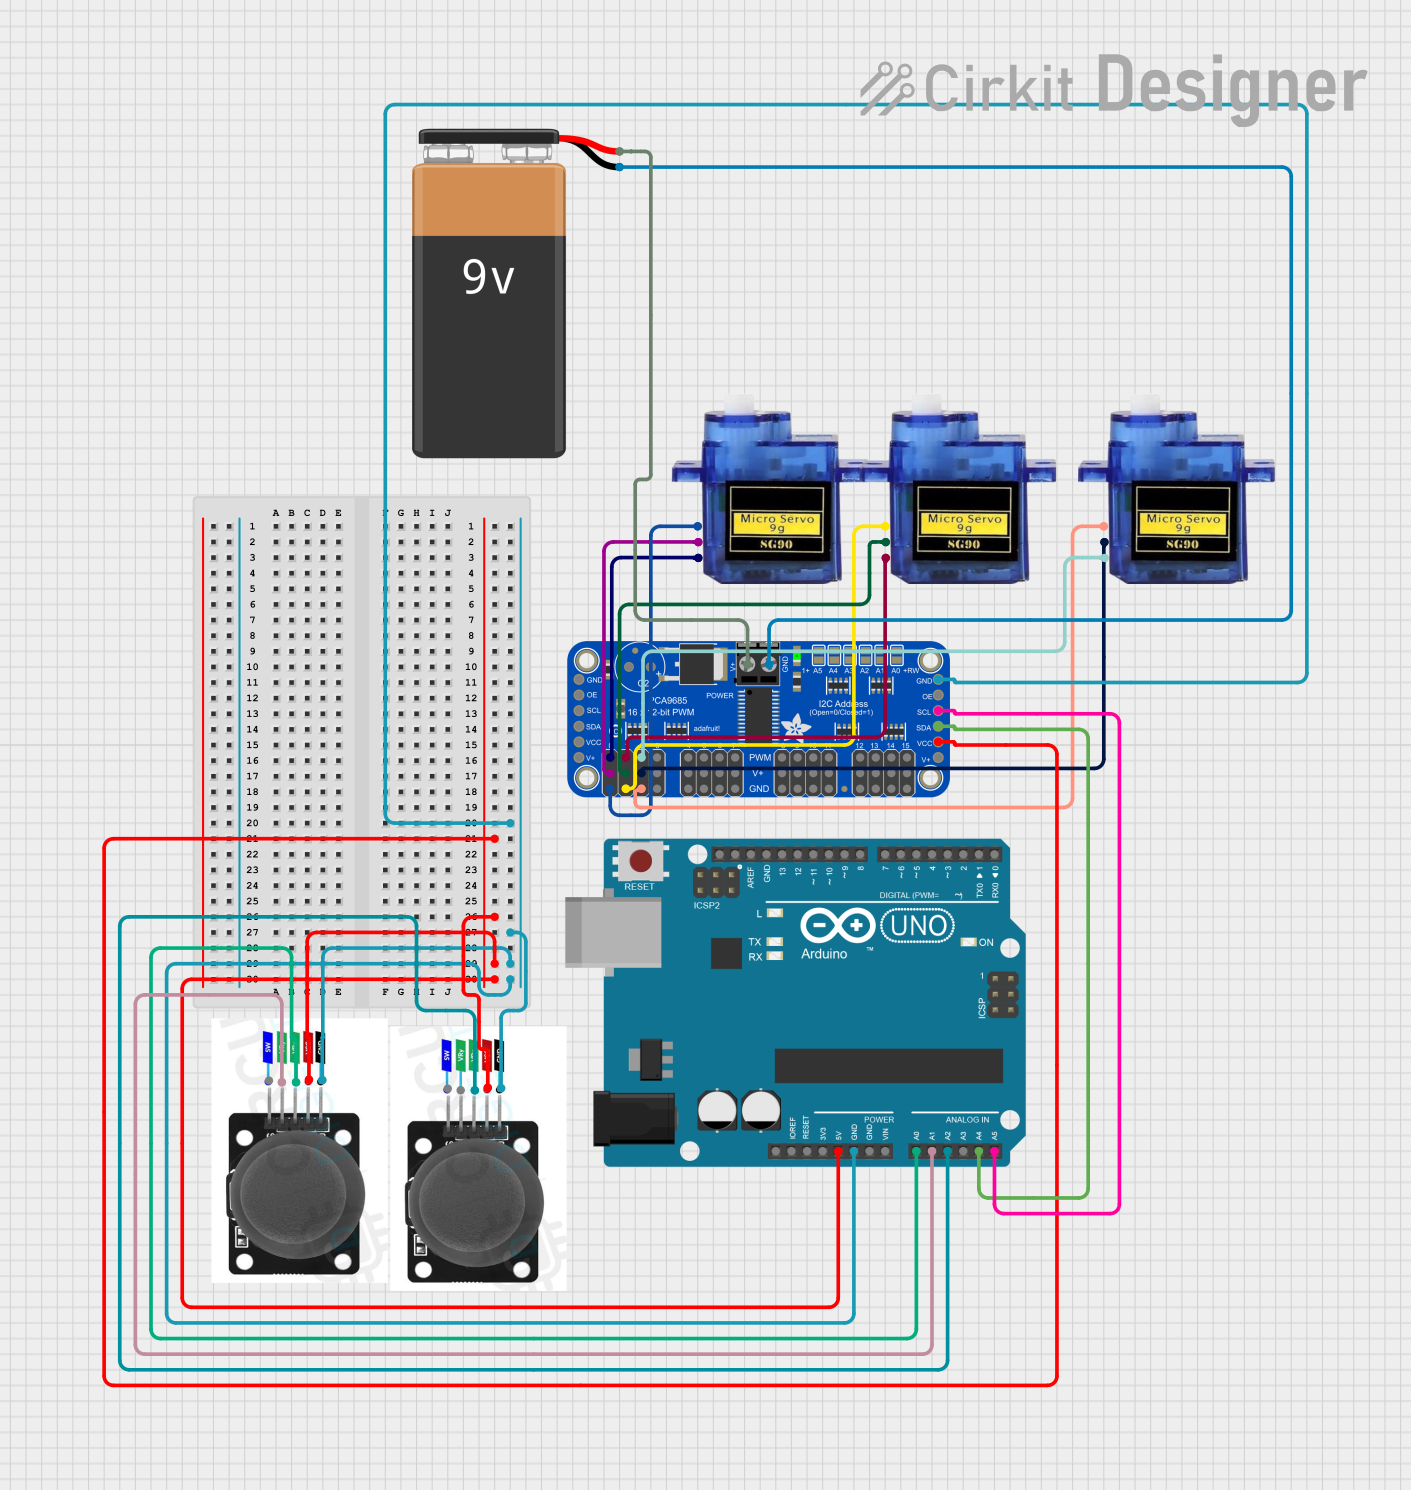
Circuit Documentation
Summary
This circuit is designed to control three micro servos using an Arduino UNO and a PCA9685 PWM Servo Breakout. The servos are controlled via two joystick modules, allowing for precise movement. The circuit is powered by a 9V battery.
Component List
Adafruit PCA9685 PWM Servo Breakout
- Description: A 16-channel PWM driver that can control up to 16 servos or LEDs.
- Pins: 5.0V, GND, PWRIN, PWM0-PWM15, VCC, SDA, SCL, OE
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13
Micro servo 9G
- Description: A small and lightweight servo motor.
- Pins: GND, +5V, PWM
Joystick module
- Description: A module with two potentiometers and a push button, used for controlling servos.
- Pins: SW, VRY, VRX, VCC, GND
9V Battery
- Description: A standard 9V battery used to power the circuit.
- Pins: -, +
Wiring Details
Adafruit PCA9685 PWM Servo Breakout
- PWRIN connected to + of 9V Battery
- GND connected to - of 9V Battery
- PWM2 connected to PWM of Micro servo 9G
- 5.0V connected to +5V of Micro servo 9G
- GND connected to GND of Micro servo 9G
- PWM1 connected to PWM of Micro servo 9G
- 5.0V connected to +5V of Micro servo 9G
- GND connected to GND of Micro servo 9G
- PWM0 connected to PWM of Micro servo 9G
- 5.0V connected to +5V of Micro servo 9G
- GND connected to GND of Micro servo 9G
- VCC connected to 5V of Arduino UNO, VCC of Joystick module, VCC of Joystick module
- SDA connected to A4 of Arduino UNO
- SCL connected to A5 of Arduino UNO
- GND connected to GND of Arduino UNO, GND of Joystick module, GND of Joystick module
Arduino UNO
- 5V connected to VCC of Adafruit PCA9685 PWM Servo Breakout, VCC of Joystick module, VCC of Joystick module
- A4 connected to SDA of Adafruit PCA9685 PWM Servo Breakout
- A5 connected to SCL of Adafruit PCA9685 PWM Servo Breakout
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout, GND of Joystick module, GND of Joystick module
- A0 connected to VRX of Joystick module
- A1 connected to VRY of Joystick module
- A2 connected to VRX of Joystick module
Micro servo 9G
- PWM connected to PWM2 of Adafruit PCA9685 PWM Servo Breakout
- +5V connected to 5.0V of Adafruit PCA9685 PWM Servo Breakout
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout
Micro servo 9G
- PWM connected to PWM1 of Adafruit PCA9685 PWM Servo Breakout
- +5V connected to 5.0V of Adafruit PCA9685 PWM Servo Breakout
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout
Micro servo 9G
- PWM connected to PWM0 of Adafruit PCA9685 PWM Servo Breakout
- +5V connected to 5.0V of Adafruit PCA9685 PWM Servo Breakout
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout
Joystick module
- VCC connected to VCC of Adafruit PCA9685 PWM Servo Breakout, 5V of Arduino UNO
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout, GND of Arduino UNO
- VRX connected to A0 of Arduino UNO
Joystick module
- VCC connected to VCC of Adafruit PCA9685 PWM Servo Breakout, 5V of Arduino UNO
- GND connected to GND of Adafruit PCA9685 PWM Servo Breakout, GND of Arduino UNO
- VRX connected to A2 of Arduino UNO
- VRY connected to A1 of Arduino UNO
9V Battery
- + connected to PWRIN of Adafruit PCA9685 PWM Servo Breakout
- - connected to GND of Adafruit PCA9685 PWM Servo Breakout
Code Documentation
#include <Servo.h>

// Servo objects
Servo shoulderServo, elbowServo, gripperServo;

// Joystick pins
const int shoulderJoystickPin = A0;
const int elbowJoystickPin = A1;
const int gripperJoystickPin = A2;

// Servo pins
const int shoulderServoPin = 9;
const int elbowServoPin = 10;
const int gripperServoPin = 11;

// Default servo positions
const int startShoulderPosition = 90;
const int startElbowPosition = 90;
const int startGripperPosition = 180;

// Dead zone settings
int deadZoneCenter = 512;       // Center point of the joystick
const int deadZoneRange = 50;   // Range considered as the dead zone

// Debugging toggle
const bool debugEnabled = true;

// Calibration button pin (optional, connect to a push button or jumper)
const int calibrateButtonPin = 7;

// Setup function
void setup() {
    // Attach servos to pins
    shoulderServo.attach(shoulderServoPin);
    elbowServo.attach(elbowServoPin);
    gripperServo.attach(gripperServoPin);

    // Initialize servos to start positions
    moveServoToPosition(shoulderServo, startShoulderPosition);
    moveServoToPosition(elbowServo, startElbowPosition);
    moveServoToPosition(gripperServo, startGripperPosition);

    // Setup serial for debugging
    if (debugEnabled) {
        Serial.begin(9600);
        Serial.println("System initialized.");
    }

    // Calibrate joystick dead zone
    pinMode(calibrateButtonPin, INPUT_PULLUP); // Pull-up for button
    deadZoneCenter = calibrateJoystickCenter();
    if (debugEnabled) {
        Serial.print("Calibrated Dead Zone Center: ");
        Serial.println(deadZoneCenter);
    }
}

// Main loop
void loop() {
    // Check for recalibration request
    if (digitalRead(calibrateButtonPin) == LOW) {
        deadZoneCenter = calibrateJoystickCenter();
        if (debugEnabled) {
            Serial.println("Joystick recalibrated.");
        }
    }

    // Control servos
    controlServoWithJoystick(shoulderJoystickPin, shoulderServo, "Shoulder");
    controlServoWithJoystick(elbowJoystickPin, elbowServo, "Elbow");
    controlServoWithJoystick(gripperJoystickPin, gripperServo, "Gripper");

    delay(20); // Stabilization delay
}

// Function to control a servo using joystick
void controlServoWithJoystick(int joystickPin, Servo &servo, const char *servoName) {
    int joystickValue = smoothAnalogRead(joystickPin);

    // Check dead zone
    if (abs(joystickValue - deadZoneCenter) < deadZoneRange) {
        if (debugEnabled) {
            Serial.print(servoName);
            Serial.println(": Joystick in dead zone, holding position.");
        }
        return; // Do nothing if in dead zone
    }

    // Map joystick value to servo angle
    int servoAngle = map(joystickValue, 0, 1023, 0, 180);
    moveServoToPosition(servo, servoAngle);

    // Debugging
    if (debugEnabled) {
        Serial.print(servoName);
        Serial.print(" Joystick Value: ");
        Serial.print(joystickValue);
        Serial.print(" -> Servo Angle: ");
        Serial.println(servoAngle);
    }
}

// Function to move a servo to a position
void moveServoToPosition(Servo &servo, int position) {
    servo.write(position