
Arduino Mega 2560 Controlled Robotic Arm with Analog Joystick
View and Edit Project In Cirkit Designer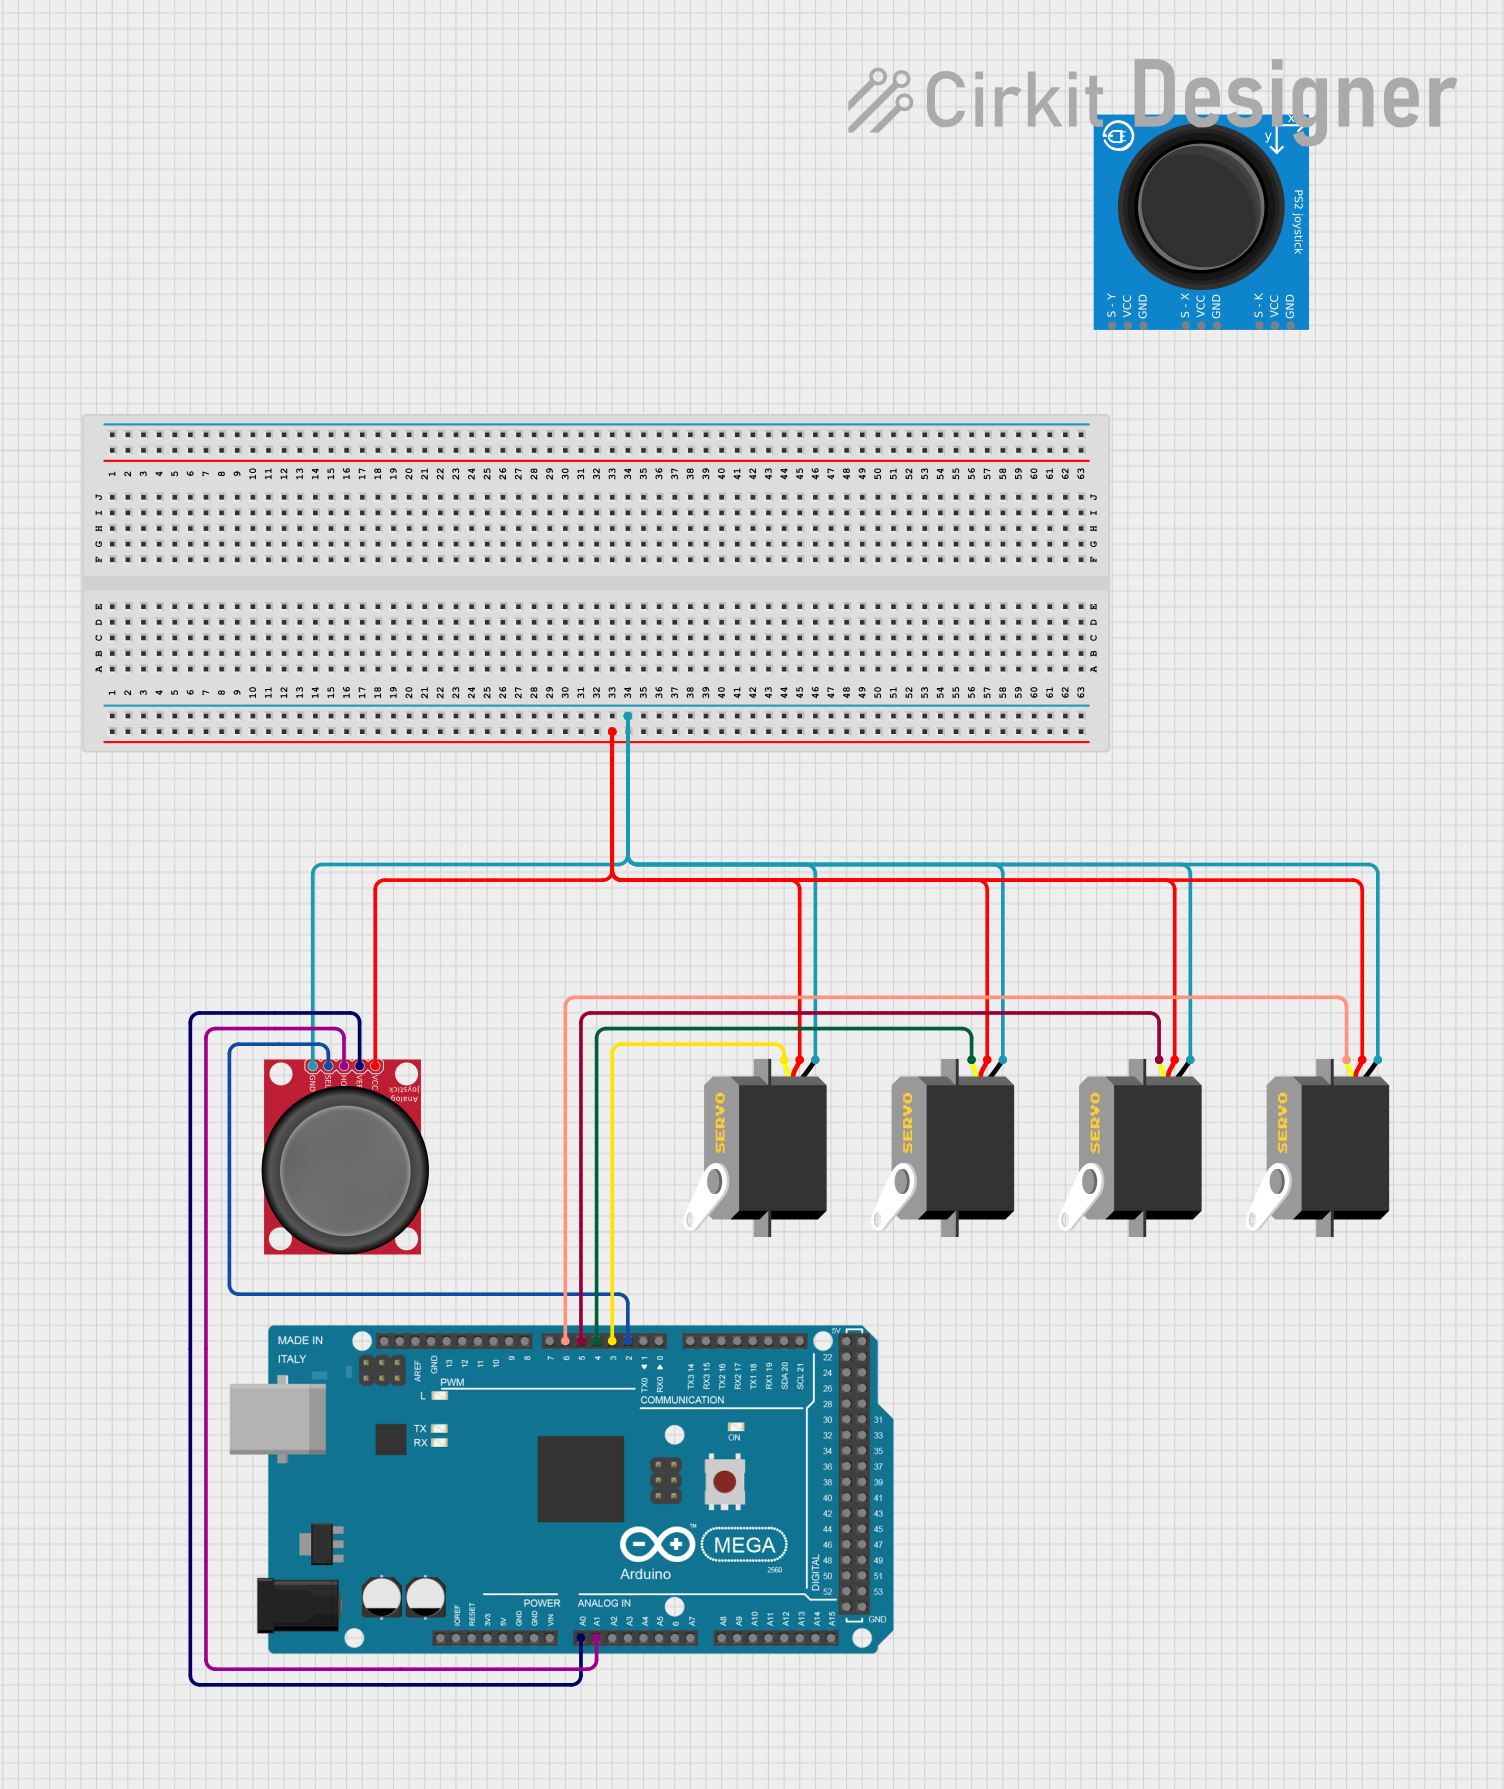
Circuit Documentation
Summary
This circuit consists of an Arduino Mega 2560 microcontroller, four servos, and an analog joystick. The servos are controlled by the Arduino, which receives input from the analog joystick. The joystick's vertical and horizontal movements are read by the Arduino to control the servos' positions.
Component List
Servo
- Description: A servo motor used for precise control of angular position.
- Pins:
gnd: Groundvcc: Power supplypulse: Control signal
Analog Joystick
- Description: An analog joystick used to provide input for controlling the servos.
- Pins:
VCC: Power supplyVERT: Vertical axis outputHORZ: Horizontal axis outputSEL: Select button outputGND: Ground
Arduino Mega 2560
- Description: A microcontroller board based on the ATmega2560.
- Pins:
IOREF,RESET,3V3,5V,GND,VIN- Analog pins:
A0toA15 - Digital pins:
D0toD53 - PWM pins:
D2 PWMtoD13 PWM - Communication pins:
SDA,SCL,RX0,TX0,RX1,TX1,RX2,TX2,RX3,TX3 AREF
Wiring Details
Servo 1
- Pins:
gndconnected to Groundvccconnected to Power supplypulseconnected toD6 PWMon Arduino Mega 2560
Servo 2
- Pins:
gndconnected to Groundvccconnected to Power supplypulseconnected toD3 PWMon Arduino Mega 2560
Servo 3
- Pins:
gndconnected to Groundvccconnected to Power supplypulseconnected toD4 PWMon Arduino Mega 2560
Servo 4
- Pins:
gndconnected to Groundvccconnected to Power supplypulseconnected toD5 PWMon Arduino Mega 2560
Analog Joystick
- Pins:
VCCconnected to Power supplyVERTconnected toA0on Arduino Mega 2560HORZconnected toA1on Arduino Mega 2560SELconnected toD2 PWMon Arduino Mega 2560GNDconnected to Ground
Documented Code
Arduino Mega 2560 Code
sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
documentation.txt
This documentation provides a comprehensive overview of the circuit, including a summary, detailed component descriptions, wiring details, and the code used in the microcontroller.