
Arduino Mega 2560 Based Position Tracking System with AS5048 Magnetic Encoder
View and Edit Project In Cirkit Designer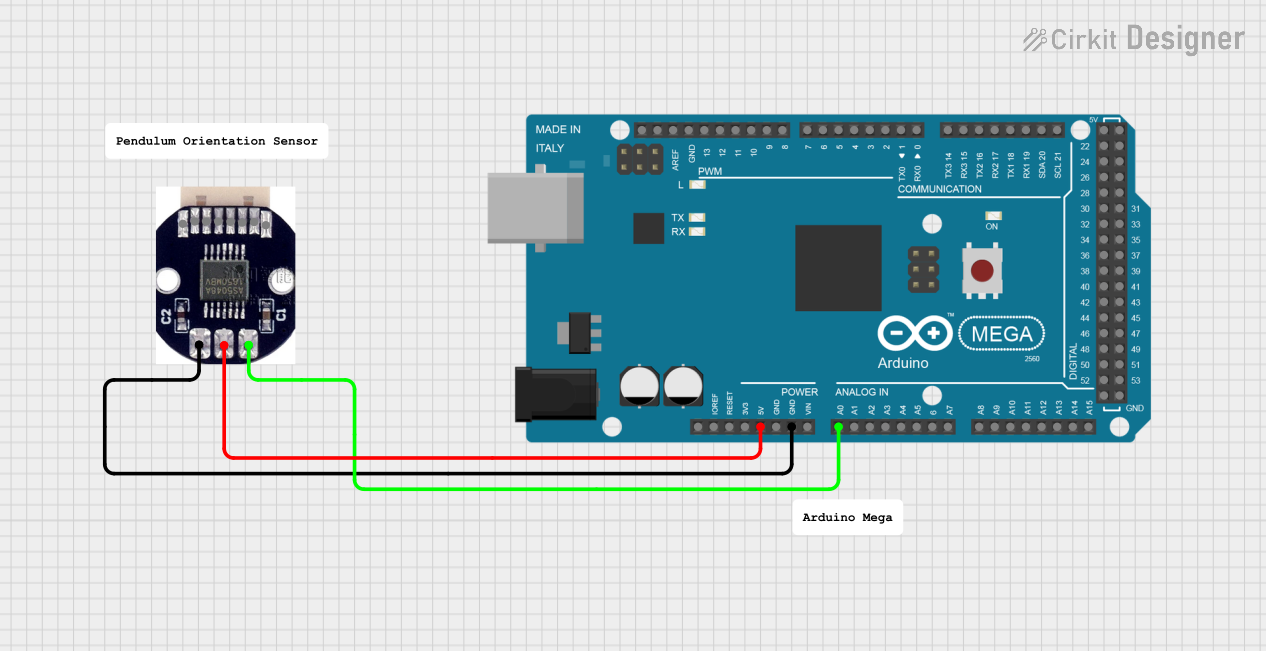
Circuit Documentation
Summary of the Circuit
This circuit consists of an Arduino Mega 2560 microcontroller which serves as the central processing unit, interfacing with an AS5048 Magnetic Encoder Position Sensor. The sensor is used to measure the absolute angle of a rotating magnetic field. The Arduino Mega 2560 provides power to the sensor and reads the PWM signal output from the sensor to determine the position.
Component List
Arduino Mega 2560
- Description: A microcontroller board based on the ATmega2560.
- Purpose: Acts as the central processing unit for the circuit, providing I/O capabilities and processing the sensor data.
- Pins: IOREF, RESET, 3V3, 5V, GND, VIN, Analog Pins (A0-A15), Digital Pins (D0-D53), PWM Pins, AREF, SDA, SCL.
AS5048 Magnetic Encoder Position Sensor
- Description: A magnetic rotary position sensor which provides a 14-bit resolution measurement.
- Purpose: Measures the absolute angle of a rotating magnetic field.
- Pins: GND, nCS, CLK, MOSI, MISO, VDD5V, PWM.
Comments
- Description: Textual annotations for the circuit.
- Purpose: Provide additional information or instructions regarding the circuit design or functionality.
Wiring Details
Arduino Mega 2560
- 5V connected to AS5048 Sensor VDD5V
- GND connected to AS5048 Sensor GND
- A0 connected to AS5048 Sensor PWM
AS5048 Magnetic Encoder Position Sensor
- VDD5V connected to Arduino Mega 2560 5V
- GND connected to Arduino Mega 2560 GND
- PWM connected to Arduino Mega 2560 A0
Documented Code
Arduino Mega 2560 Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Additional Notes
- The code provided for the Arduino Mega 2560 is a template with empty setup and loop functions. This code needs to be completed with the logic for initializing the sensor and reading the PWM signal to determine the position.
- The documentation file associated with the microcontroller is currently empty and can be used to provide detailed information about the code and its functionality.