
Circuit Documentation
Summary of the Circuit
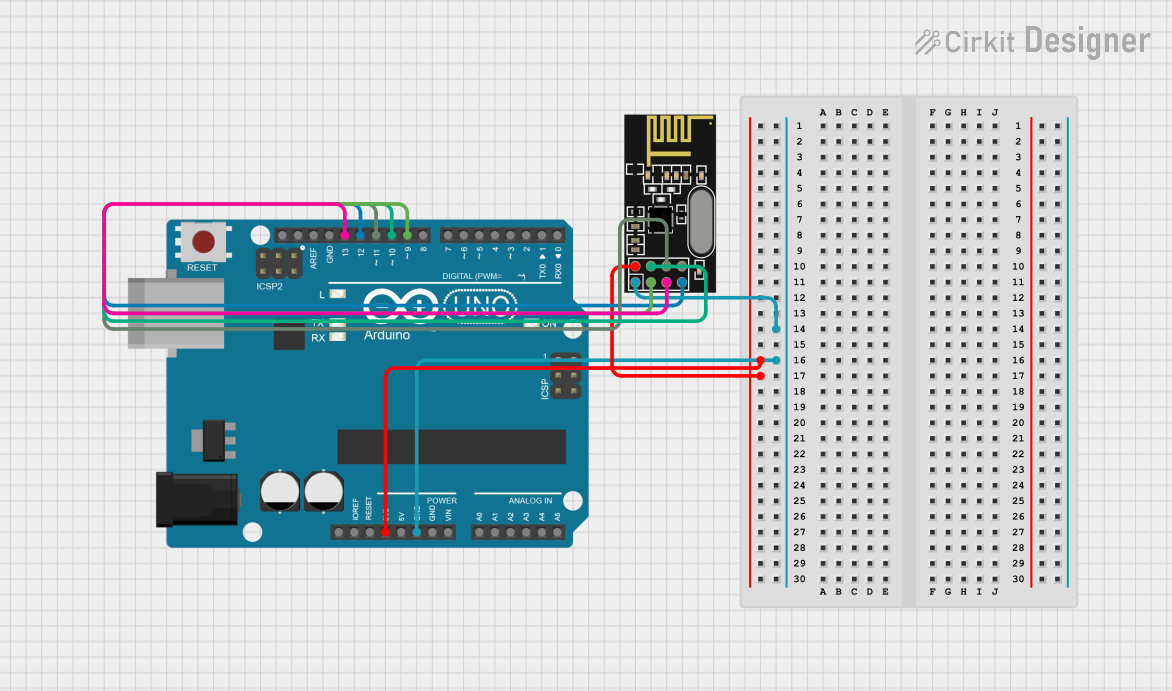
This circuit integrates an Arduino UNO microcontroller board with an NRF24L01 wireless transceiver module. The purpose of the circuit is to establish a wireless communication link, allowing the Arduino UNO to send data packets through the NRF24L01 module. The Arduino UNO is programmed to send a "Hello World" message at regular intervals using the SPI communication protocol.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13.
- Purpose: Acts as the main controller and SPI master for the NRF24L01 module.
NRF24L01
- Description: A 2.4GHz wireless transceiver module.
- Pins: IRQ (not used), MOSI, CSN, VCC (3V), GND, CE, SCK, MISO.
- Purpose: Provides wireless communication capabilities to the Arduino UNO.
Wiring Details
Arduino UNO
- 3.3V connected to NRF24L01 VCC (3V)
- GND connected to NRF24L01 GND
- D13 (SCK) connected to NRF24L01 SCK
- D12 (MISO) connected to NRF24L01 MISO
- D11 (MOSI) connected to NRF24L01 MOSI
- D10 (CSN) connected to NRF24L01 CSN
- D9 (CE) connected to NRF24L01 CE
NRF24L01
- VCC (3V) connected to Arduino UNO 3.3V
- GND connected to Arduino UNO GND
- CE connected to Arduino UNO D9
- CSN connected to Arduino UNO D10
- SCK connected to Arduino UNO D13
- MISO connected to Arduino UNO D12
- MOSI connected to Arduino UNO D11
Documented Code
sketch.ino
#include <SPI.h>
#include <nRF24L01.h>
#include <RF24.h>

RF24 radio(9, 10); // CE, CSN

const byte address[6] = "00001";

void setup() {
  radio.begin();
  radio.openWritingPipe(address);
  radio.setPALevel(RF24_PA_MIN);
  radio.stopListening();
}

void loop() {
  const char text[] = "Hello World";
  radio.write(&text, sizeof(text));
  delay(1000);
}
Description: This code initializes the RF24 library with the pins connected to the CE and CSN pins of the NRF24L01 module. It sets up the wireless communication parameters and sends the "Hello World" message repeatedly every second.
documentation.txt
This file is intended for additional documentation, but it is currently empty.