
Arduino Mega 2560 Controlled Quadruple DC Motor System with Encoders
View and Edit Project In Cirkit Designer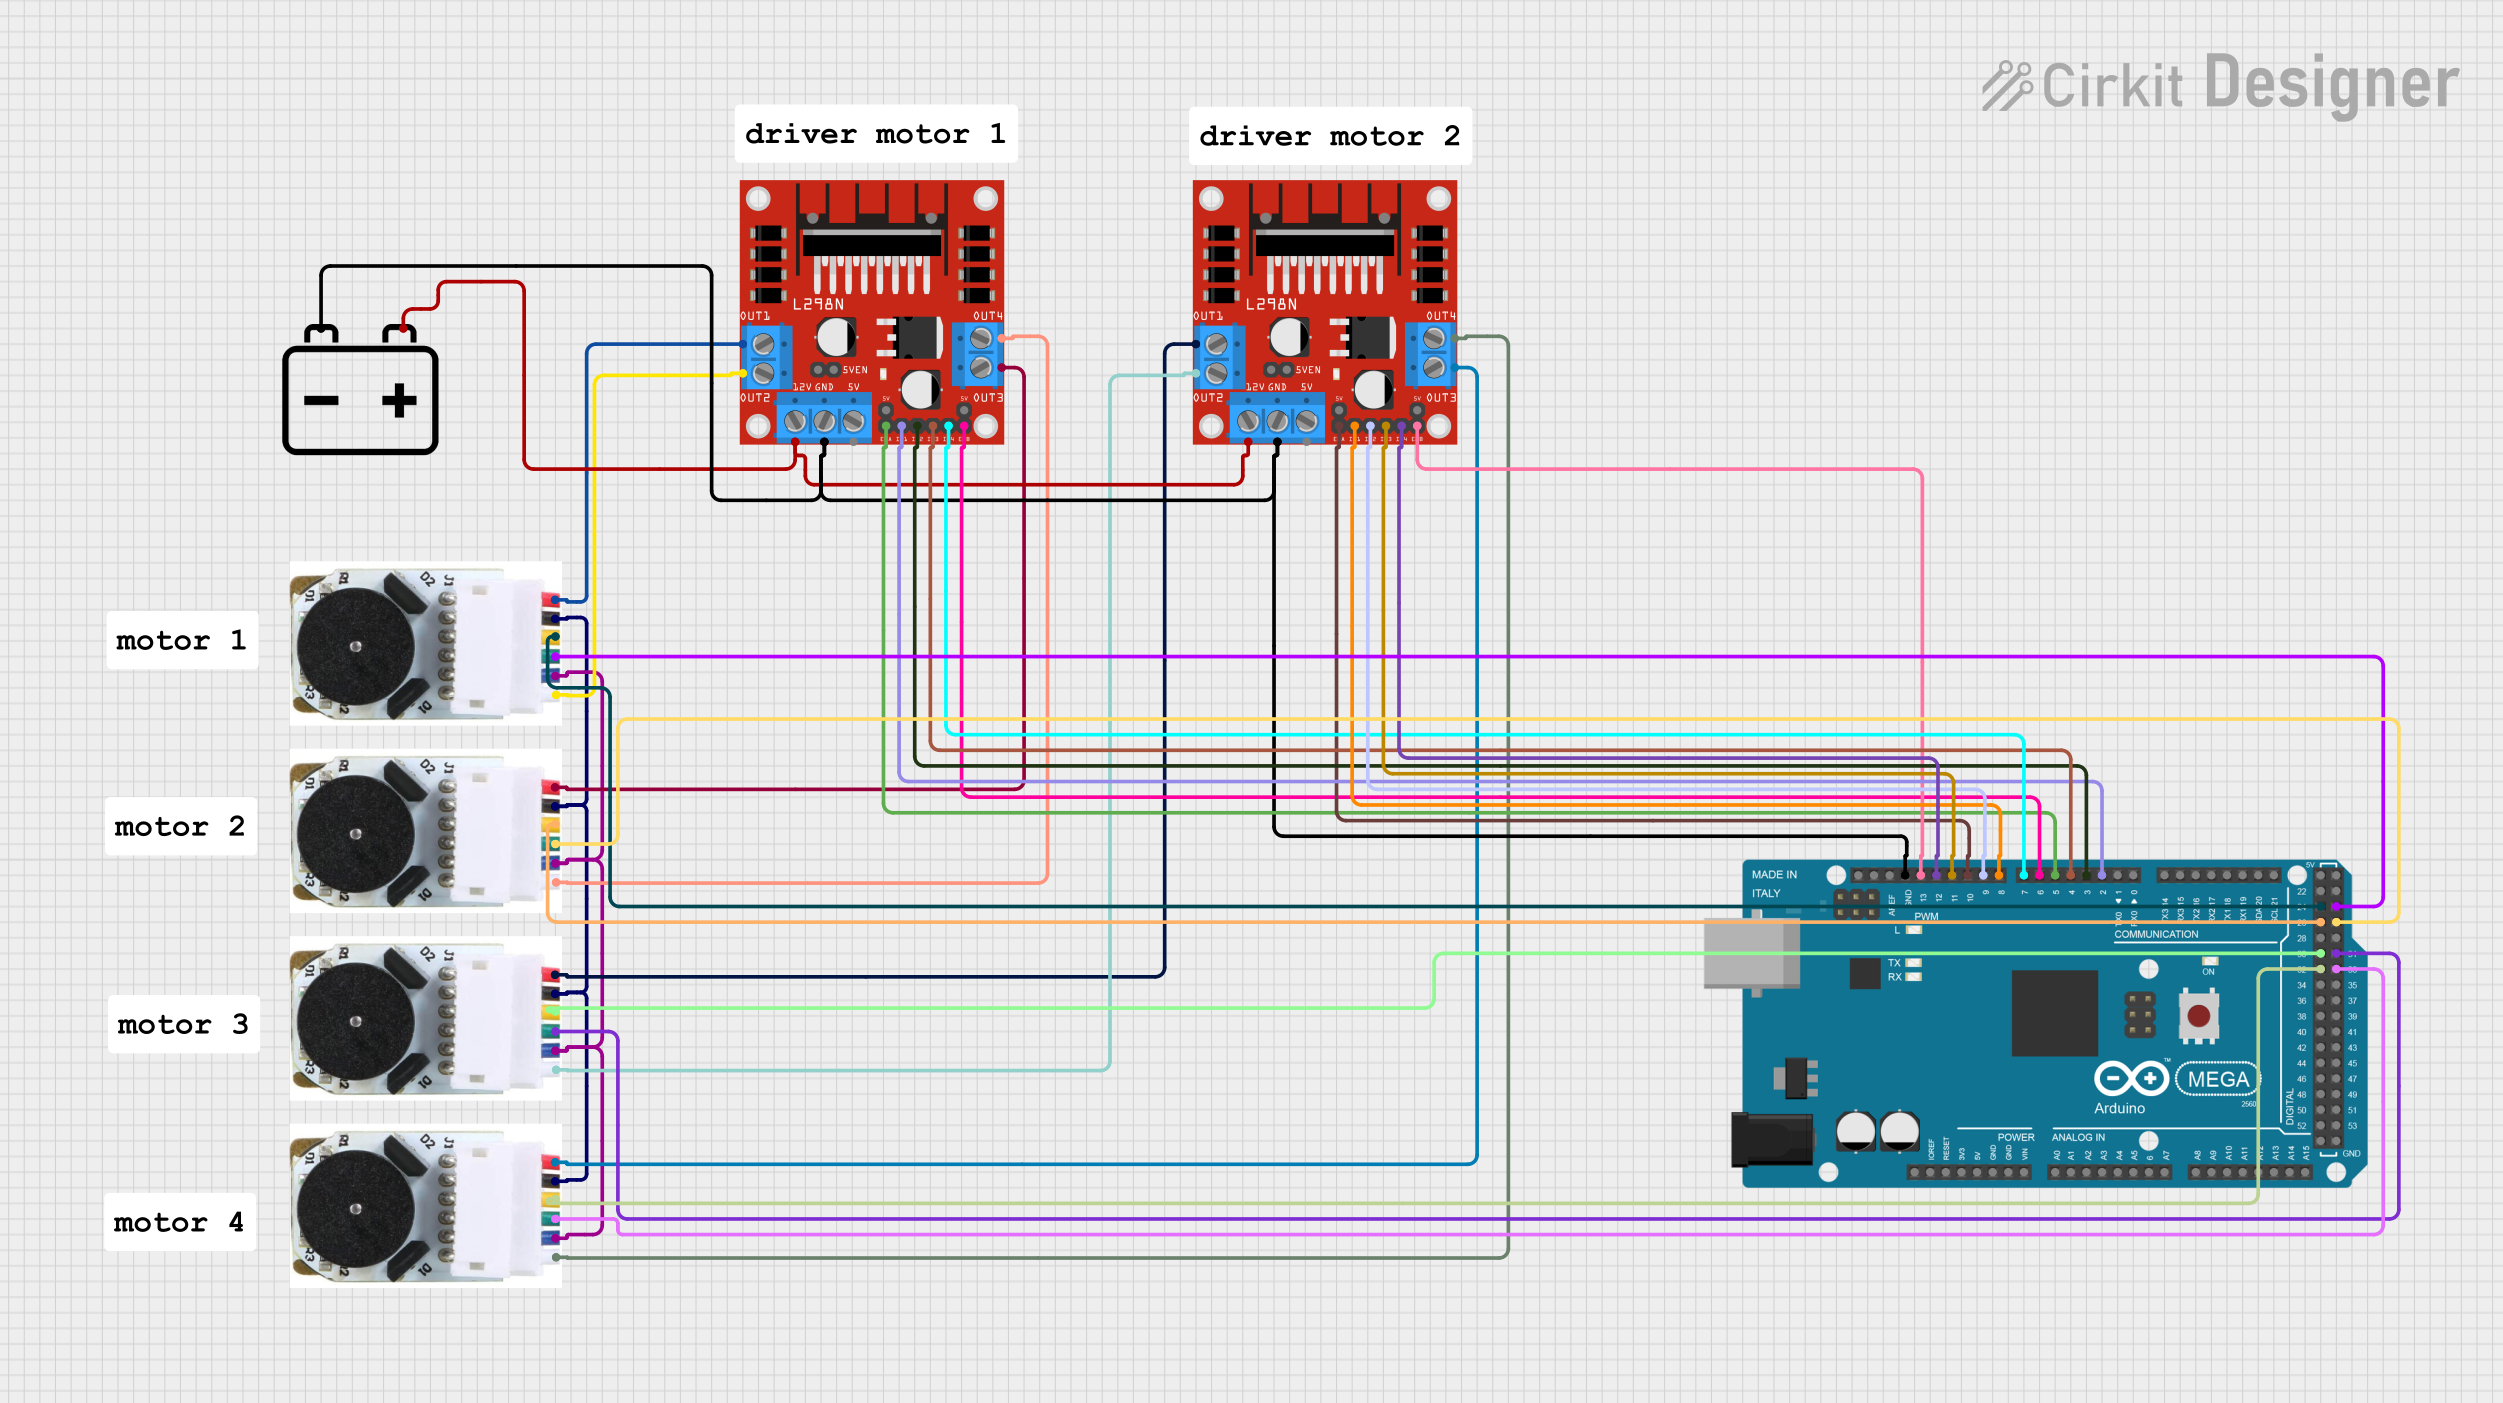
Circuit Documentation
Summary
The circuit in question is designed to control four DC motors with encoders using an Arduino Mega 2560 microcontroller and two L298N DC motor drivers. The motors are equipped with encoders for feedback on their rotational position. The Arduino Mega 2560 provides the control signals to the L298N drivers, which in turn drive the motors. A 12V battery is used to power the motor drivers and the motors.
Component List
Arduino Mega 2560
- Microcontroller board based on the ATmega2560
- It has 54 digital input/output pins (of which 15 can be used as PWM outputs), 16 analog inputs, 4 UARTs (hardware serial ports), a 16 MHz crystal oscillator, a USB connection, a power jack, an ICSP header, and a reset button.
DC Motor with Encoder (x4)
- A DC motor that comes with an attached encoder.
- The encoder provides feedback on the motor's rotational position, which can be used for precise control of the motor.
L298N DC Motor Driver (x2)
- A motor driver module based on the L298N H-bridge.
- It can drive two DC motors or one stepper motor.
- It has an onboard 5V regulator which can be enabled using a jumper.
12V Battery
- A power source for the motor drivers and motors.
- Provides the necessary voltage and current to drive the motors.
Comments
- There are several comment components included in the parts list, which are likely used for annotation purposes within the circuit design software.
Wiring Details
Arduino Mega 2560
- D2 PWM to L298N Driver IN1
- D3 PWM to L298N Driver IN2
- D4 PWM to L298N Driver IN3
- D5 PWM to L298N Driver ENA
- D6 PWM to L298N Driver ENB
- D7 PWM to L298N Driver IN4
- D8 PWM to L298N Driver IN1
- D9 PWM to L298N Driver IN2
- D10 PWM to L298N Driver ENA
- D11 PWM to L298N Driver IN3
- D12 PWM to L298N Driver IN4
- D13 PWM to L298N Driver ENB
- D24 to DC Motor Encoder A
- D25 to DC Motor Encoder B
- D26 to DC Motor Encoder A
- D27 to DC Motor Encoder B
- D30 to DC Motor Encoder A
- D31 to DC Motor Encoder B
- D32 to DC Motor Encoder A
- D33 to DC Motor Encoder B
- GND to L298N Driver GND (Common Ground)
DC Motor with Encoder
- Encoder A to Arduino Mega 2560 (D24, D26, D30, D32)
- Encoder B to Arduino Mega 2560 (D25, D27, D31, D33)
- GND - Encoder to Common Ground
- VCC - Encoder Power to Common Power Rail
- Motor +ve to L298N Driver OUT1/OUT3
- Motor -ve to L298N Driver OUT2/OUT4
L298N DC Motor Driver
- IN1, IN2, IN3, IN4 to Arduino Mega 2560 (D2, D3, D4, D7, D8, D9, D11, D12)
- ENA, ENB to Arduino Mega 2560 (D5, D6, D10, D13)
- OUT1, OUT2, OUT3, OUT4 to DC Motors
- 12V to 12V Battery +
- GND to Common Ground
12V Battery
-
- to L298N Driver 12V
-
- to Common Ground
Documented Code
sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
documentation.txt
The provided code file documentation.txt is empty and does not contain any code or comments.