
Circuit Documentation
Summary of the Circuit
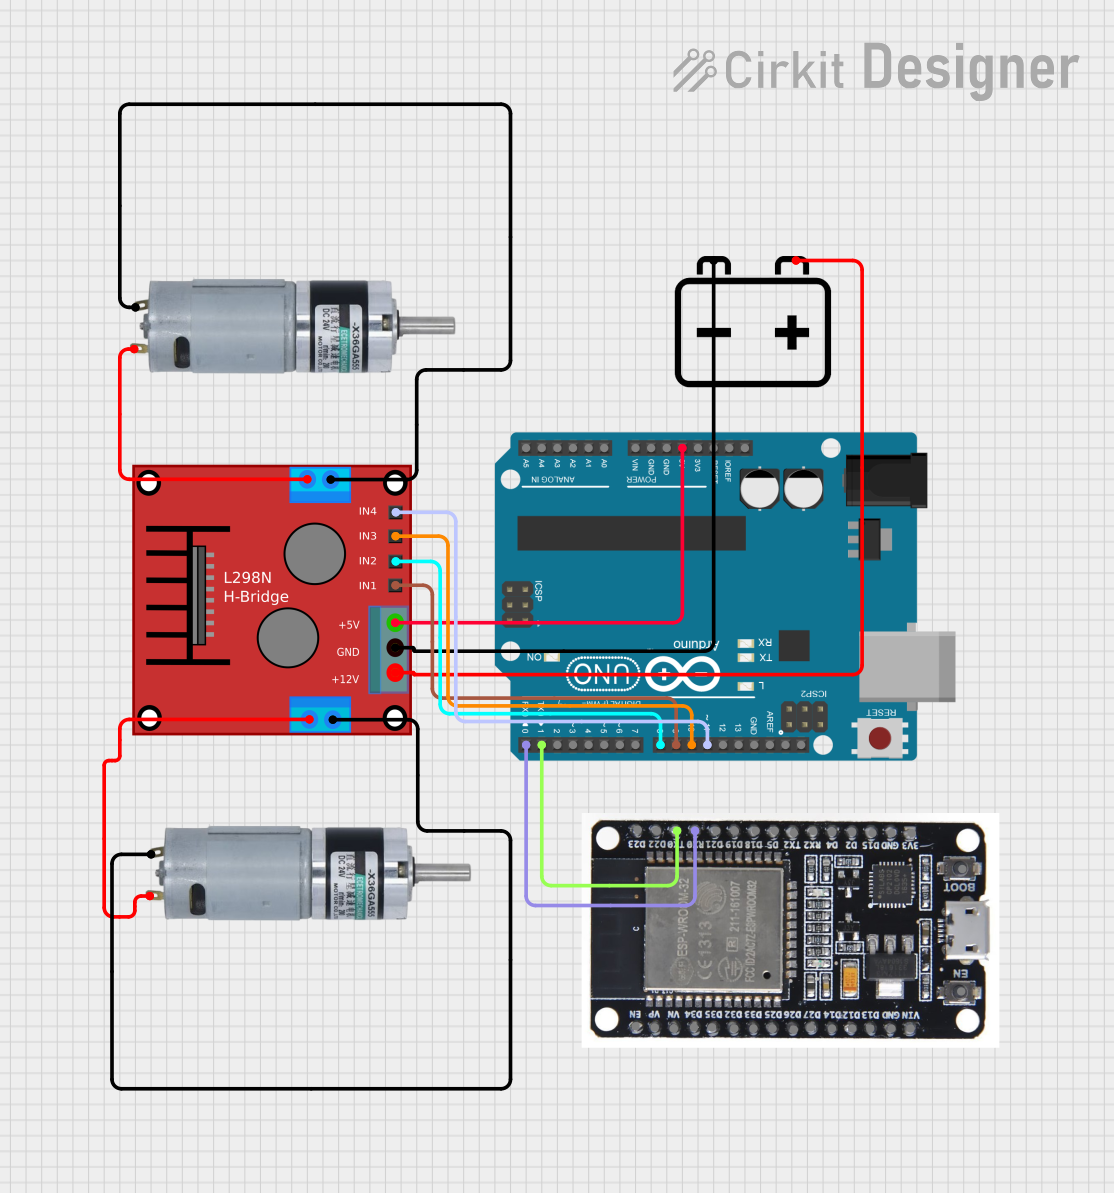
This circuit integrates an Arduino UNO microcontroller with an ESP32 module, a ponte H motor driver, two MRB Planetary gearbox motors, and a 12V battery. The Arduino UNO is responsible for controlling the motor driver, which in turn drives the two motors. The ESP32 is connected to the Arduino UNO for potential communication between the two microcontrollers. The 12V battery provides power to the motor driver, which controls the motors' operation.
Component List
Arduino UNO
- Microcontroller board based on the ATmega328P
- It has 14 digital input/output pins, 6 analog inputs, a 16 MHz quartz crystal, a USB connection, a power jack, an ICSP header, and a reset button.
Ponte H (Motor Driver)
- An H-bridge circuit that allows voltage to be applied across a load in either direction
- Commonly used to control the speed and direction of motors.
MRB Planetary Gearbox Motor (x2)
- A DC motor with a gearbox for increased torque
- Utilized for applications requiring high torque and precision.
12V Battery
- Provides the power source for the motor driver and motors
- Ensures that the motors can operate independently of the microcontroller's power supply.
ESP32
- A microcontroller with integrated Wi-Fi and Bluetooth
- Suitable for a variety of applications ranging from low-power sensor networks to more demanding tasks such as voice encoding, music streaming, and MP3 decoding.
Wiring Details
Arduino UNO
- 5V connected to the 5V of the ponte H
- D11 connected to IN4 of the ponte H
- D10 connected to IN3 of the ponte H
- D9 connected to IN1 of the ponte H
- D8 connected to IN2 of the ponte H
- D1 (TX) connected to TX0 of the ESP32
- D0 (RX) connected to RX0 of the ESP32
Ponte H (Motor Driver)
- 5V connected to the 5V of the Arduino UNO
- IN4 connected to D11 of the Arduino UNO
- IN3 connected to D10 of the Arduino UNO
- IN1 connected to D9 of the Arduino UNO
- IN2 connected to D8 of the Arduino UNO
- OUT4-Motor2 connected to the negative terminal of Motor 2
- OUT3-Motor2 connected to the positive terminal of Motor 2
- OUT2-Motor1 connected to the negative terminal of Motor 1
- OUT1-Motor1 connected to the positive terminal of Motor 1
- GND connected to the negative terminal of the 12V Battery
- 12V connected to the positive terminal of the 12V Battery
MRB Planetary Gearbox Motor 1
- + connected to OUT1-Motor1 of the ponte H
- - connected to OUT2-Motor1 of the ponte H
MRB Planetary Gearbox Motor 2
- + connected to OUT3-Motor2 of the ponte H
- - connected to OUT4-Motor2 of the ponte H
12V Battery
- + connected to the 12V of the ponte H
- - connected to the GND of the ponte H
ESP32
- TX0 connected to D1 (TX) of the Arduino UNO
- RX0 connected to D0 (RX) of the Arduino UNO
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
ESP32 Code
No code provided for the ESP32.
This documentation provides an overview of the circuit, including a description of each component, their wiring connections, and the code for the Arduino UNO. The ESP32 code section is left blank as no code was provided.