
Bluetooth-Controlled Robotic Vehicle with Ultrasonic Obstacle Detection
View and Edit Project In Cirkit Designer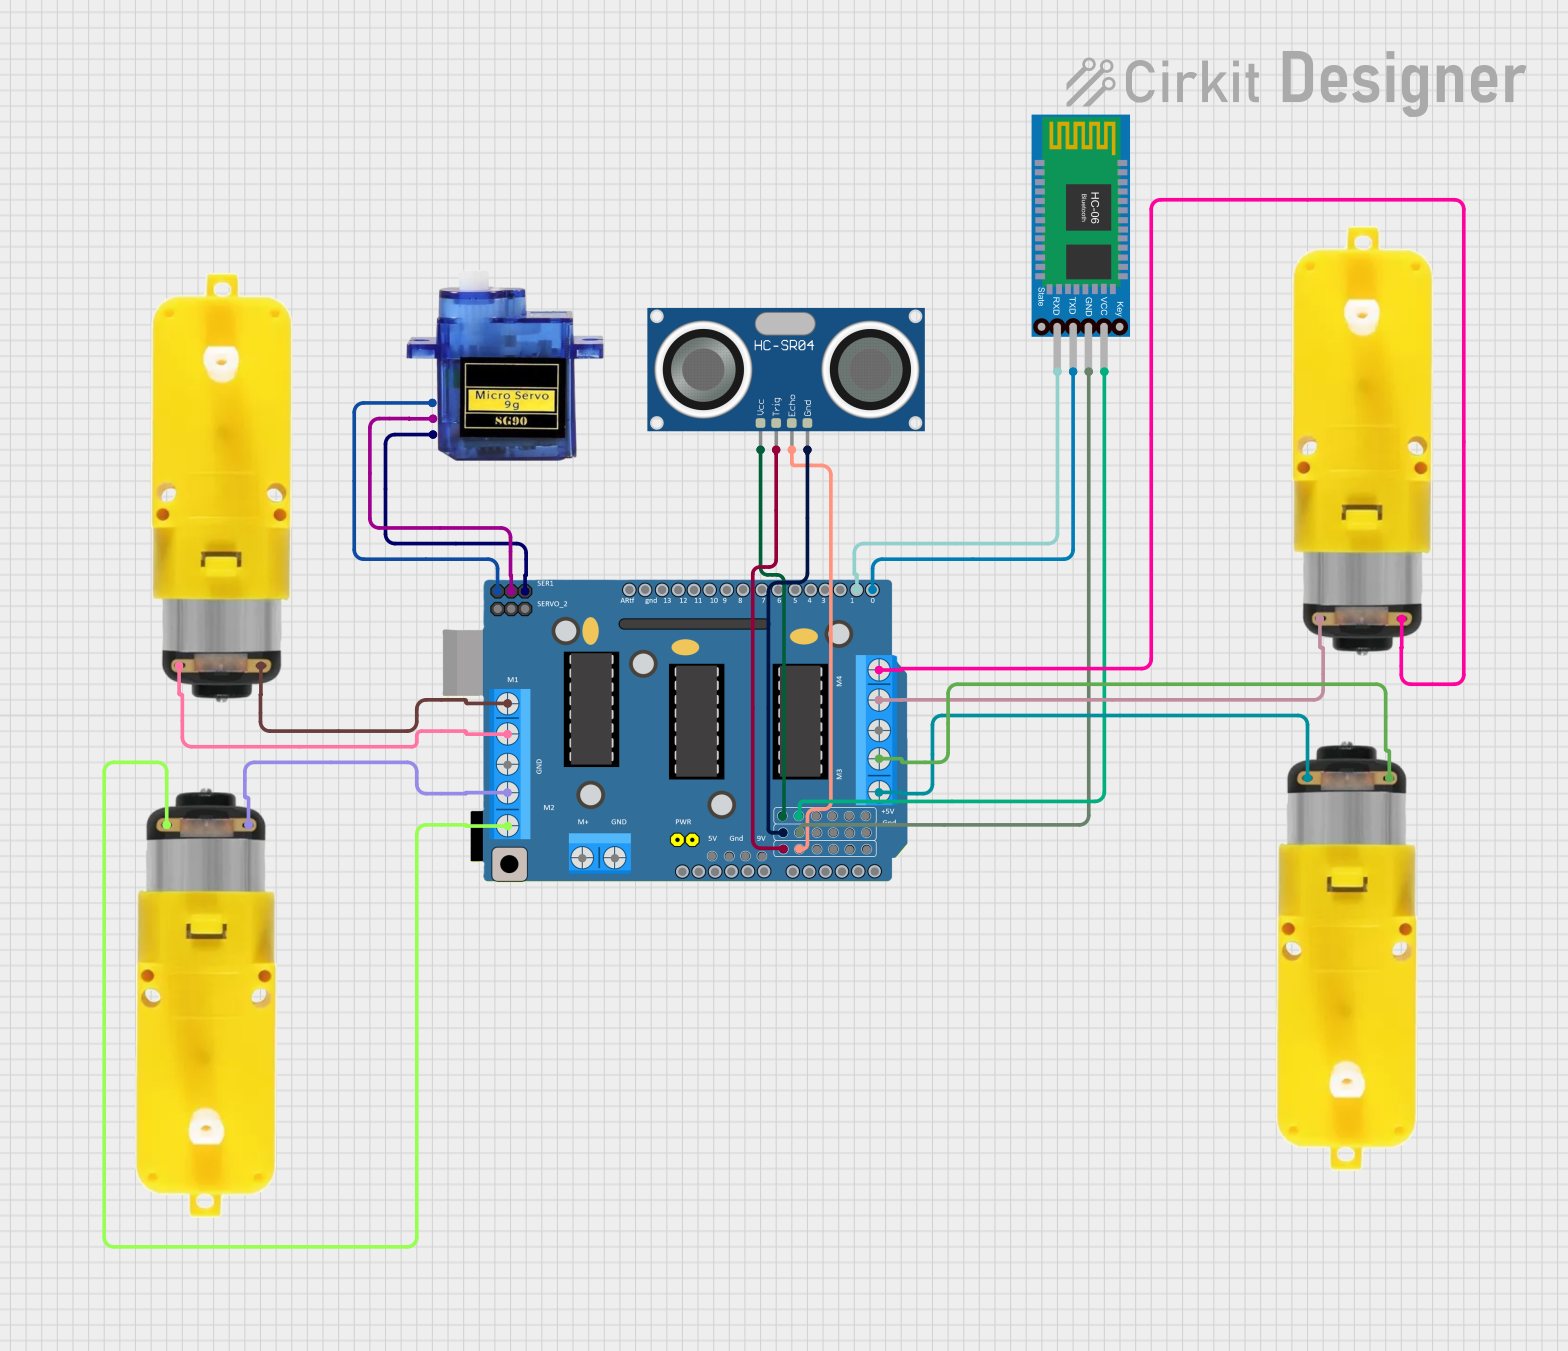
Circuit Documentation
Summary
The circuit in question is designed to control a set of motors and a servo using a DRIVER SHIELD L293D, interfaced with an HC-SR04 Ultrasonic Sensor and a Bluetooth HC-06 module for wireless communication. The circuit is powered through the DRIVER SHIELD L293D, which also provides power to the other components. The motors are controlled by the DRIVER SHIELD L293D, which receives control signals from a microcontroller (not specified in the provided data). The HC-SR04 Ultrasonic Sensor is used for distance measurement, and the Bluetooth HC-06 module enables wireless communication.
Component List
DRIVER SHIELD L293D
- Description: A motor driver shield based on the L293D driver IC. It can drive up to 4 DC motors with individual speed control or 2 stepper motors.
- Pins: RESET, 3.3V, 5V, GND, VIN, 9V, A0-A5, M1-M4 (+/-), SERVO_1, SERVO_2, RX/D0, TX/D1, D2-D13, ARef, VCC (External Power Supply), GND (External Power Supply)
Micro servo 9G
- Description: A small and lightweight servo motor suitable for various applications requiring precise control.
- Pins: GND, +5V, PWM
HC-SR04 Ultrasonic Sensor
- Description: An ultrasonic distance sensor capable of measuring distances by emitting ultrasonic waves and measuring the time taken for the echo to return.
- Pins: VCC, TRIG, ECHO, GND
Bluetooth HC-06
- Description: A Bluetooth module that allows for serial communication over Bluetooth.
- Pins: VCC, GND, TXD, RXD
Motor with reducer (4 instances)
- Description: A DC motor with a gear reducer to provide high torque at lower speeds.
- Pins: 3 - 6 VCC, GND
Wiring Details
DRIVER SHIELD L293D
- A0 connected to HC-SR04 Ultrasonic Sensor TRIG
- A1 connected to HC-SR04 Ultrasonic Sensor ECHO
- GND connected to HC-SR04 Ultrasonic Sensor GND, Bluetooth HC-06 GND, Micro servo 9G GND, and all Motor with reducer GND
- 5V connected to Bluetooth HC-06 VCC, HC-SR04 Ultrasonic Sensor VCC, and Micro servo 9G +5V
- M1 (+) connected to Motor with reducer VCC
- M1 GND (-) connected to Motor with reducer GND
- M2 (+) connected to Motor with reducer VCC
- M2 GND (-) connected to Motor with reducer GND
- M3 (+) connected to Motor with reducer VCC
- M3 GND (-) connected to Motor with reducer GND
- M4 (+) connected to Motor with reducer VCC
- M4 GND (-) connected to Motor with reducer GND
- SERVO_1 connected to Micro servo 9G PWM
- RX/D0 connected to Bluetooth HC-06 TXD
- TX/D1 connected to Bluetooth HC-06 RXD
Micro servo 9G
- GND connected to DRIVER SHIELD L293D GND
- +5V connected to DRIVER SHIELD L293D 5V
- PWM connected to DRIVER SHIELD L293D SERVO_1
HC-SR04 Ultrasonic Sensor
- VCC connected to DRIVER SHIELD L293D 5V
- TRIG connected to DRIVER SHIELD L293D A0
- ECHO connected to DRIVER SHIELD L293D A1
- GND connected to DRIVER SHIELD L293D GND
Bluetooth HC-06
- VCC connected to DRIVER SHIELD L293D 5V
- GND connected to DRIVER SHIELD L293D GND
- TXD connected to DRIVER SHIELD L293D RX/D0
- RXD connected to DRIVER SHIELD L293D TX/D1
Motor with reducer
- 3 - 6 VCC connected to DRIVER SHIELD L293D M1 (+), M2 (+), M3 (+), M4 (+) respectively for each motor instance
- GND connected to DRIVER SHIELD L293D M1 GND (-), M2 GND (-), M3 GND (-), M4 GND (-) respectively for each motor instance
Documented Code
No code was provided for the microcontrollers in the circuit. The documentation of the code would typically include descriptions of the functions, algorithms, and control logic used to operate the motors, read sensor data, and handle Bluetooth communication. Without the code, this section cannot be completed.