
ESP32-Based Remote-Controlled Servo System with GPS and IMU Integration
View and Edit Project In Cirkit Designer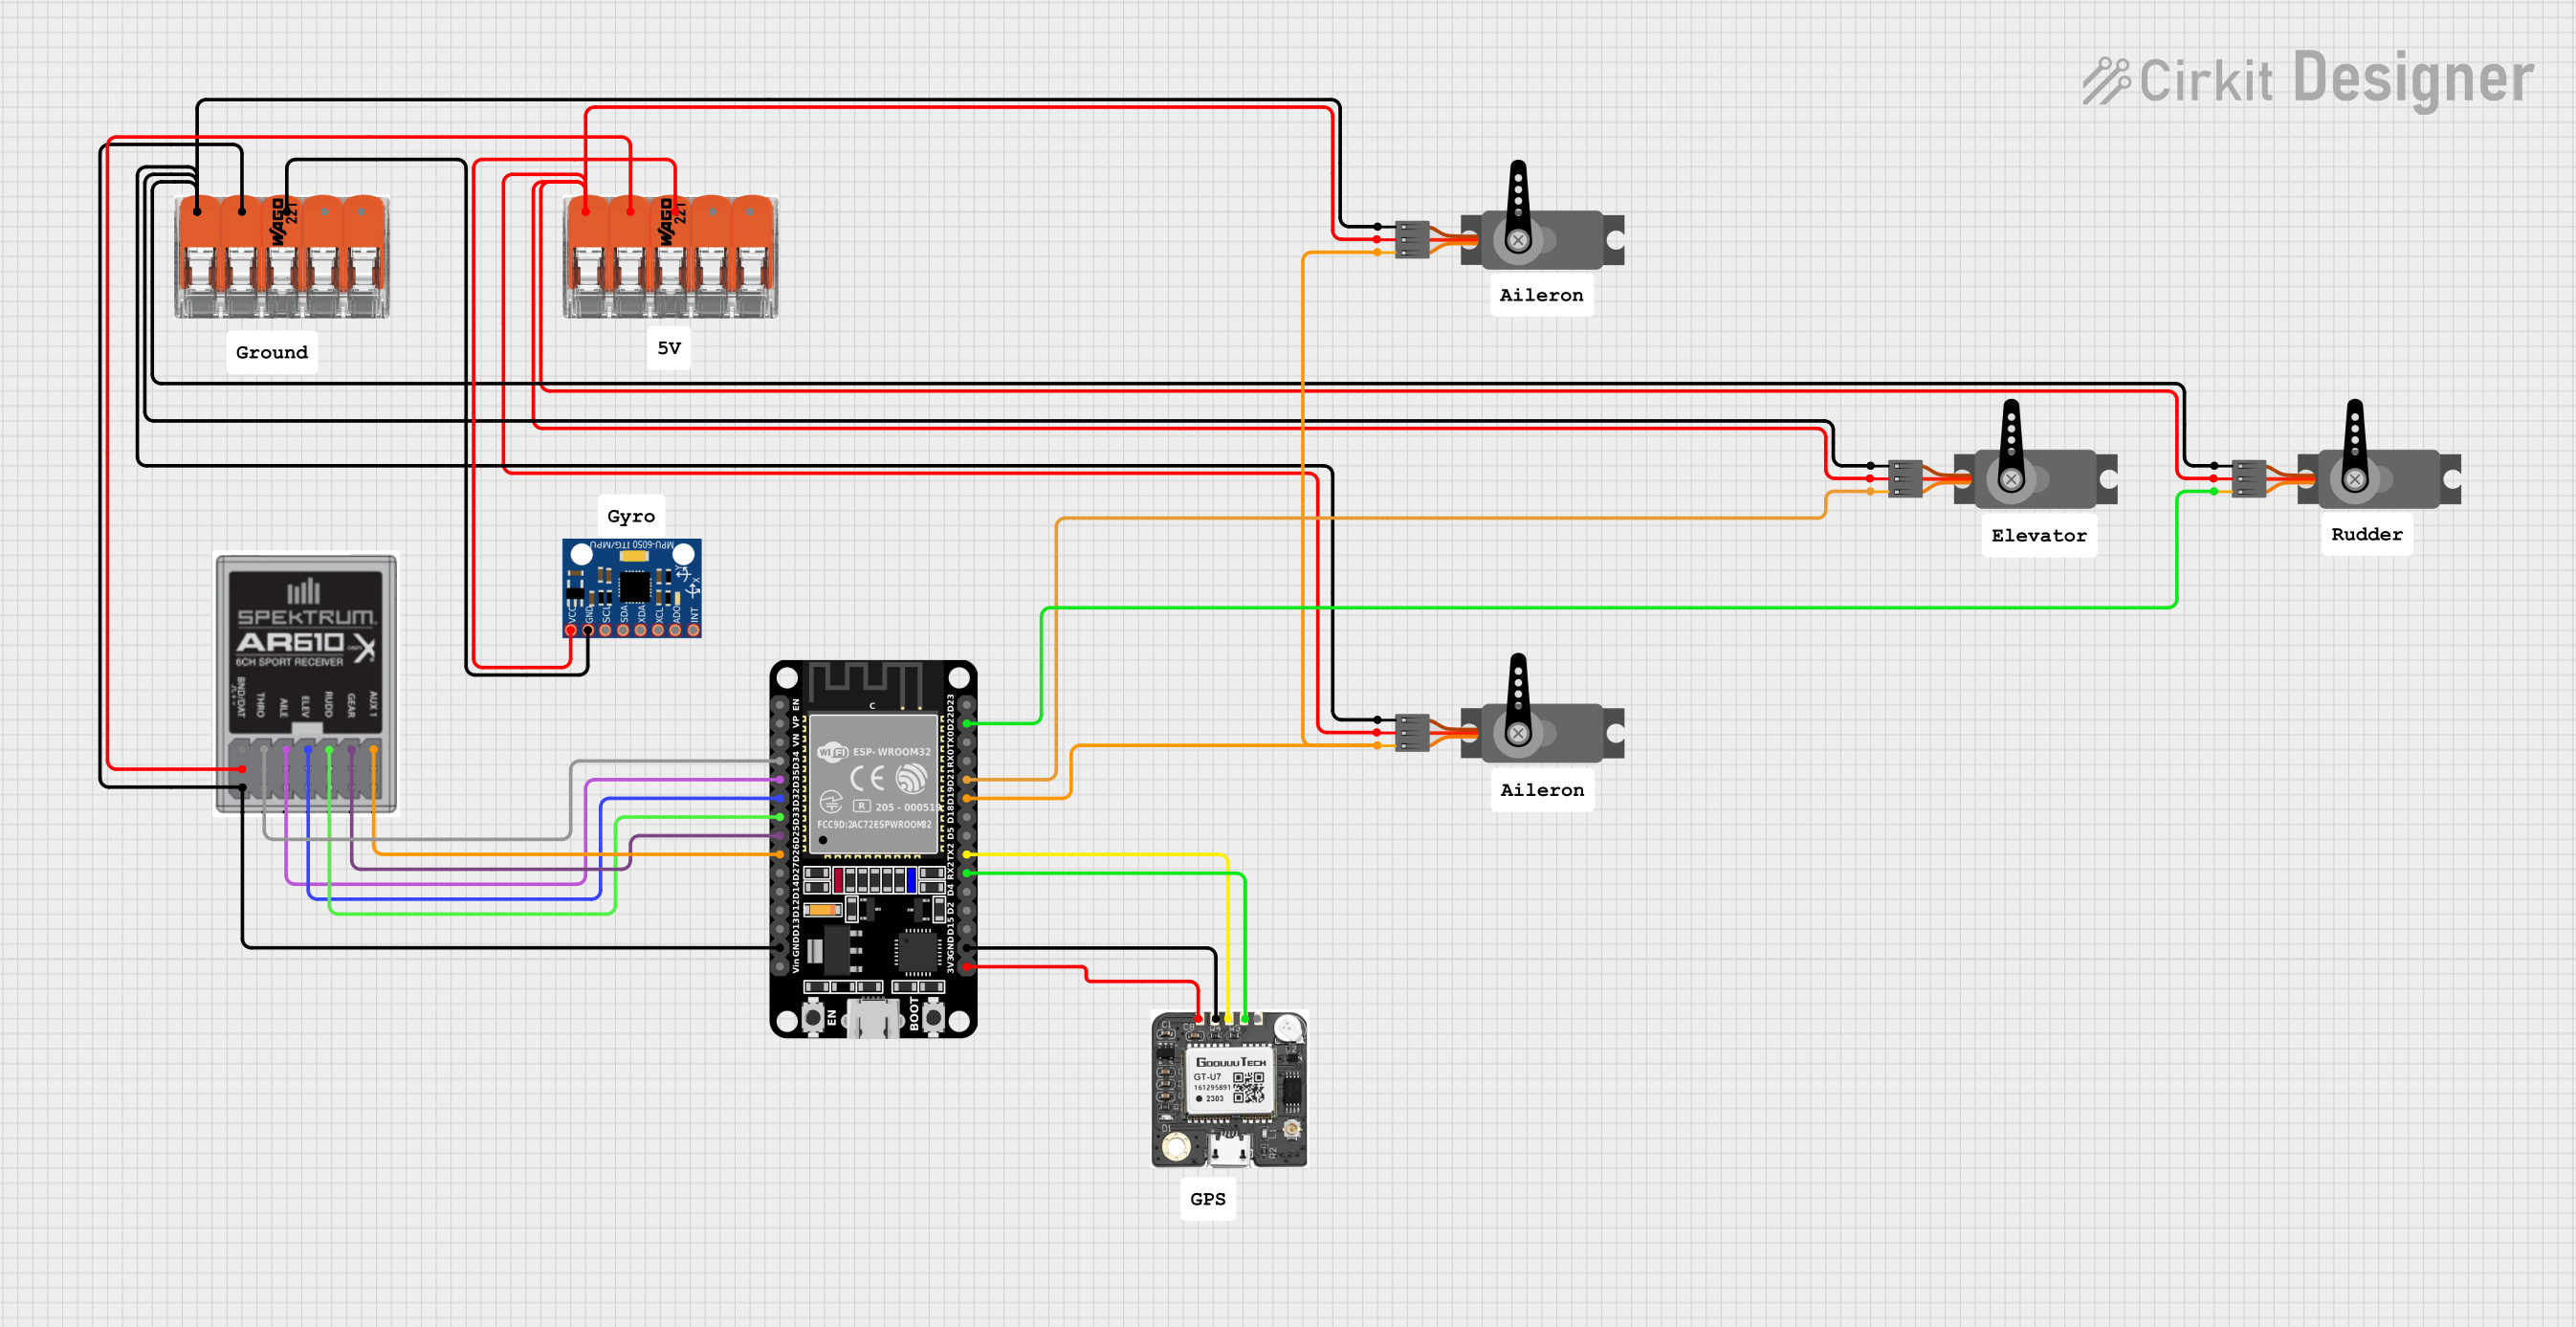
Circuit Documentation
Summary
This document provides a detailed overview of a circuit that includes an ESP32 microcontroller, an MPU-6050 accelerometer and gyroscope, a Neo 6M GPS module, multiple servos, and an AR610 receiver. The circuit is designed to interface these components for various control and sensing applications.
Component List
ESP32 (30 pin)
- Description: A powerful microcontroller with Wi-Fi and Bluetooth capabilities.
- Pins: EN, VP, VN, D34, D35, D32, D33, D25, D26, D27, D14, D12, D13, GND, Vin, D23, D22, TX0, RX0, D21, D19, D18, D5, TX2, RX2, D4, D2, D15, 3V3
MPU-6050
- Description: A 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer.
- Pins: VCC, GND, SCL, SDA, XDA, XCL, AD0, INT
Neo 6M GPS
- Description: A GPS module used for obtaining geographical location data.
- Pins: VCC, GND, RXD, TXD, PPS
Servo
- Description: A motor used for precise control of angular position.
- Pins: GND, VCC, PWM
AR610
- Description: A 6-channel receiver used for remote control applications.
- Pins: Bind, Throttle, Ailerons, Elevator, Rudder, Gear, Aux, Gnd, +5v
Splicing Connector WAGO 221
- Description: A splicing connector used for connecting multiple wires.
- Pins: Port 1, Port 2, Port 3, Port 4, Port 5
Wiring Details
ESP32 (30 pin)
- D34 is connected to Throttle of AR610.
- D35 is connected to Ailerons of AR610.
- D32 is connected to Elevator of AR610.
- D33 is connected to Rudder of AR610.
- D25 is connected to Gear of AR610.
- D26 is connected to Aux of AR610.
- GND is connected to Gnd of AR610 and Port 4 of Splicing Connector WAGO 221.
- D22 is connected to PWM of a Servo.
- D21 is connected to PWM of another Servo.
- D19 is connected to PWM of two Servos.
- TX2 is connected to RXD of Neo 6M GPS.
- RX2 is connected to TXD of Neo 6M GPS.
- GND is connected to GND of Neo 6M GPS.
- 3V3 is connected to VCC of Neo 6M GPS.
MPU-6050
- VCC is connected to Port 3 of Splicing Connector WAGO 221.
- GND is connected to Port 3 of another Splicing Connector WAGO 221.
Neo 6M GPS
- RXD is connected to TX2 of ESP32.
- TXD is connected to RX2 of ESP32.
- GND is connected to GND of ESP32.
- VCC is connected to 3V3 of ESP32.
Servo
- PWM of one Servo is connected to D22 of ESP32.
- PWM of another Servo is connected to D21 of ESP32.
- PWM of two Servos are connected to D19 of ESP32.
- GND of four Servos are connected to Port 5 of Splicing Connector WAGO 221.
- VCC of four Servos are connected to Port 5 of another Splicing Connector WAGO 221.
AR610
- Throttle is connected to D34 of ESP32.
- Ailerons is connected to D35 of ESP32.
- Elevator is connected to D32 of ESP32.
- Rudder is connected to D33 of ESP32.
- Gear is connected to D25 of ESP32.
- Aux is connected to D26 of ESP32.
- Gnd is connected to GND of ESP32 and Port 4 of Splicing Connector WAGO 221.
- +5v is connected to Port 4 of another Splicing Connector WAGO 221.
Splicing Connector WAGO 221
- Port 3 is connected to VCC of MPU-6050.
- Port 3 is connected to GND of MPU-6050.
- Port 4 is connected to GND of AR610 and GND of ESP32.
- Port 4 is connected to +5v of AR610.
- Port 5 is connected to GND of four Servos.
- Port 5 is connected to VCC of four Servos.
Code
No code is provided for this circuit.