
Arduino Mega 2560 Controlled Robotics Platform with Wireless NRF24L01 Communication
View and Edit Project In Cirkit Designer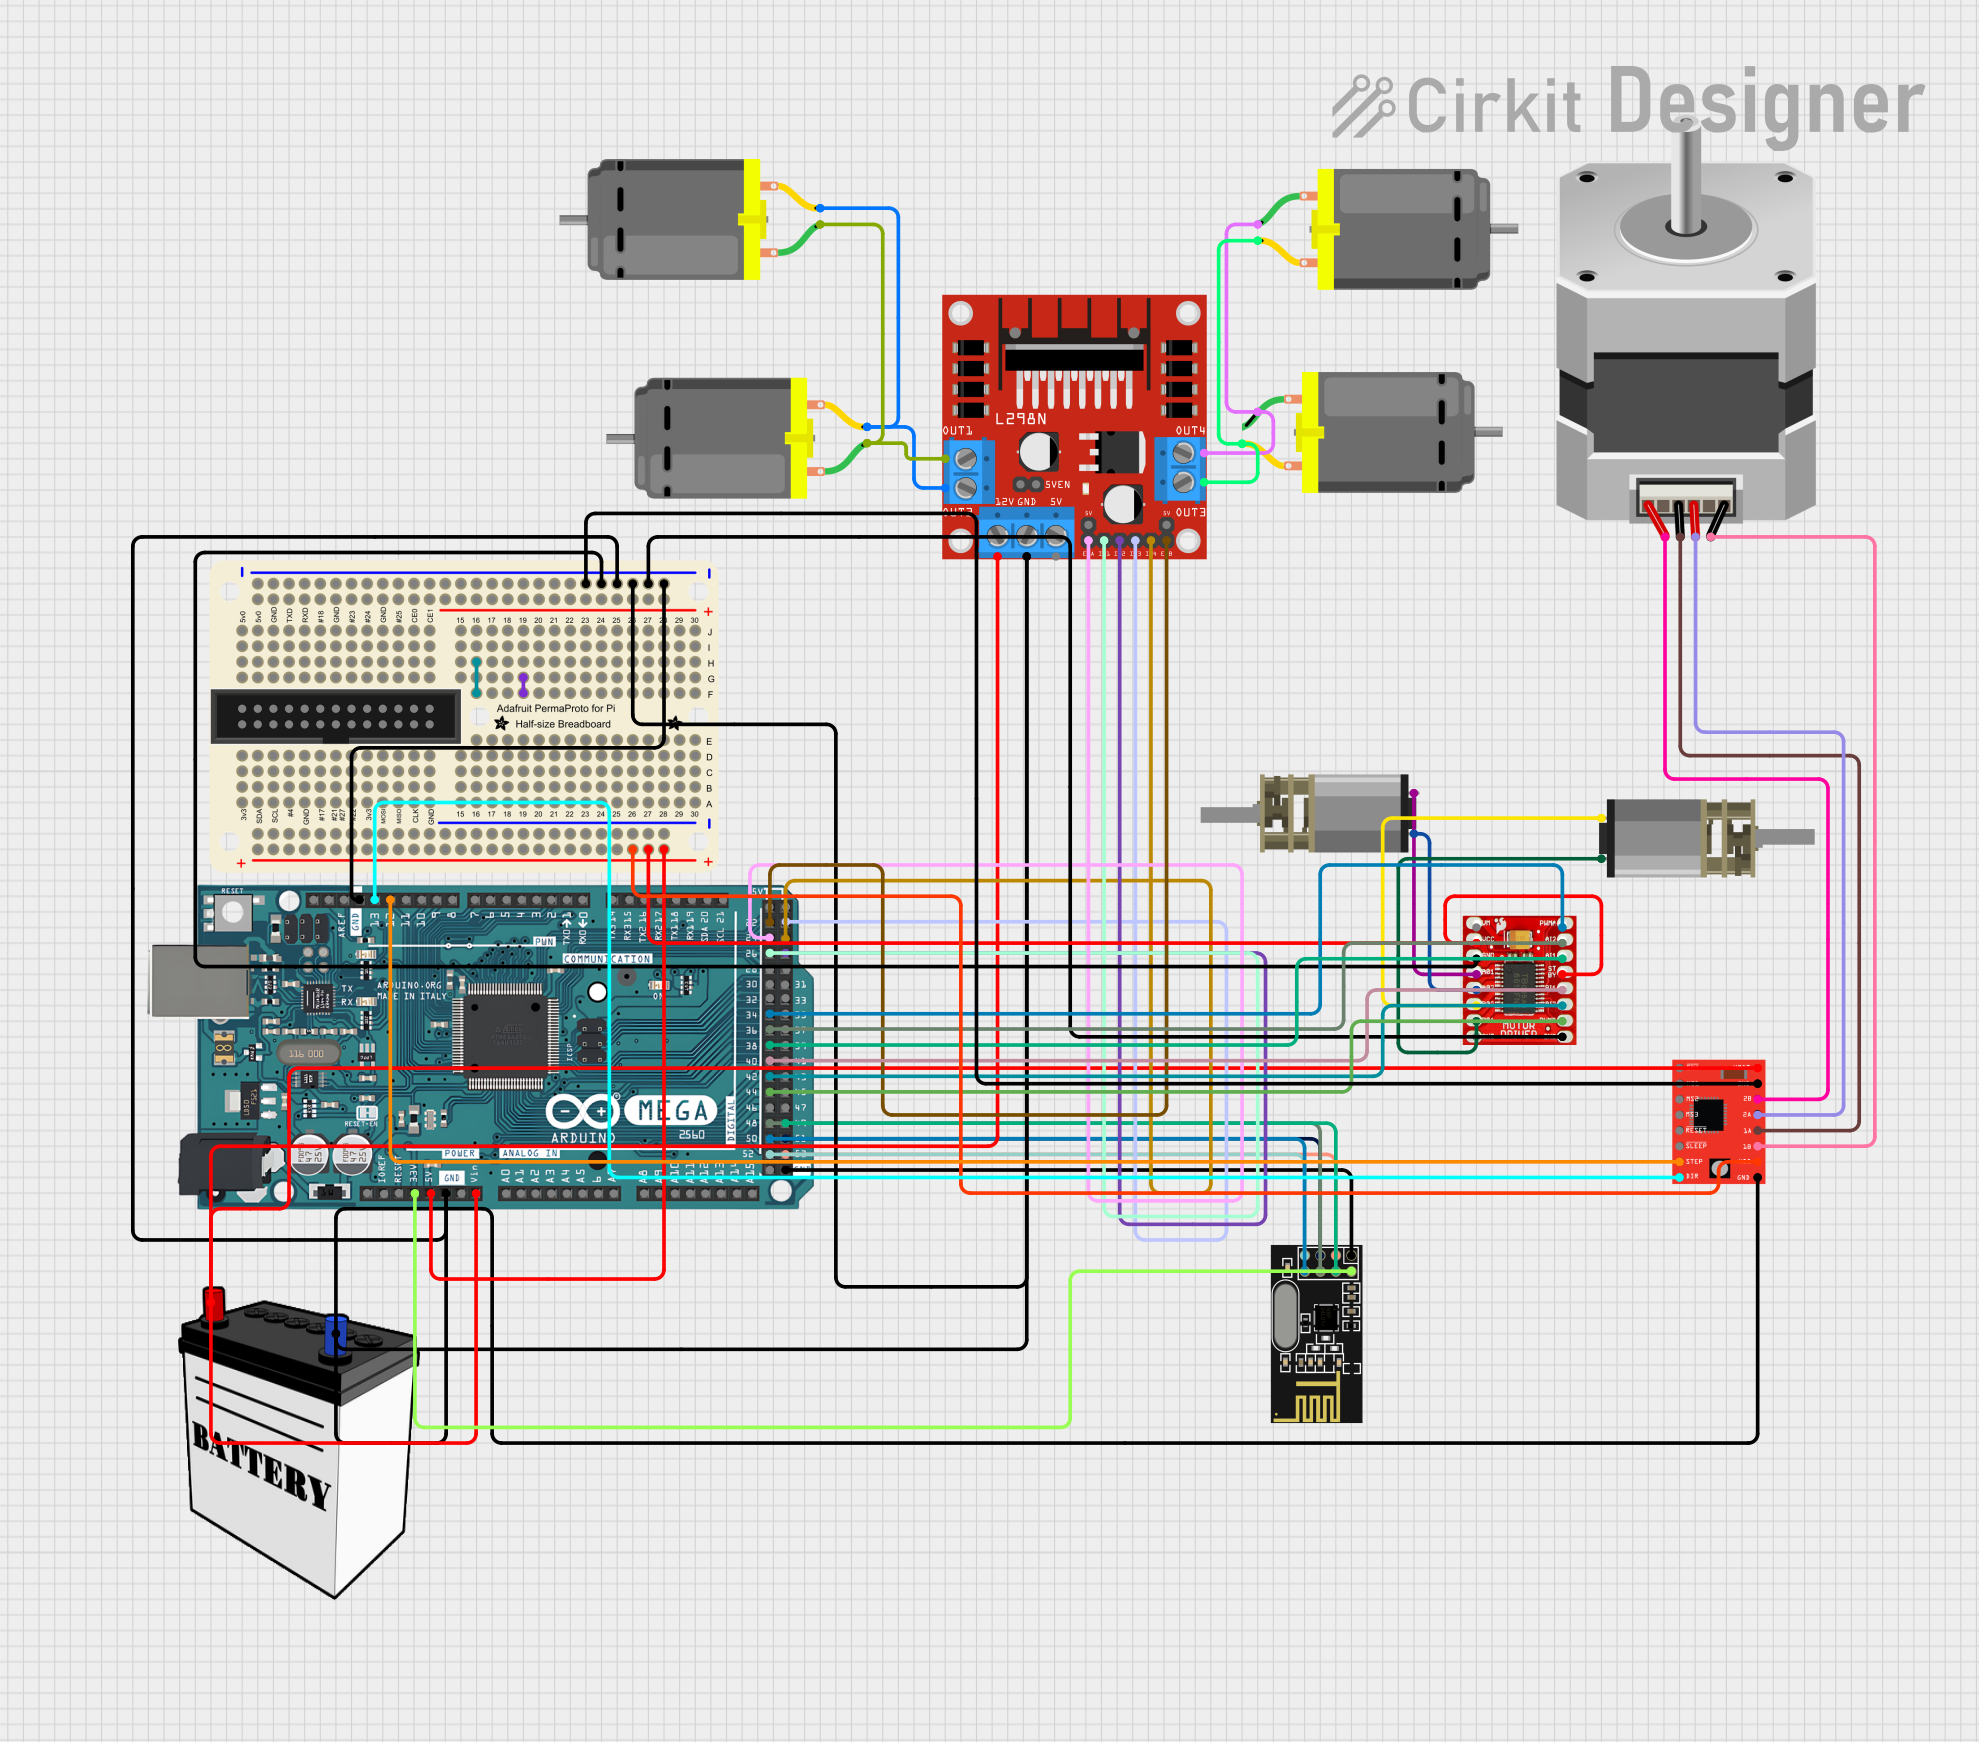
Circuit Documentation
Summary
This circuit is designed to interface an NRF24L01 wireless module with an Arduino Mega 2560 microcontroller. The circuit also includes a 12V battery, an L298N DC motor driver, an Adafruit Raspberry Pi Perma Proto Half-sized breadboard, multiple DC motors, a TB6612FNG motor driver, DC Mini Metal Gear Motors, an A4988 stepper motor driver, and a bipolar stepper motor. The Arduino Mega 2560 controls the NRF24L01 module and motor drivers to operate the motors. The 12V battery provides power to the motor drivers and, through voltage regulation, to the Arduino Mega 2560.
Component List
- NRF24L01: A wireless transceiver module that operates in the 2.4 GHz band.
- Arduino Mega 2560: A microcontroller board based on the ATmega2560, with numerous digital and analog I/O pins.
- 12V Battery: Provides the main power source for the motors and motor drivers.
- L298N DC Motor Driver: An integrated circuit that allows for the control of two DC motors.
- Adafruit Raspberry Pi Perma Proto Half: A prototyping board used for making custom circuits.
- DC Motors: Electric motors that run on direct current (DC) electricity.
- TB6612FNG Motor Driver: A compact motor driver capable of driving two motors.
- DC Mini Metal Gear Motor: A small DC motor with a gearbox for increased torque.
- A4988 Stepper Motor Driver (Red): A compact driver for controlling stepper motors.
- Stepper Motor (Bipolar): A type of stepper motor with two coils and four wires.
Wiring Details
NRF24L01
- MOSI connected to Arduino Mega 2560 D48
- CSN connected to Arduino Mega 2560 D49
- VCC (3V) connected to Arduino Mega 2560 3V3
- GND connected to Arduino Mega 2560 GND
- CE connected to Arduino Mega 2560 D53
- SCK connected to Arduino Mega 2560 D51
- MISO connected to Arduino Mega 2560 D52
Arduino Mega 2560
- 5V connected to Adafruit Raspberry Pi Perma Proto Half PWRSTRIP2
- GND connected to multiple components' GND pins
- VIN connected to 12V Battery VCC and motor drivers' voltage inputs
- Digital Pins connected to motor drivers' control inputs
12V Battery
- VCC connected to Arduino Mega 2560 VIN and motor drivers' voltage inputs
- GND connected to Arduino Mega 2560 GND and motor drivers' GND
L298N DC Motor Driver
- 12V connected to 12V Battery VCC
- GND connected to Arduino Mega 2560 GND
- Control Inputs (IN1, IN2, IN3, IN4, ENA, ENB) connected to Arduino Mega 2560 digital pins
- Motor Outputs (OUT1, OUT2, OUT3, OUT4) connected to DC Motors
Adafruit Raspberry Pi Perma Proto Half
- PWRSTRIP2 connected to Arduino Mega 2560 5V and A4988 VDD
- GNDSTRIP1 connected to Arduino Mega 2560 GND and motor drivers' GND
DC Motors
- pin 1 and pin 2 connected to L298N DC motor driver outputs
TB6612FNG Motor Driver
- GND connected to Adafruit Raspberry Pi Perma Proto Half GNDSTRIP1
- VCC and STBY connected to Adafruit Raspberry Pi Perma Proto Half PWRSTRIP2
- Control Inputs (AI1, AI2, BI1, BI2, PWMA, PWMB) connected to Arduino Mega 2560 digital pins
- Motor Outputs (A01, A02, B01, B02) connected to DC Mini Metal Gear Motors
DC Mini Metal Gear Motors
- IN1 and IN2 connected to TB6612FNG Motor Driver outputs
A4988 Stepper Motor Driver (Red)
- GND connected to Adafruit Raspberry Pi Perma Proto Half GNDSTRIP1
- VDD connected to Adafruit Raspberry Pi Perma Proto Half PWRSTRIP2
- Control Inputs (STEP, DIR) connected to Arduino Mega 2560 digital pins
- Motor Outputs (1A, 1B, 2A, 2B) connected to Stepper Motor (Bipolar)
Stepper Motor (Bipolar)
- A, B, C, D connected to A4988 Stepper Motor Driver outputs
Documented Code
Arduino Mega 2560
File: sketch.ino
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
File: documentation.txt
(No additional documentation provided)
This code is a template and does not contain any specific functionality. It should be populated with the initialization and operational code required to control the NRF24L01 module and the motor drivers connected to the Arduino Mega 2560.