
A-Star 32U4 Mini Controlled Servo with VL53L8CX Time-of-Flight Distance Sensing
View and Edit Project In Cirkit Designer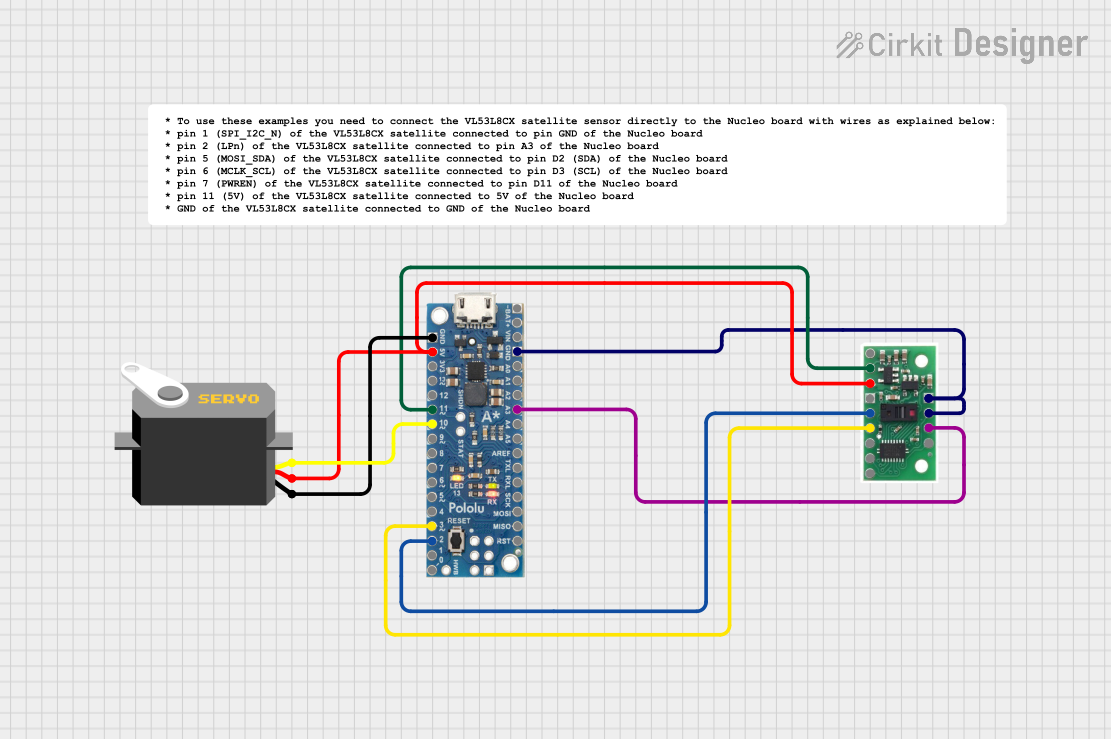
Circuit Documentation
Summary
The circuit in question is designed to interface an A-Star 32U4 Mini microcontroller with a VL53L8CX Time-of-Flight Distance Sensor and a Servo motor. The A-Star 32U4 Mini serves as the central processing unit, controlling the Servo motor and communicating with the distance sensor to obtain distance measurements. The distance sensor is capable of measuring distances in an 8x8 zone, and the Servo motor is used to actuate or move parts based on the microcontroller's commands. The circuit is powered by the 5V output from the A-Star 32U4 Mini, which also provides ground connections to the other components.
Component List
A-Star 32U4 Mini
- Description: A compact microcontroller based on the ATmega32U4.
- Pins: GND, 5V, 3V3, 13, 12, 11, 10, 9, 8, 7, 6, 5, 4, 3, 2, 1, 0, + BAT, - BAT, VIN, A0, A1, A2, A3, A4, A5, AREF, TXL, RXL, SCK, MOSI, MISO, RST.
VL53L8CX Time-of-Flight 8×8-Zone Distance Sensor Carrier with Voltage Regulators
- Description: A sensor for accurate distance measurements using time-of-flight technology.
- Pins: CORE/IOVDD, AVDD, VIN, GND, SDA/MOSI, SCL/MCLK, MISO, CS, SPI/I2C, LP, SYNC, INT.
Servo
- Description: An actuator for precise control of angular position.
- Pins: gnd, vcc, pulse.
Comment
- Description: A placeholder or annotation within the circuit design, typically not a physical component.
Wiring Details
A-Star 32U4 Mini
- GND is connected to the ground pins of the Servo and the VL53L8CX Distance Sensor.
- 5V provides power to the VIN of the VL53L8CX Distance Sensor and the VCC of the Servo.
- Pin 11 is connected to the AVDD pin of the VL53L8CX Distance Sensor.
- Pin 10 controls the pulse pin of the Servo.
- Pin 3 (SCL/MCLK) is connected to the SCL/MCLK pin of the VL53L8CX Distance Sensor.
- Pin 2 (SDA/MOSI) is connected to the SDA/MOSI pin of the VL53L8CX Distance Sensor.
- A3 is connected to the LP pin of the VL53L8CX Distance Sensor.
VL53L8CX Time-of-Flight 8×8-Zone Distance Sensor Carrier with Voltage Regulators
- VIN is powered by the 5V output from the A-Star 32U4 Mini.
- GND is connected to the ground pin of the A-Star 32U4 Mini.
- AVDD is connected to pin 11 of the A-Star 32U4 Mini.
- SCL/MCLK is connected to pin 3 of the A-Star 32U4 Mini.
- SDA/MOSI is connected to pin 2 of the A-Star 32U4 Mini.
- LP is connected to pin A3 of the A-Star 32U4 Mini.
Servo
- gnd is connected to the ground pin of the A-Star 32U4 Mini.
- vcc is powered by the 5V output from the A-Star 32U4 Mini.
- pulse is controlled by pin 10 of the A-Star 32U4 Mini.
Documented Code
There is no code provided for the microcontroller in this circuit. The code would typically include initialization routines for the microcontroller's peripherals, setup code for the Servo and the VL53L8CX Distance Sensor, and the main loop where the microcontroller would read data from the sensor, process it, and control the Servo accordingly. Since no code is available, this section cannot be completed.