
ESP32-Based Smart Trash Bin Monitoring System with Wi-Fi Connectivity
View and Edit Project In Cirkit Designer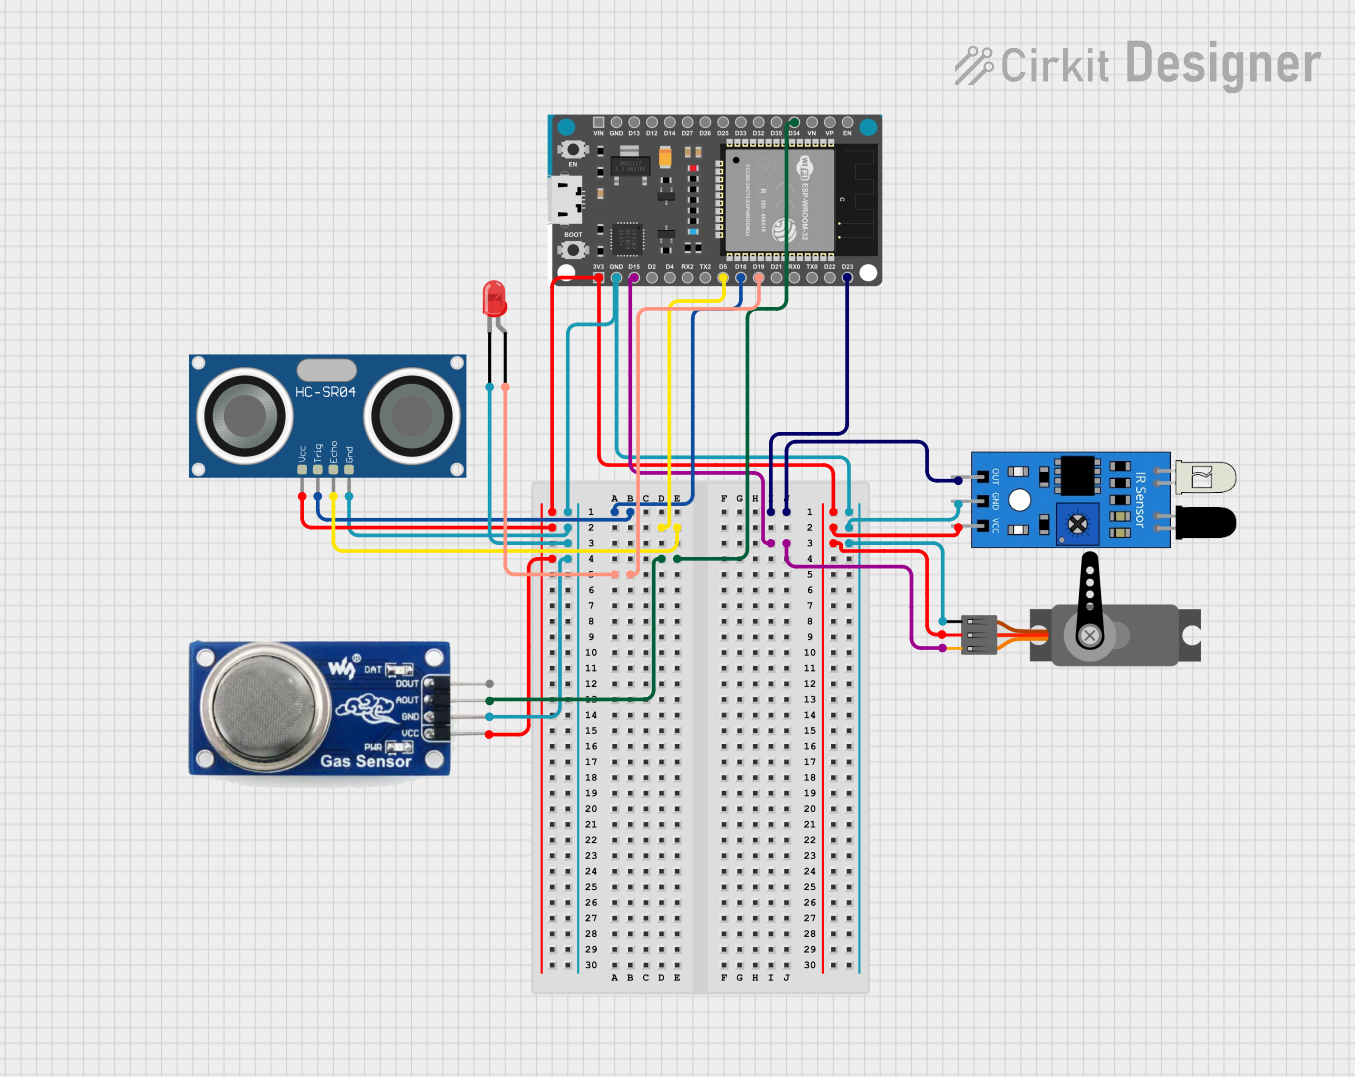
Circuit Documentation
Summary
This circuit is designed for a smart trash bin monitoring system. It utilizes an ESP32 microcontroller to interface with various sensors and a servo motor. The system includes an ultrasonic sensor for measuring trash levels, an IR sensor for detecting obstacles, an MQ-135 gas sensor for detecting harmful gases, and an LED indicator. The ESP32 connects to the Blynk platform for remote monitoring and control.
Component List
ESP32 Devkit V1
- Description: A powerful microcontroller with WiFi and Bluetooth capabilities.
- Pins: 3V3, GND, D15, D2, D4, RX2, TX2, D5, D18, D19, D21, RX0, TX0, D22, D23, EN, VP, VN, D34, D35, D32, D33, D25, D26, D27, D14, D12, D13, VIN
HC-SR04 Ultrasonic Sensor
- Description: A sensor used to measure distance by using ultrasonic waves.
- Pins: VCC, TRIG, ECHO, GND
Servo
- Description: A motor used for precise control of angular position.
- Pins: GND, VCC, PWM
IR Sensor
- Description: An infrared sensor used to detect obstacles.
- Pins: out, gnd, vcc
MQ-135 Gas Sensor
- Description: A sensor used to detect harmful gases.
- Pins: D OUT, A OUT, GND, VCC
LED: Two Pin (red)
- Description: A simple red LED used as an indicator.
- Pins: cathode, anode
Wiring Details
ESP32 Devkit V1
- 3V3: Connected to VCC of HC-SR04 Ultrasonic Sensor, Servo, IR Sensor, and MQ-135 Gas Sensor.
- GND: Connected to GND of HC-SR04 Ultrasonic Sensor, Servo, IR Sensor, MQ-135 Gas Sensor, and cathode of LED.
- D15: Connected to PWM of Servo.
- D5: Connected to ECHO of HC-SR04 Ultrasonic Sensor.
- D18: Connected to TRIG of HC-SR04 Ultrasonic Sensor.
- D19: Connected to anode of LED.
- D23: Connected to out of IR Sensor.
- D34: Connected to A OUT of MQ-135 Gas Sensor.
HC-SR04 Ultrasonic Sensor
- VCC: Connected to 3V3 of ESP32 Devkit V1.
- TRIG: Connected to D18 of ESP32 Devkit V1.
- ECHO: Connected to D5 of ESP32 Devkit V1.
- GND: Connected to GND of ESP32 Devkit V1.
Servo
- GND: Connected to GND of ESP32 Devkit V1.
- VCC: Connected to 3V3 of ESP32 Devkit V1.
- PWM: Connected to D15 of ESP32 Devkit V1.
IR Sensor
- out: Connected to D23 of ESP32 Devkit V1.
- gnd: Connected to GND of ESP32 Devkit V1.
- vcc: Connected to 3V3 of ESP32 Devkit V1.
MQ-135 Gas Sensor
- D OUT: Not connected.
- A OUT: Connected to D34 of ESP32 Devkit V1.
- GND: Connected to GND of ESP32 Devkit V1.
- VCC: Connected to 3V3 of ESP32 Devkit V1.
LED: Two Pin (red)
- cathode: Connected to GND of ESP32 Devkit V1.
- anode: Connected to D19 of ESP32 Devkit V1.
Documented Code
// Blynk credentials
#define BLYNK_TEMPLATE_ID "TMPL6njxn9Afv"
#define BLYNK_TEMPLATE_NAME "Smart Trash Bin Monitoring"
#define BLYNK_AUTH_TOKEN "tLRf6lKv0tmOddiNEDzB6Usg4nReIkjv"

#include <ESP32Servo.h>
#include <WiFi.h>
#include <BlynkSimpleEsp32.h>

// Pin Definitions
#define IR_SENSOR_PIN 23 // Pin untuk sensor IR
#define SERVO_PIN 15     // Pin untuk servo
#define MQ135_PIN 34     // Pin untuk sensor MQ-135 (analog)
#define TRIG_PIN 18      // Pin untuk Trigger sensor ultrasonik
#define ECHO_PIN 5       // Pin untuk Echo sensor ultrasonik
#define LED_PIN 19       // Pin untuk LED Merah

// WiFi credentials
char ssid[] = "M4"; // Ganti dengan SSID WiFi Anda
char pass[] = "12345678"; // Ganti dengan password WiFi Anda

// Thresholds
int gasThreshold = 1000; // Ambang batas untuk mendeteksi gas (sesuaikan dengan kalibrasi sensor)
bool gasDetected = false;

Servo servo;

void setup() {
  // Setup Pins
  pinMode(IR_SENSOR_PIN, INPUT); // Set pin sensor IR sebagai input
  servo.attach(SERVO_PIN); // Menghubungkan servo ke pin
  servo.write(0); // Posisi awal servo (tertutup)

  pinMode(TRIG_PIN, OUTPUT); // Set pin Trigger sebagai output
  pinMode(ECHO_PIN, INPUT);  // Set pin Echo sebagai input
  pinMode(LED_PIN, OUTPUT);   // Set pin LED sebagai output

  // Connect to WiFi
  WiFi.begin(ssid, pass);
  while (WiFi.status() != WL_CONNECTED) {
    delay(1000);
  }

  // Connect to Blynk
  Blynk.begin(BLYNK_AUTH_TOKEN, ssid, pass); // Menghubungkan ke Blynk
}

void loop() {
  Blynk.run(); // Menjalankan Blynk

  // Sensor IR
  int sensorValue = digitalRead(IR_SENSOR_PIN); // Membaca nilai dari sensor IR
  if (sensorValue == LOW) { // Jika halangan terdeteksi (sensor IR LOW)
    servo.write(90); // Menggerakkan servo (buka)
    delay(2000); // Tunggu 2 detik
    servo.write(0); // Kembali ke posisi awal (tutup)
  }

  // Sensor MQ-135
  int gasValue = analogRead(MQ135_PIN);
  Blynk.virtualWrite(V0, gasValue); // Kirim nilai gas ke widget di Virtual Pin V0

  if (gasValue > gasThreshold) {
    gasDetected = true;
    Blynk.logEvent("gas_detected", "Bau gas terdeteksi!"); // Log event ke Blynk
  } else {
    gasDetected = false;
  }

  // Sensor Ultrasonik
  long duration, distance;

  // Mengirimkan sinyal trigger
  digitalWrite(TRIG_PIN, LOW);
  delayMicroseconds(2);
  digitalWrite(TRIG_PIN, HIGH);
  delayMicroseconds(10);
  digitalWrite(TRIG_PIN, LOW);

  // Membaca sinyal echo
  duration = pulseIn(ECHO_PIN, HIGH);

  // Menghitung jarak (dalam cm)
  distance = duration * 0.034 / 2;

  // Menghitung kapasitas sampah (maksimum 15 cm)
  int trashCapacity = map(distance, 0, 15, 100, 0); // Menghitung kapasitas dalam persen
  if (trashCapacity < 0) trashCapacity = 0; // Pastikan tidak negatif

  // Mengupdate status di Blynk
  Blynk.virtualWrite(V2, trashCapacity); // Menampilkan kapasitas sampah di widget V2

  // Menghidupkan LED jika jarak lebih dari 15 cm
  if (distance < 15) {
    digitalWrite(LED_PIN, HIGH); // Hidupkan LED Merah
  } else {
    digitalWrite(LED_PIN, LOW); // Matikan LED
  }

  delay(500); // Delay sebelum pembacaan berikutnya
}
This documentation provides a comprehensive overview of the circuit, including a summary, component list, wiring details, and the embedded code for the ESP32 microcontroller.