
Raspberry Pi 4B-Based Multi-Sensor Data Acquisition and Display System
View and Edit Project In Cirkit Designer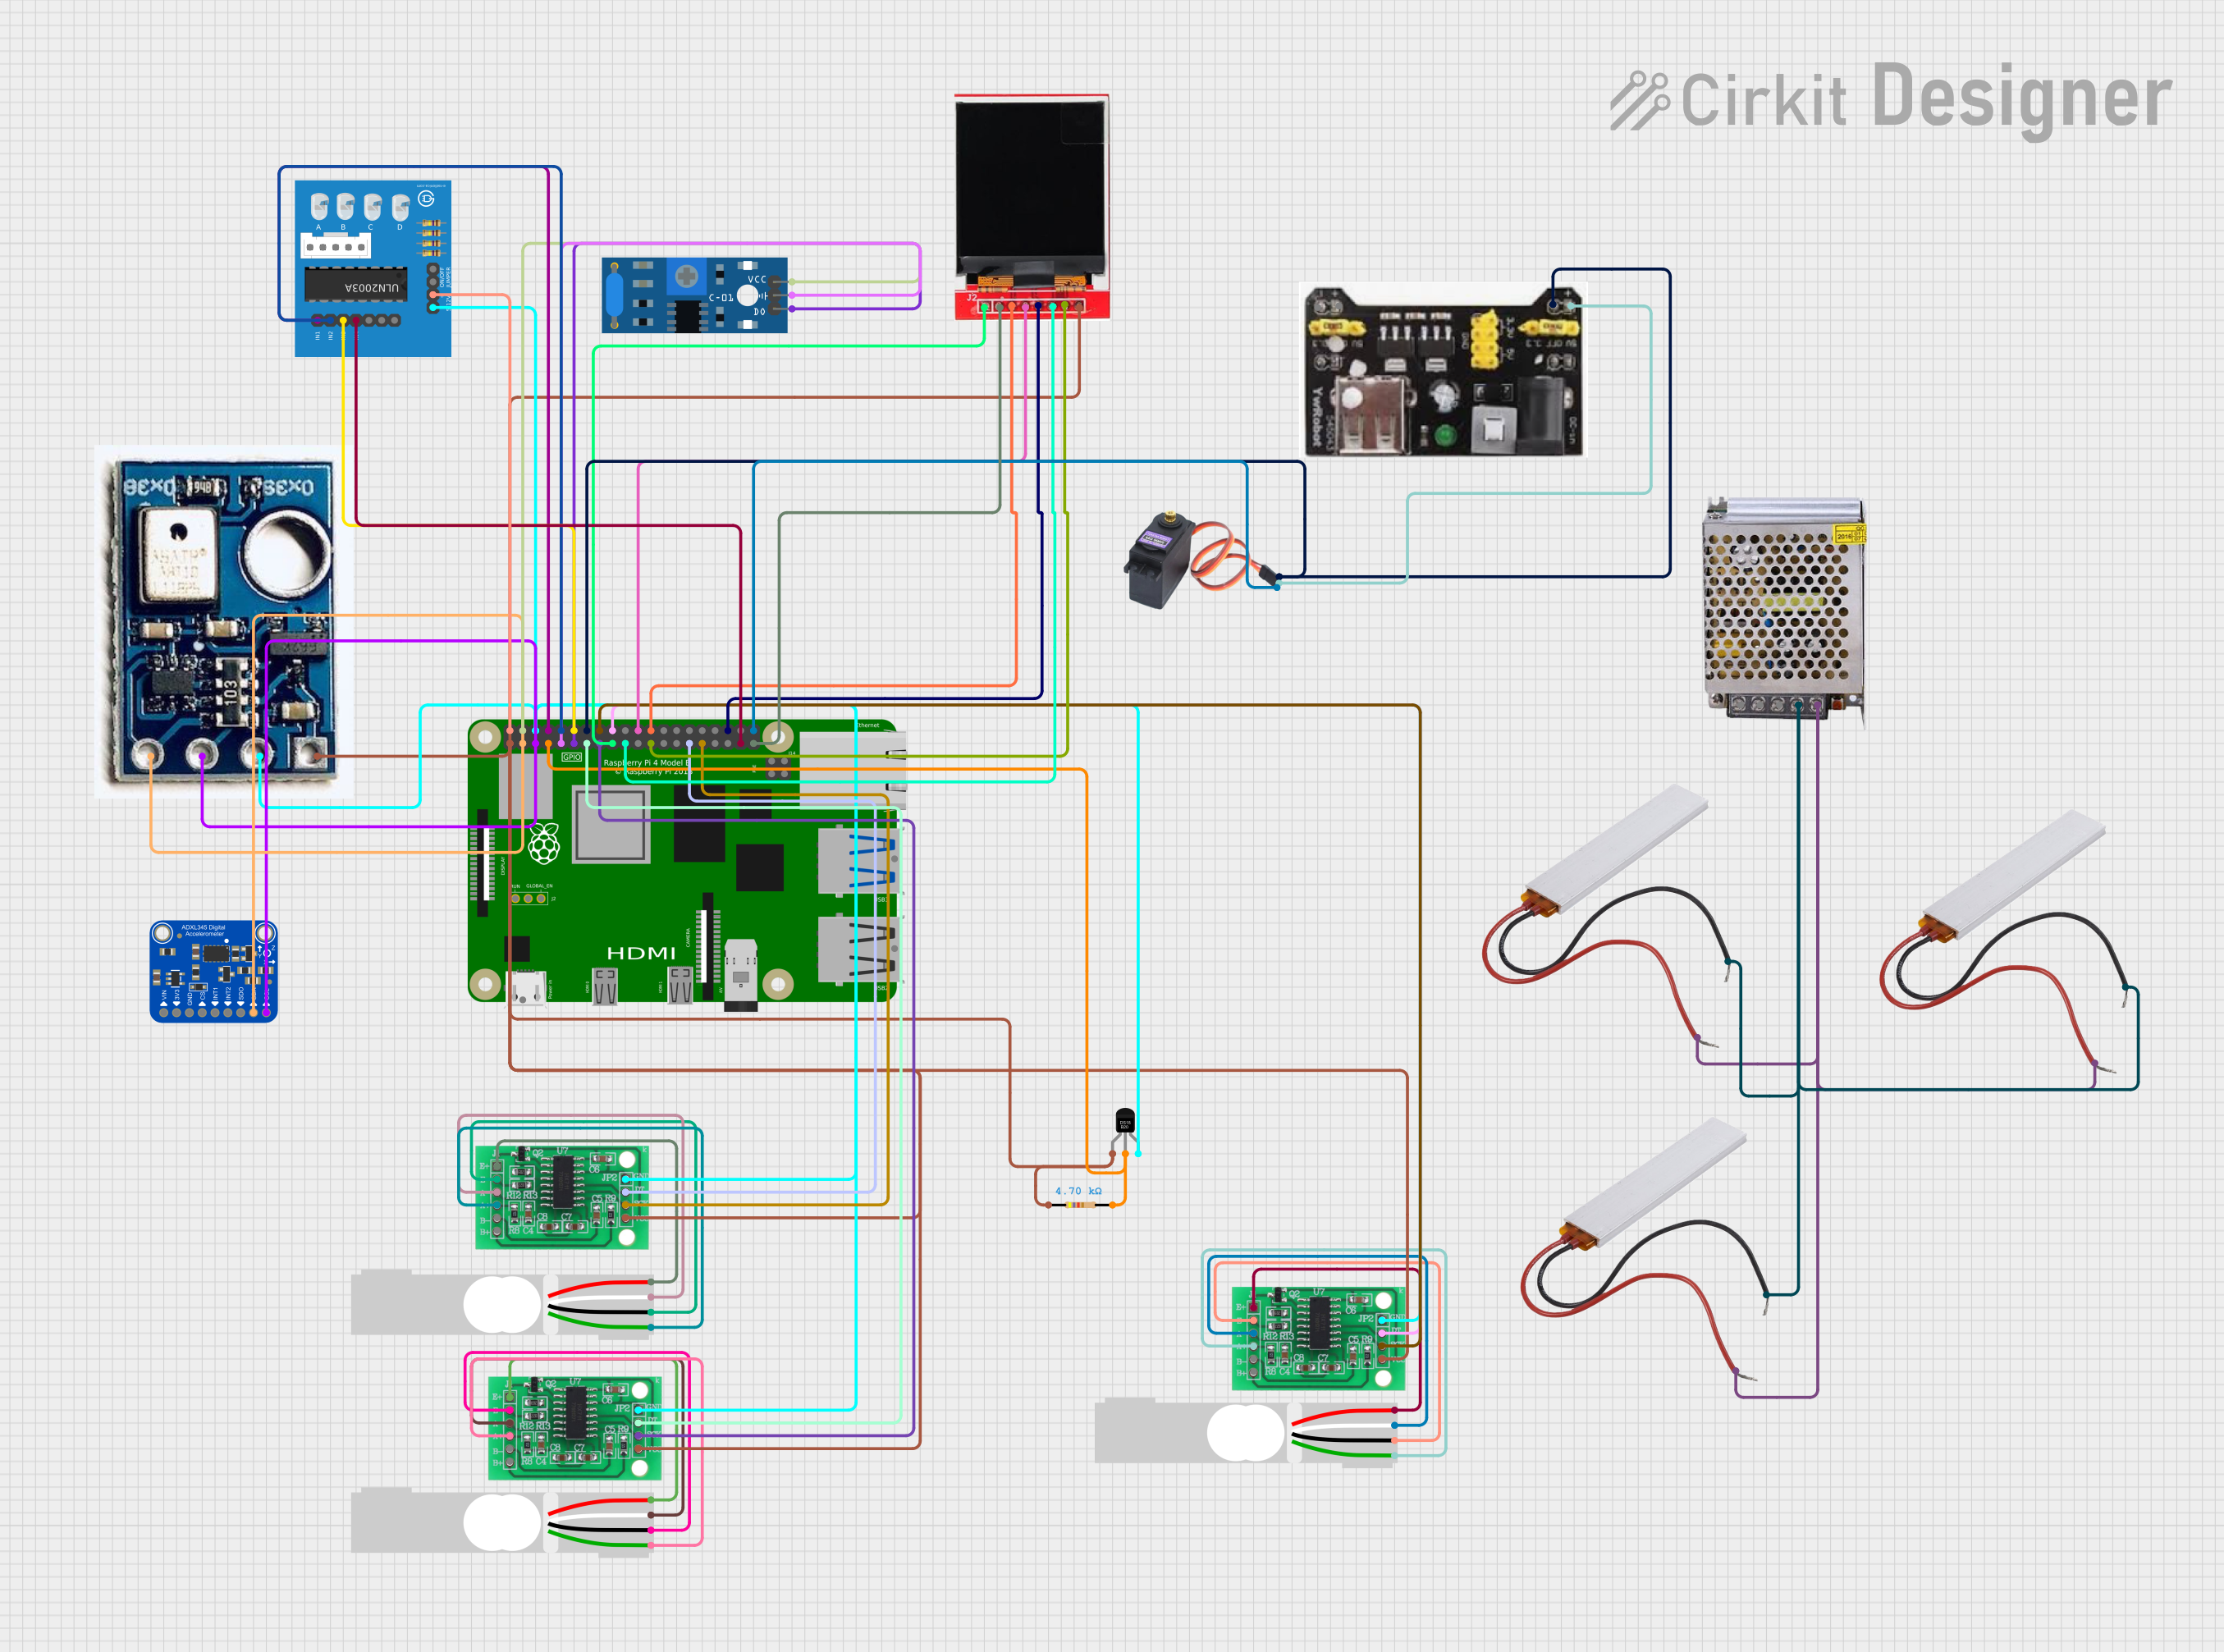
Circuit Documentation
Summary
This circuit integrates a variety of components including a Raspberry Pi 4B, sensors (DS18B20, AHT10, Adafruit ADXL345, SW-420 Vibration Sensor), a TFT LCD Display (ST7735S), multiple HX711 Bridge Sensor Interfaces with corresponding Load Cells, a ULN2003A breakout board, a servo motor (MG996R), PTCs for circuit protection, and a power supply module. The Raspberry Pi 4B serves as the central processing unit, interfacing with the sensors and display, and controlling the servo motor through GPIO pins. The HX711 interfaces are used to digitize the signals from the load cells, which are likely used for weight measurement. The circuit is powered by a 12V 5A power supply, with voltage regulation provided by the MB102 Breadboard Power Supply Module and the Raspberry Pi's onboard voltage regulators.
Component List
Raspberry Pi 4B
- Microcontroller and central processing unit of the circuit.
- Equipped with multiple GPIO pins for interfacing with other components.
DS18B20
- A digital temperature sensor that communicates over a one-wire interface.
Resistor (4.7k Ohms)
- Used as a pull-up resistor for the DS18B20 data line.
Load Cell - Red/white/black/green
- Transducers that convert force into an electrical signal.
TFT LCD Display ST7735S
- A small display for visual output from the Raspberry Pi.
PTC (Positive Temperature Coefficient)
- Protective devices that limit current in the event of a fault.
SW-420 Vibration Sensor
- A sensor that detects vibrations and outputs a digital signal.
HX711 - Bridge Sensor Interface
- An ADC converter for reading load cells.
POWER SUPPLY 12V 5AMP
- Provides the main power to the circuit.
AHT10
- A high precision temperature and humidity sensor.
Adafruit ADXL345
- A 3-axis accelerometer for motion detection.
ULN2003A breakout board
- A driver board for controlling stepper motors or other loads.
MG996R
- A high-torque servo motor.
MB102 Breadboard Power Supply Module 3.3V/5V
- A module that provides regulated power to the breadboard.
Wiring Details
Raspberry Pi 4B
3V3powers the DS18B20, AHT10, and TFT LCD Display.5Vpowers the ULN2003A breakout board and SW-420 Vibration Sensor.GPIO2(SDA) is connected to the AHT10 and Adafruit ADXL345 for I2C communication.GPIO3(SCL) is also connected to the AHT10 and Adafruit ADXL345 for I2C communication.GPIO4is connected to the DS18B20 data line through a 4.7k Ohm resistor.GPIO14,GPIO15,GPIO18,GPIO26are connected to the ULN2003A breakout board inputs.GPIO17is connected to the SW-420 Vibration Sensor digital output.GPIO22,GPIO23,GPIO24,GPIO27,GPIO5,GPIO6are connected to the HX711 data and clock inputs.GPIO8,GPIO10,GPIO11,GPIO25,GPIO16,GPIO21are connected to the TFT LCD Display for SPI communication and control.- Multiple
GNDpins are used for grounding various components.
DS18B20
VDDto 3.3V power.DQto Raspberry Pi GPIO4 with a 4.7k Ohm pull-up resistor to 3.3V.GNDto ground.
Resistor (4.7k Ohms)
- One end to DS18B20
DQand the other end to 3.3V.
Load Cells
E+,E-,A-,A+connected to corresponding HX711 inputs.
TFT LCD Display ST7735S
Vccto 3.3V power.GNDto ground.CS,RESET,A0,SDA,SCKto corresponding Raspberry Pi GPIO pins for SPI communication.
PTCs
Neutrallines connected together and to theGND (DC)of the power supply.Livelines connected together and to the12V-24V Output (DC)of the power supply.
SW-420 Vibration Sensor
vccto 5V power.Groundto ground.Digital outputto Raspberry Pi GPIO17.
HX711 - Bridge Sensor Interface
3.3/3.5V Supplyto 3.3V power.GND - GROUNDto ground.E+,E-,A-,A+to corresponding Load Cell wires.DATA (OUT)andSCK - CLOCK (IN)to corresponding Raspberry Pi GPIO pins.
POWER SUPPLY 12V 5AMP
220V Positive Pole (AC)and220V Negative Pole (AC)to AC power source.GND (DC)to PTCNeutral.12V-24V Output (DC)to PTCLive.
AHT10
VINto 3.3V power.GNDto ground.SDAandSCLto corresponding Raspberry Pi GPIO pins for I2C communication.
Adafruit ADXL345
VINto 3.3V power.GNDto ground.SDA/SDIOandSCLto corresponding Raspberry Pi GPIO pins for I2C communication.
ULN2003A breakout board
+5Vto 5V power.0Vto ground.In 1,In 2,In 3,In 4to corresponding Raspberry Pi GPIO pins.
MG996R
VCCto 5V power.GNDto ground.SIGto Raspberry Pi GPIO21.
MB102 Breadboard Power Supply Module 3.3V/5V
GNDto ground.3.3Vand5vto corresponding components requiring regulated power.
Documented Code
There is no code provided for the microcontrollers in the circuit. The Raspberry Pi 4B would typically be programmed using Python, C++, or another suitable programming language to interface with the connected sensors, display, and other components. The code would handle data acquisition, processing, and output, as well as control signals for the servo motor and other actuators.