
Arduino-Controlled Bluetooth Robotic Vehicle with Dual L298N Motor Drivers
View and Edit Project In Cirkit Designer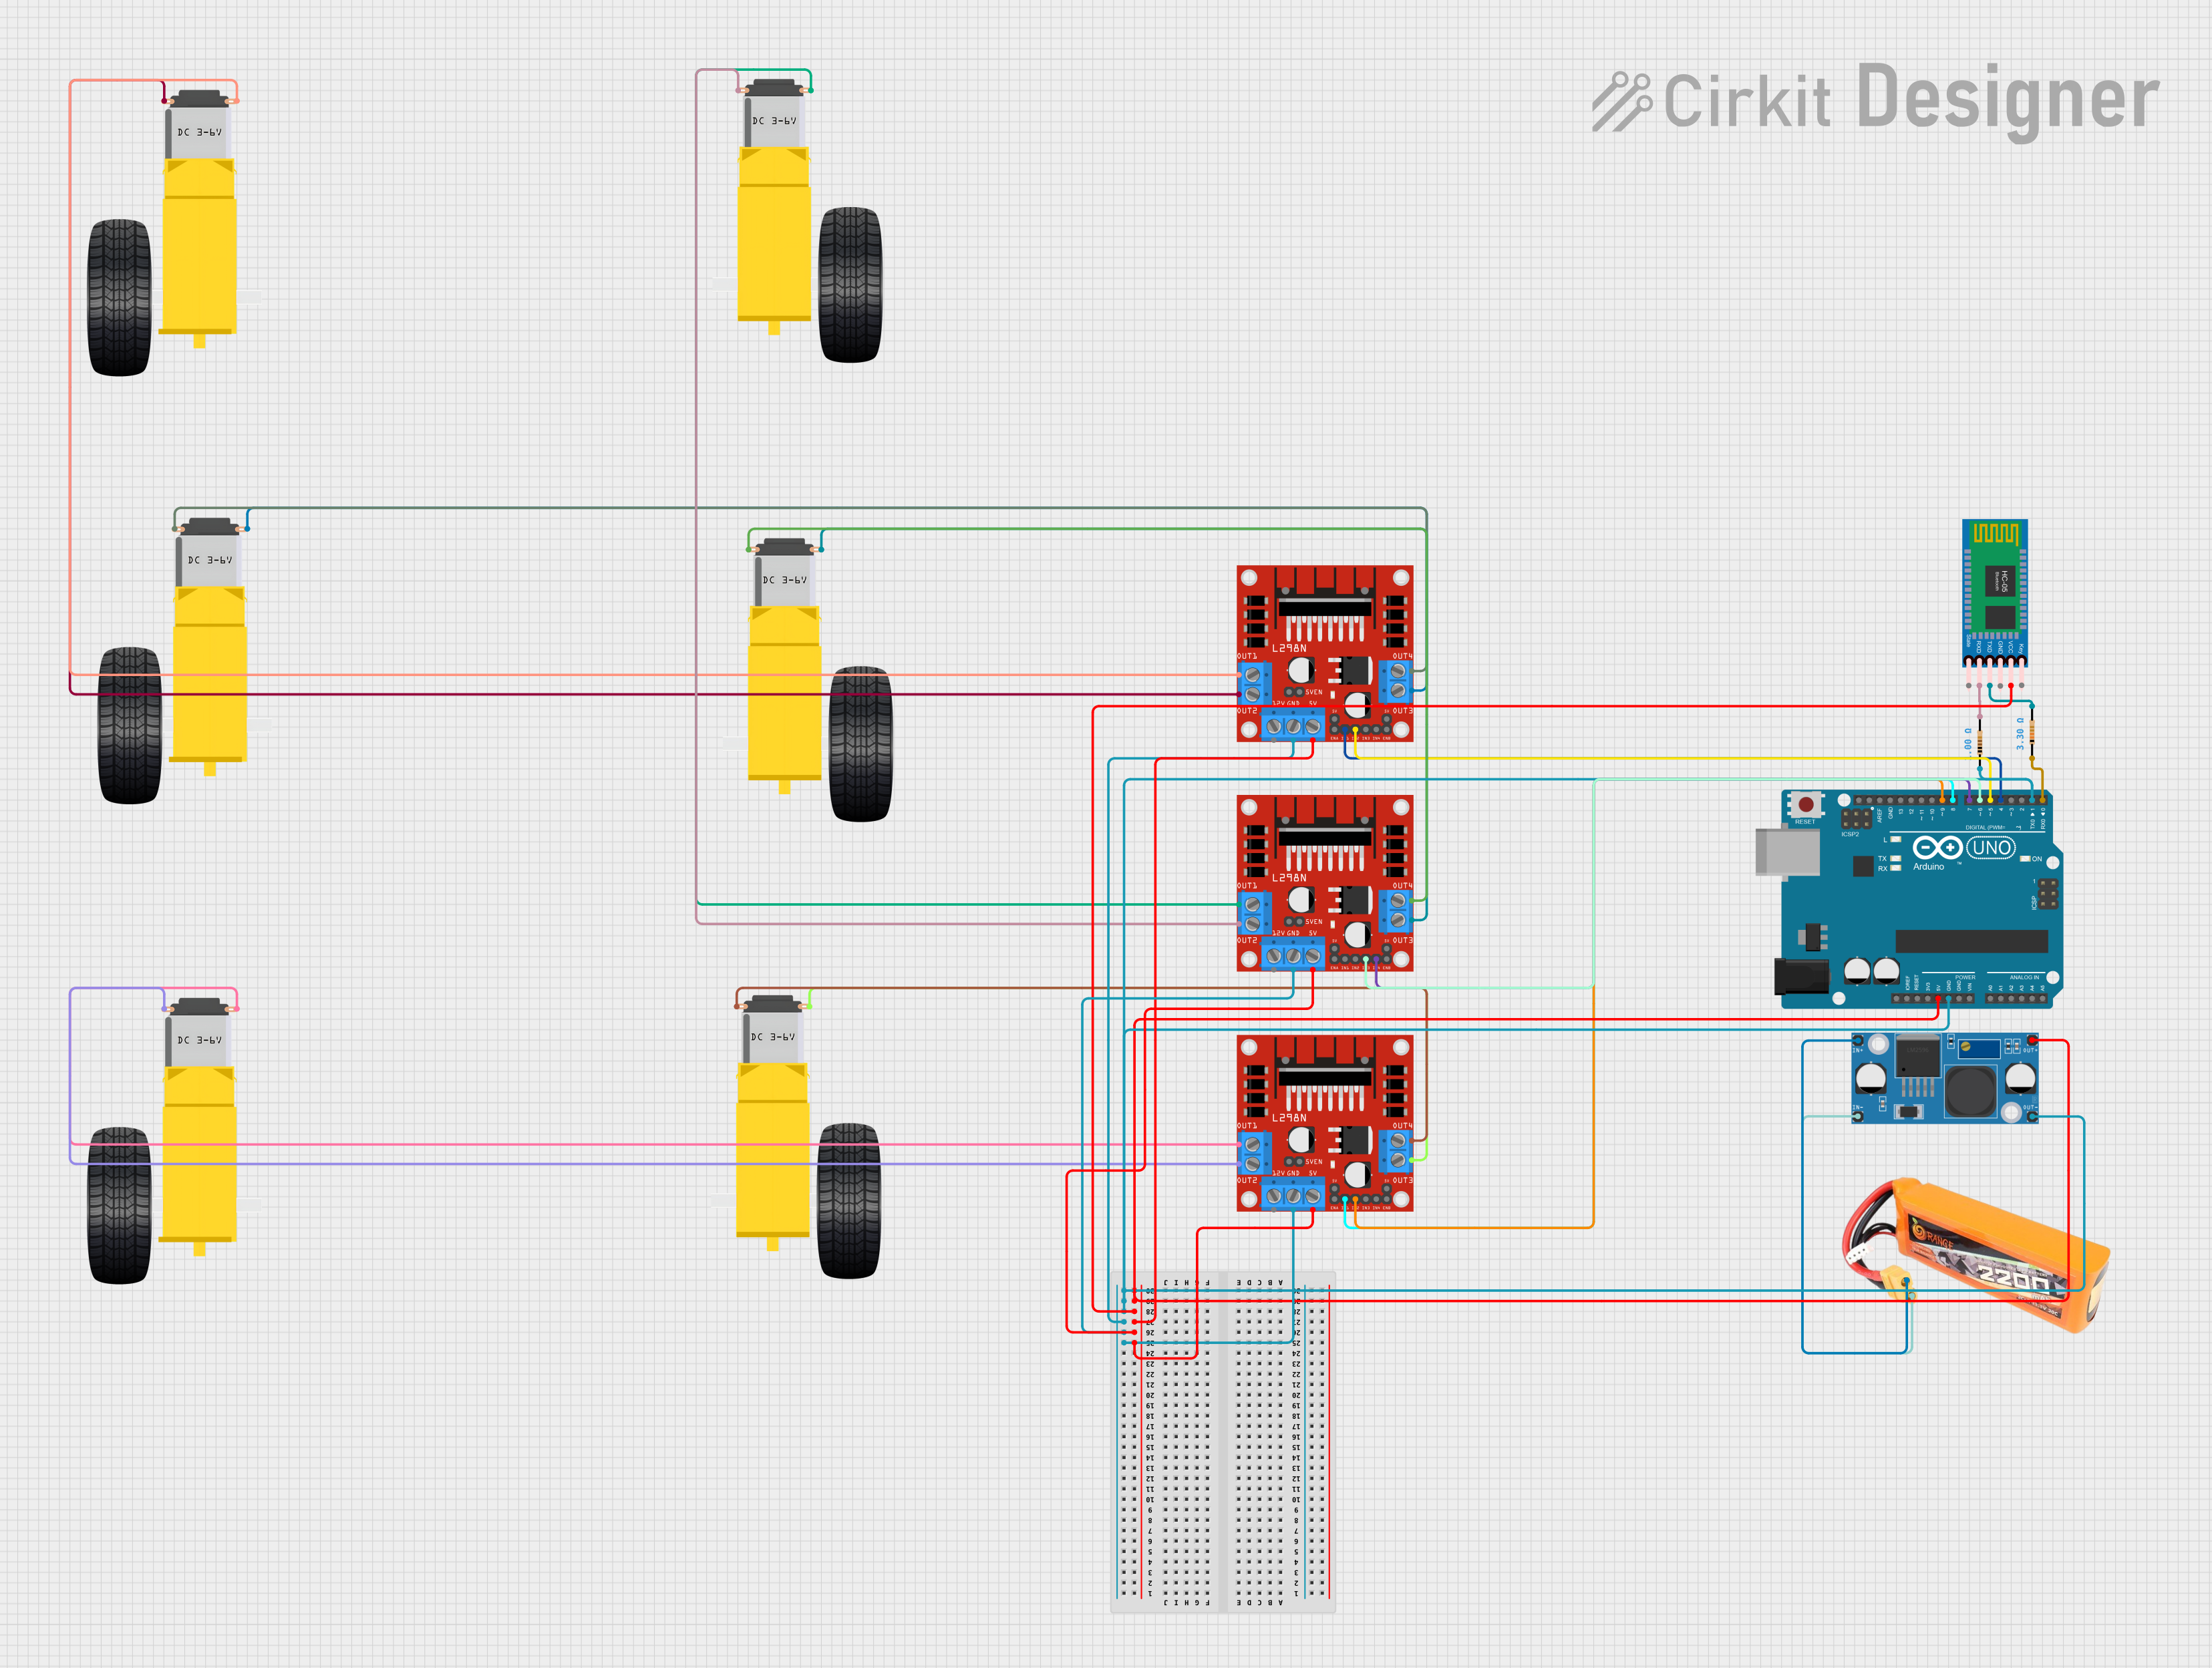
Circuit Documentation
Summary
The circuit in question is designed to control a set of DC motors using an Arduino UNO as the central processing unit, interfaced with an HC-05 Bluetooth module for wireless communication. The L298N DC motor drivers are used to drive the motors, and power is supplied by a lipo battery, with voltage regulation provided by an LM2956 Buck Converter. The circuit also includes resistors for current limiting or voltage division purposes.
Component List
HC-05 Bluetooth Module
- Description: A Bluetooth module for wireless communication.
- Pins: Key, VCC, TXD, RXD, State, GND
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13
L298N DC Motor Driver
- Description: A dual H-bridge motor driver for controlling the direction and speed of DC motors.
- Pins: OUT1-OUT4, 12V, GND, 5V, 5V-ENA-JMP-I/O, +5V-J1/J2, ENA/B, IN1-IN4
LM2956 Buck Converter DC-DC
- Description: A DC-DC buck converter for stepping down voltage.
- Pins: OUT+, OUT-, IN+, IN-
Resistor (1 Ohm)
- Description: A resistor with 1 Ohm resistance.
Resistor (3.3 Ohms)
- Description: A resistor with 3.3 Ohms resistance.
Lipo Battery 2200mAh 30C
- Description: A rechargeable lithium polymer battery.
- Pins: VCC, GND
Gearmotor DC Wheels (Left and Right)
- Description: DC gearmotors for driving wheels.
- Pins: PIN1, PIN2
Wiring Details
HC-05 Bluetooth Module
- VCC connected to 5V power net.
- TXD connected through a 3.3 Ohm resistor to Arduino UNO (D0).
- RXD connected through a 1 Ohm resistor to Arduino UNO (D1).
- GND connected to common ground net.
Arduino UNO
- 5V pin providing power to the 5V power net.
- GND pin connected to common ground net.
- D0 (RX) connected to HC-05 Bluetooth Module (TXD) through a 3.3 Ohm resistor.
- D1 (TX) connected to HC-05 Bluetooth Module (RXD) through a 1 Ohm resistor.
- D4-D9 connected to L298N motor driver IN1-IN4 pins for motor control.
L298N DC Motor Driver (Multiple Instances)
- 5V pin connected to 5V power net.
- GND pin connected to common ground net.
- IN1-IN4 pins controlled by Arduino UNO D4-D9.
- OUT1-OUT4 pins connected to Gearmotor DC Wheels.
LM2956 Buck Converter DC-DC
- IN+ connected to lipo battery VCC.
- IN- connected to lipo battery GND.
- OUT+ providing 5V to the 5V power net.
- OUT- connected to common ground net.
Resistor (1 Ohm and 3.3 Ohms)
- 1 Ohm resistor connected between HC-05 Bluetooth Module (RXD) and Arduino UNO (D1).
- 3.3 Ohms resistor connected between HC-05 Bluetooth Module (TXD) and Arduino UNO (D0).
Lipo Battery 2200mAh 30C
- VCC providing power to LM2956 Buck Converter (IN+).
- GND connected to LM2956 Buck Converter (IN-).
Gearmotor DC Wheels (Left and Right)
- PIN1 and PIN2 connected to respective OUT pins on L298N motor drivers.
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code is a template and does not contain any functional code for controlling the motors or interfacing with the Bluetooth module. This will need to be implemented based on the specific requirements of the project.