
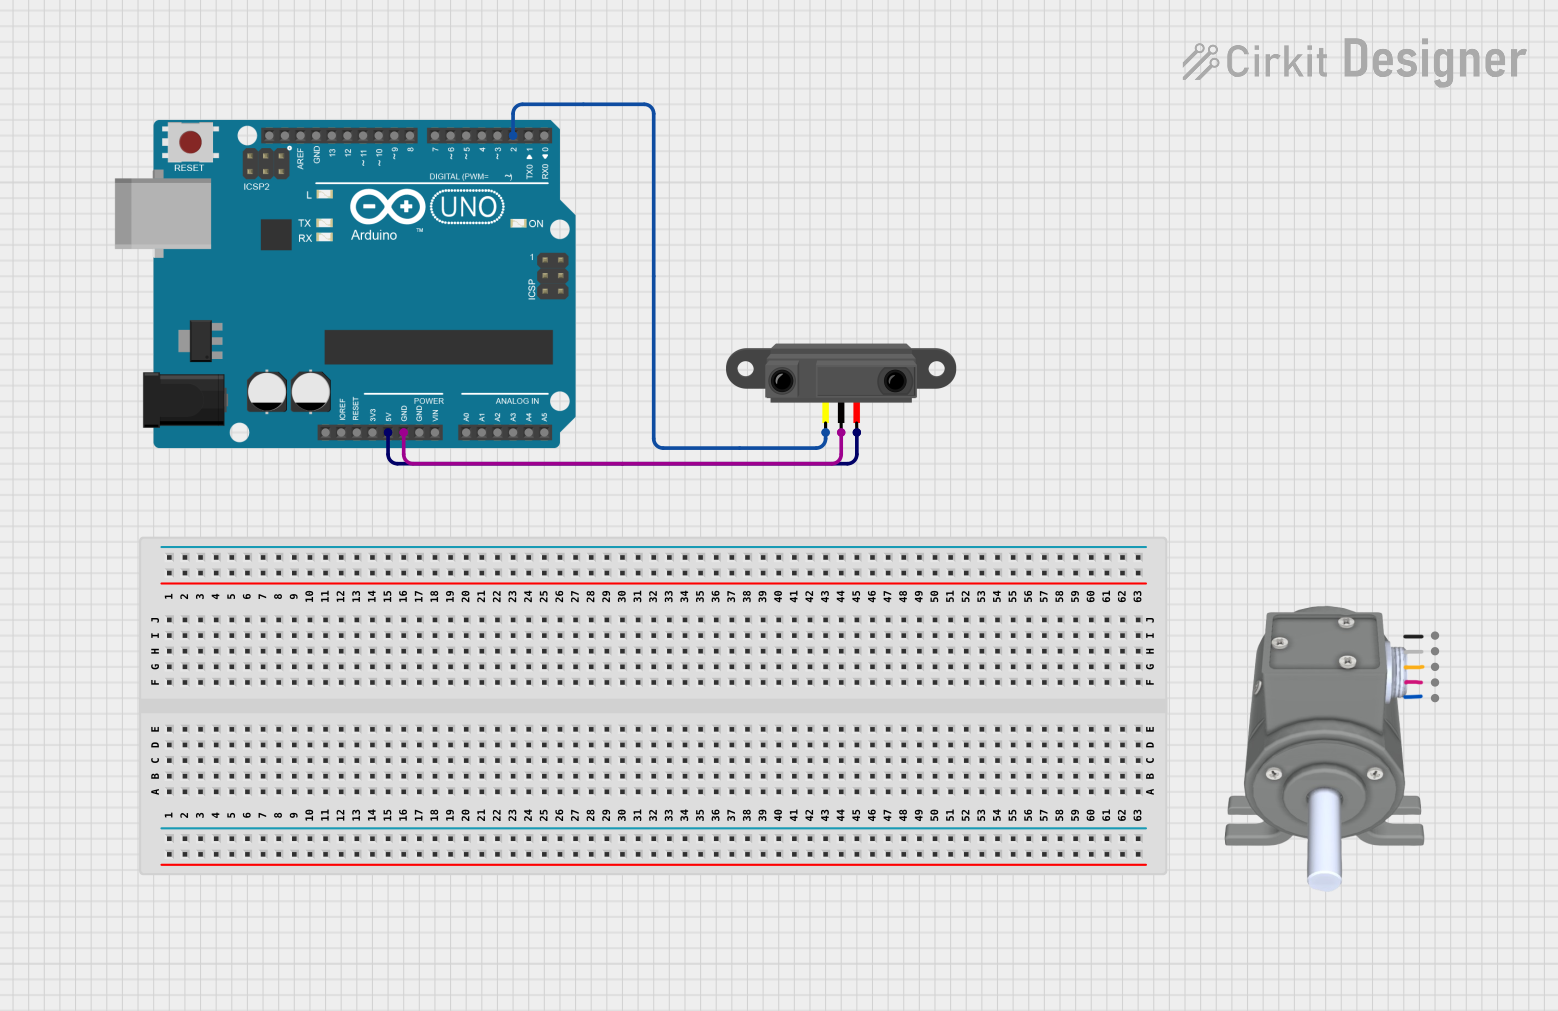
Circuit Documentation
Summary of the Circuit
This circuit consists of an Arduino UNO microcontroller, an Infrared Proximity Sensor, and a Rotary Encoder (incremental type, side mount). The Arduino UNO serves as the central processing unit, controlling the input from the Infrared Proximity Sensor and the Rotary Encoder. The Infrared Proximity Sensor is used to detect the presence of an object within its range, and the Rotary Encoder provides rotational position feedback.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0-A5, SCL, SDA, AREF, D0-D13.
- Purpose: Acts as the central processing unit for the circuit, reading sensor inputs and controlling outputs.
Infrared Proximity Sensor
- Description: A sensor that detects the presence of an object within a certain distance without any physical contact.
- Pins: Vout, GND, Vcc.
- Purpose: Provides proximity detection functionality to the circuit.
Rotary Encoder (incremental type, side mount)
- Description: An electromechanical device that converts the angular position or motion of a shaft or axle to digital code.
- Pins: A, B, Z, VCC, GND.
- Purpose: Provides rotational position feedback to the circuit.
Wiring Details
Arduino UNO
- 5V: Provides power to the Infrared Proximity Sensor.
- GND: Common ground for the circuit.
- D2: Receives the output signal from the Infrared Proximity Sensor.
Infrared Proximity Sensor
- Vcc: Connected to the 5V output from the Arduino UNO.
- GND: Connected to the ground on the Arduino UNO.
- Vout: Sends the detection signal to digital pin D2 on the Arduino UNO.
Rotary Encoder (incremental type, side mount)
- Wiring details not provided.
Documented Code
The following code is for the Arduino UNO microcontroller:
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
The code provided is a template with empty setup() and loop() functions. The setup() function is intended to contain initialization code that runs once when the microcontroller is powered on or reset. The loop() function is intended to contain the main logic of the program, which runs repeatedly as long as the microcontroller is powered.
Note: The actual implementation code for the Infrared Proximity Sensor and the Rotary Encoder is not provided and should be added to the setup() and loop() functions as needed for the specific application.