
Arduino UNO-Based GPS-Enabled Quadcopter with Brushless Motors and Sensors
View and Edit Project In Cirkit Designer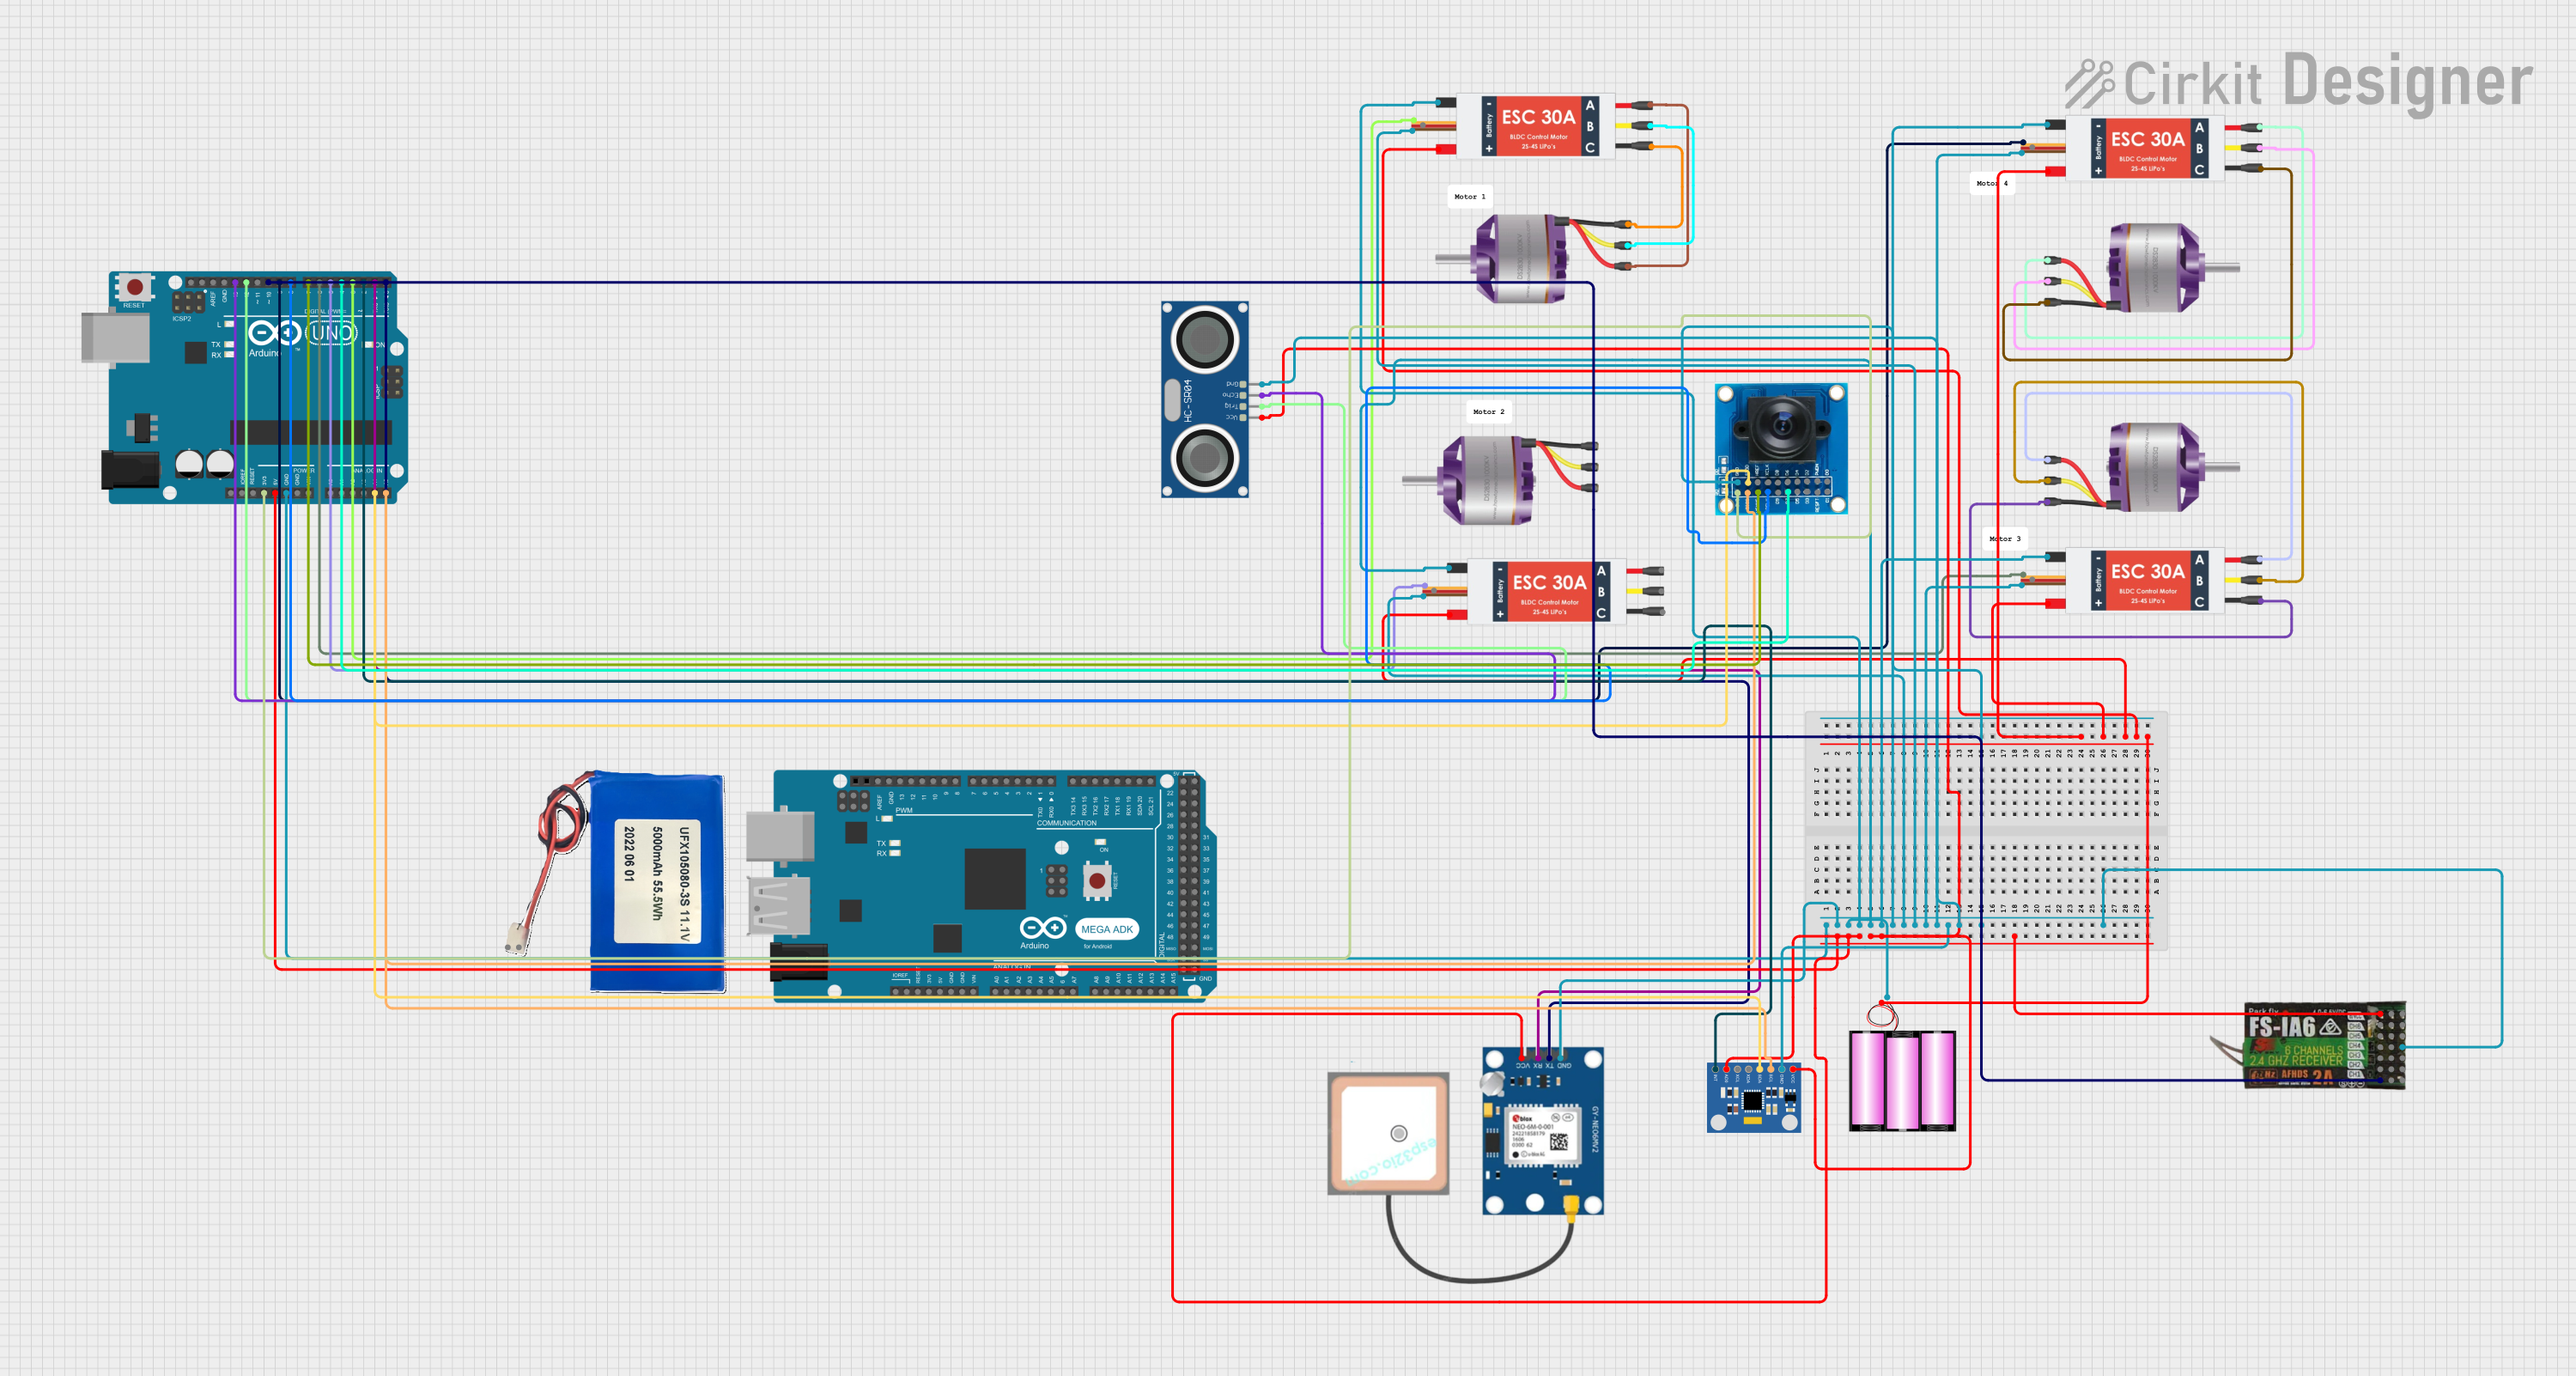
Circuit Documentation
Summary
This document provides a detailed overview of a circuit design that includes an Arduino UNO, various sensors, a GPS module, brushless motors, electronic speed controllers (ESCs), and other components. The circuit is designed to interface these components for a specific application, with the Arduino UNO serving as the central microcontroller.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
NEO-6M (GPS Module)
- Description: A GPS module for receiving satellite signals.
- Pins: GND, TX, RX, VCC
Brushless Motor
- Description: A motor that operates using electronic commutation.
- Pins: L1, L2, L3
Electronic Speed Controller (ESC)
- Description: A device to control the speed of the brushless motor.
- Pins: Battery VCC, Battery GND, Signal, 5V out, GND out, M1, M2, M3
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
- Description: A sensor module that provides accelerometer and gyroscope data.
- Pins: INT, AD0, XCL, XDA, SDA, SCL, GND, VCC
FLYSKY FS-IA6
- Description: A 6-channel receiver for remote control systems.
- Pins: CH1, 5V, GND, CH2, CH3, CH4, CH5, CH6, VCC
OV7725
- Description: A camera module for capturing images.
- Pins: 3V3, GND, SIOC, SIOD, VSYNC, HREF, PCLK, XCLK, D9, D8, D7, D6, D5, D4, D3, D2, RESET, D1, D0, PWDN
HC-SR04 Ultrasonic Sensor
- Description: A sensor for measuring distance using ultrasonic waves.
- Pins: VCC, TRIG, ECHO, GND
Li-ion 5000mAh
- Description: A rechargeable lithium-ion battery.
- Pins: 11.1V, GND
Battery 12V
- Description: A 12V battery for powering the circuit.
- Pins: +, -
Arduino Mega ADK (Rev3)
- Description: A microcontroller board based on the ATmega2560.
- Pins: A8, A9, A10, A11, A12, A13, A14, A15, A0, A1, A2, A3, A4, A5, A6, A7, D21/SCL, D20/SDA, D19/RX1, D18/TX1, D17/RX2, D16/TX2, D15/RX3, D14/TX3, ICSP2 MISO, 5V, ICSP2 SCK, ICSP2 MOSI, RESET2, GND, AREF, D13 PWM, D12 PWM, D11 PWM, D10 PWM, D9 PWM, D8 PWM, RESET, 3V3, VIN, D0/RX0, D1/TX0, D2 PWM, D3 PWM, D4 PWM, D5 PWM, D6 PWM, D7 PWM, D22, D23, D24, D25, D26, D27, D28, D29, D30, D31, D32, D33, D34, D35, D36, D37, D38, D39, D40, D41, D42, D43, D44, D45, D46, D47, D48, D49, D50/MISO, D51/MOSI, D52/SCK, D53/SS, ICSP MISO, ICSP MOSI, ICSP SCK, RESET3, IOREF
Wiring Details
Arduino UNO
GND connected to:
- NEO-6M (GPS Module) GND
- Battery 12V -
- ESC Battery GND (all instances)
- ESC GND out (all instances)
- MPU6050 GND
- HC-SR04 GND
- OV7725 GND
- FLYSKY FS-IA6 GND
5V connected to:
- NEO-6M (GPS Module) VCC
- MPU6050 AD0, VCC
- HC-SR04 VCC
- FLYSKY FS-IA6 VCC
3.3V connected to:
- OV7725 3V3
A4 connected to:
- OV7725 SIOD
- MPU6050 SDA
A5 connected to:
- OV7725 SIOC
- MPU6050 SCL
D13 connected to:
- HC-SR04 ECHO
D12 connected to:
- HC-SR04 TRIG
D10 connected to:
- FLYSKY FS-IA6 CH1
D9 connected to:
- ESC Signal (instance 5a19b957-fc6e-403c-b89b-026e3b113dd7)
D8 connected to:
- OV7725 PCLK
D7 connected to:
- OV7725 VSYNC
D6 connected to:
- ESC Signal (instance eca8b3b3-3af7-42e1-9235-e79f2e16eb97)
D5 connected to:
- ESC Signal (instance f91d8dcb-9acd-4965-bb48-4be7cb79fad3)
D4 connected to:
- OV7725 D7
D3 connected to:
- ESC Signal (instance 8b837c74-4e37-40a5-bf1f-6aaa56bcc2be)
D2 connected to:
- MPU6050 INT
D1 connected to:
- NEO-6M (GPS Module) RX
D0 connected to:
- NEO-6M (GPS Module) TX
NEO-6M (GPS Module)
- GND connected to Arduino UNO GND
- VCC connected to Arduino UNO 5V
- RX connected to Arduino UNO D1
- TX connected to Arduino UNO D0
Brushless Motor
- L1 connected to ESC M1
- L2 connected to ESC M2
- L3 connected to ESC M3
Electronic Speed Controller (ESC)
- Battery VCC connected to Battery 12V +
- Battery GND connected to Arduino UNO GND
- Signal connected to Arduino UNO D9, D6, D5, D3
- 5V out not connected
- GND out connected to Arduino UNO GND
- M1 connected to Brushless Motor L1
- M2 connected to Brushless Motor L2
- M3 connected to Brushless Motor L3
MPU6050 Accelerometer + Gyroscope (Wokwi Compatible)
- GND connected to Arduino UNO GND
- VCC connected to Arduino UNO 5V
- SDA connected to Arduino UNO A4
- SCL connected to Arduino UNO A5
- INT connected to Arduino UNO D2
FLYSKY FS-IA6
- GND connected to Arduino UNO GND
- VCC connected to Arduino UNO 5V
- CH1 connected to Arduino UNO D10
OV7725
- GND connected to Arduino UNO GND
- 3V3 connected to Arduino UNO 3.3V
- SIOD connected to Arduino UNO A4
- SIOC connected to Arduino UNO A5
- VSYNC connected to Arduino UNO D7
- PCLK connected to Arduino UNO D8
- D7 connected to Arduino UNO D4
HC-SR04 Ultrasonic Sensor
- GND connected to Arduino UNO GND
- VCC connected to Arduino UNO 5V
- TRIG connected to Arduino UNO D12
- ECHO connected to Arduino UNO D13
Li-ion 5000mAh
- Not connected in this circuit
Battery 12V
- + connected to ESC Battery VCC