
Arduino and ESP-8266 Controlled Peristaltic Pump and Stepper Motor System with L298N Motor Drivers
View and Edit Project In Cirkit Designer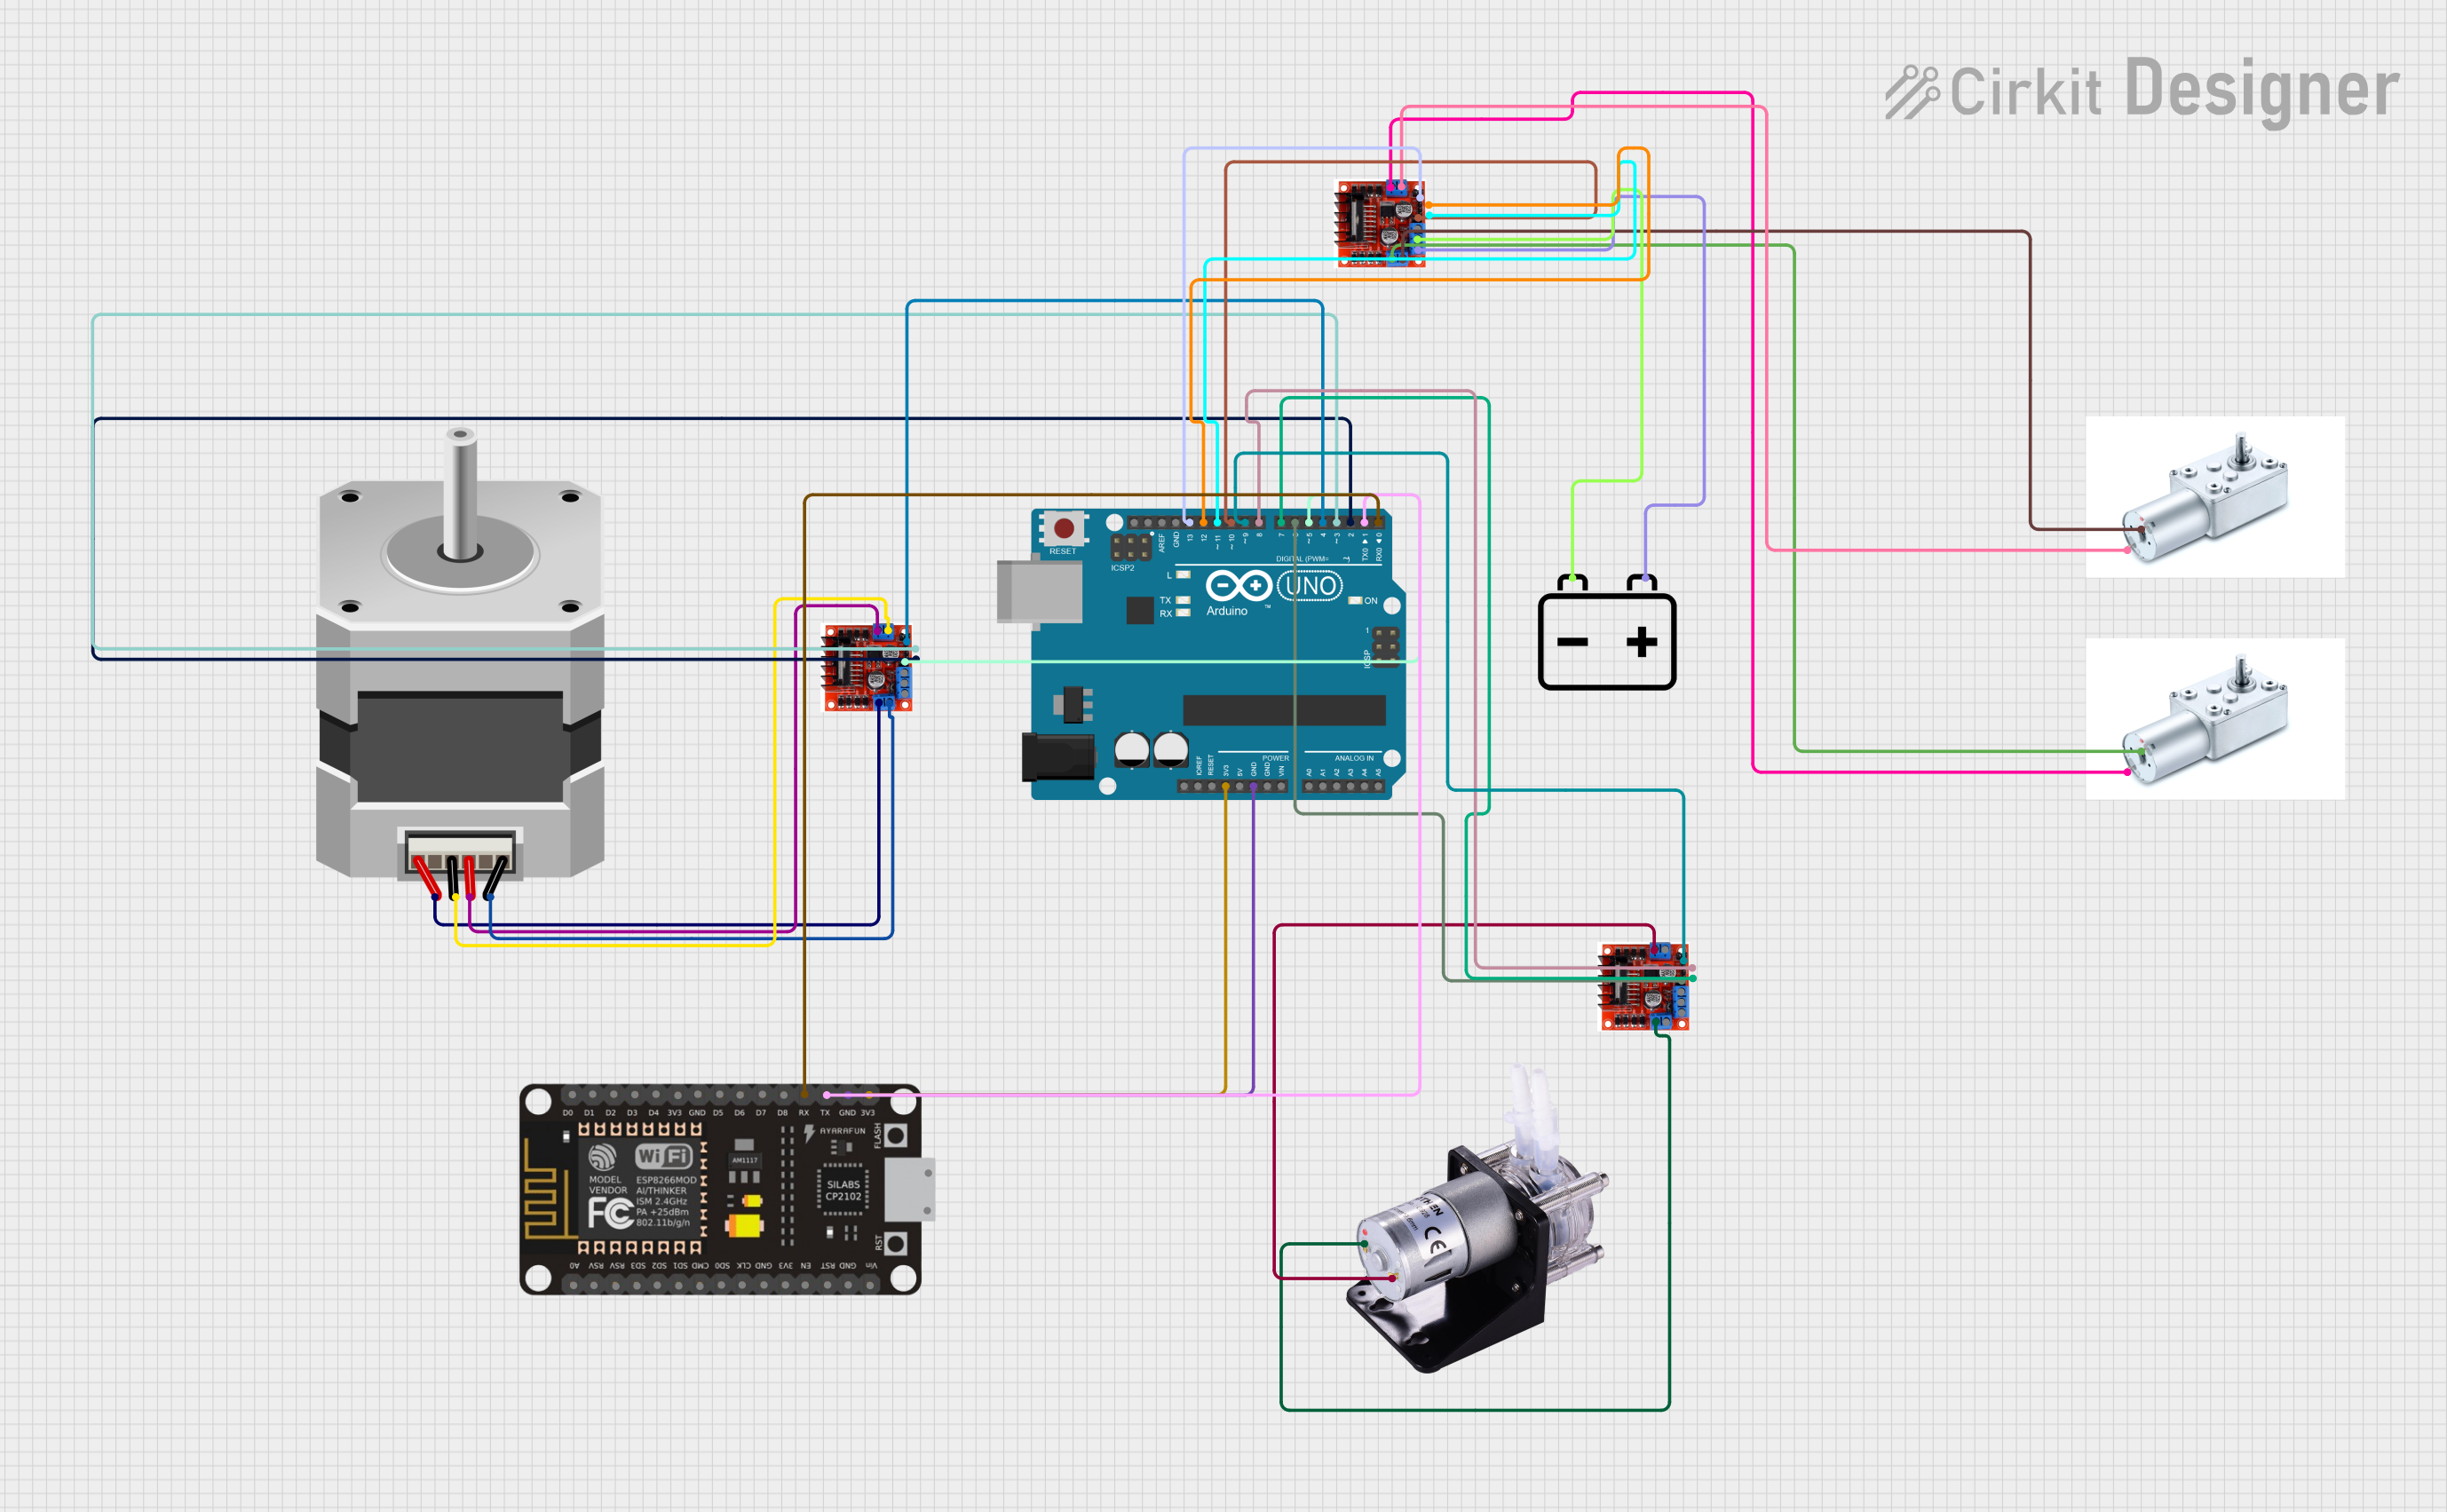
Circuit Documentation
Summary
The circuit in question is designed to control a peristaltic pump and two types of motors (a NEMA23 stepper motor and two Greartisan DC 12V 45RPM Turbo Worm Geared Motors) using an Arduino UNO microcontroller and three L298N Motor Driver Controller Board Modules. An ESP-8266 Controller is also included, interfaced with the Arduino UNO for potential IoT capabilities. The circuit is powered by a 12V battery, which supplies power to the motor drivers and subsequently to the motors.
Component List
Peristaltic Pump
- A pump that moves fluid by squeezing a flexible tube, typically used for precise fluid transport.
Arduino UNO
- A microcontroller board based on the ATmega328P, with a variety of digital and analog I/O pins.
L298N Motor Driver Controller Board Module
- A high-power motor driver capable of driving inductive loads such as relays, solenoids, and DC and stepping motors.
NEMA23 Stepper Motor
- A stepper motor with a 2.3-inch faceplate, commonly used for precise control of position and speed.
12V Battery
- A power source for the circuit, providing the necessary voltage for the motor drivers and motors.
Greartisan DC 12V 45RPM Turbo Worm Geared Motor
- A geared motor that provides high torque at low speeds, suitable for applications requiring robust force at slower rotations.
ESP-8266 Controller
- A Wi-Fi capable microcontroller module that can be used for Internet of Things (IoT) applications.
Wiring Details
Peristaltic Pump
- Connected to the output of the first L298N Motor Driver.
Arduino UNO
- Digital pins D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, and D2 are used to control the inputs of the L298N Motor Drivers.
- Pins 3.3V and GND are used to power the ESP-8266 Controller.
- Pins D1 (TX) and D0 (RX) are used for serial communication with the ESP-8266 Controller.
L298N Motor Driver Controller Board Module
- Three instances of this driver are used to control the Peristaltic Pump, NEMA23 Stepper Motor, and two Greartisan DC Motors.
- Each driver's inputs are controlled by specific pins from the Arduino UNO.
- The drivers are powered by the 12V battery.
NEMA23 Stepper Motor
- Connected to the outputs of the third L298N Motor Driver.
12V Battery
- Provides power to the L298N Motor Drivers.
Greartisan DC 12V 45RPM Turbo Worm Geared Motors
- Each motor is connected to the outputs of the second and third L298N Motor Drivers.
ESP-8266 Controller
- Powered by the 3.3V and GND pins from the Arduino UNO.
- Communicates with the Arduino UNO via the TX and RX pins.
Documented Code
Arduino UNO Code (sketch.ino)
void setup() {
  // put your setup code here, to run once:

}

void loop() {
  // put your main code here, to run repeatedly:

}
Note: The provided code for the Arduino UNO is a template with empty setup and loop functions. The user is expected to fill in the code to control the motors via the L298N Motor Drivers and to handle communication with the ESP-8266 Controller.
ESP-8266 Controller Code
No code was provided for the ESP-8266 Controller.
End of documentation.