
ESP32-Based Autonomous Vehicle with Ultrasonic Sensing and GPS Tracking
View and Edit Project In Cirkit Designer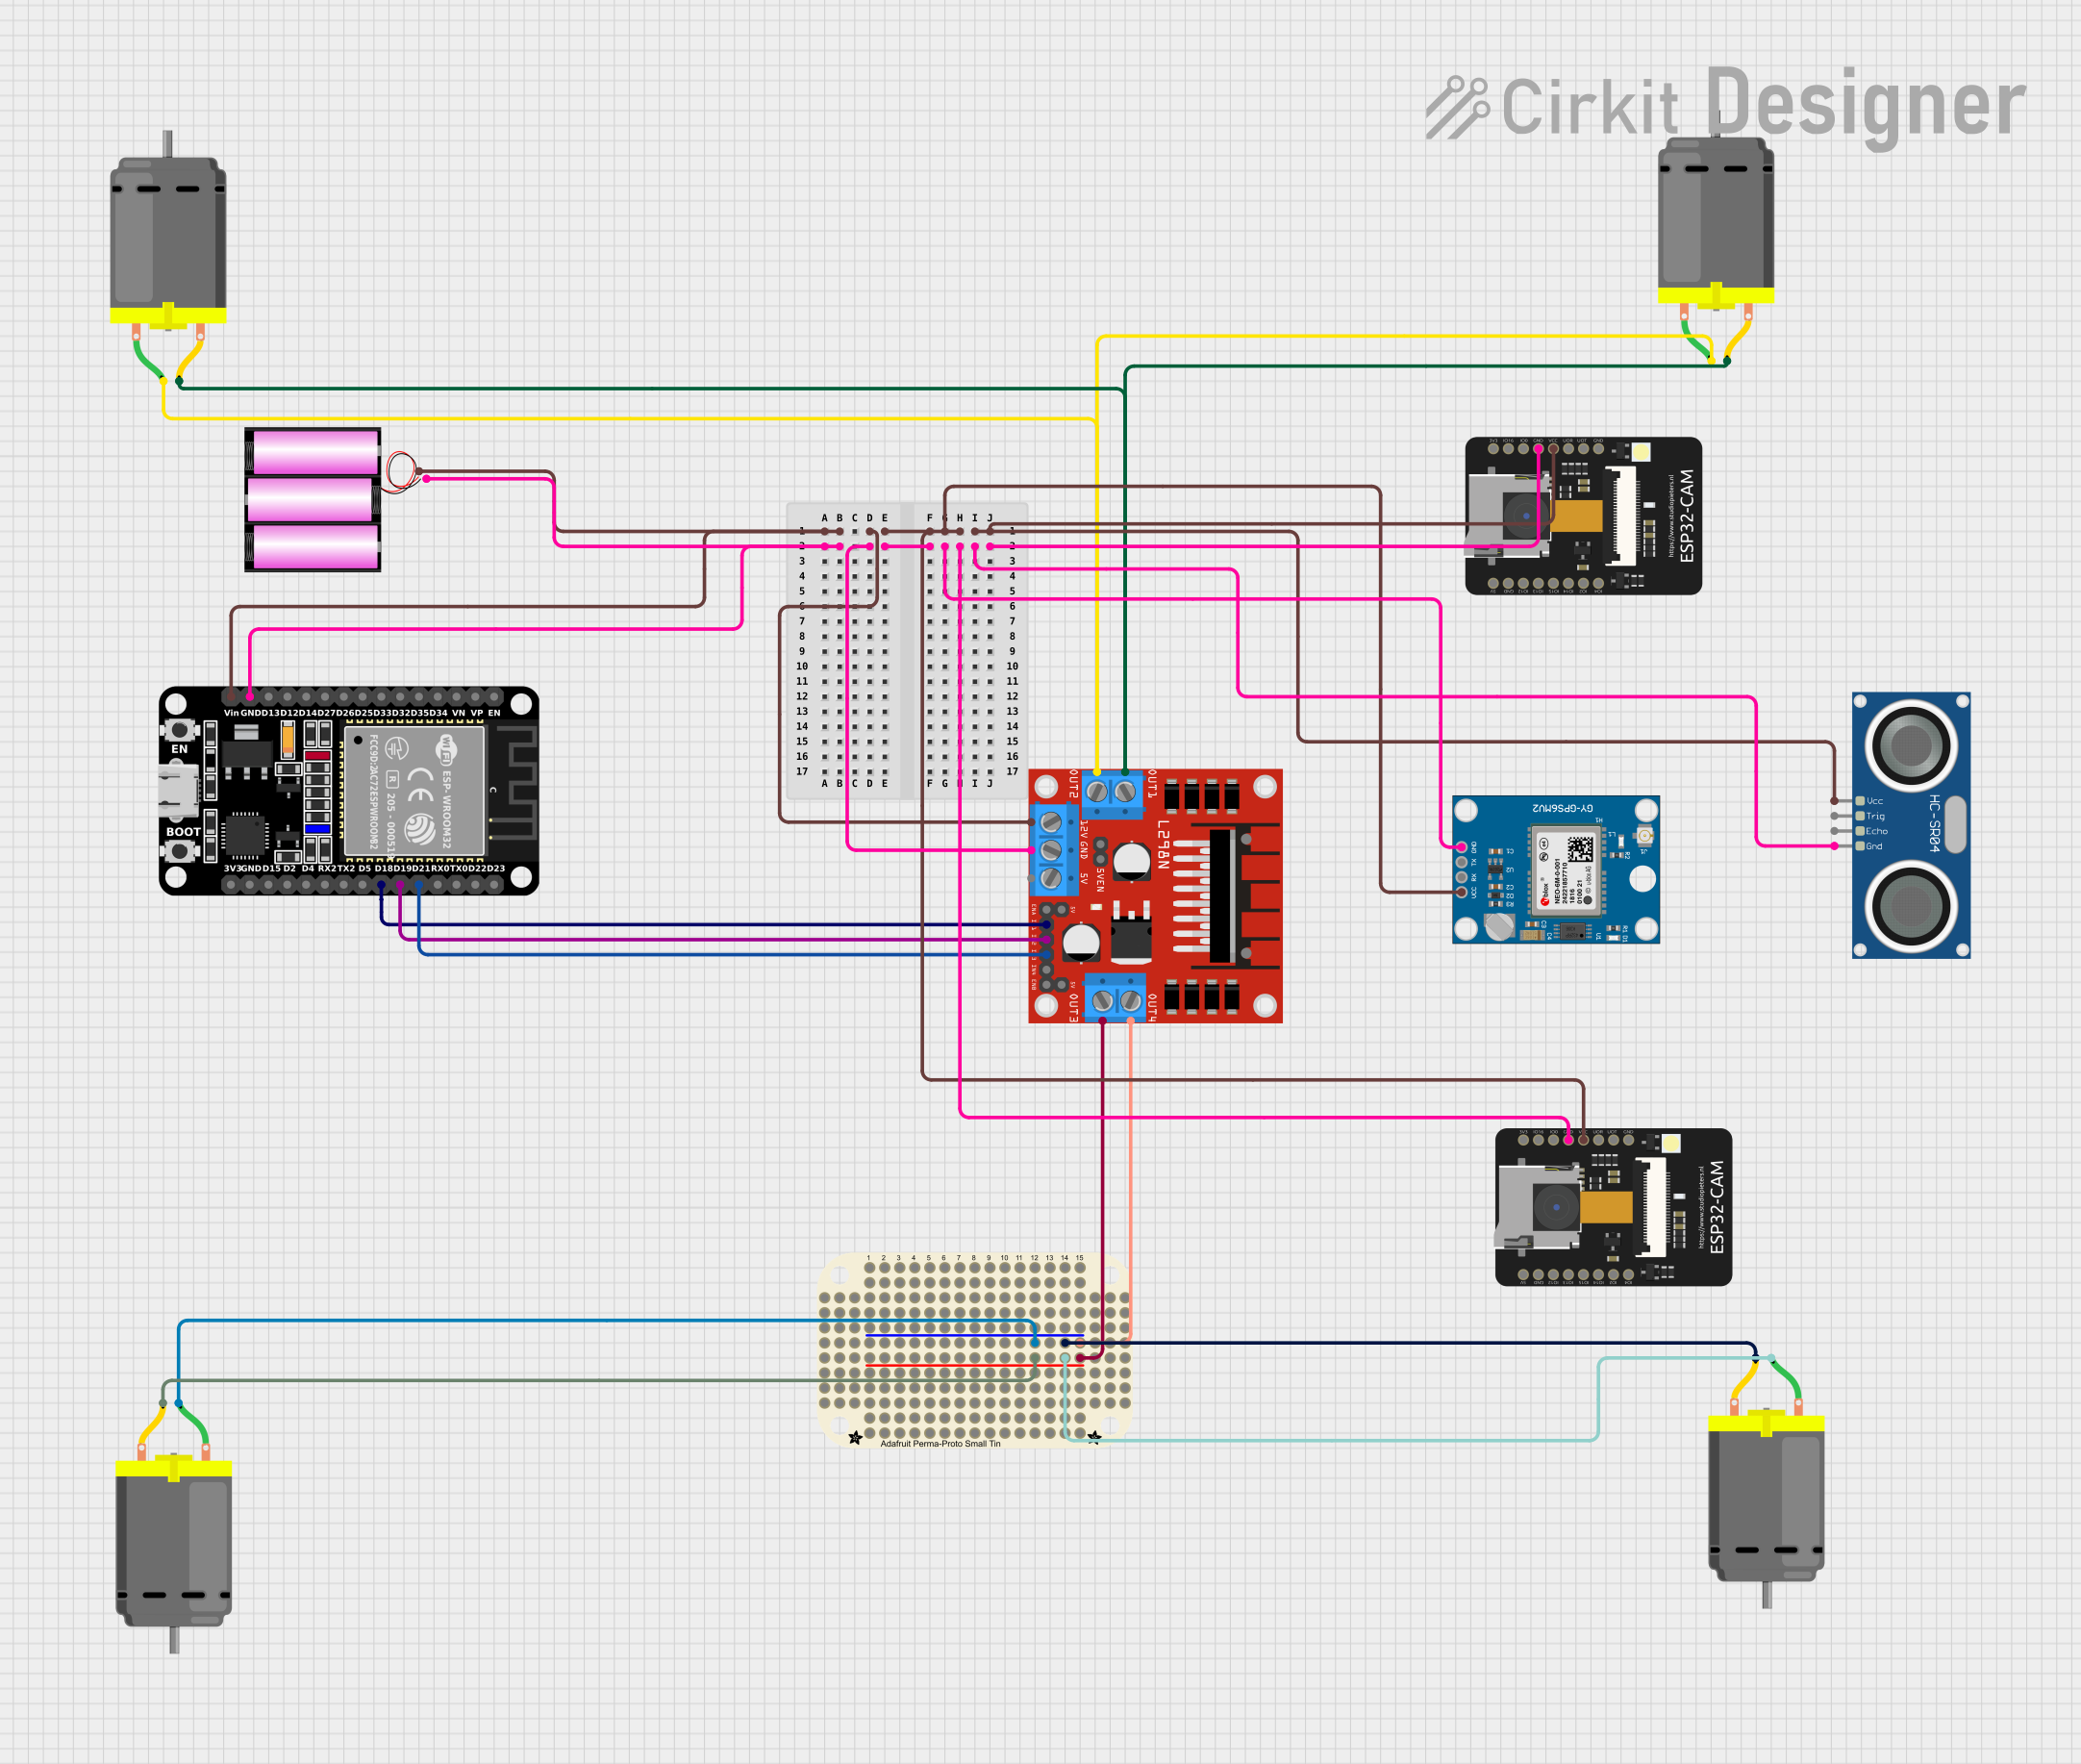
Circuit Documentation
Summary
The circuit in question is designed to interface an HC-SR04 Ultrasonic Sensor, two ESP32 microcontroller modules (one of which is an ESP32-CAM), a Neo 6M GPS Module, and four DC Motors through an L298N DC motor driver. The circuit is powered by a 12V battery, and the components are interconnected to perform specific functions, which could include distance measurement, wireless communication, motor control, and GPS positioning. The ESP32 modules are likely to be the central processing units, controlling the motors and sensors, and handling data communication.
Component List
HC-SR04 Ultrasonic Sensor
- Pins: VCC, TRIG, ECHO, GND
- Description: A sensor used for measuring distances via ultrasonic waves.
ESP32 (30 pin)
- Pins: EN, VP, VN, D34, D35, D32, D33, D25, D26, D27, D14, D12, D13, GND, Vin, D23, D22, TX0, RX0, D21, D19, D18, D5, TX2, RX2, D4, D2, D15, 3V3
- Description: A microcontroller with Wi-Fi and Bluetooth capabilities, used for various I/O and wireless tasks.
L298N DC Motor Driver
- Pins: OUT1, OUT2, 12V, GND, 5V, OUT3, OUT4, 5V-ENA-JMP-I, 5V-ENA-JMP-O, +5V-J1, +5V-J2, ENA, IN1, IN2, IN3, IN4, ENB
- Description: A module used to control the direction and speed of DC motors.
ESP32-CAM
- Pins: 5V, GND, IO12, IO13, IO15, IO14, IO2, IO4, VOT, VOR, VCC, IO0, IO16, 3V3
- Description: An ESP32 variant with an integrated camera, used for image capturing and processing.
DC Motor
- Pins: pin 1, pin 2
- Description: An electric motor that converts electrical energy into mechanical rotation.
Neo 6M GPS Module
- Pins: GND, TX, RX, VCC
- Description: A module used for obtaining geographical position data via satellite signals.
Adafruit Perma Proto Small Mint
- Pins: A, AA, B, BB, C, CC, D, DD, E, F, G, GND, H, I, J, K, L, M, N, and various numbered nets
- Description: A prototyping board used for making permanent circuit connections.
Battery 12V
- Pins: +, -
- Description: A power source providing 12V to the circuit.
Wiring Details
HC-SR04 Ultrasonic Sensor
- VCC: Connected to 12V power supply.
- GND: Connected to ground.
- TRIG: (Connection details not provided)
- ECHO: (Connection details not provided)
ESP32 (30 pin)
- Vin: Connected to 12V power supply.
- GND: Connected to ground.
- D21: Connected to IN3 on L298N DC motor driver.
- D19: Connected to IN2 on L298N DC motor driver.
- D18: Connected to IN1 on L298N DC motor driver.
- (Other pins are not detailed in the provided net list)
L298N DC Motor Driver
- 12V: Connected to 12V power supply.
- GND: Connected to ground.
- OUT1, OUT2: Connected to DC Motors.
- OUT3, OUT4: Connected to Adafruit Perma Proto Small Mint board.
- IN1, IN2, IN3: Controlled by ESP32 (30 pin) microcontroller.
ESP32-CAM
- VCC: Connected to 12V power supply.
- GND: Connected to ground.
- (Other pins are not detailed in the provided net list)
DC Motors
- pin 1: Connected to OUT2 or OUT4 on L298N DC motor driver or Adafruit Perma Proto Small Mint board.
- pin 2: Connected to OUT1 or OUT3 on L298N DC motor driver or Adafruit Perma Proto Small Mint board.
Neo 6M GPS Module
- VCC: Connected to 12V power supply.
- GND: Connected to ground.
- TX, RX: (Connection details not provided)
Adafruit Perma Proto Small Mint
- PWR: Connected to OUT3 on L298N DC motor driver and DC Motors.
- GND: Connected to OUT4 on L298N DC motor driver and DC Motors.
Battery 12V
- +: Connected to VCC of various components.
- -: Connected to GND of various components.
Documented Code
No code was provided in the input. Typically, this section would include the source code for the microcontrollers, along with comments explaining the functionality of each part of the code. Since no code is available, it is recommended to check the source or request the code from the designer for complete documentation.