
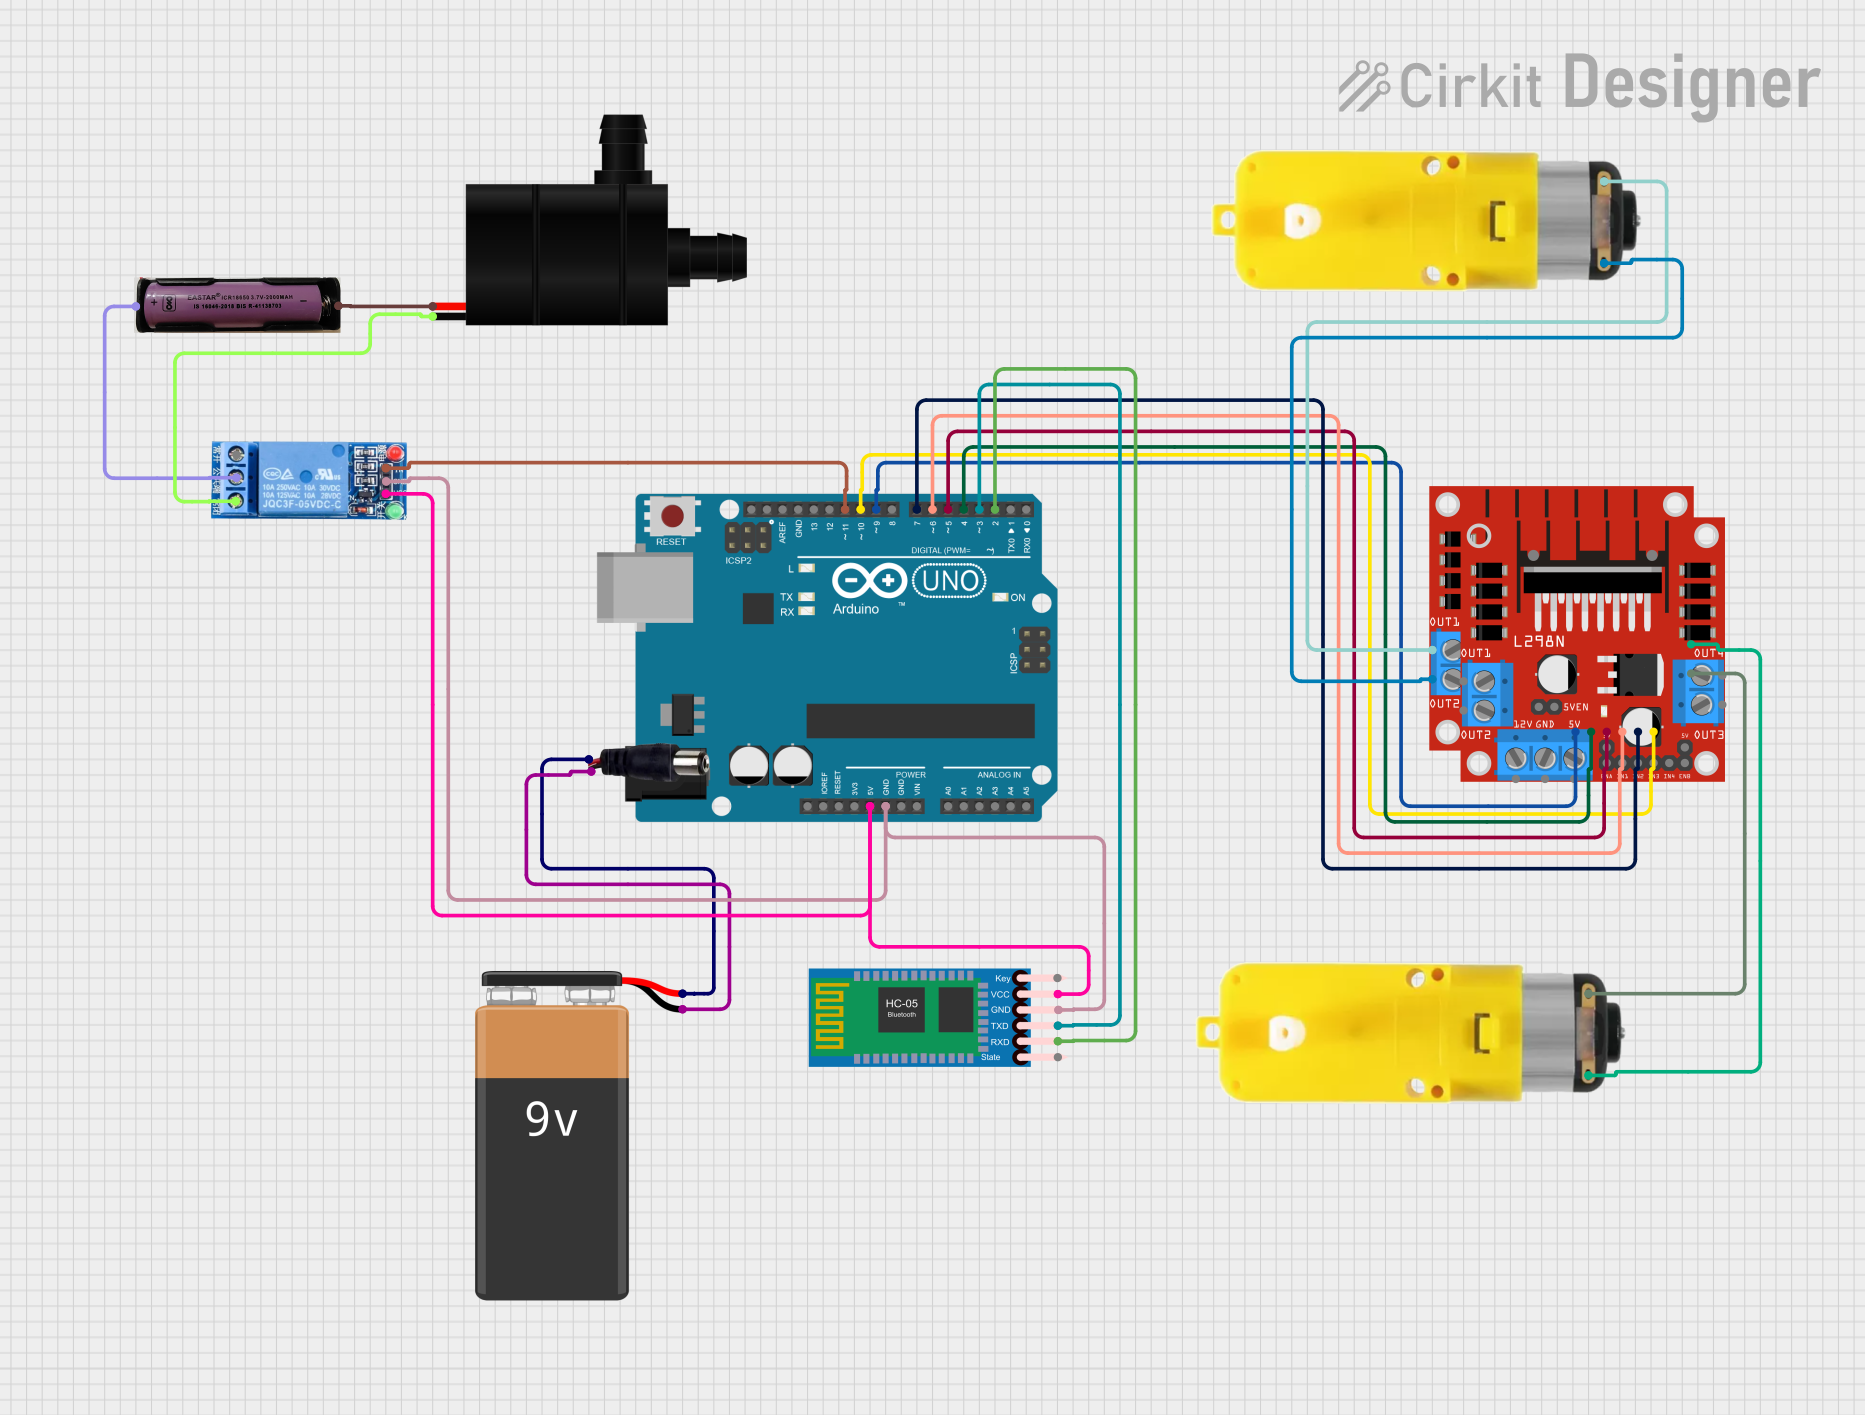
Solar Panel Cleaning Robot Circuit Documentation
Summary
This document provides a detailed overview of the Solar Panel Cleaning Robot circuit. The robot is controlled by an Arduino UNO and includes two motors for movement, a water pump for cleaning, and a Bluetooth module for remote control. The robot can move forward, backward, turn left, turn right, and stop based on commands received via Bluetooth.
Component List
Arduino UNO
- Description: Microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
9V Battery
- Description: Power source for the circuit.
- Pins: -, +
Power Jack
- Description: Connector for the 9V battery.
- Pins: POSITIF, NEGATIF
Motor with Reducer (x2)
- Description: Motor with a gear reducer for movement.
- Pins: 3 - 6 VCC, GND
L298N DC Motor Driver (x2)
- Description: Dual H-Bridge motor driver for controlling the motors.
- Pins: OUT1, OUT2, 12V, GND, 5V, OUT3, OUT4, 5V-ENA-JMP-I, 5V-ENA-JMP-O, +5V-J1, +5V-J2, ENA, IN1, IN2, IN3, IN4, ENB
HC-05 Bluetooth Module
- Description: Bluetooth module for remote control.
- Pins: Key, VCC, TXD, RXD, State, GND
Water Pump
- Description: Pump for cleaning the solar panel.
- Pins: VCC, GND
1 Channel Relay 5V
- Description: Relay module for controlling the water pump.
- Pins: VCC, GND, IN, NC, COM, NO
3.7V Battery
- Description: Power source for the water pump.
- Pins: +, -
Wiring Details
Arduino UNO
- 5V connected to VCC of HC-05 Bluetooth Module and 1 Channel Relay 5V.
- GND connected to GND of HC-05 Bluetooth Module and 1 Channel Relay 5V.
- D11 connected to IN of 1 Channel Relay 5V.
- D10 connected to ENB of L298N DC Motor Driver.
- D9 connected to ENA of L298N DC Motor Driver.
- D7 connected to IN4 of L298N DC Motor Driver.
- D6 connected to IN3 of L298N DC Motor Driver.
- D5 connected to IN2 of L298N DC Motor Driver.
- D4 connected to IN1 of L298N DC Motor Driver.
- D3 connected to TXD of HC-05 Bluetooth Module.
- D2 connected to RXD of HC-05 Bluetooth Module.
9V Battery
- - connected to NEGATIF of Power Jack.
- + connected to POSITIF of Power Jack.
Power Jack
- NEGATIF connected to - of 9V Battery.
- POSITIF connected to + of 9V Battery.
Motor with Reducer (1)
- 3 - 6 VCC connected to OUT1 of L298N DC Motor Driver.
- GND connected to OUT2 of L298N DC Motor Driver.
Motor with Reducer (2)
- 3 - 6 VCC connected to OUT3 of L298N DC Motor Driver.
- GND connected to OUT4 of L298N DC Motor Driver.
L298N DC Motor Driver
- OUT1 connected to 3 - 6 VCC of Motor with Reducer (1).
- OUT2 connected to GND of Motor with Reducer (1).
- OUT3 connected to 3 - 6 VCC of Motor with Reducer (2).
- OUT4 connected to GND of Motor with Reducer (2).
- ENB connected to D10 of Arduino UNO.
- ENA connected to D9 of Arduino UNO.
- IN4 connected to D7 of Arduino UNO.
- IN3 connected to D6 of Arduino UNO.
- IN2 connected to D5 of Arduino UNO.
- IN1 connected to D4 of Arduino UNO.
HC-05 Bluetooth Module
- VCC connected to 5V of Arduino UNO.
- GND connected to GND of Arduino UNO.
- TXD connected to D3 of Arduino UNO.
- RXD connected to D2 of Arduino UNO.
Water Pump
- VCC connected to - of 3.7V Battery.
- GND connected to NO of 1 Channel Relay 5V.
1 Channel Relay 5V
- VCC connected to 5V of Arduino UNO.
- GND connected to GND of Arduino UNO.
- IN connected to D11 of Arduino UNO.
- NO connected to GND of Water Pump.
- COM connected to + of 3.7V Battery.
3.7V Battery
- + connected to COM of 1 Channel Relay 5V.
- - connected to VCC of Water Pump.
Documented Code
/*
 * Arduino Sketch for Solar Panel Cleaning Robot
 * This code controls a solar panel cleaning robot using an Arduino UNO. The robot
 * is equipped with two motors for movement, a water pump for cleaning, and a
 * Bluetooth module for remote control. The robot can move forward, backward,
 * turn left, turn right, and stop based on commands received via Bluetooth.
 */

#include <SoftwareSerial.h>

// Bluetooth module connected to pins 2 (RX) and 3 (TX)
SoftwareSerial mySerial(2, 3);

// Motor driver pins
int Rightmotor1 = 4;
int Rightmotor2 = 5;
int leftmotor1 = 6;
int leftmotor2 = 7;
int en1 = 9;
int en2 = 10;

// Relay pin for water pump
int relayPin = 11;

// String to hold incoming Bluetooth data
String command = "";

void setup() {
  // Initialize motor pins
  pinMode(Rightmotor1, OUTPUT);
  pinMode(Rightmotor2, OUTPUT);
  pinMode(leftmotor1, OUTPUT);
  pinMode(leftmotor2, OUTPUT);
  pinMode(en1, OUTPUT);
  pinMode(en2, OUTPUT);
  pinMode(relayPin, OUTPUT);

  // Start serial communication for debugging and Bluetooth
  Serial.begin(9600);
  mySerial.begin(9600);

  Serial.println("Bluetooth Car Ready!");
}

void loop() {
  if (mySerial.available()) {
    char received = mySerial.read(); // Read the single character command
    if (received == 'F') {
      moveForward(); // Move forward
    } else if (received == 'B') {
      moveBackward(); // Move backward
    } else if (received == 'L') {
      turnLeft(); // Turn left
    } else if (received == 'R') {
      turnRight(); // Turn right
    } else if (received == 'S') {
      stopMotors(); // Stop
    } else if (received == 'P') {
      startPump(); // Start water pump
    } else if (received == 'O') {
      stopPump(); // Stop water pump
    }
  }
}

// Movement functions
void moveForward() {
  digitalWrite(Rightmotor1, HIGH);
  digitalWrite(Rightmotor2, LOW);
  digitalWrite(leftmotor1, HIGH);
  digitalWrite(leftmotor2, LOW);
  analogWrite(en1, 200);  // Adjust speed as needed (0-255)
  analogWrite(en2, 200);
  Serial.println("Moving Forward");
}

void moveBackward() {
  digitalWrite(Rightmotor1, LOW);
  digitalWrite(Rightmotor2, HIGH);
  digitalWrite(leftmotor1, LOW);
  digitalWrite(leftmotor2, HIGH);
  analogWrite(en1, 200);
  analogWrite(en2, 200);
  Serial.println("Moving Backward");
}

void turnLeft() {
  digitalWrite(Rightmotor1, HIGH);
  digitalWrite(Rightmotor2, LOW);
  digitalWrite(leftmotor1, LOW);
  digitalWrite(leftmotor2, HIGH);
  analogWrite