
Circuit Documentation
Summary of the Circuit
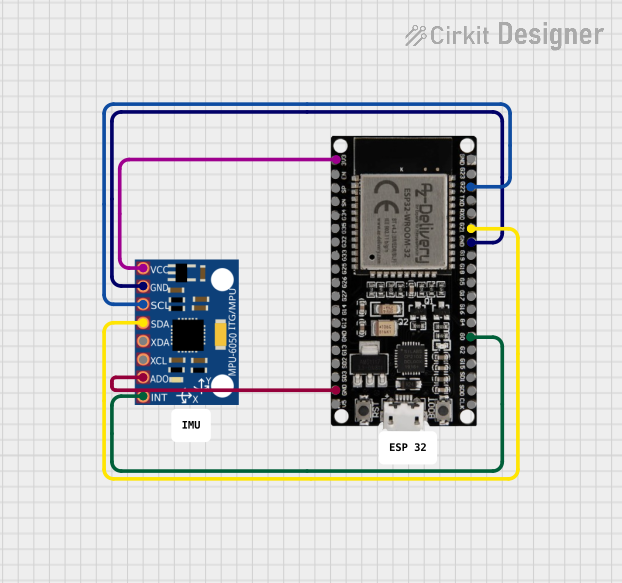
This circuit integrates an ESP32 microcontroller with an MPU-6050 motion sensor. The ESP32 is a versatile microcontroller with Wi-Fi and Bluetooth capabilities, and it is used here as the central processing unit to interface with the MPU-6050, which is a 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer.
The ESP32 reads data from the MPU-6050 over an I2C connection, which is a common communication protocol for microcontrollers and peripherals. The ground and power connections are established between the two components, and an interrupt line is connected from the MPU-6050 to the ESP32 to signal when new data is available.
Component List
ESP32 38 PINS
- Description: A microcontroller with Wi-Fi and Bluetooth capabilities, featuring a wide range of GPIO pins.
- Purpose: Acts as the central processing unit for the circuit, interfacing with the MPU-6050 sensor and handling data processing and communication.
MPU-6050
- Description: A 6-axis motion tracking device that combines a 3-axis gyroscope and a 3-axis accelerometer.
- Purpose: Provides motion tracking data to the ESP32 for processing.
Comments
- Description: Placeholder components for additional notes or documentation within the circuit design. These do not have a physical presence in the circuit.
Wiring Details
ESP32 38 PINS Wiring
- G22 connected to MPU-6050 SCL (I2C clock line)
- G21 connected to MPU-6050 SDA (I2C data line)
- GND connected to MPU-6050 GND (ground connection)
- G0 connected to MPU-6050 INT (interrupt signal)
- 3V3 connected to MPU-6050 VCC (power supply)
- GND connected to MPU-6050 AD0 (I2C address selection, grounded for default address)
MPU-6050 Wiring
- SCL connected to ESP32 G22 (I2C clock line)
- SDA connected to ESP32 G21 (I2C data line)
- GND connected to ESP32 GND (ground connection)
- INT connected to ESP32 G0 (interrupt signal)
- VCC connected to ESP32 3V3 (power supply)
- AD0 connected to ESP32 GND (I2C address selection, grounded for default address)
Documented Code
No code has been provided for the microcontroller. Typically, this section would include the embedded code written for the ESP32, detailing the setup and main loop, along with any interrupt service routines or functions used to communicate with the MPU-6050. Since no code is available, this section remains empty. When code is added, it should be documented here with explanations of its functionality and purpose within the circuit.