
Circuit Documentation
Summary
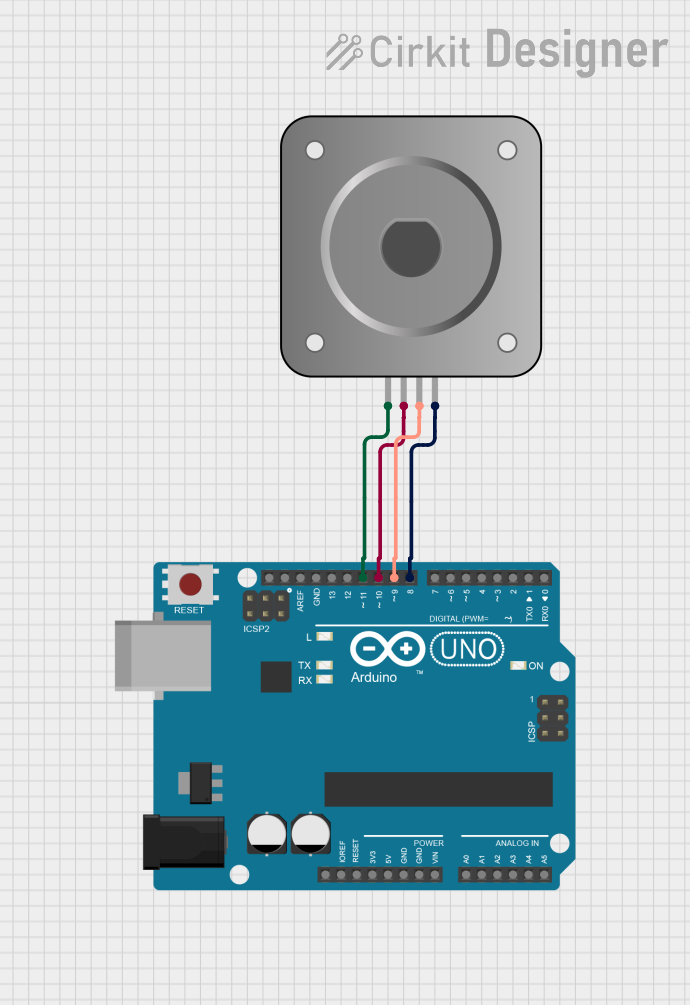
This circuit involves an Arduino UNO microcontroller controlling a Bipolar Stepper Motor (NEMA 17). The Arduino UNO is programmed to drive the stepper motor using a simple direct drive method. The connections between the Arduino and the stepper motor are established through digital pins D8, D9, D10, and D11.
Component List
Arduino UNO
- Description: A microcontroller board based on the ATmega328P.
- Pins: UNUSED, IOREF, Reset, 3.3V, 5V, GND, Vin, A0, A1, A2, A3, A4, A5, SCL, SDA, AREF, D13, D12, D11, D10, D9, D8, D7, D6, D5, D4, D3, D2, D1, D0
- Purpose in Circuit: To control the Bipolar Stepper Motor.
Bipolar Stepper Motor (NEMA 17)
- Description: A type of stepper motor with two coils.
- Pins: A-, A+, B+, B-
- Purpose in Circuit: To be driven by the Arduino UNO to perform rotational movements.
Wiring Details
Arduino UNO
- D11: Connected to A- of the Bipolar Stepper Motor.
- D10: Connected to A+ of the Bipolar Stepper Motor.
- D9: Connected to B+ of the Bipolar Stepper Motor.
- D8: Connected to B- of the Bipolar Stepper Motor.
Bipolar Stepper Motor (NEMA 17)
- A-: Connected to D11 of the Arduino UNO.
- A+: Connected to D10 of the Arduino UNO.
- B+: Connected to D9 of the Arduino UNO.
- B-: Connected to D8 of the Arduino UNO.
Code Documentation
Arduino UNO Code
/*---------------------------------------*\
| Simple direct drive of Bipolar Stepper  |
\*---------------------------------------*/

// pins connected
#define Ap 10  // A+ line
#define Am 11  // A- line
#define Bp 9   //  .
#define Bm 8   //  .

void setup() {
  // set output
  pinMode(Ap,OUTPUT);  pinMode(Am,OUTPUT);
  pinMode(Bp,OUTPUT);  pinMode(Bm,OUTPUT);
}

int I = 0 ;
void loop() {
  // This is Wave Fullstep motion - only one coil energized at a time
  if ( I++ <25 ) {  // stop after 25*4 steps (=100) - quarter turn with gearRatio "2:1"
    delay(10);
    digitalWrite(Bm,LOW);  digitalWrite(Ap,HIGH);
    delay(10);
    digitalWrite(Ap,LOW);  digitalWrite(Bp,HIGH);
    delay(10);
    digitalWrite(Bp,LOW);  digitalWrite(Am,HIGH);
    delay(10);
    digitalWrite(Am,LOW);  digitalWrite(Bm,HIGH);
  } else while(1);
}
This code sets up the Arduino UNO to control the Bipolar Stepper Motor using a wave full-step motion, where only one coil is energized at a time. The motor will perform 100 steps, which corresponds to a quarter turn with a gear ratio of 2:1.