
Battery-Powered Robotic Control System with RP Lidar and Encoder Feedback
View and Edit Project In Cirkit Designer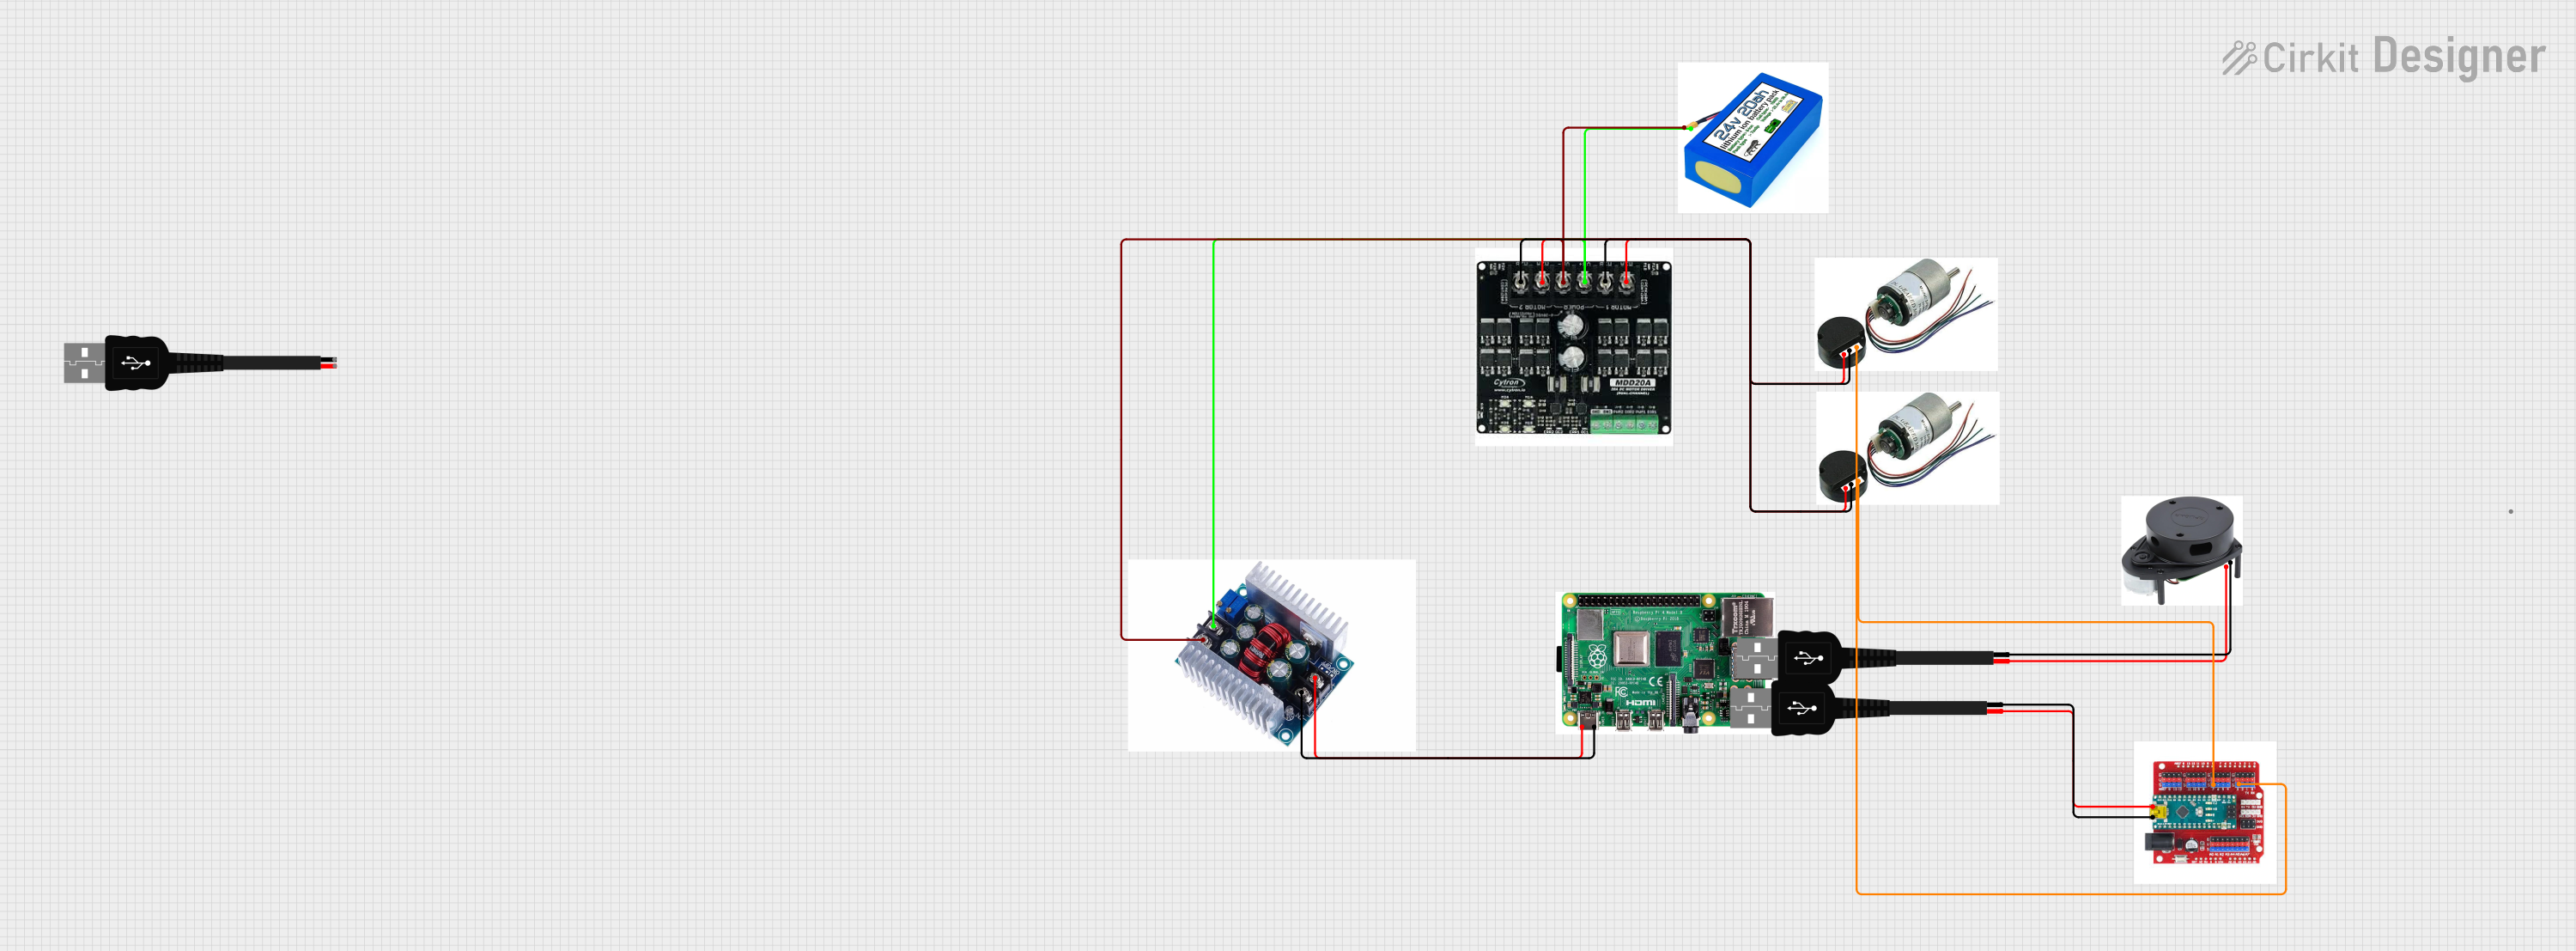
Circuit Documentation
Summary
The circuit in question is designed to control a pair of motors using a motor driver, with power supplied by a battery through a buck converter. The buck converter steps down the voltage to power a Raspberry Pi (referred to as "ras") and a microcontroller (referred to as "nano"). The nano is also connected to the motor encoders for feedback. Additionally, an RP Lidar unit is included for environmental scanning, powered by a USB connection.
Component List
Battery
- Description: Provides the main power source for the circuit.
Motor Driver
- Description: Controls the power supplied to the motors, allowing for speed and direction control.
Motors (x2)
- Description: Converts electrical energy into mechanical motion. Includes encoders for position feedback.
Buck Converter
- Description: Steps down the voltage from the battery to a lower voltage suitable for the Raspberry Pi and the nano.
Raspberry Pi (ras)
- Description: A small computer used for processing and control tasks within the circuit.
RP Lidar
- Description: A sensor used for measuring distances and mapping the environment.
Nano
- Description: A microcontroller used for interfacing with the motor encoders and possibly other low-level control tasks.
USB Male 2 Pin Connection (x3)
- Description: Provides a connection interface for power delivery to the RP Lidar and the nano.
Wiring Details
Battery
- Provides power to the buck converter and the motor driver.
Motor Driver
- Receives power from the battery.
- Controls two motors, providing power and ground connections to each.
- Interfaced with the motor encoders through the nano.
Motors
- Each motor receives power and ground from the motor driver.
- Encoder outputs are connected to the nano for feedback.
Buck Converter
- Input is connected to the battery.
- Output provides a stepped-down voltage to the Raspberry Pi.
Raspberry Pi (ras)
- Powered by the buck converter.
RP Lidar
- Powered by one of the USB connections.
Nano
- Receives power from one of the USB connections.
- Reads encoder signals from both motors.
USB Male 2 Pin Connection
- Three instances are used to provide power connections to the RP Lidar and the nano.
Documented Code
No code has been provided for the microcontrollers in the circuit. When code becomes available, it should be documented here with explanations for each function and routine, as well as any relevant algorithms or logic used in the control of the circuit components.