
ESP32-S3 Based Wi-Fi-Controlled Robotic Platform with Sensing and Actuation
View and Edit Project In Cirkit Designer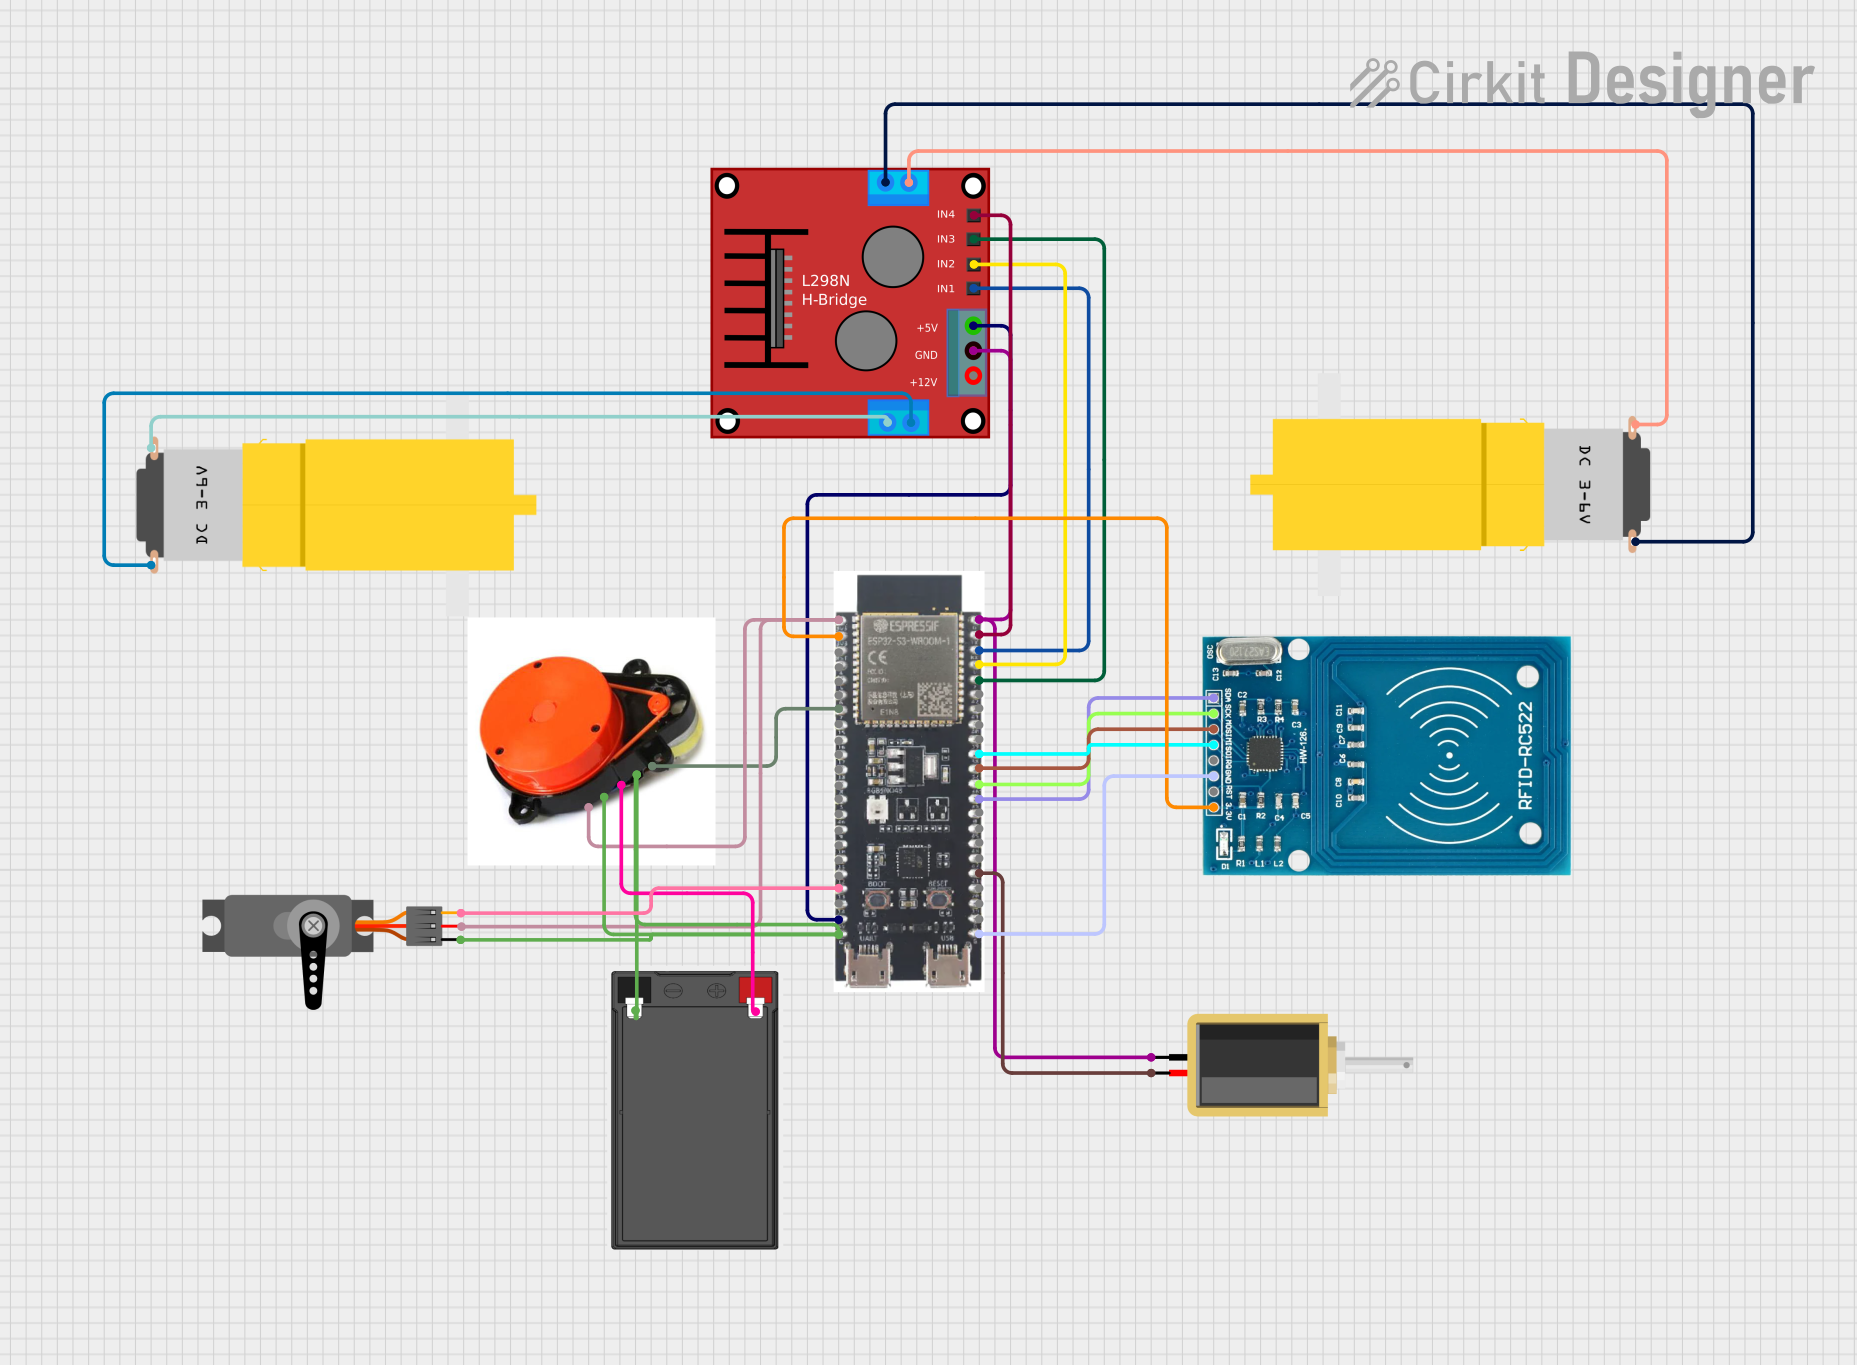
Circuit Documentation
Summary of the Circuit
This circuit is designed to control a pair of motors using an H-bridge driver, interface with a LIDAR sensor for distance measurement, operate a servo motor, read RFID tags, and drive a solenoid. The central processing unit of the circuit is an ESP32-S3 microcontroller, which manages the inputs and outputs, including sensor data and motor control signals. The circuit is powered by a battery, and the ESP32-S3 regulates the power distribution to the other components.
Component List
Motors
- Motor amarillo motorreductor hobby: A hobbyist yellow geared motor for driving mechanical loads.
Microcontroller
- ESP32-S3: A microcontroller with Wi-Fi capabilities, multiple GPIOs, and support for various communication protocols.
Motor Driver
- Ponte H (H-Bridge): An H-bridge motor driver that allows for control of motor direction and speed.
Sensors
- LIDAR def: A LIDAR sensor used for accurate distance measurement.
- RFID-RC522: An RFID reader module for reading RFID tags.
Actuators
- Solenoid: An electromagnetic actuator used for creating linear motion.
- Servo: A rotary actuator or servo motor that allows for precise control of angular position.
Power Source
- Battery: The primary power source for the circuit.
Wiring Details
Motor amarillo motorreductor hobby
- VCC: Connected to the output of the H-bridge driver.
- GND: Connected to the ground net of the circuit.
ESP32-S3
- 3v3: Powers the Servo (VCC) and RFID-RC522 (VCC).
- GPIO7: Connected to the LIDAR def (Tx) for data transmission.
- GPIO13: Connected to the Servo (PWM) for pulse-width modulation control.
- 5V: Powers the H-bridge driver.
- GND: Common ground for the entire circuit.
- GPIO43, GPIO44, GPIO1, GPIO2: Control signals for the H-bridge driver (IN4, IN1, IN2, IN3 respectively).
- GPIO38, GPIO37, GPIO36, GPIO35: SPI communication with RFID-RC522 (MISO, MOSI, SCK, SDA respectively).
- GPIO21: Controls the Solenoid.
Ponte H (H-Bridge)
- OUT1-Motor1, OUT2-Motor1, OUT3-Motor2, OUT4-Motor2: Outputs to the motors.
- 5V: Powered by the ESP32-S3.
- GND: Connected to the ground net.
- IN1, IN2, IN3, IN4: Control inputs from the ESP32-S3.
LIDAR def
- M+, Vcc: Powered by the battery.
- M-, Gnd: Connected to the ground net.
- Tx: Data transmission to the ESP32-S3.
RFID-RC522
- VCC (3.3V): Powered by the ESP32-S3.
- GND: Connected to the ground net.
- MISO, MOSI, SCK, SDA: SPI communication with the ESP32-S3.
Solenoid
- Pin1: Connected to the ground net.
- Pin2: Controlled by the ESP32-S3.
Servo
- VCC: Powered by the ESP32-S3.
- GND: Connected to the ground net.
- PWM: Pulse-width modulation control from the ESP32-S3.
Battery
- +: Powers the LIDAR def (Vcc).
- -: Connected to the ground net of the circuit.
Documented Code
No code has been provided for the microcontroller. The documentation of the code would typically include a description of the functionality implemented in the code, such as motor control algorithms, sensor data acquisition, communication protocols, and any other logic related to the operation of the circuit. Since no code is available, this section cannot be completed.