
ESP8266 NodeMCU Controlled HC-SR04 Ultrasonic Distance Sensor
View and Edit Project In Cirkit Designer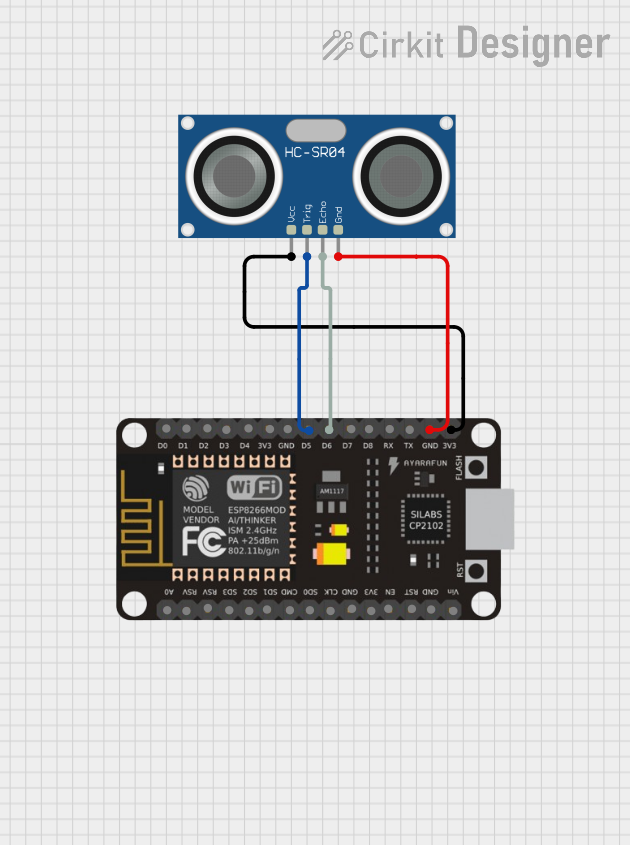
Circuit Documentation
Summary of the Circuit
This circuit integrates an HC-SR04 Ultrasonic Sensor with an ESP8266 NodeMCU microcontroller. The purpose of this circuit is to measure distances using the ultrasonic sensor and process the data with the ESP8266 NodeMCU. The ESP8266 is powered by its 3.3V pin and interfaces with the HC-SR04 sensor through specific GPIO pins for triggering and receiving echo signals. The ground pins of both components are connected to establish a common reference point for the voltages.
Component List
HC-SR04 Ultrasonic Sensor
- Description: An ultrasonic ranging sensor that provides 2cm to 400cm non-contact measurement functionality with a ranging accuracy that can reach up to 3mm.
- Pins:
- VCC: Power supply input (3.3V - 5V)
- TRIG: Trigger input pin
- ECHO: Echo output pin
- GND: Ground
ESP8266 NodeMCU
- Description: A low-cost Wi-Fi microchip with full TCP/IP stack and microcontroller capability.
- Pins:
- Digital I/O: D0 - D8
- RX: Receive pin for serial communication
- TX: Transmit pin for serial communication
- A0: Analog input
- 3V3: 3.3V power supply
- GND: Ground
- RST: Reset pin
- EN: Chip enable
- VIN: Voltage input for battery or regulated power supply
- SD0 - SD3, CMD, CLK: SD card interface
- RSV: Reserved
Wiring Details
HC-SR04 Ultrasonic Sensor
- VCC connected to 3V3 of ESP8266 NodeMCU
- TRIG connected to D5 of ESP8266 NodeMCU
- ECHO connected to D6 of ESP8266 NodeMCU
- GND connected to GND of ESP8266 NodeMCU
ESP8266 NodeMCU
- 3V3 supplies power to HC-SR04 Ultrasonic Sensor VCC
- D5 connected to TRIG of HC-SR04 Ultrasonic Sensor
- D6 connected to ECHO of HC-SR04 Ultrasonic Sensor
- GND provides a common ground with HC-SR04 Ultrasonic Sensor
Documented Code
No code has been provided for the microcontroller. The documentation for the code will be added once the code is available. The code is expected to initialize the ESP8266 NodeMCU's GPIO pins for communication with the HC-SR04 sensor, trigger the ultrasonic pulses, measure the time taken for the echo to return, and calculate the distance based on the time measurement. It should also include routines for handling any data processing and communication required by the application.